Related Experiment Video
Updated: Sep 30, 2026

Designing a Bio-responsive Robot from DNA Origami
Published on: July 8, 2013
Geometry-Mechanics Compatibility Enables Interpretable Inverse Design of Non-Rigid Origami
Yucong Sun1,2,3, Keyao Song1,2,3, Yiqiu Wang1,2,3
1School of Aeronautics and Astronautics, Shanghai Jiao Tong University, Shanghai 200240, China.

Abstract:
Non-rigid origami offers a geometric route to programmable mechanical and kinematic functions in metamaterials, deployable structures, and robotic mechanisms. Yet, its inverse design remains constrained by a fundamental modeling dilemma: High-fidelity nonlinear simulations become prohibitively expensive when repeatedly applied across large design spaces, whereas reduced models are efficient but often rely on pattern-specific assumptions whose validity is difficult to assess across crease patterns. Here, we introduce a compatibility-guided inverse-design framework that uses a geometry-mechanics test to determine when a parameterized design family can be reliably represented by a single-degree-of-freedom (1-DOF) kinematic model. Once qualified, the reduced model enables rapid and interpretable exploration of the admissible design space, while incompatible cases remain evaluated using high-fidelity analysis. We demonstrate the framework by designing origami metamaterials with programmable multistability and multi-plateau mechanical responses, enabled by the identification and removal of key geometric constraints. Its broader applicability is further illustrated through target-shape morphing and task-specific robotic motion programming. By turning model reduction from an assumed approximation into an explicit design decision, this framework provides a geometry-driven route from target functions to manufacturable non-rigid origami while reducing reliance on simulation-intensive search.
Related Concept Videos
 01:25
Coplanar Forces
 01:11
Bending of Members Made of Several Materials
Hooke's Law determines stress in each material, stating that stress is proportional to strain but varies due to each material's...
 01:22
Generalized Hooke's Law
 01:15
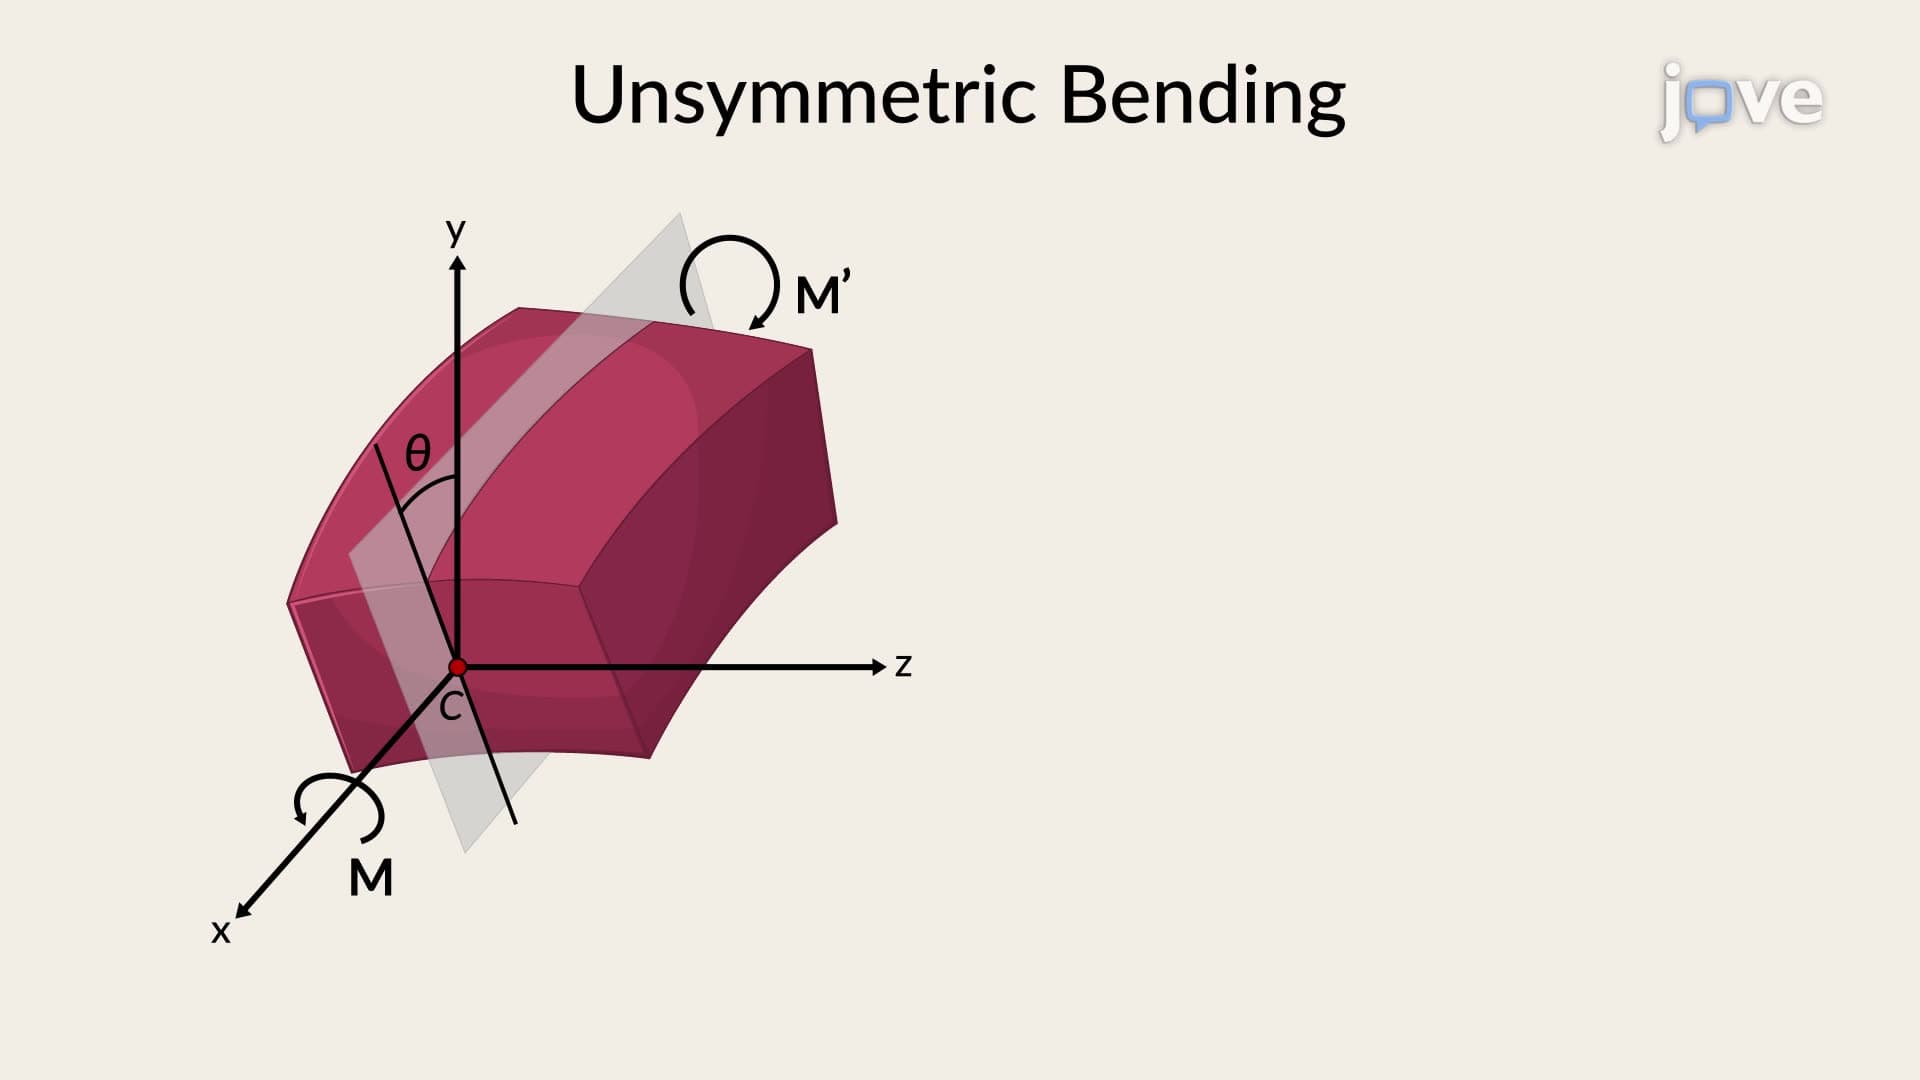
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
 01:09
Bending of Material: Problem Solving
 01:15
Relation between Poisson's ratio, Modulus of Elasticity and Modulus of Rigidity