Related Experiment Video
Updated: Jun 24, 2025

Design and Synthesis of a Reconfigurable DNA Accordion Rack
Published on: August 15, 2018
Easy-to-actuate multi-compatible truss structures with prescribed reconfiguration
Lin Ai1, Shukun Yin2,3, Weixia He3
1The Institute of Technological Sciences, Wuhan University, Wuhan, Hubei, 430072, China.

Abstract:
Multi-stable structures attract great interest because they possess special energy landscapes with domains of attraction around the stable states. Consequently, multi-stable structures have the potential to achieve prescribed reconfiguration with only a few lightweight actuators (such as shape-memory alloy springs), and do not need constant actuation to be locked at a stable state. However, most existing multi-stability designs are based on assembling bi-stable unit cells, which contain multitudes of distractive stable states, diminishing the feasibility of reconfiguration actuation. Another type is by introducing prestress together with kinematic symmetry or nonlinearity to achieve multi-stability, but the resultant structure often suffers the lack of stiffness. To help address these challenges, we firstly introduce the constraints that a truss structure is simultaneously compatible at multiple (more than two) prescribed states. Then, we solve for the design of multi-stable truss structures, named multi-compatible structures in this paper, where redundant stable states are limited. Secondly, we explore minimum energy paths connecting the designed stable states, and compute for a simple and inaccurate pulling actuation guiding the structure to transform along the computed paths. Finally, we fabricated four prototypes to demonstrate that prescribed reconfigurations with easy-actuation have been achieved and applied a quadra-stable structure to the design of a variable stiffness gripper. Altogether, our full-cycle design approach contains multi-stability design, stiffness design, minimum-energy-path finding, and pulling actuation design, which highlights the potential for designing morphing structures with lightweight actuation for practical applications.

Related Concept Videos
 01:21
Simple Trusses
The most basic planar truss is a simple truss with three members arranged in a triangular formation. This triangular truss is inherently stable and rigid due to its geometry, making it an ideal starting point for creating more...
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:25
Space Trusses
At the core of a space truss lies the fundamental unit known as the tetrahedron. This structure is composed of six members that form a three-dimensional shape...
 01:30
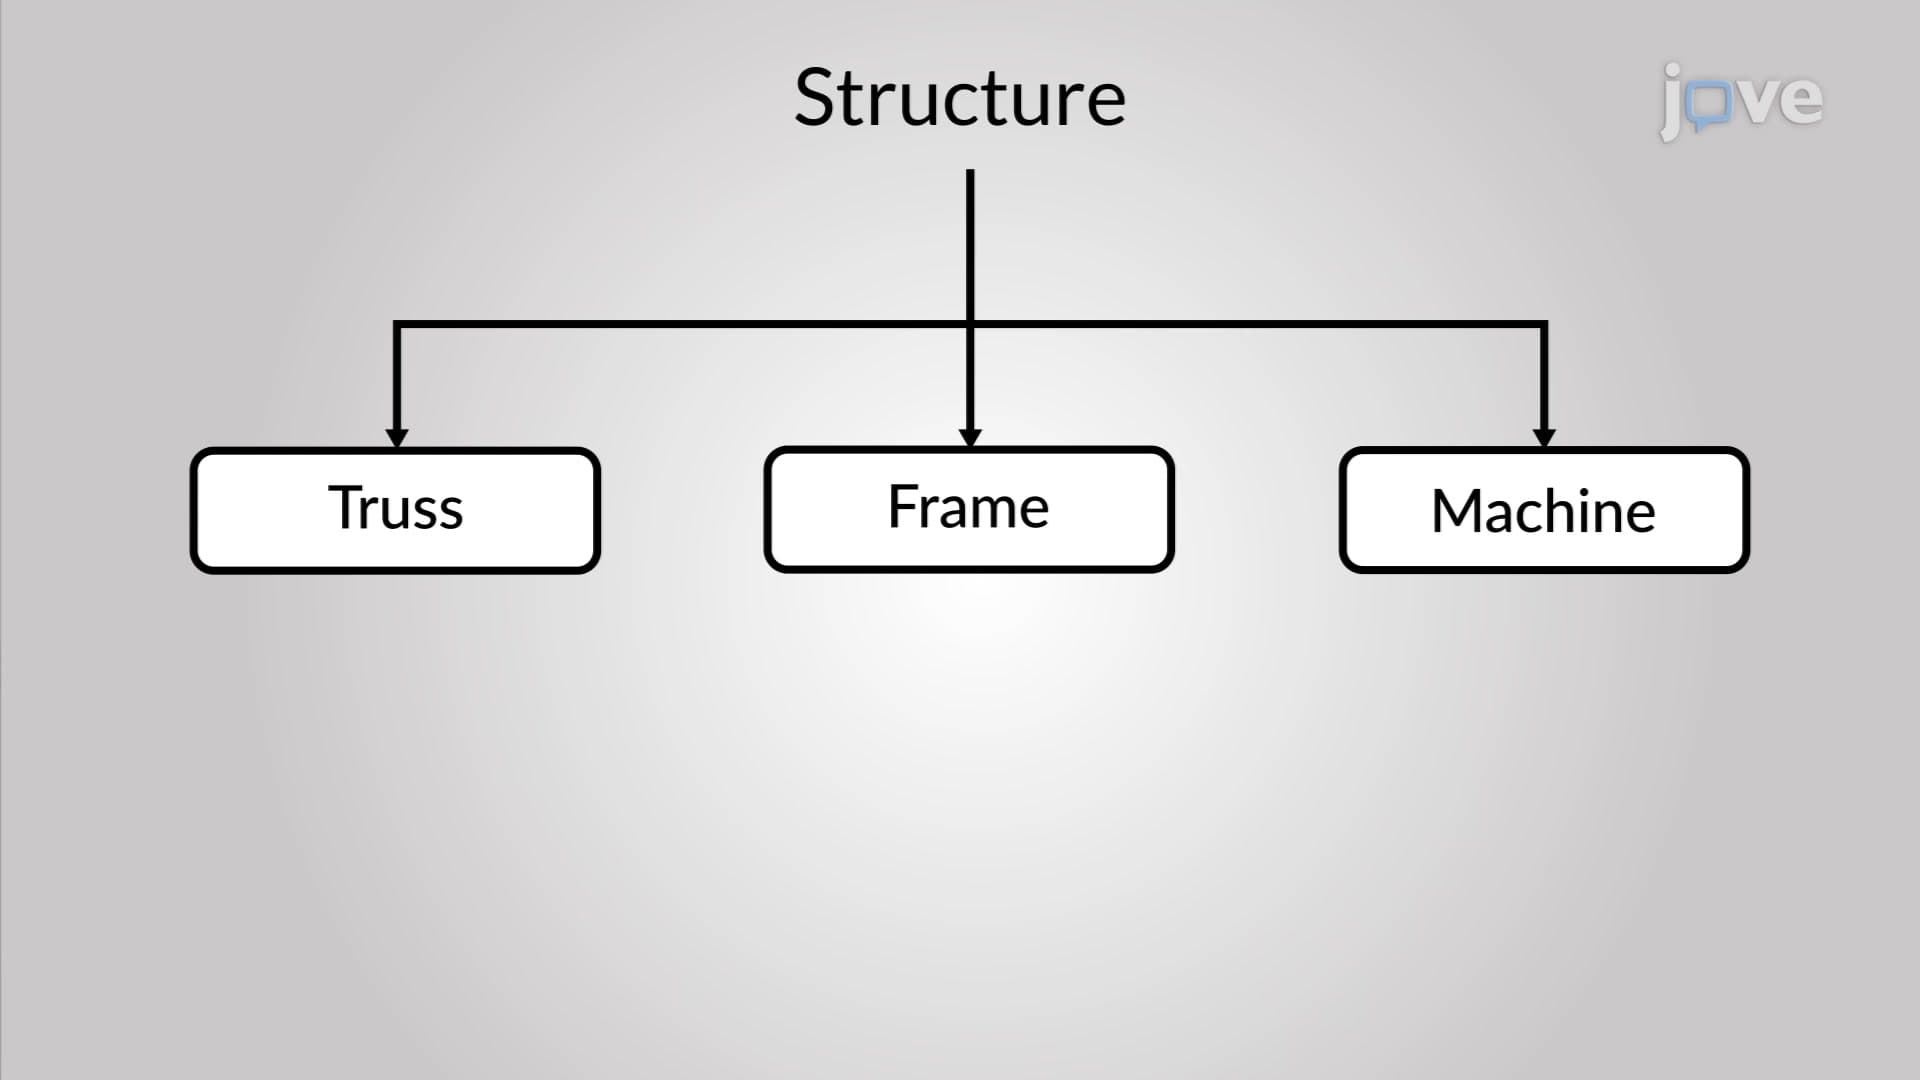
Introduction to Structures
There are three main...
 01:30
Zero-Force Member
One critical concept in truss design is the idea of zero-force members. It refers to a truss member that experiences no stress under loading conditions.
 01:30
Method of Joints
Since plane truss members are in the same plane, each joint is subjected to a coplanar and concurrent force system. To apply the method of joints, the first step is to...