Related Experiment Video
Updated: Oct 2, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Estimating Linear and Rotational Head Kinematics in Ice Hockey from a Single Helmet-Mounted IMU Using Vector
Dario Sciacca1, Anisoara Ionescu2
1Signal Processing Laboratory 5, Swiss Federal School of Technology (EPFL), 1015, Lausanne, Switzerland. dario.sciacca@epfl.ch.

Purpose:
Accurate estimation of head kinematics is critical for assessing brain injury risk in contact sports. This study introduces a Vector AutoRegressive (VAR) framework to jointly model linear acceleration and angular velocity during head impacts, capturing the inherent coupling between translational and rotational dynamics.
Methods:
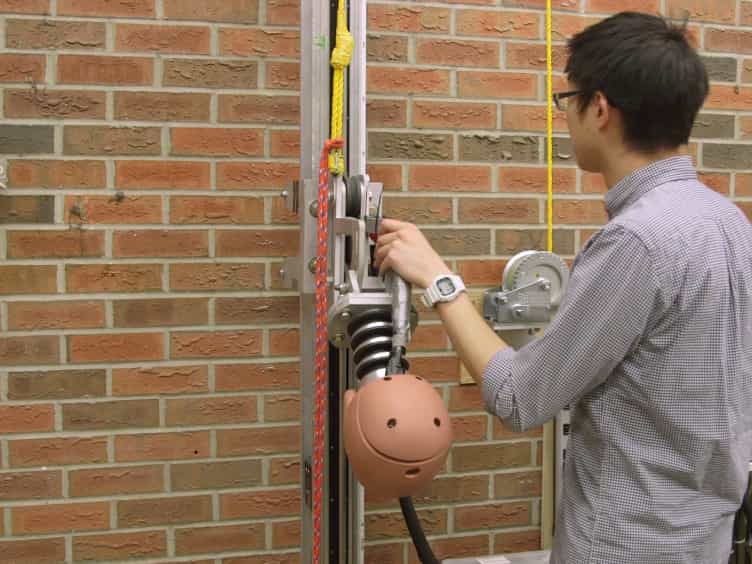
Controlled impacts were performed on a helmeted Hybrid III 50th percentile male headform using a pendulum impactor across multiple locations (front, front-oblique, side, rear-oblique) and three impact intensities (30°, 50°, 70° pendulum angles). Helmet-mounted Inertial Measurement Unit (IMU) signals were processed using VAR models trained on reference headform data at 30° and 50° impacts. The proposed framework was also evaluated for the estimation of head kinematics at untrained impact intensities (70°).
Results:
At the trained intensities, the VAR approach generally improved angular velocity reconstruction across impact configurations, with PMPE and RMSE reductions of up to 20.9 pp (-81.1%) and 288.8 °/s (-85.7%), respectively, at 30°. Linear acceleration improvements were more limited, with PMPE and RMSE reductions of up to 171.8 pp (-85.7%) and 10.9 g (-74.8%), also at 30°. At the untrained 70° intensity, angular velocity PMPE decreased at all locations but significantly only at the front-oblique, while RMSE decreased significantly at the front and front-oblique (up to - 341.1 °/s, - 52.2%). In contrast, linear acceleration PMPE degraded at all locations, increasing by up to 68.6 pp (+726.4%), while RMSE showed either deterioration or non-significant improvement.
Conclusion:
In conclusion, the VAR modeling framework offers a promising multivariate approach for reconstructing head impact kinematics from a single IMU-instrumented helmet. However, limited generalization to higher, untrained intensities highlights the need for further development before real-time head injury assessment can be supported.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:26
Kinematic Equations - I