Related Experiment Video
Updated: Oct 7, 2026
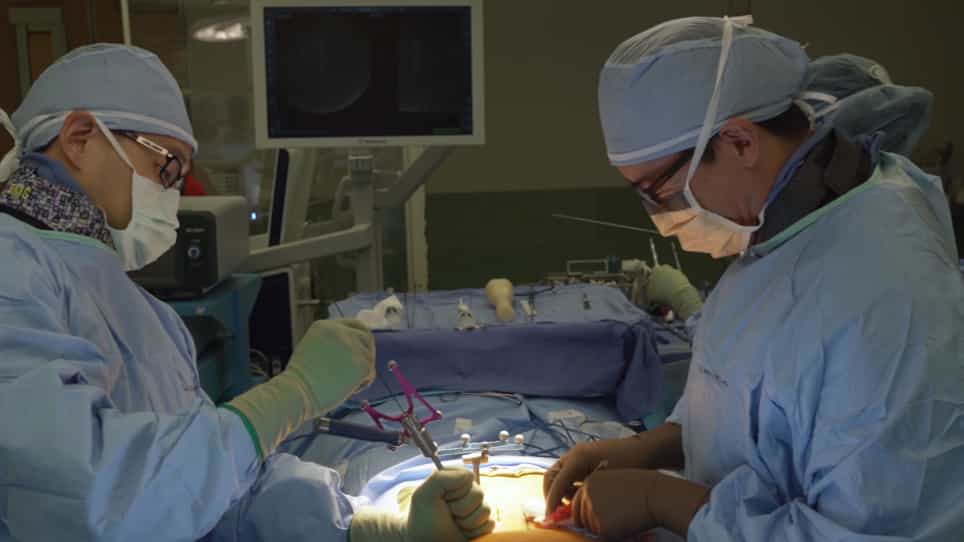

Cone Beam Intraoperative Computed Tomography-based Image Guidance for Minimally Invasive Transforaminal Interbody Fusion
Published on: August 6, 2019
Radiation-free real-time registration update for image-guided multilevel open posterior lumbar fusion: in vivo
Ryan B Duke1, Xiaoyao Fan1, Steven P Baltic2
1Thayer School of Engineering, Dartmouth College, Hanover, NH 03755, United States.

Abstract:
Background: Surgical navigation becomes inaccurate when spinal alignment changes, requiring repeat scan such as O-arm CT to restore accuracy, but this introduces additional radiation exposure, workflow disruption, and delay. We developed and confirmed ex vivo validation of a novel hand-held system (HHS) that can update a preoperative CT (pCT) using intraoperative stereovision (iSV), leveraging a level-wise registration framework to account for intervertebral motion. Methods: iSV guidance was compared against Medtronic Stealth Station guidance for lumbar pedicle screw placement in 6 live Yucatan mini-pigs. The animals were positioned supine with hyperextension of the lumbar spine for pCT. They were then positioned prone with flexion of the lumbar spine during surgery. iSV data of exposed spine was acquired to generate an updated CT (uCT) to reflect the current spinal alignment. Half of the pedicle screws were randomly selected to be placed using pCT and the other half with uCT. The surgeon was blinded and was instructed to place the screws solely based on guidance provided by the navigation system. Results: A total of 66 pedicle screws were implanted in 6 live animals. Only 1 of the uCT navigated screws showed a grade 3 (>4 mm) breach of 5.5 mm, whereas the pCT navigated screws had 3 instances with values of 18 mm, 9.5 mm, and 10.9 mm. The registration error of the iSV uCT was lower than that of the pCT (3.9±1.9 mm vs 6.1±5.4 mm; p<.05). Conclusions: Intraoperative Stereovision uCT resulted in lower registration error and improved pedicle screw accuracy in live animals.