Related Experiment Video
Updated: Oct 17, 2026
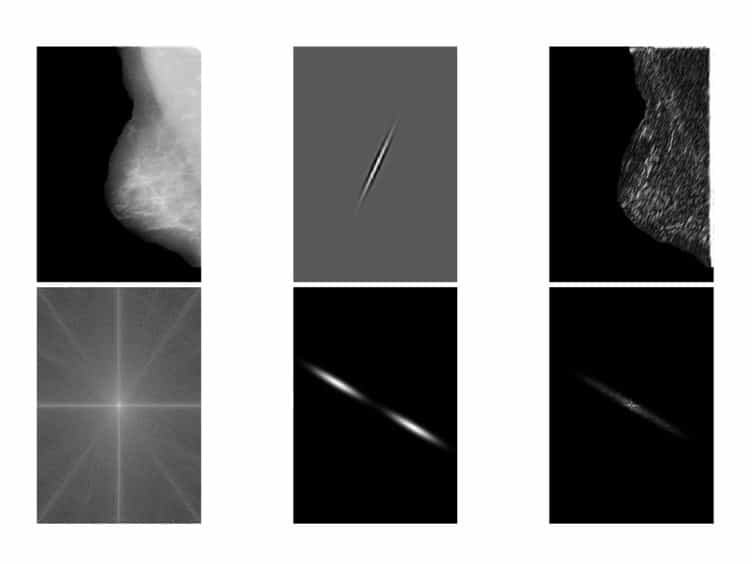
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
GCGFormer: Geometry-Compatibility-Guided Attention for Rotated Object Detection
Huiji Wang1, Dandan Huang1, Zhi Liu1,2
1School of Electronic Information Engineering, Changchun University of Science and Technology, Changchun 130022, China.

Abstract:
Rotated object detection in remote sensing imagery requires both semantic understanding and accurate geometric reasoning. Existing geometry-aware detectors commonly introduce geometric information through oriented proposals or decoder queries, making their designs dependent on specific detection architectures, while geometric relationships among feature tokens remain insufficiently explored. To address this limitation, we propose GCGFormer, a geometry-compatibility-guided attention module for rotated object detection. Specifically, GCGFormer constructs a dual-token representation and a geometry compatibility matrix to model pairwise spatial relationships, including positional proximity, aspect ratio consistency, and orientation alignment. The matrix is integrated into self-attention to jointly optimize semantic similarity and geometric coherence. The proposed module can be readily integrated into existing detectors without extensive modifications. As an architecture-independent module placed before the detection head, GCGFormer can be integrated into different rotated object detectors. Experiments on DOTA-v1.0 show that GCGFormer improves the mAP of Oriented R-CNN from 65.1% to 65.6%, Rotated Faster R-CNN from 63.3% to 63.8%, Rotated ATSS from 61.7% to 62.1%, S2ANet from 62.7% to 63.1%, and YOLOv8-OBB from 72.7% to 72.9%. These consistent, although modest, improvements demonstrate that explicit feature-token geometric compatibility provides a generally applicable complement to semantic attention for rotated object detection.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:11
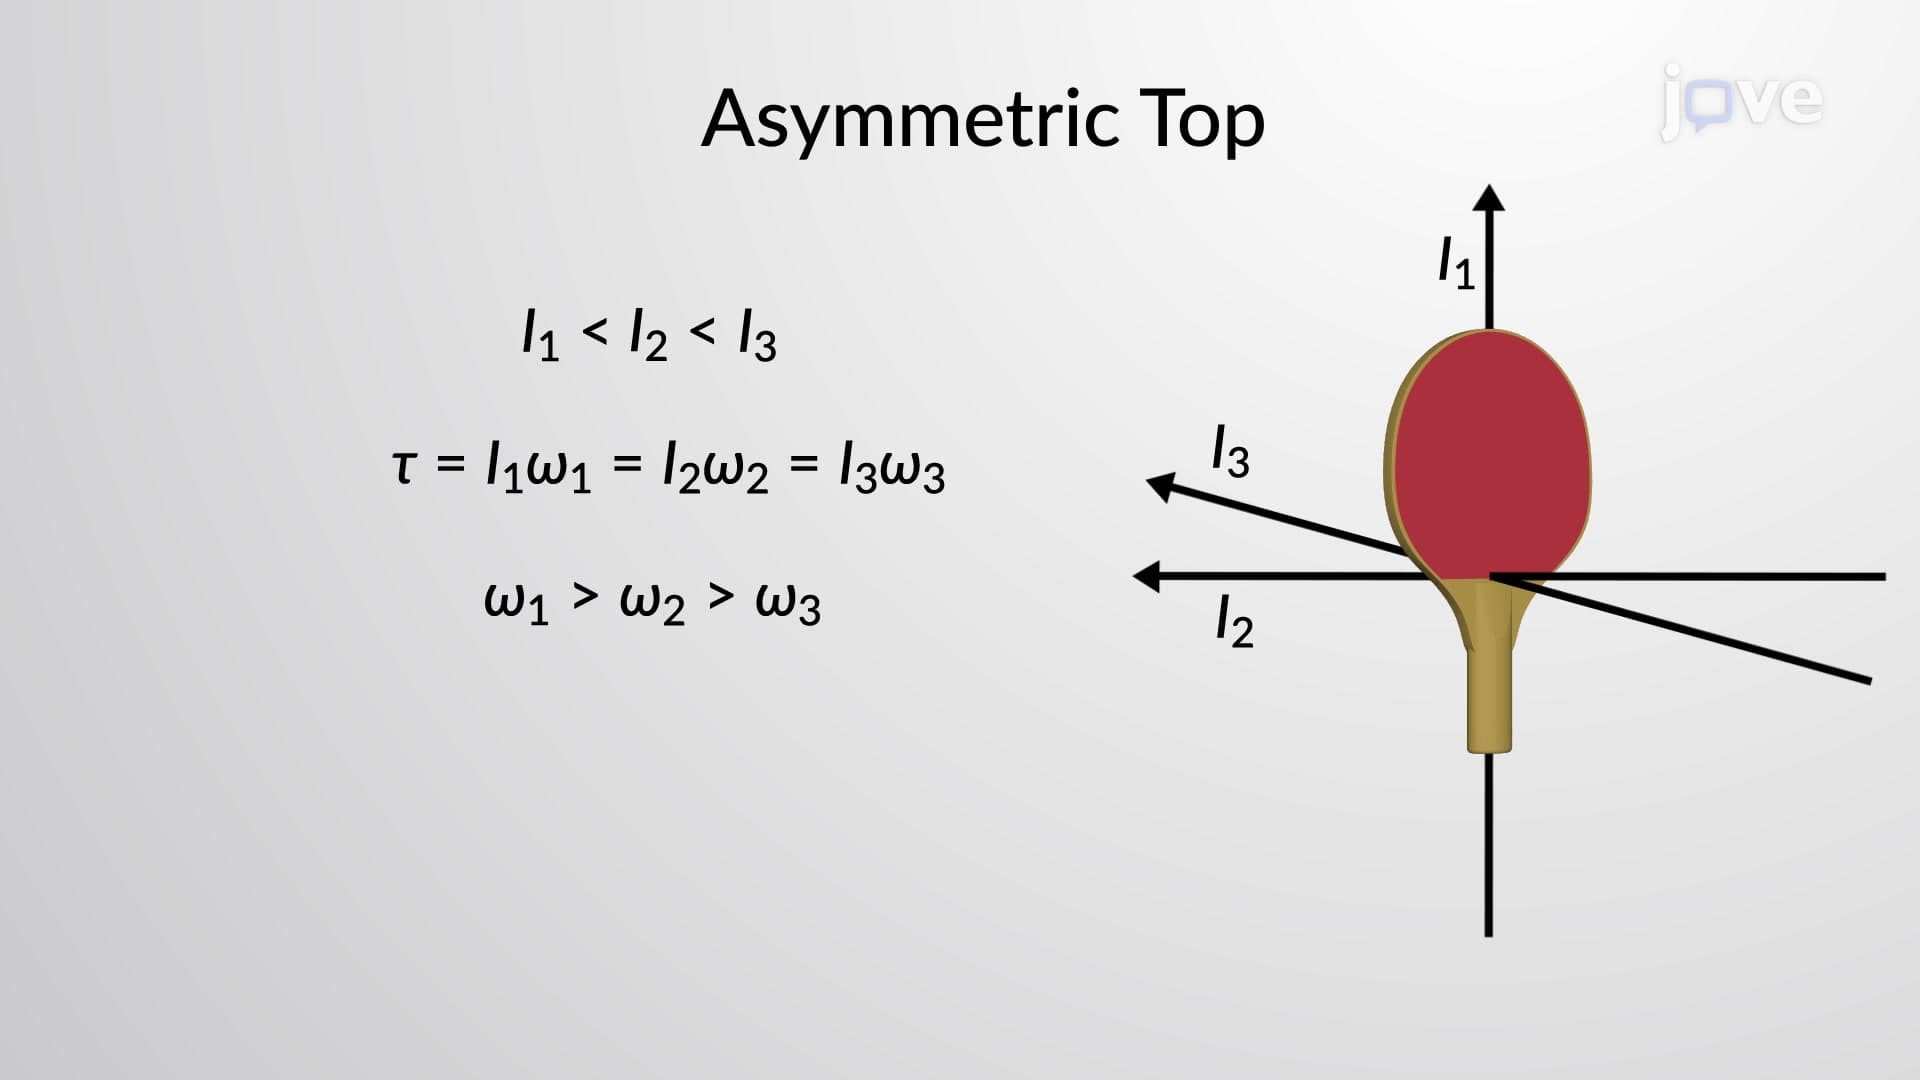
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:16
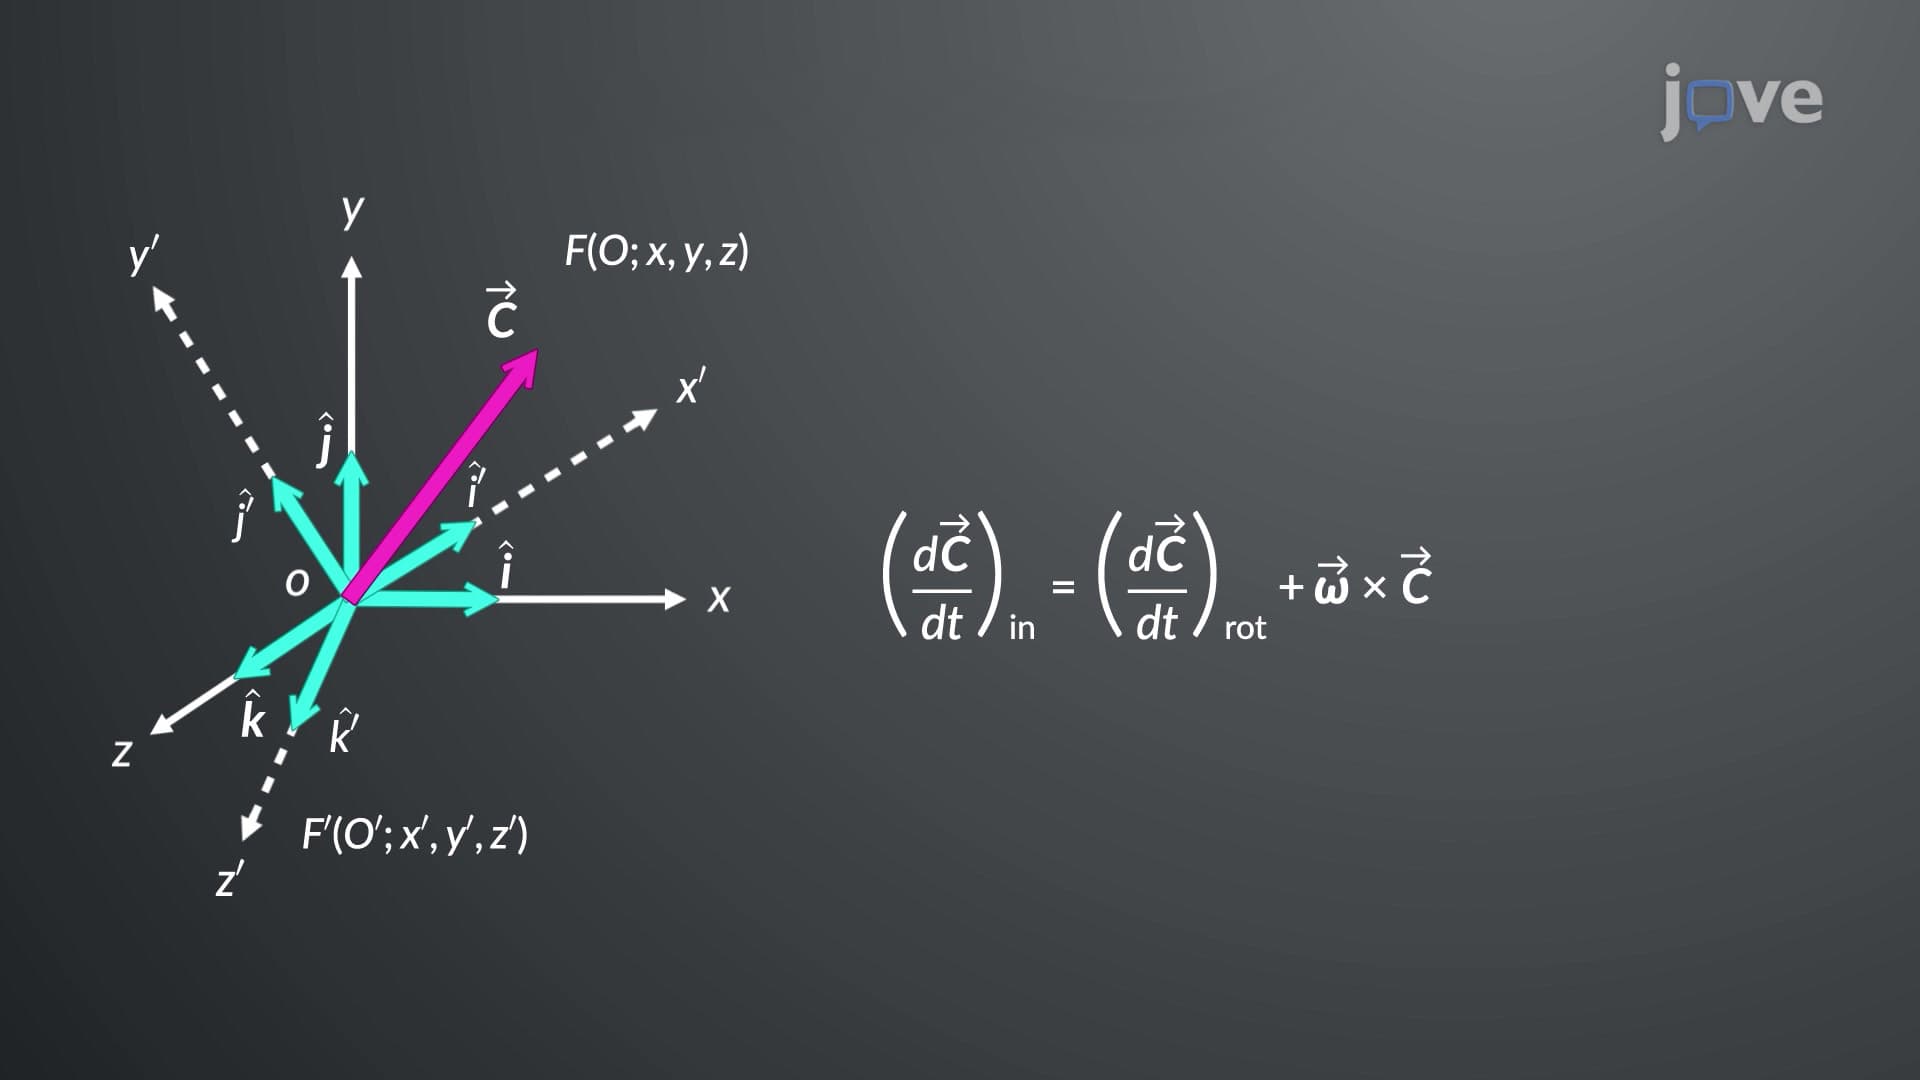
Vector Transformation in Rotating Coordinate Systems
 01:20
Gauss's Law: Cylindrical Symmetry