Related Experiment Video
Updated: Oct 19, 2026
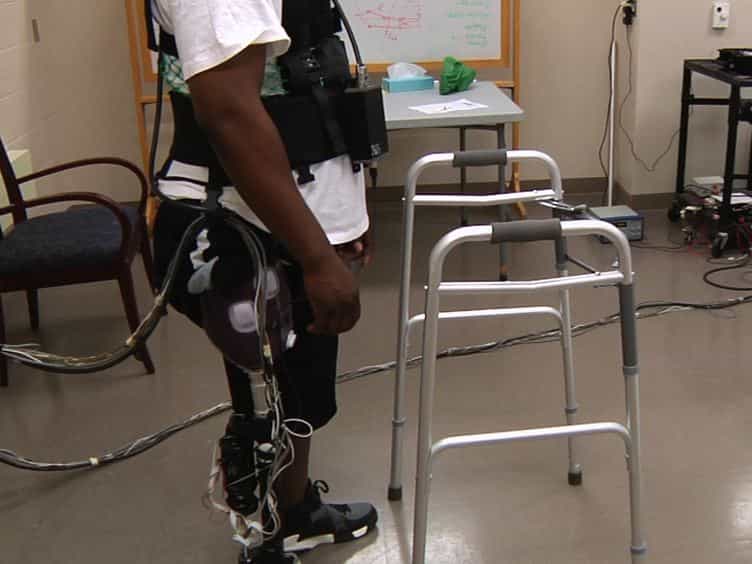
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Multi-dataset benchmarking and preliminary transfer learning for lower-limb EMG classification toward adaptive
Jafar Jafar1, Cezary Rzymkowski1,2, Andrzej Kordecki1
1Faculty of Power and Aeronautical Engineering, Institute of Aeronautics and Applied Mechanics, Warsaw University of Technology, Nowowiejska 24, 00-665 Warsaw, Poland.

Purpose:
Reliable decoding of lower-limb motor intent from surface electromyography signals remains challenging due to electrode placement variability, muscle fatigue, inter-subject differences, and differences between able-bodied and amputee populations. This study evaluates the robustness of commonly used machine-learning approaches for lower-limb electromyography classification under these sources of variability.
Methods:
A unified benchmarking analysis was conducted across four lower-limb electromyography datasets: UCI lower limb electromyography, vastus medialis electromyography, K2MUSE, and the above-knee sit-to-stand (STS) amputee dataset. Three classification models - support vector machine, random forest, and multilayer perceptron - were evaluated using standardized preprocessing and feature extraction pipelines. Cross-subject robustness was assessed using leave-one-subject-out (LOSO) validation on the K2MUSE dataset. A preliminary transfer-learning experiment was also performed by fine-tuning a multilayer perceptron pretrained on able-bodied data using the amputee STS dataset.
Results:
The random forest model achieved the highest performance in datasets with lower variability, with macro F1 scores of 0.9033 ± 0.0048 on the UCI dataset and 0.6000 ± 0.0087 on the vastus dataset. Under cross-subject non-ideal acquisition conditions, performance decreased for all models. The multilayer perceptron showed competitive robustness in the K2MUSE ideal-versus-fatigue LOSO evaluation (0.476 ± 0.058 macro-F1), while random forest showed the most compact subject-wise distribution (median 0.476 [interquartile range 0.049]). In the transfer-learning experiment, fine-tuning improved performance on the above-knee STS dataset relative to training from scratch (macro-F1 0.5540 ± 0.0141 vs. 0.5203 ± 0.0371).
Conclusions:
These results highlight the different strengths of classical and neural machine-learning models under varying electromyography variability conditions and provide a foundation for more robust intention-decoding systems for adaptive lower-limb prosthetic control.