Related Experiment Video
Updated: Oct 19, 2026
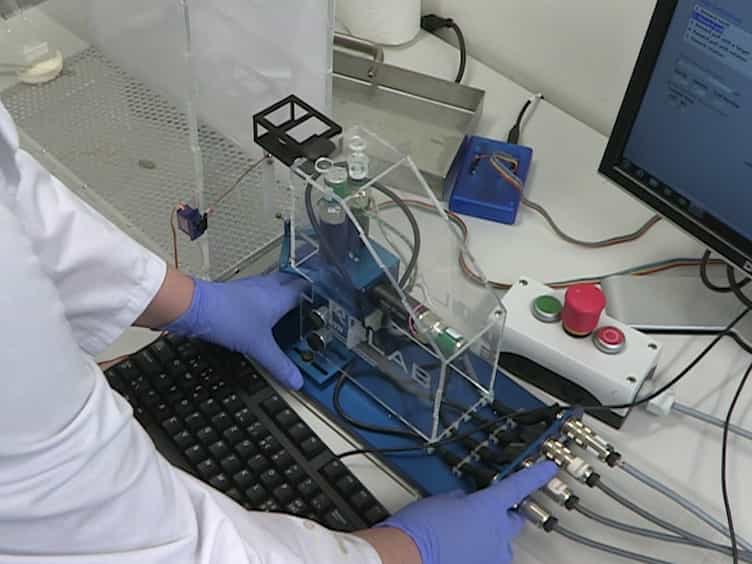
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Data-Driven and Physics-Informed Modeling Perspectives for Soft Manipulators: From SINDy to Hybrid Intelligence
Wenbo Hui1, Yunyi Wang1, Teng Zhang1
1Department of Mechanical Engineering, University of Bath, Bath, UK.

Abstract:
Soft manipulators offer a route to safer, more adaptive and physically intelligent robots, but their compliant bodies remain difficult to model, predict and control. Large deformation, distributed actuation, hysteresis, material variability and contact-rich interaction challenge both classical mechanics-based models and purely data-driven approaches. Here, we examine emerging modeling perspectives for soft manipulators through a conceptual progression from sparse identification of nonlinear dynamics to hybrid intelligence. We discuss how sparse identification of nonlinear dynamics (SINDy), Koopman learning, neural ordinary differential equations, physics-informed neural networks, and hybrid physics machine learning models contribute complementary capabilities, including interpretable reduced-order dynamics, control-ready prediction, continuous-time latent modeling, physics-constrained field reconstruction, and residual correction. We present that no single modeling approach is sufficient for the next generation of soft robotic systems. Instead, progress requires integrated modeling ecosystems that combine mechanical structure, data-driven discovery and task-aware adaptation. Such hybrid-intelligence frameworks can transform models from passive descriptions of deformation into active components of sensing, control, design and decision-making, enabling soft manipulators that are more interpretable, robust and deployable in real-world environments.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:21
Manipulation and Analysis