Related Experiment Videos
Efficient Hamiltonian, structure and trace distance learning of Gaussian states
Marco Fanizza1,2,3, Cambyse Rouzé4, Daniel Stilck França5,6
1Inria, Télécom Paris - LTCI, Institut Polytechnique de Paris, Palaiseau, France. marco.fanizza@inria.fr.

Abstract:
When learning descriptions of many-body quantum systems, assuming locality of interactions can dramatically reduce the required number of observations and computational time compared to unstructured approaches. In this work, we uncover an infinite-dimensional instance of this phenomenon, initiating the study of Hamiltonian learning for positive-temperature bosonic Gaussian states. We present sample- and computationally efficient protocols for inferring the parameters and graph structure of underlying quadratic Hamiltonians, provided that temperature, squeezing, displacement, and the interaction graph's maximal degree are bounded. Notably, our protocol relies solely on heterodyne measurements, which are often experimentally feasible, and achieves a sample complexity that scales only logarithmically with the number of modes. Furthermore, our techniques allow for the learning of positive-temperature Gaussian states in trace distance with quadratic scaling in precision and polynomial scaling in the number of modes.
Related Concept Videos
 01:30
Gaussian Elimination: Problem Solving
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:18
First Law: Particles in Two-dimensional Equilibrium
Newton's first law tells us about the...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
 01:13
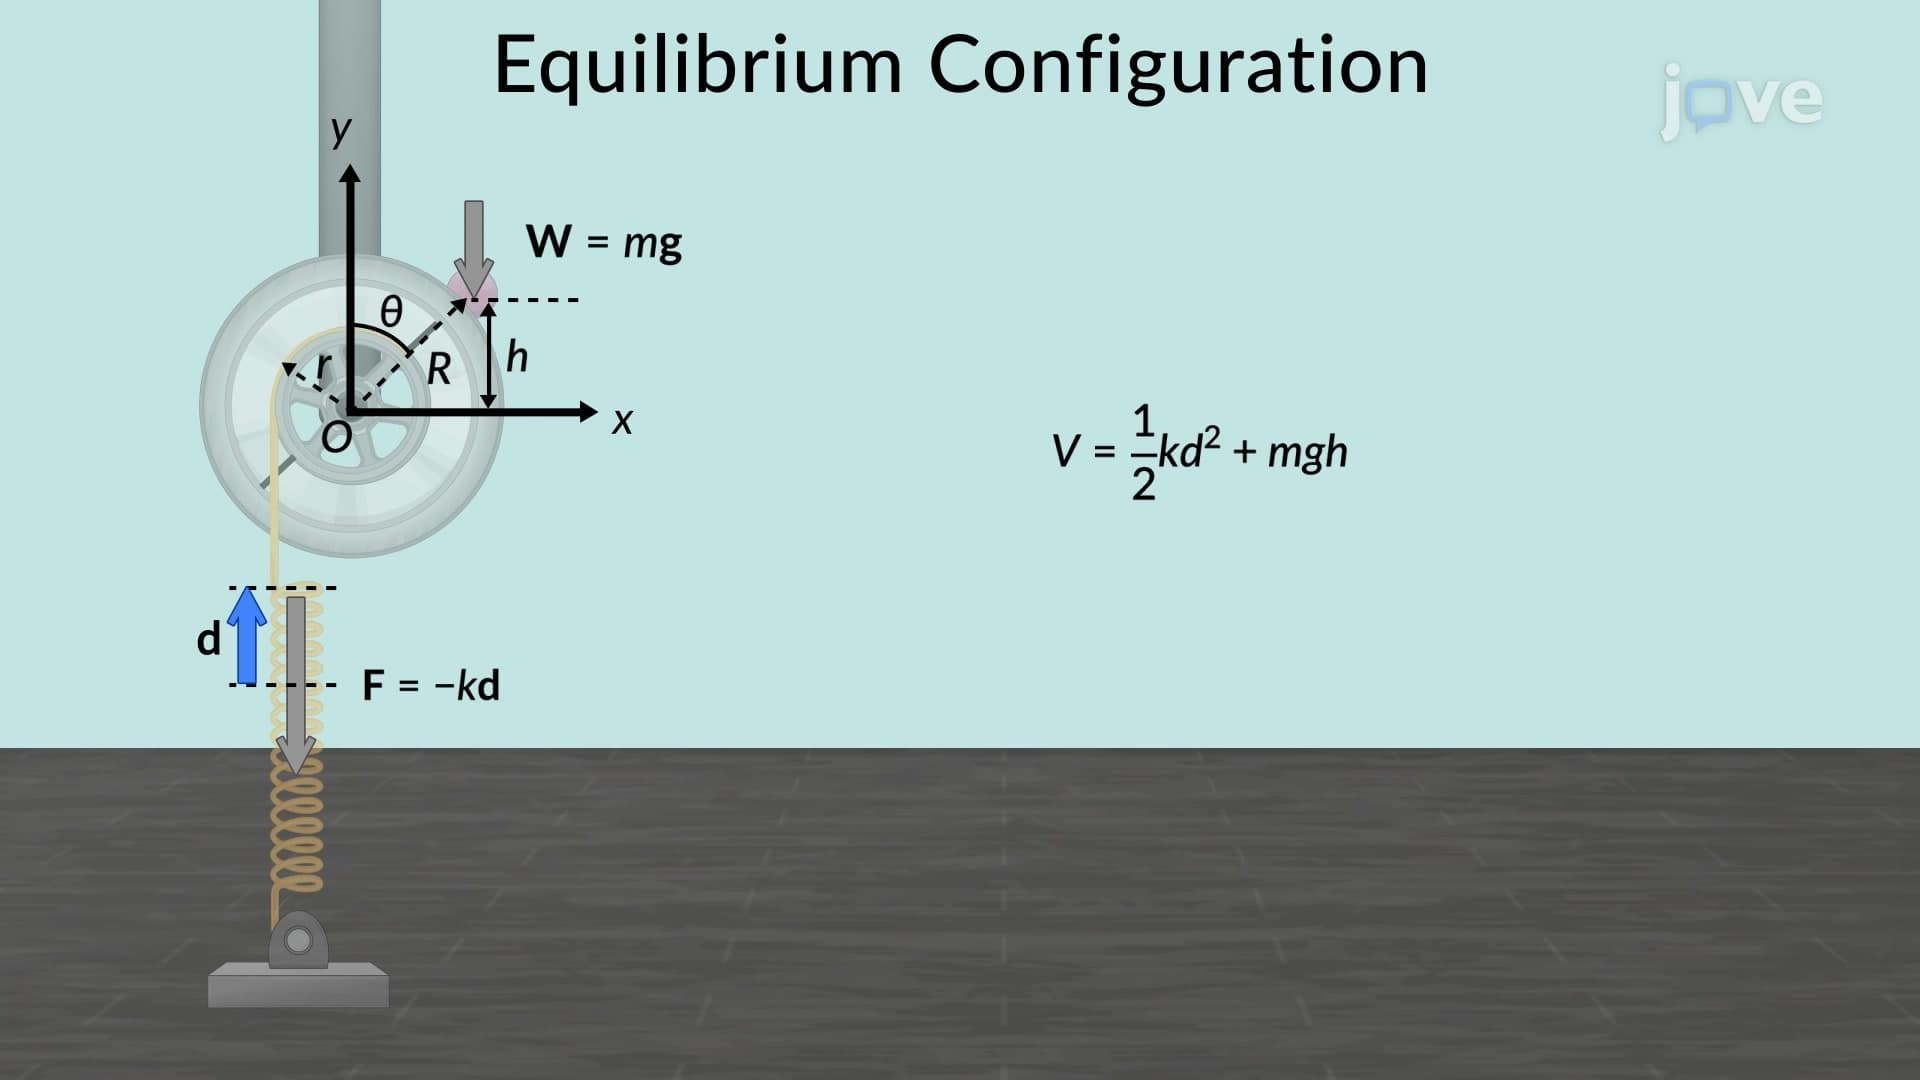
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...