Related Experiment Video
Updated: Oct 25, 2026
DeepOmicsAE: Representing Signaling Modules in Alzheimer's Disease with Deep Learning Analysis of Proteomics, Metabolomics, and Clinical Data
Published on: December 15, 2023
An autoencoder conjugacy network to learn one-dimensional chaotic maps
Meagan Carney1, Cecilia González-Tokman1, Ruethaichanok Kardkasem1
1School of Mathematics and Physics, The University of Queensland, St Lucia, Australia.

Abstract:
We introduce a data-driven method for learning one-dimensional chaotic maps using an improved autoencoder architecture that incorporates a conjugacy layer in the latent space. The network learns an unknown conjugacy mapping the original chaotic map into latent space, where a known transformation to the tent map is applied to constrain the representation. This approach enforces dynamical principles while improving the accuracy of predicted orbits for one-dimensional chaotic maps that share the topological entropy of, and the single unimodal shape of, the standard logistic map. We demonstrate its effectiveness within this scope on continuous and one-dimensional piecewise chaotic maps, showing improved performance over traditional and recent deep learning architectures, and identify possible failure modes when the target map lies outside this conjugacy class.
Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:20
Region of Convergence of Laplace Tarnsform
Consider a decaying exponential signal that begins at a specific time. When deriving its Laplace transform, the time-domain variable is replaced with a complex variable. This substitution...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
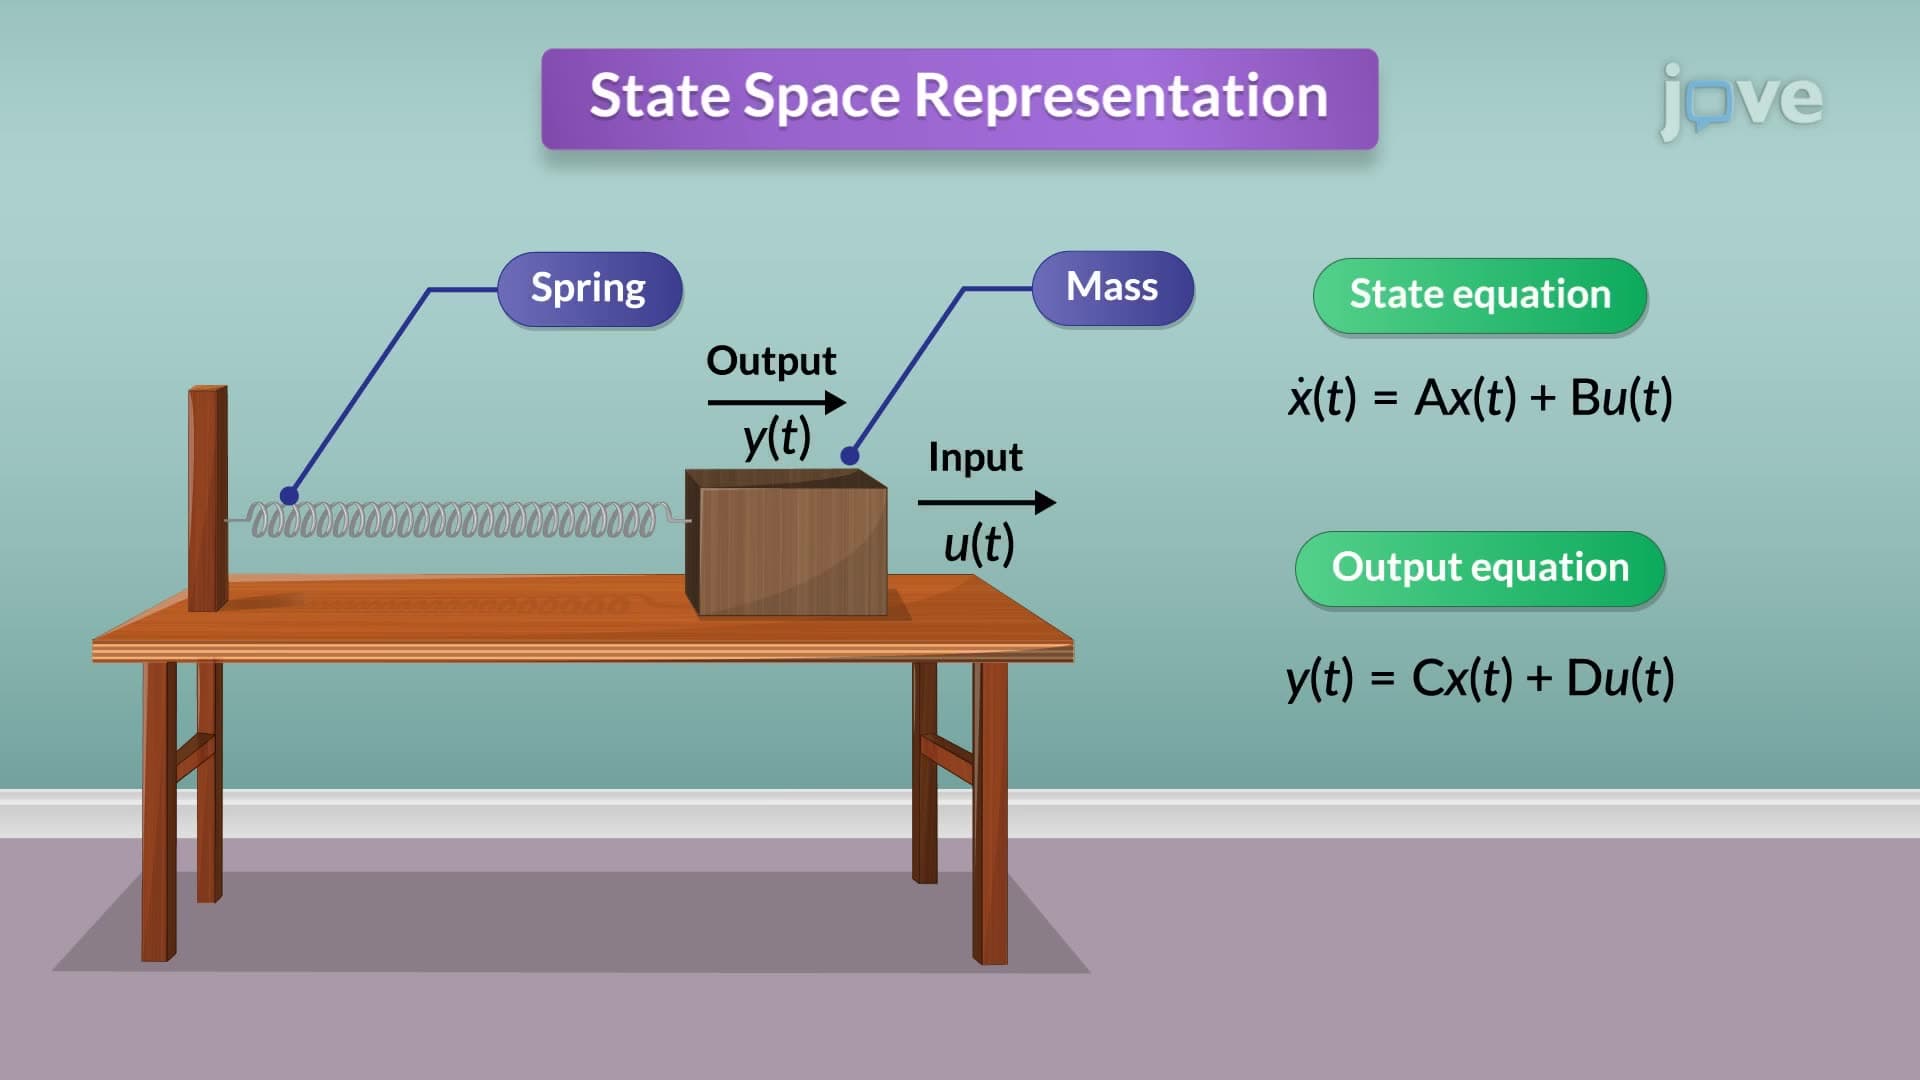
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
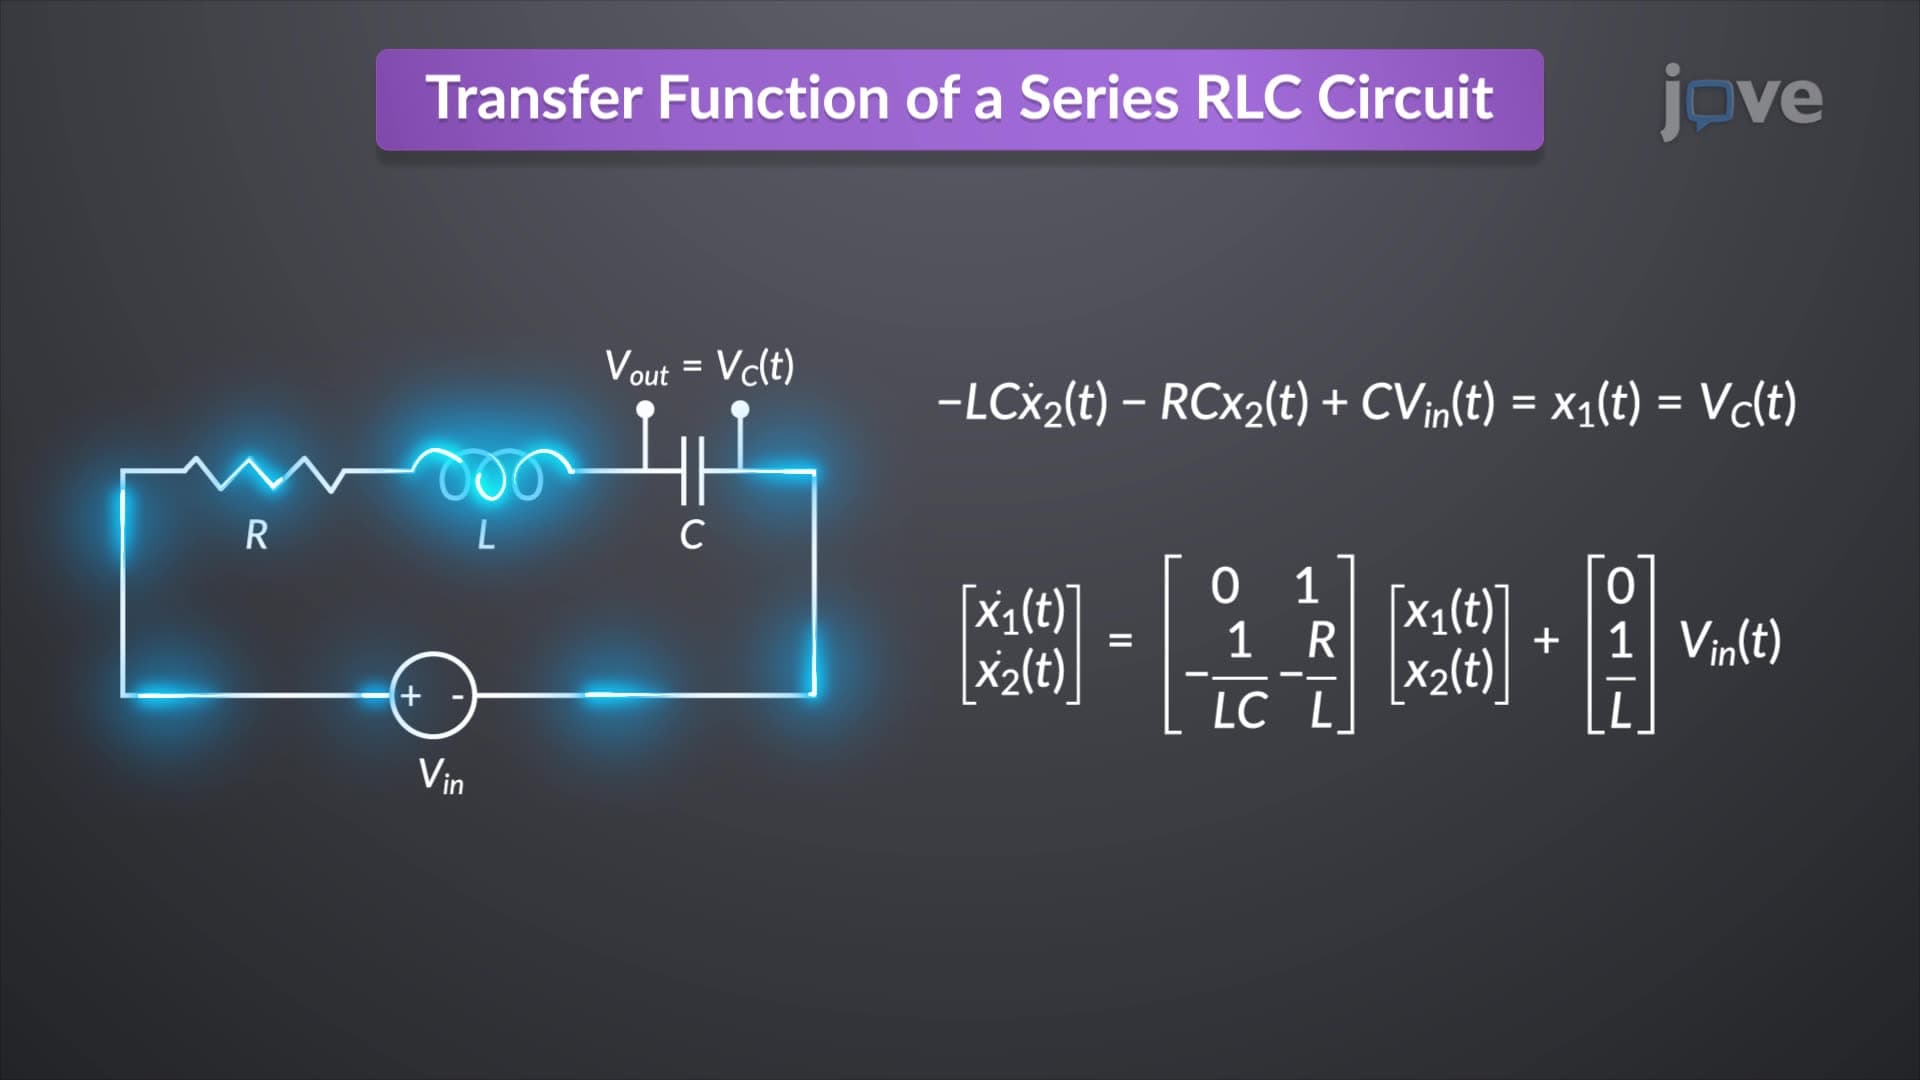
Transfer Function to State Space
In an RLC...