Related Experiment Video
Updated: Oct 25, 2026
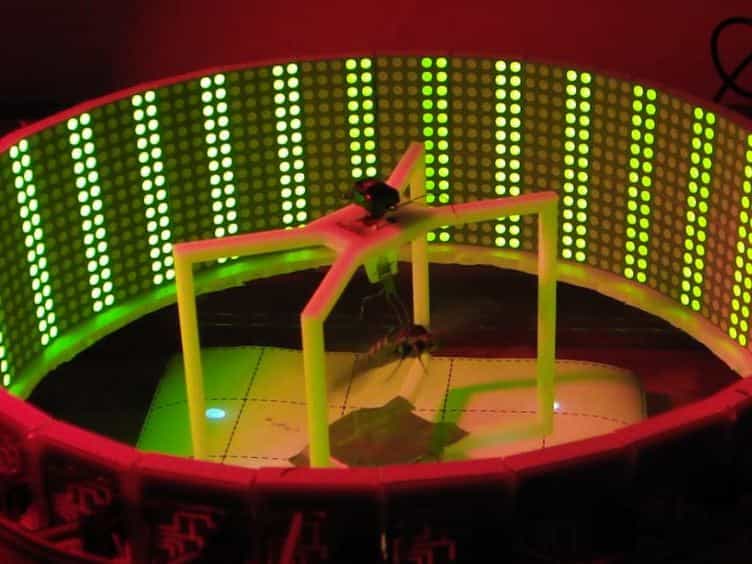
Early Metamorphic Insertion Technology for Insect Flight Behavior Monitoring
Published on: July 12, 2014
Morphological intelligence for dynamic aerial interactions
Yongkang Jiang1, Junjin Li1, Shuyu Meng2
1Shanghai Research Institute for Intelligent Autonomous Systems & State Key Laboratory of Autonomous Intelligent Unmanned Systems, Tongji University; Shanghai, 201210, China.

Abstract:
Biological flyers achieve ecological dominance not through flight alone, but by seamlessly integrating aerial locomotion with forceful physical interactions, including snatching prey, perching on irregular surfaces, and operating across diverse media. Translating this agility into aerial robotics demands reconciling a fundamental conflict: impulsive, high-force actions destabilize the flight platform. Here, we present a bio-inspired unmanned aerial vehicle (UAV) equipped with a mechanically intelligent impulsive limb that resolves this tradeoff through physical decoupling. An asymmetric bistable impulse module delivers a 2.3-fold extension within 70 ms, while a soft-linkage architecture reduces the transmission of impulsive interaction forces to the airframe. For the tested seven-segment configuration, intrinsic geometric tolerance corresponds to a passive vertical accommodation range of approximately 70% of the fully deployed arm length, reducing the need for precise altitude regulation within the tested range. We demonstrate the system's multimodal capacity through dynamic in-flight snatching, energy-efficient perching, high-impact solid fracture, and cross-medium capture in viscous fluids, establishing a new paradigm for UAVs executing physically demanding tasks in complex environments.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Application of Linearization and Approximation
 02:50
Morphogenesis