Related Experiment Video
Updated: Oct 26, 2026
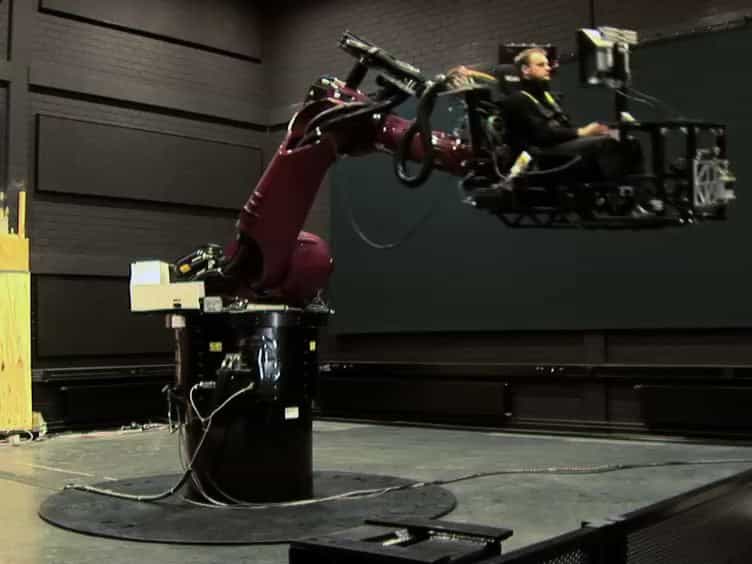
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Time Uncertainty in Intelligent Multi-Source Navigation Systems: Impact Analysis, Algorithm Design, and System
Xin Liu1, Wenshuo Li2, Chenliang Wang1
1School of Automation Science and Electrical Engineering, Beihang University, Beijing 100083, China.

Abstract:
Intelligent multi-source navigation systems (IMSNS), designed to fuse information from multiple physical domains-including optical, mechanical, electrical, magnetic, and thermal-play a key role in ensuring cross-domain intelligent flight for aircraft. With the growing complexity of operational scenarios for cross-domain intelligent aircraft, disturbances and uncertainties have become increasingly prevalent in IMSNS. As systems characterized by strong spatiotemporal coupling, IMSNS performance depends heavily on precise and reliable time information. Particularly under highly dynamic motion conditions, time uncertainty has emerged as a critical factor constraining further improvement in system performance. For a general class of IMSNS, this paper first outlines the generation mechanisms and impact characteristics of time uncertainties. Based on their physical origins, time uncertainties in IMSNS are categorized into 2 types: (a) absolute time uncertainties, represented by time dissemination errors, which relate to time reference issues; and (b) relative time uncertainties, represented by timekeeping errors, which correspond to time alignment problems. The influence mechanisms of these two types of time uncertainty on IMSNS are analyzed separately. On this basis, a time uncertainty mitigation scheme that integrates hardware enhancement with algorithmic optimization is proposed. The scheme is capable of addressing time uncertainties through optimized system design, system modeling considering multi-source heterogeneous time uncertainties, and refined estimation and compensation algorithms. To validate and examine the proposed scheme, the bioinspired polarization navigation system is taken as a representative IMSNS case study. Simulation and experimental results demonstrate the effectiveness of the proposed time uncertainty mitigation scheme.
Related Concept Videos
 01:29
Real-World Applications of Space Curves
 01:30
Vector Functions and Motion: Problem Solving
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:26
Errors in Global Positioning System
 00:59
Uncertainty: Overview
 01:10
Propagation of Uncertainty from Systematic Error