Related Experiment Video
Updated: Oct 27, 2026
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
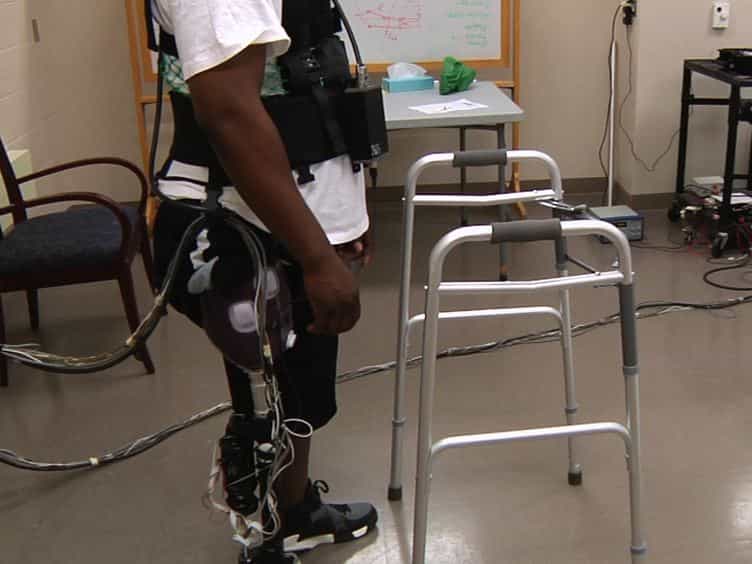
Integrated Multi-Terrain Locomotion Recognition and Knee-Exoskeleton Assistance for Load Carrying: A Feasibility
Jun Liu1, Yichen Lin2,3,4, Yinuo Yao3
1National Earthquake Response Support Service, Beijing 100049, China.

Abstract:
Multi-terrain load carriage changes knee motion and muscular demand, requiring assistance that adapts to the current locomotion task. This feasibility study evaluated an integrated pipeline in which five inertial measurement units (IMUs) and a quaternion-based dynamic temporal pooling Transformer (QDTPformer) selected task-specific dynamic movement primitive (DMP) references for powered knee-exoskeleton assistance. Six participants took part across the offline recognition and human-assistance evaluations. For level walking (Flat), ramp ascent (Ramp), and stair ascent (Stairs), QDTPformer achieved 95.74% offline test accuracy and 89.54%±1.07% mean window-level accuracy in leave-one-subject-out evaluation. Online recognition selected the corresponding DMP reference and assistance parameters. Phase-aligned DMP-knee correlations were 0.967, 0.944, and 0.777 for Flat, Ramp, and Stairs, respectively. The equally weighted mean surface electromyography (sEMG) root mean square (RMS) reduction across two muscles and three tasks was 8.42%, with task- and wearer-dependent responses. The main contribution is an end-to-end recognition-to-assistance pipeline evaluated across three terrains using both kinematic and muscle-activity outcomes.