Related Experiment Video
Updated: Oct 27, 2026
A Real-Time Interactive System for Studying Confrontational Pursuit Behavior in Rodents
Published on: May 16, 2025
A Bio-Inspired Pursuit-Evasion Game and Fixed-Time Safety Control Method for USV Swarm Encirclement
Fengxiang Mao1, Liang Xu1, Jingjing Guo1
1School of Computer Science and Artificial Intelligence, Xinyang University, Xinyang 464000, China.

Abstract:
Unmanned Surface Vehicle (USV) swarms face significant challenges during dynamic target encirclement in complex marine environments, particularly regarding strong target maneuverability and strict safety constraints. To address these issues, this paper proposes a novel encirclement and capture method. The proposed approach integrates a bio-inspired pursuit-evasion dynamic game with fixed-time safety control. Drawing on the behavioral mechanism of dynamic cooperative blocking and escape space compression in group predation in nature, a multi-pursuer single-evader dynamic game model is established. The payoff functions of pursuers and the evader are constructed to characterize the strategic interaction between both sides, and adaptive cooperative encirclement strategies for the USV swarm are generated based on dynamic game equilibrium. To address environmental disturbances and the requirement of rapid response in complex marine environments, a fixed-time safety controller is designed. Taking the desired encirclement positions generated by the dynamic game as control objectives, a safety constraint mechanism is constructed by introducing control barrier functions, which achieves rapid convergence and cooperative collision avoidance of the USV swarm. Furthermore, the fixed-time convergence of position errors and the satisfaction of safety constraints for the control system are proven via Lyapunov stability theory. Finally, dynamic target encirclement numerical simulations under ocean current disturbances verify the effectiveness of the proposed method. The results demonstrate that the USV swarm can adapt to continuous target maneuvering, realize stable encirclement and capture, and satisfy safety constraints.
Related Concept Videos
 01:26
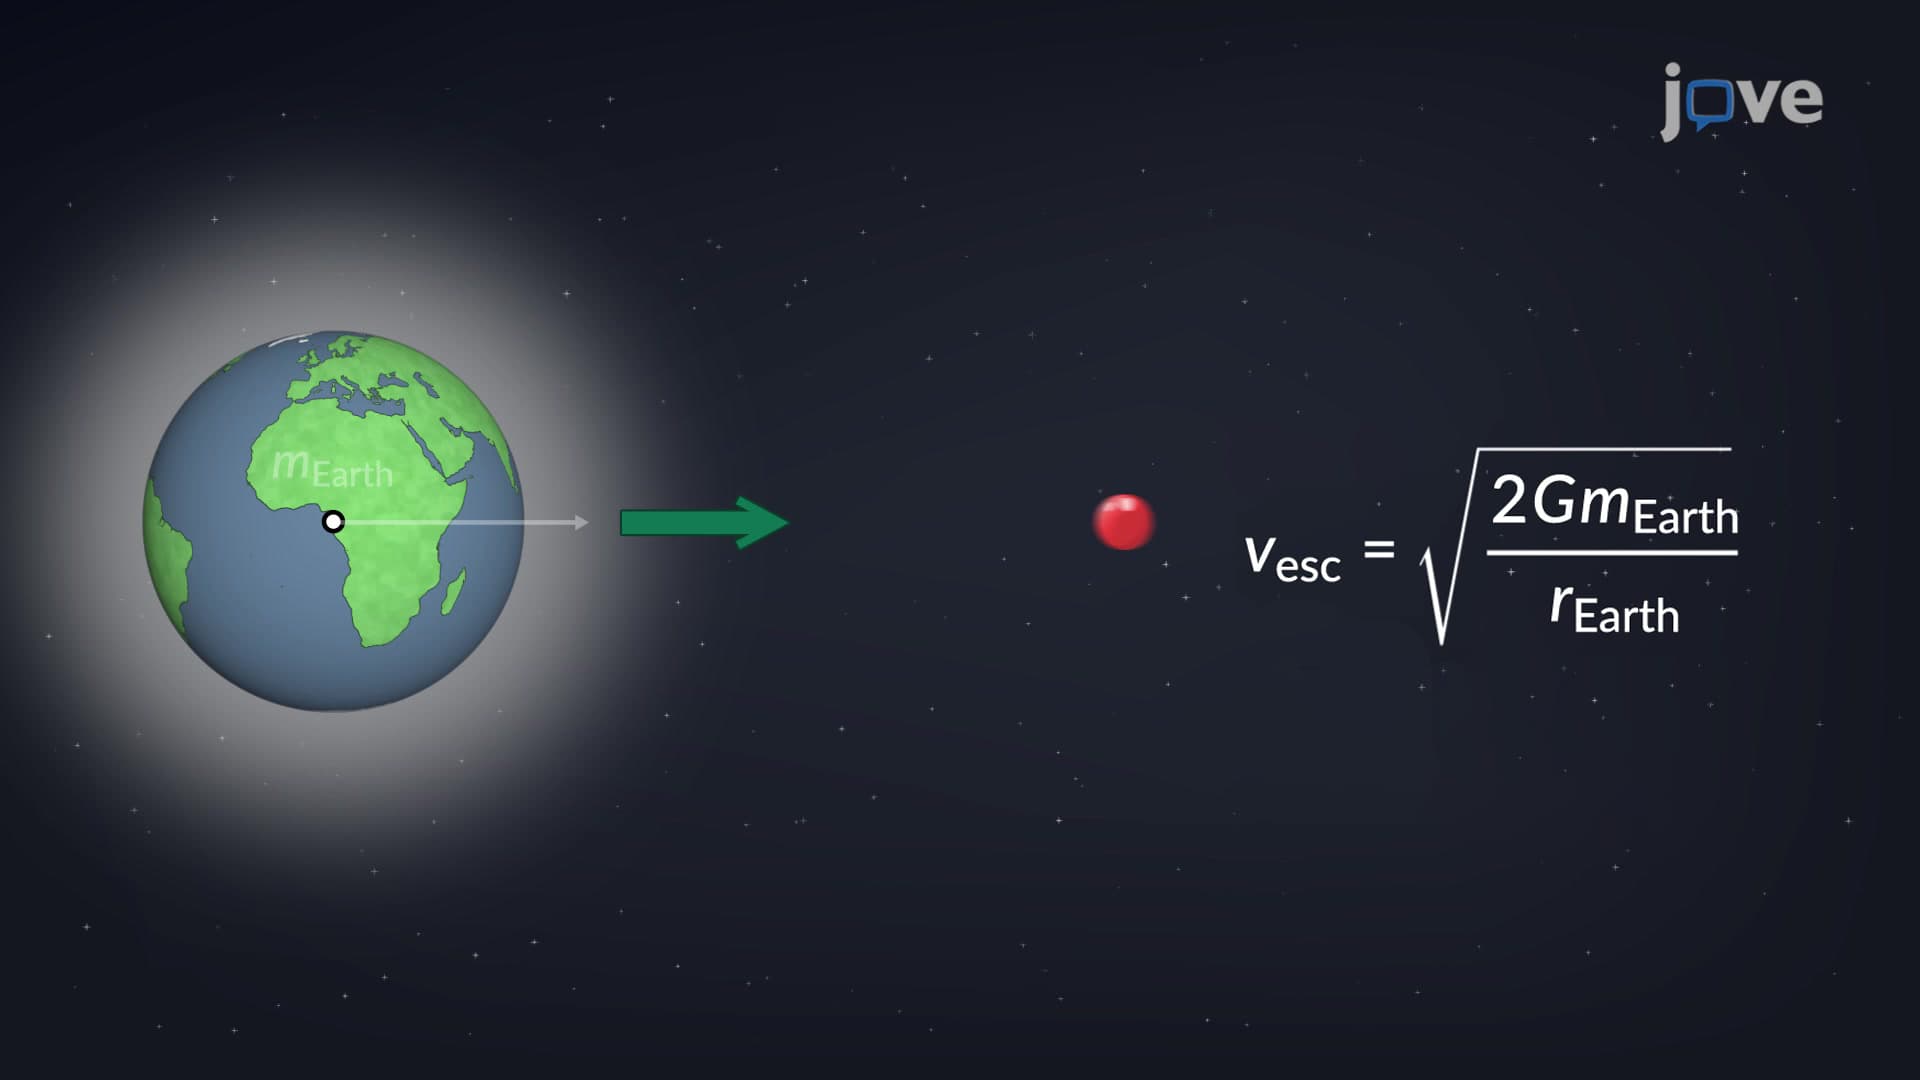
Escape Velocity
To calculate the escape velocity, it is assumed that no energy is lost to any frictional forces. In practice, a satellite launched from...
 01:16
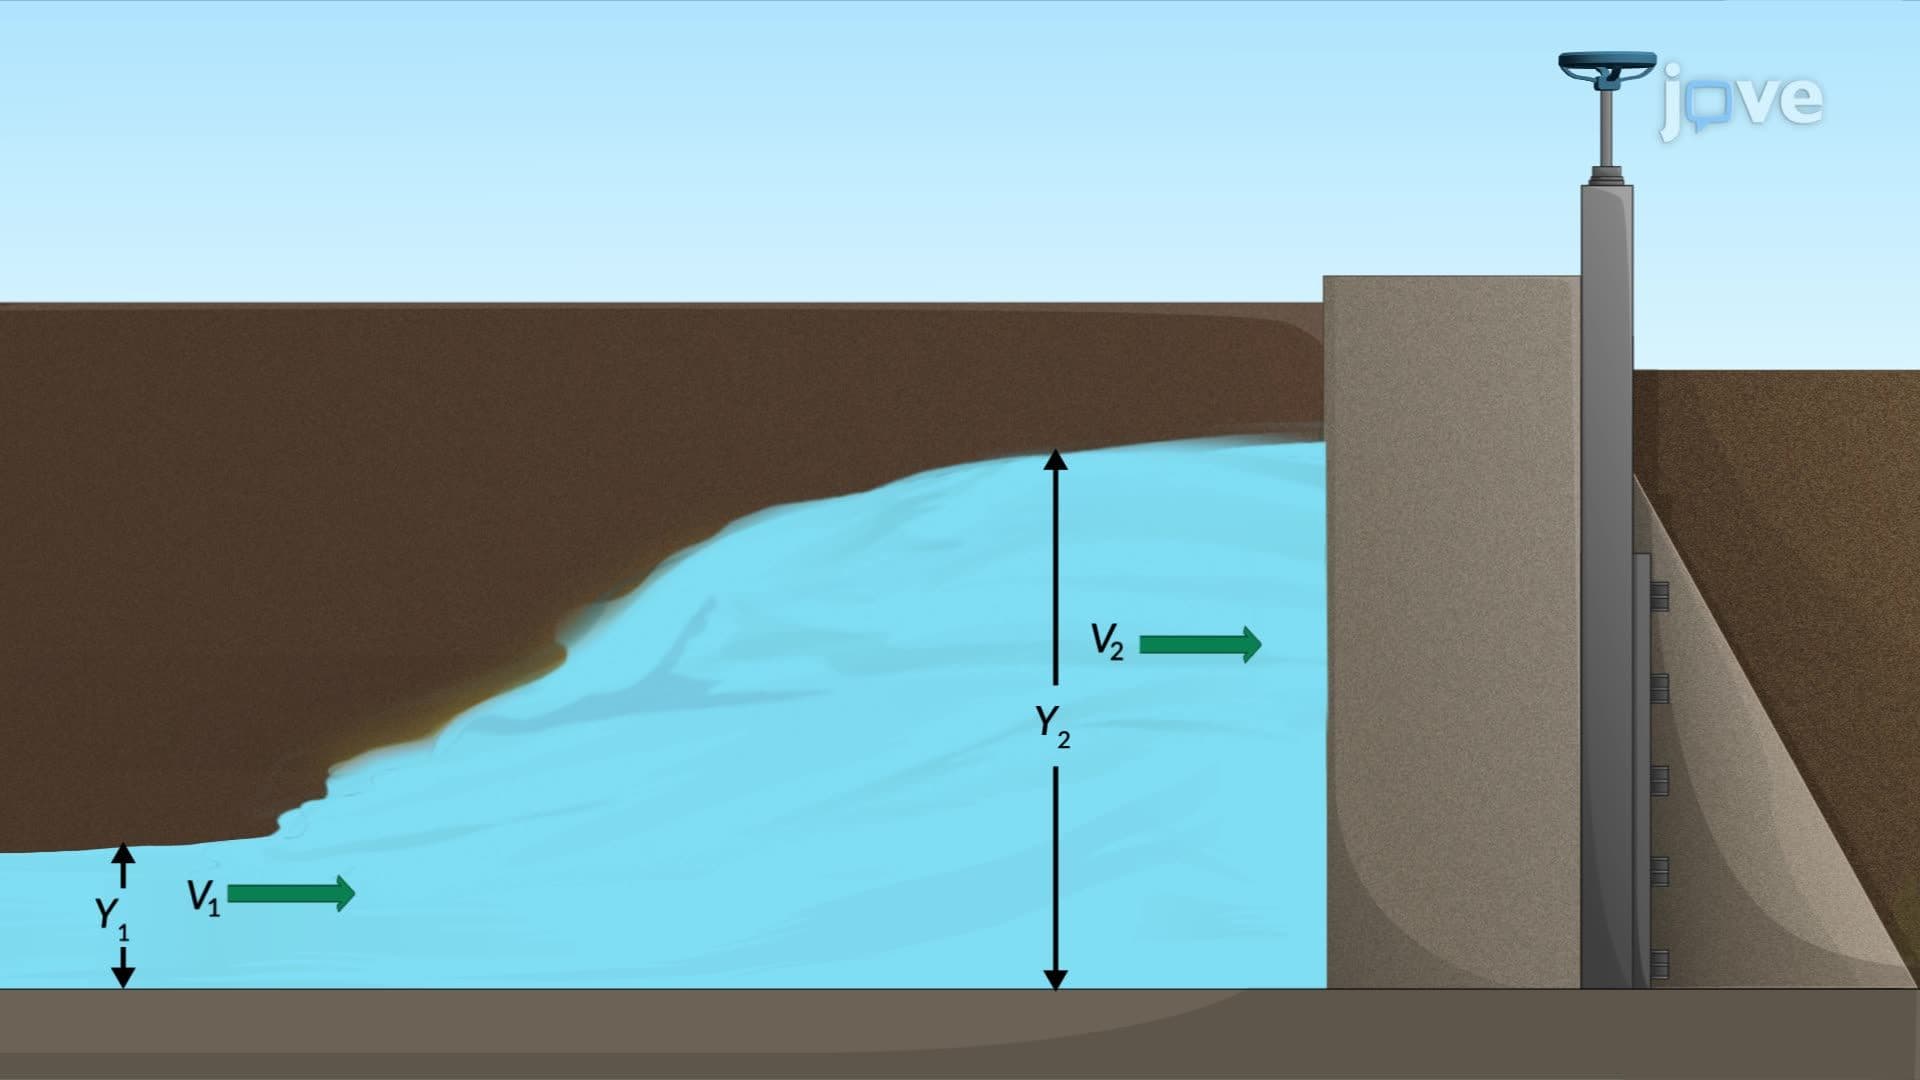
Hydraulic Jump: Problem Solving
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:14
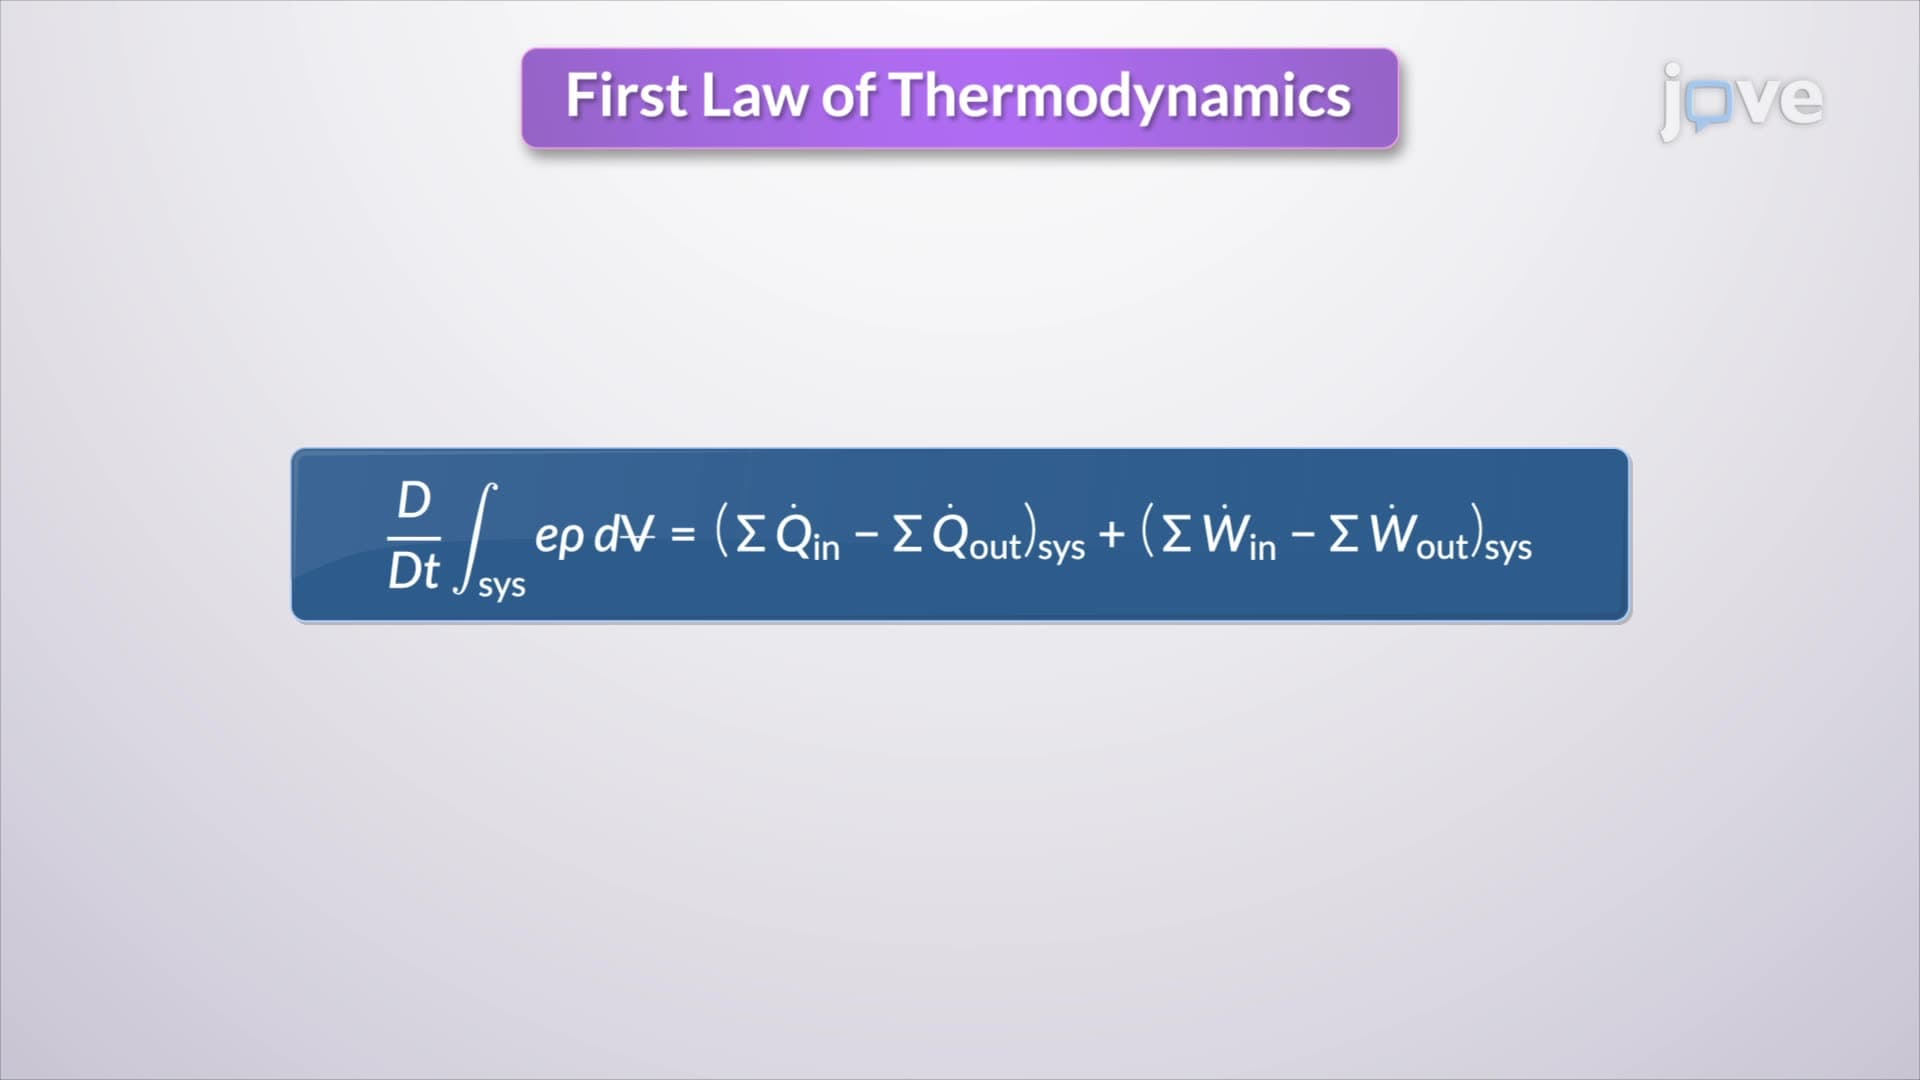
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...