Variable kinetic constraints in robotic assistance enhance learning of a complex motor skill
Related Experiment Video
Updated: Nov 6, 2026
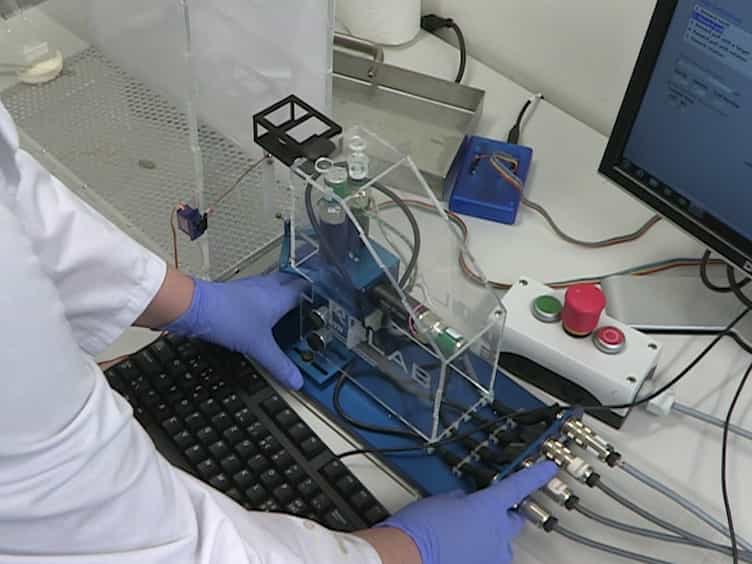
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
L Charbonnier1,2, Y Blandin1, A Decatoire2
1Centre de Recherches sur la Cognition et l'Apprentissage (UMR 7295), Centre National de la Recherche Scientifique, Université de Poitiers; Université de Tours, Poitiers, France.

Abstract:
Robotic assistance can improve the learning of complex motor skills and support rehabilitation. However, most active robotic devices developed to date provide assistance based on movement trajectories (kinematics) rather than the underlying limb dynamics (kinetics) that generate movement. To our knowledge, no study has directly compared, within a single task, how kinematics and kinetics should be integrated to enhance motor learning. The present study investigated how a complex torque-motion profile involving the right arm can be learned by manipulating torque error margins within an admittance-controlled robotic device. The participants practiced under four acquisition conditions-Constant 2 N·m, Constant 12 N·m, increasing margin (Margin+), and decreasing margin (Margin-)-in which the width of the error margin on the required torque was manipulated to induce different levels of kinetic constraints on practice. On Day 1, all the participants first completed a pretest without visual feedback, followed by 6 blocks of practice. During this acquisition phase, group-specific error margins were applied, and participants received both concurrent and terminal visual feedback of their produced torque. On Day 2, a posttest without visual feedback was performed to assess retention (identical as pretest). The results revealed that the variable-margin groups (Margin + and Margin-) led to greater improvements in kinetic and kinematic profile tracking and more stable retention than the constant-margin groups (Constant 2 N·m and Constant 12 N·m). These findings suggest that variable-margin practice enhances learning by fostering increased exploration of the task space while emphasizing both kinetic and kinematic aspects of task performance. Whereas constant margins appear to stabilize a single movement solution, variable constraints may promote a more generalizable motor control strategy, possibly by refining the predictive mapping between motor commands and their sensory consequences that contribute to updating internal models. Such insights could optimize the design of robotic rehabilitation protocols aimed at fostering durable motor recovery and relearning.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:30
Motor Skills Development During Early Childhood
 01:18
Hierarchy of Motor Control
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
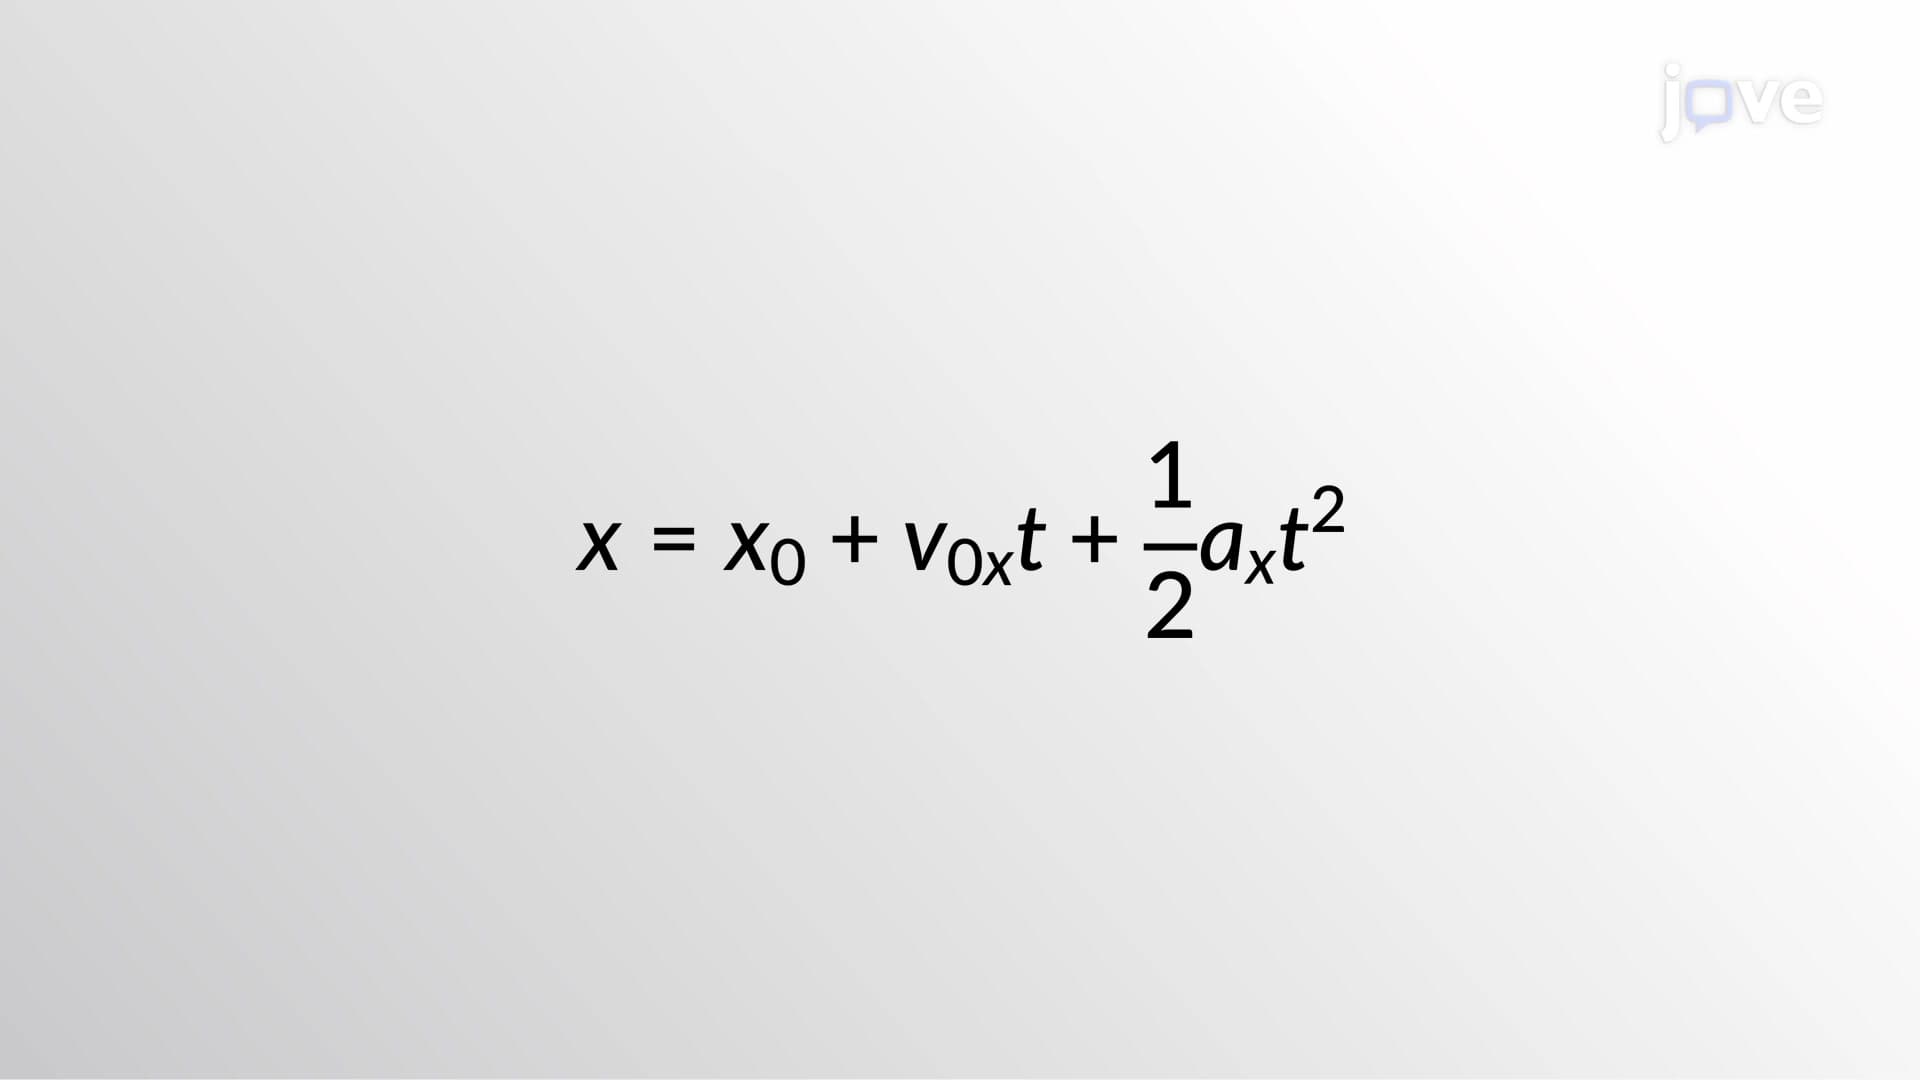 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
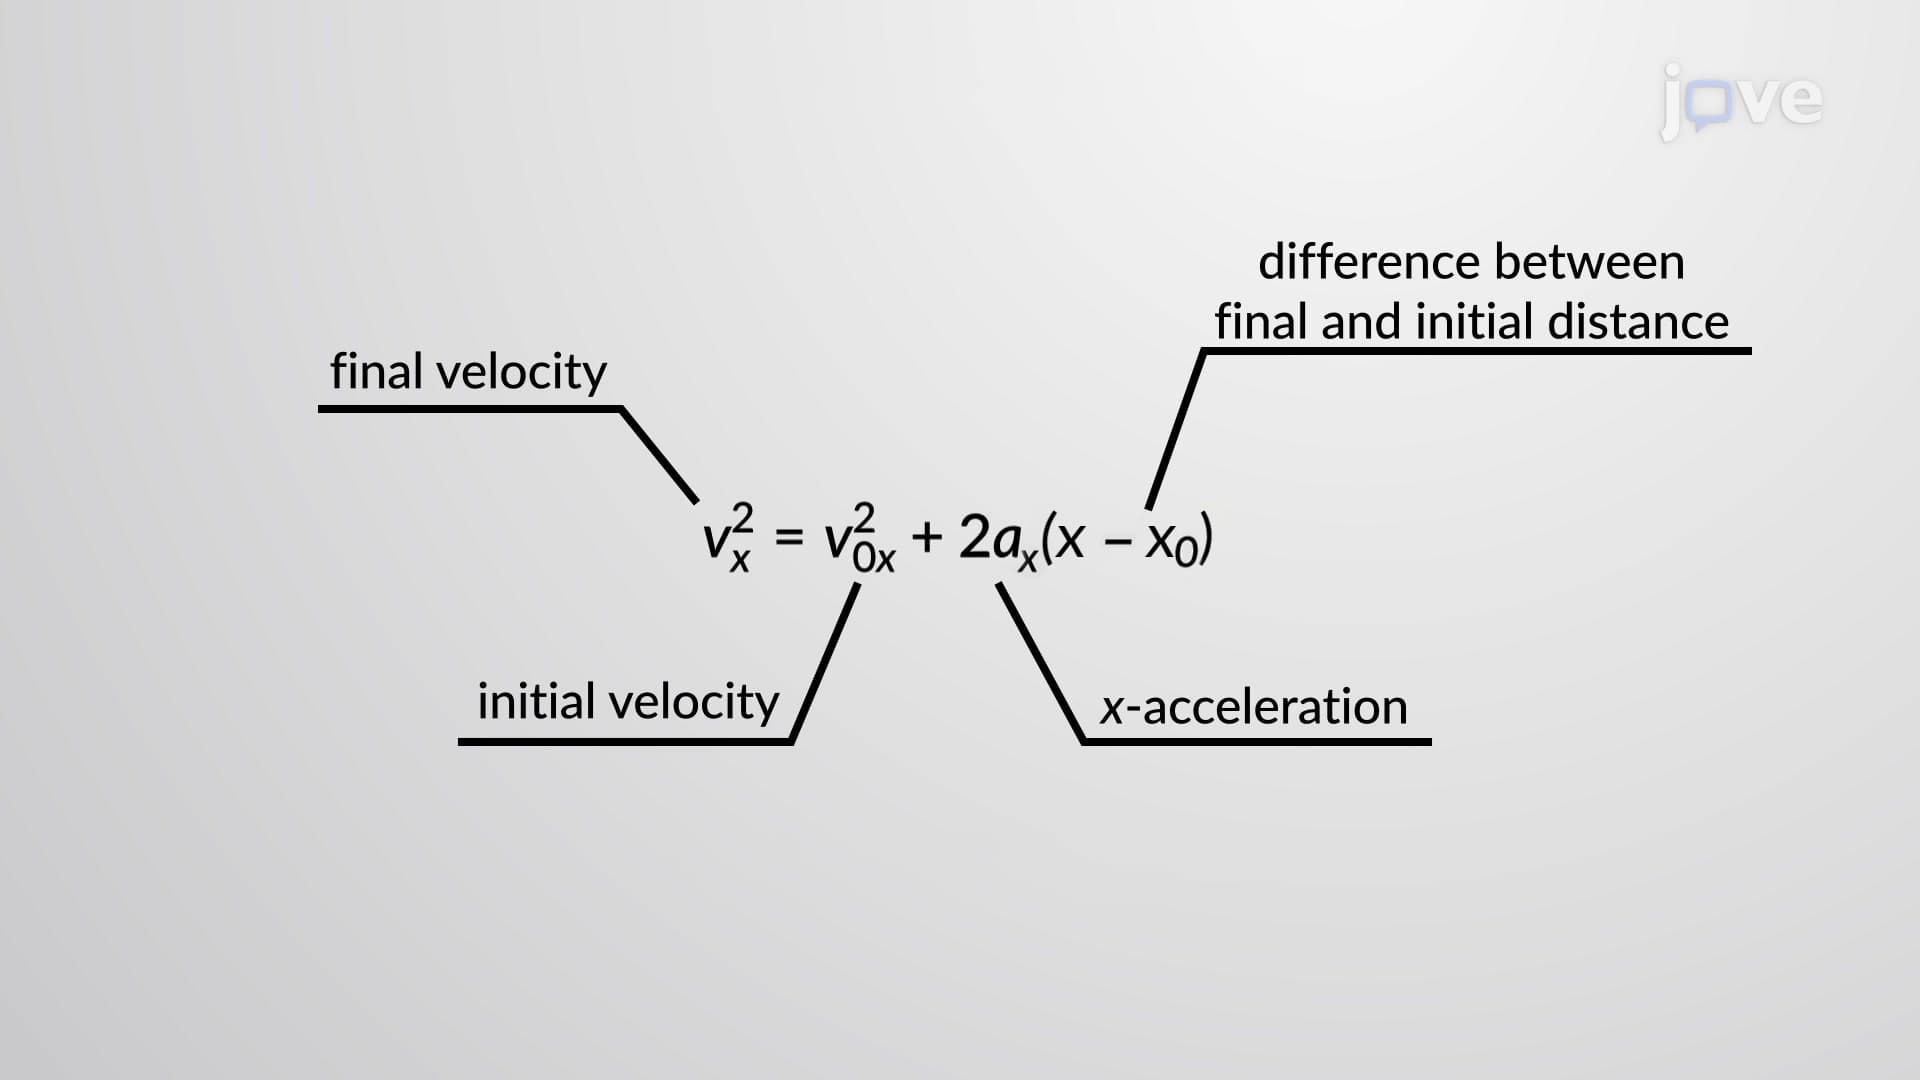 01:18
Kinematic Equations - III
Using the kinematic equations,...