Development of a 7-DOF robotic arm control system for autonomous grasping of user-specified general objects
Related Experiment Video
Updated: Nov 6, 2026
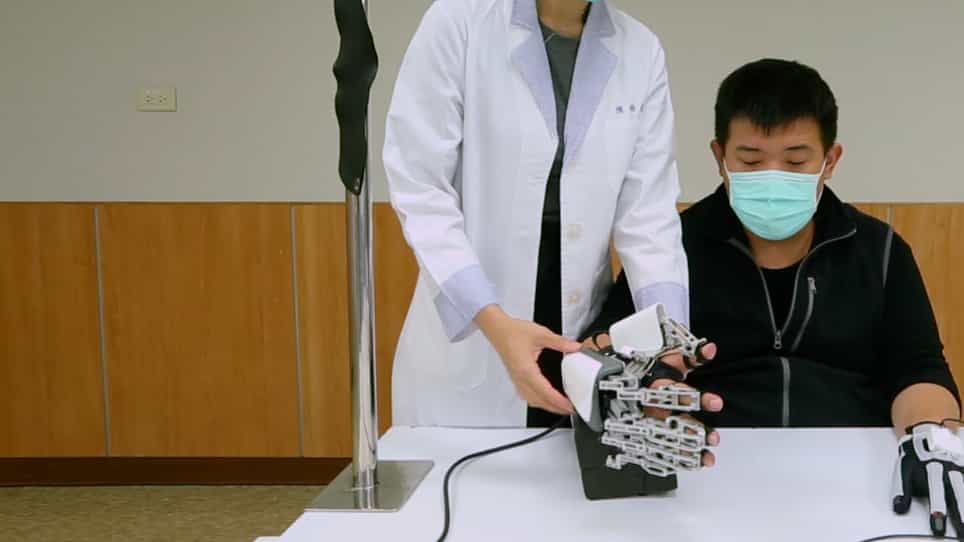
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Shuting Bai1, Yinlai Jiang2, Hiroshi Yokoi1
1Department of Mechanical and Intelligent Systems Engineering, The University of Electro-Communications, Tokyo, Japan.

Abstract:
Robotic manipulators used in assistive robots need the ability to autonomously grasp various objects in unstructured environments and allow users to specify target objects in cluttered environments. This study developed a control system for autonomous grasping of user-specified general objects on a coupled tendon-driven 7-DOF robotic arm. A geometry-based inverse kinematics method was introduced to generate grasping motions for the 7-DOF robotic arm, and an end-to-end multi-task model based on the proposed 3D Mixture-of-Experts (MoE) UNet was developed to simultaneously perform 6-DOF grasp pose estimation and semantic segmentation using point cloud data as input. Evaluation on the GraspNet-1Billion dataset showed that the proposed 3D MoE UNet backbone generally improved both tasks over the 3D UNet baseline, achieving gains of up to 5.24 AP points for grasp pose estimation and up to 3.42 mIoU points for semantic segmentation, while requiring only a limited number of additional active parameters during inference. In real-world grasping experiments involving 10 objects in cluttered scenes, the system achieved a 100% pick-and-place success rate for each of the three seen objects and an average success rate of 52.9% for the 7 unseen objects. During these experiments, the proposed model operated in real time at an average of 20 FPS with limited memory usage. These results demonstrate the effectiveness of the proposed system for autonomous grasping in cluttered real-world environments and its potential for application to standalone assistive robots.

Related Concept Videos
 01:31
Hand Control During Infancy and Toddlerhood
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...