Velocity and acceleration of height growth using kernel estimation

Annals of Human Biology
|September 1, 1984
PubMed

Related Concept Videos

Velocity and Position by Graphical Method01:34

Velocity and Position by Graphical Method
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to calculate...
Acceleration Vectors01:30

Acceleration Vectors

In everyday conversation, accelerating means speeding up. Acceleration is a vector in the same direction as the change in velocity, Δv, therefore the greater the acceleration, the greater the change in velocity over a given time. Since velocity is a vector, it can change in magnitude, direction, or both. Thus acceleration is a change in speed or direction, or both. For example, if a runner traveling at 10 km/h due east slows to a stop, reverses direction, and continues their run at 10 km/h due...
Measuring Acceleration Due to Gravity01:12

Measuring Acceleration Due to Gravity

Consider a coffee mug hanging on a hook in a pantry. If the mug gets knocked, it oscillates back and forth like a pendulum until the oscillations die out.
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
Relative Motion Analysis - Acceleration01:10

Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
Application of Nonlinear Inequalities01:29

Application of Nonlinear Inequalities

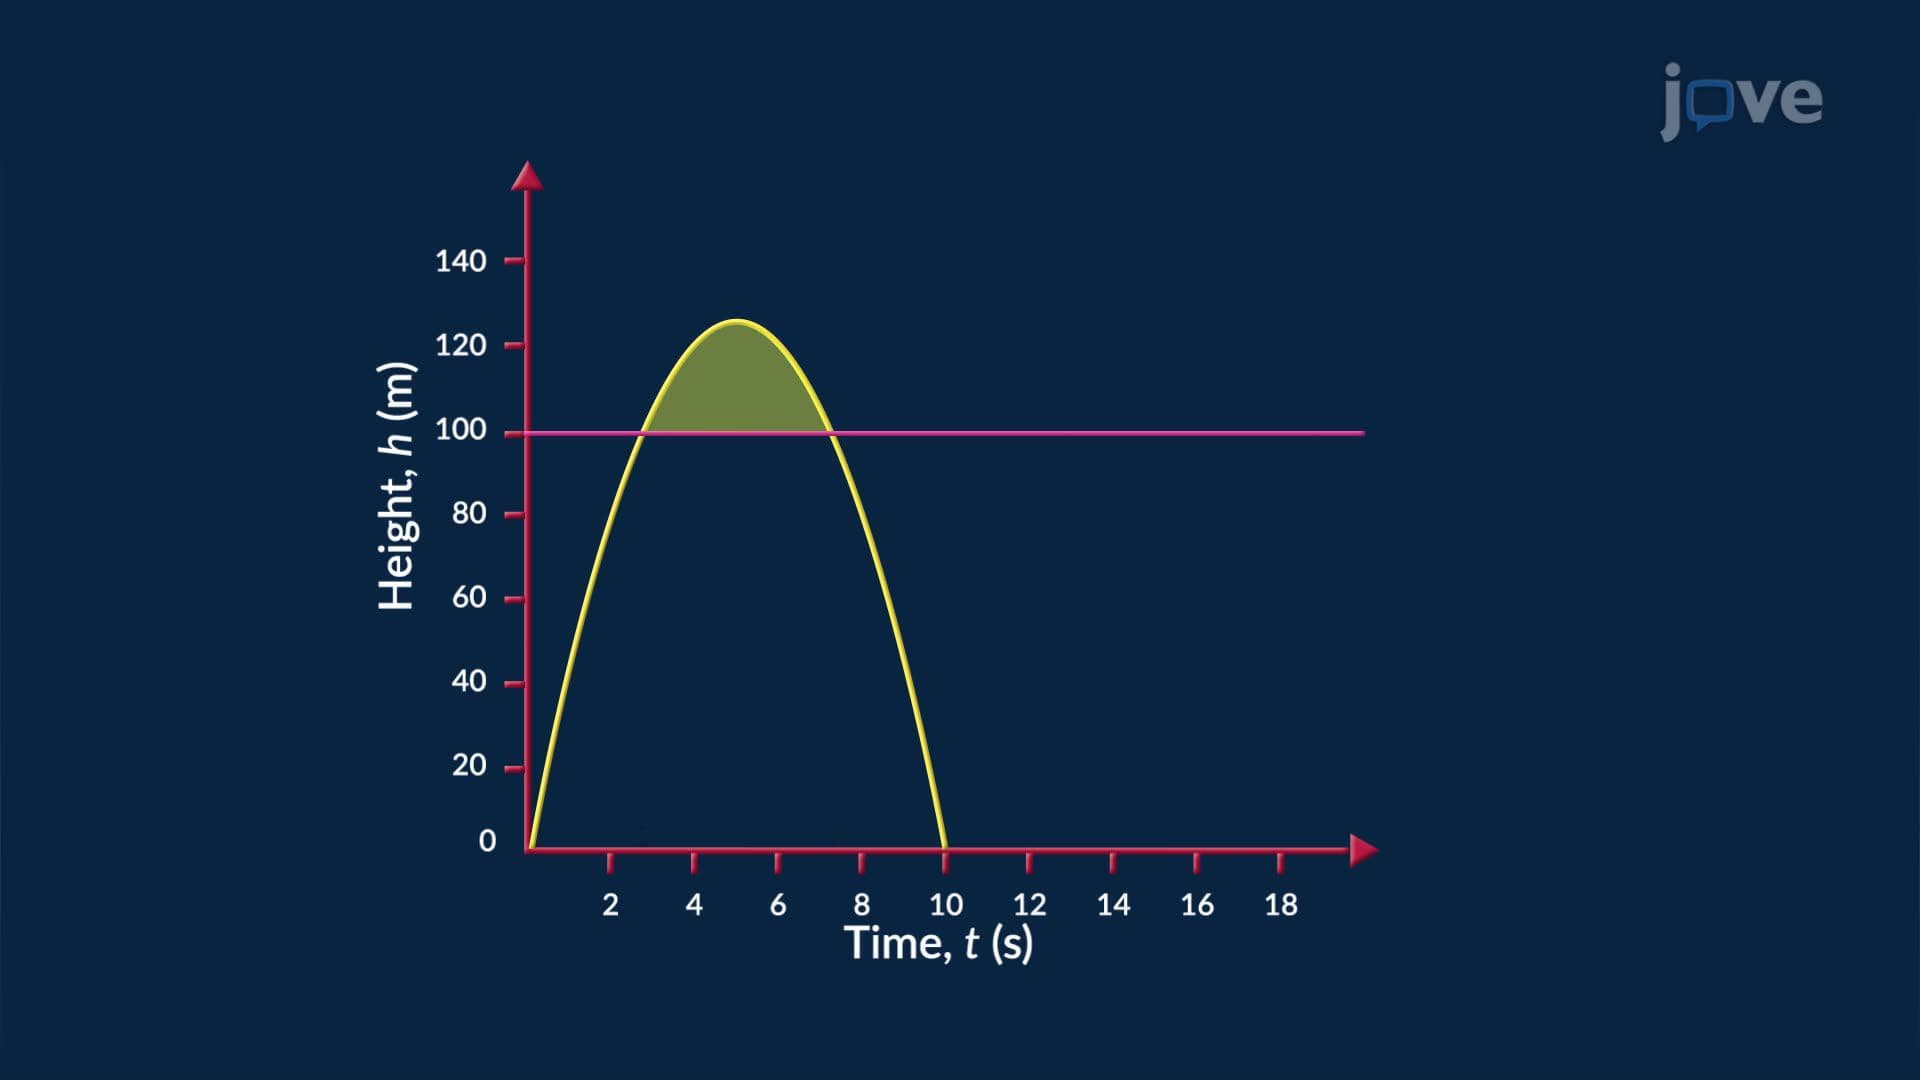
A nonlinear inequality describes a comparison involving an expression that curves or behaves more complexly than a straight line. These inequalities often appear in forms that include squares, products, or variables in the denominator.To solve such an inequality, one starts by rewriting it so that zero appears on one side. For example, the inequality:  can be factored as: This form makes it easier to identify the values that cause the expression to equal zero. In this case, the key values are 3...
Vector Functions and Motion: Problem Solving01:30

Vector Functions and Motion: Problem Solving

Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...