Spatiotemporal integration in the detection of coherent motion
Related Experiment Video
Updated: Oct 30, 2026
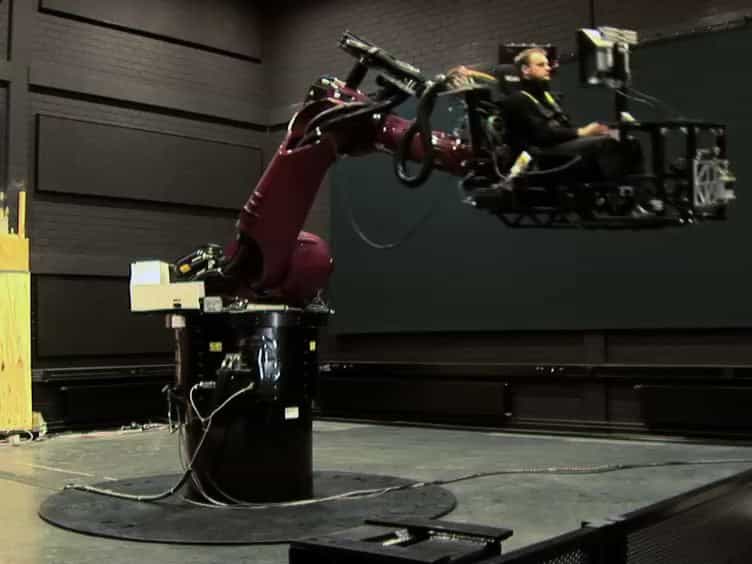
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012

Abstract:
We present data on the signal to noise threshold (SNR) for the impression of coherent, smooth motion in stroboscopically moving dot patterns (frame repetitionrate 100 Hz) degraded with additive noise (uncorrelated pattern each new frame). (Both patterns were 250 X 255 square arrays in which a pixel was randomly assigned a light or dark value with probability 50%.) It is found that the threshold varies roughly as the inverse square root of the number of available basic dot correlation pairs, subject to certain constraints that can be interpreted as due to the geometry of basic correlator units subserving the detection of motion. This geometry is estimated from the data and compared with values that have been obtained with independent methods. Phenomenologically the results are simple: when the target field is enlarged in the direction perpendicular to the motion the SNR threshold follows the theoretical expectations. Otherwise the variation is stronger, which points to a recruitment of new units. For an impression of movement to occur the smallest targets are short thin strips elongated in the direction of motion (e.g. 2.5' X 12' for 2.08 deg sec-1), but the threshold continues to fall at least to 5 degrees X 5 degrees. There is a trade-off between target area and presentation time. For a 5 degrees X 5 degrees target coherent motion can be seen in 3 successive frames, but for a 10' X 10' target ten times as many frames have to be presented, whereas an impression of movement is not obtained for still smaller targets.
More Related Videos
 11:28
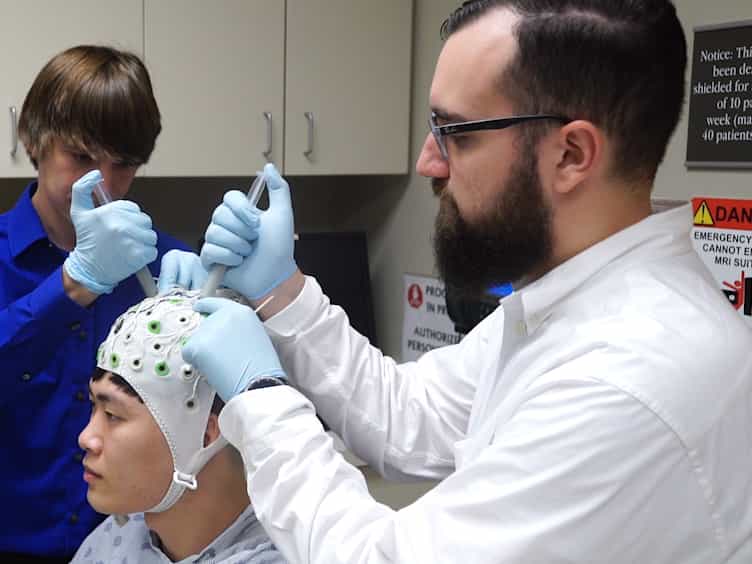
Concurrent EEG and Functional MRI Recording and Integration Analysis for Dynamic Cortical Activity Imaging
Published on: June 30, 2018
 07:24
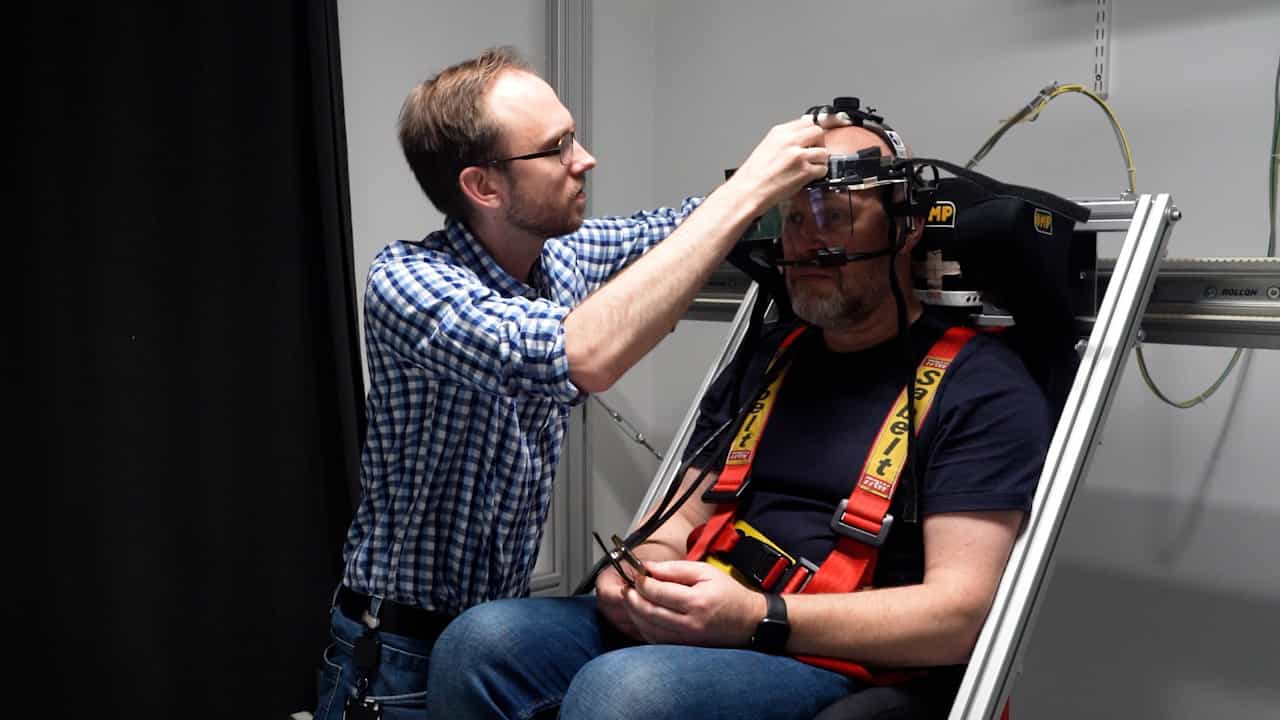
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...