Related Experiment Video
Updated: Oct 13, 2026
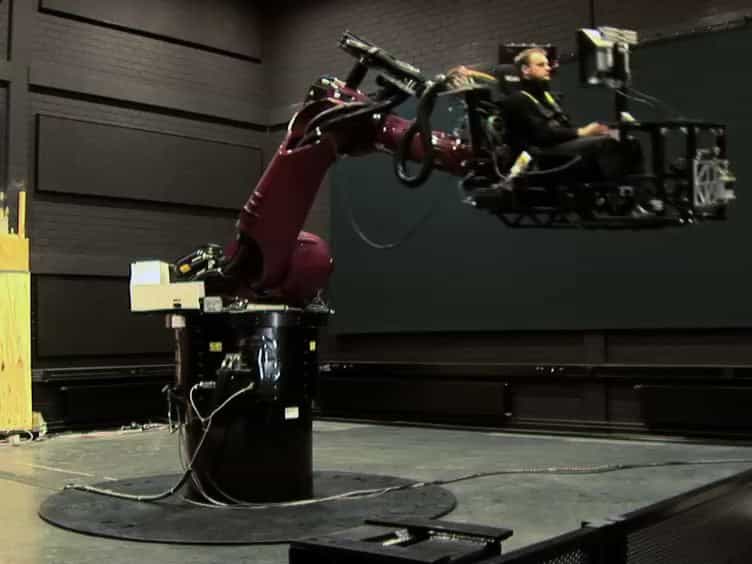
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Apparent movement of successively generated subjective figures

Abstract:
In the present studies a pair of random-dot frames was constructed so that two areas in the first frame (f1) were correlated with two areas in the second frame (f2). The alternation of the pair of frames (an f1--f2 sequence) gave rise to two subjective figures. When two pairs of randomdot frames (an f1--f2 sequence and an f3--f4 sequence), each of which produced two subjective figures in different locations, were thmeselves alternated, the subjective figures from the f1--f2 sequence interacted with the subjective figures from the f3--f4 sequence to produce apparent movement. With any one of the four general kinds of displays which we constructed, subjects usually perceived only one of two types of subjective-figure movement. The type of movement that was perceived with a given display depended primarily upon the degree of change (across the interval between an f1--f2 and an f3--f4 sequence) of the internal structure of the successively generated subjective figures. Relative intensity differences between the subjective figures and their backgrounds influenced the type of apparent movement seen, whereas variations in the density of elements in a display did not. We tentatively propose a two-stage model to explain the apparent movement of the subjective figures: the first stage is assumed to generate the subjective figures by means of a cross-correlation of the intensity distributions of the two frames within an f1--f2 sequence and within an f3--f4 sequence; on the basis of inputs from the first stage, the second stage generates apparent movement signals for the subjective figures.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...