Related Experiment Video
Updated: Aug 14, 2026
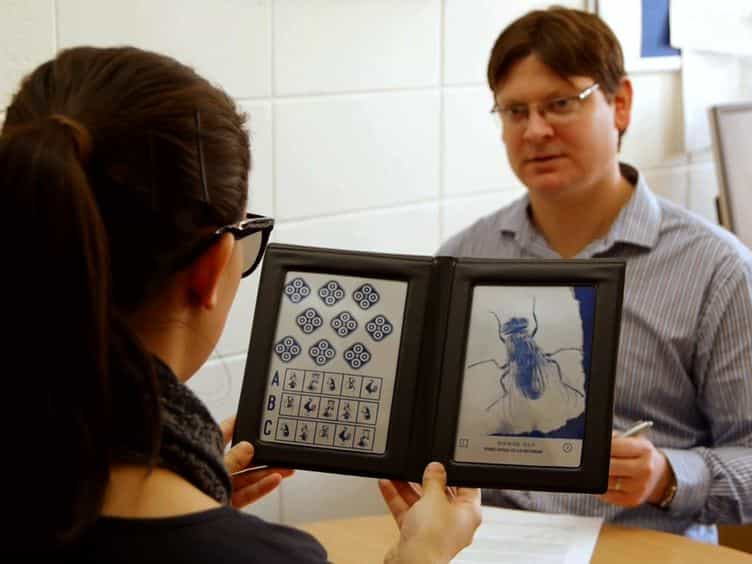

Measuring Sensitivity to Viewpoint Change with and without Stereoscopic Cues
Published on: December 5, 2013
Binocular perception of slant about oblique axes relative to a visual frame of reference
1Faculty of Physics and Astronomy, Department of Human Physics, Utrecht University, The Netherlands.

Abstract:
From the literature it is known that the processing of disparity for slant is different in the presence and in the absence of a visual frame of reference. The experimental finding that vertical disparity is not processed for slant perception in the presence of a visual reference is elaborated. This theoretical analysis results in a reduction of the three basic first-order transformations between the retinal half images (divergence, rotation, and deformation) to only two basic orthogonal transformations. The first of these, horizontal scale, results in slant perception about the vertical axis, whereas the second, horizontal shear, results in slant perception about the horizontal axis. These transformations are based primarily on horizontal disparity. It is shown experimentally that in the presence of a frame of reference the amount of vertical transformation that is added to the two basic transformations (horizontal scale and shear) of a random-dot stimulus is indeed irrelevant for slant perception. It is suggested that, in the presence of a visual reference, slant perception about oblique axes is based solely on linear combinations of the horizontal-scale and horizontal-shear transformations. Subjects are able to reproduce slants about oblique axes experimentally merely by combining horizontal scale and shear.
More Related Videos
 07:45
Assessing Binocular Central Visual Field and Binocular Eye Movements in a Dichoptic Viewing Condition
Published on: July 21, 2020
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:17
Accessory Structures of the Eye
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:15
Depth Perception and Spatial Vision