Transformations between visual and kinesthetic coordinate systems in reaches to remembered object locations and orientations
Related Experiment Video
Updated: Nov 6, 2026

Visualization Method for Proprioceptive Drift on a 2D Plane Using Support Vector Machine
Published on: October 27, 2016
1Department of Exercise Science, University of Iowa, Iowa City 52242.

Abstract:
The abilities of human subjects to perform reach and grasp movements to remembered locations/orientations of a cylindrical object were studied under four conditions: (1) visual presentation of the object-reach with vision allowed; (2) visual presentation-reach while blindfolded; (3) kinesthetic presentation of the object-reach while blindfolded and (4) kinesthetic presentation-reach with vision. The results showed that subjects were very accurate in locating the object in the purely kinesthetic condition and that directional errors were low in all four conditions; but, predictable errors in reach distance occurred in conditions 1,2, and 4. The pattern of these distance errors was similar to that identified in previous research using a pointing task to a small target (i.e., overshoots of close targets, undershoots of far targets). The observation that the pattern of distance errors in condition 4 was similar to that of conditions 1 and 2 suggests that subjects transform kinesthetically defined hand locations into a visual coordinate system when vision is available during upper limb motion to a remembered kinesthetic target. The differences in orientation of the upper limb between target and reach positions in condition 3 were similar in magnitude to the errors associated with kinesthetic perceptions of arm and hand orientations in three-dimensional space reported in previous studies. However, fingertip location was specified with greater accuracy than the orientation of upper limb segments. This was apparently accomplished by compensation of variations in shoulder (arm) angles with oppositely directed variations in elbow joint angles. Subjects were also able to transform visually perceived object orientation into an appropriate hand orientation for grasp, as indicated by the relation between hand roll angle and object orientation (elevation angle). The implications of these results for control of upper limb motion to external targets are discussed.

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:16
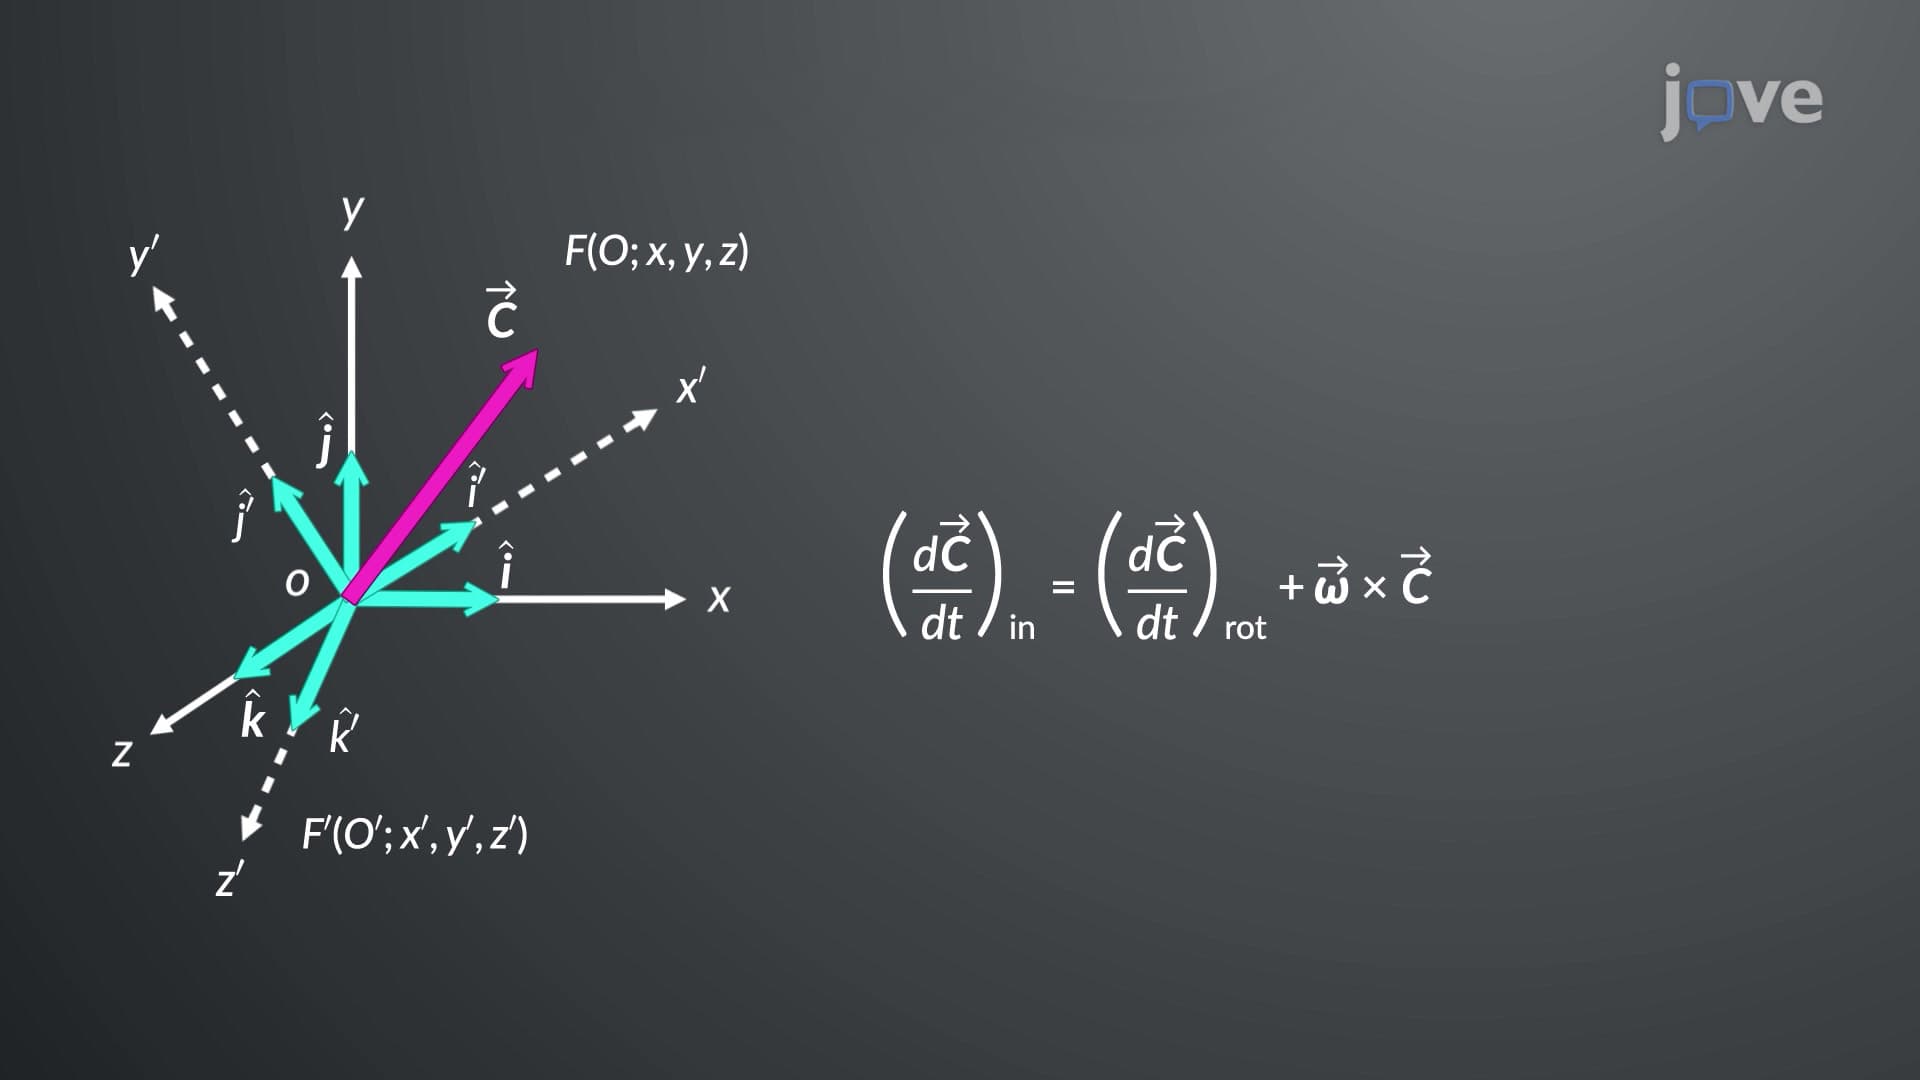
Vector Transformation in Rotating Coordinate Systems
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:03
Inertial Frames of Reference
 01:33
Somatosensation