A comparison of intersegmental joint dynamics to isokinetic dynamometer measurements
Related Experiment Video
Updated: Nov 6, 2026
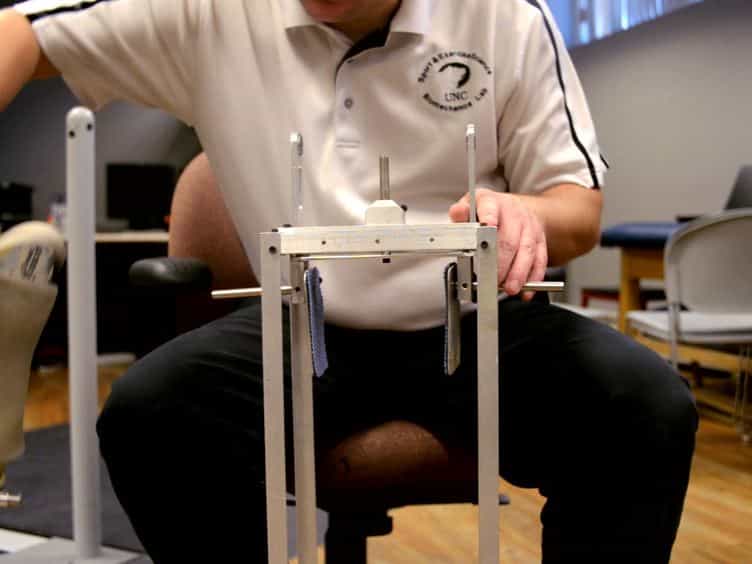
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
K R Kaufman1, K N An, E Y Chao
1Motion Analysis Laboratory, Children's Hospital, San Diego, CA 92123, USA.

Abstract:
This study quantified the errors associated with measurements obtained using an isokinetic dynamometer for knee evaluation at 60 degrees and 180 degrees s-1. Five normal subjects were tested. A triaxial electrogoniometer was used to measure the kinematics. A custom-designed load cell was used to measure the three orthogonal components of the reaction force applied by the isokinetic dynamometer to the leg. The inverse dynamics problem was solved to obtain the intersegmental dynamics at the knee joint. These data were compared to those obtained from the isokinetic dynamometer. The results indicate that the knee motion recorded by the isokinetic dynamometer was in error by 7-9 degrees during flexion and 10-13 degrees during extension. The isokinetic dynamometer recorded knee flexions which were less than actual during the flexion portion of the exercise and greater than actual during extension. The duration of constant velocity was limited based on the speed selected. The knee moment was in error by 5 Nm during flexion and 25-29 Nm during extension. The use of a gravity correction factor reduced the knee moment error during extension, but increased it during flexion.

Related Concept Videos
 01:22
Isotonic and Isometric Muscle Contractions
Isotonic contractions
Isotonic contractions occur when a muscle changes length while the...
 01:17
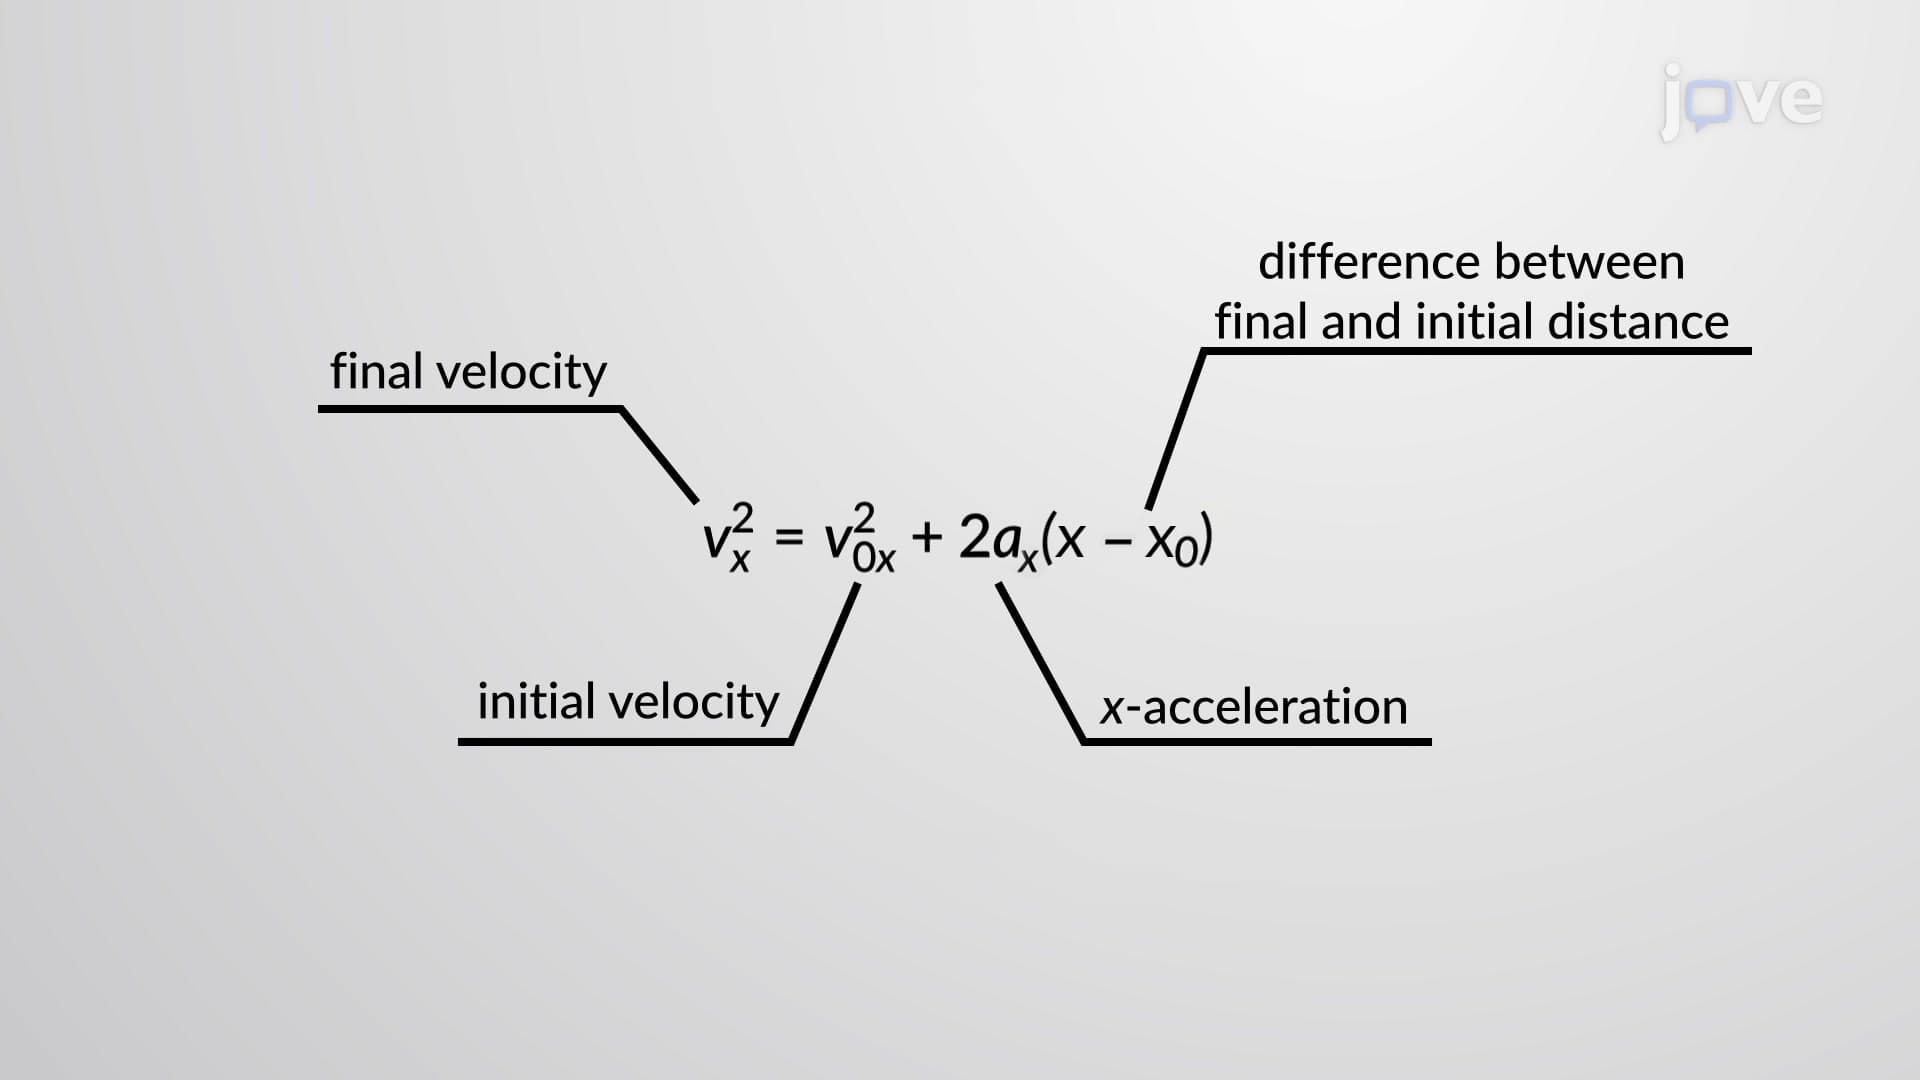
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:18
Kinematic Equations - III
Using the kinematic equations,...