A new system for three-dimensional kinematic trajectory acquisition and analysis--II. Digital orthogonal integration

Y Zejie1, Y Yanming, L Wenlian

  • 1Department of Modern Physics, University of Science and Technology of China, Hefei, PR China.

Related Concept Videos

Orthogonal Trajectories01:26

Orthogonal Trajectories

Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
Relative Motion Analysis using Rotating Axes01:25

Relative Motion Analysis using Rotating Axes

Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...

Vector Functions and Motion: Problem Solving01:30

Vector Functions and Motion: Problem Solving

Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...
Relative Motion Analysis using Rotating Axes - Acceleration01:22

Relative Motion Analysis using Rotating Axes - Acceleration

Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
One-Degree-of-Freedom System01:24

One-Degree-of-Freedom System

In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
Kinematic Equations - III01:18

Kinematic Equations - III

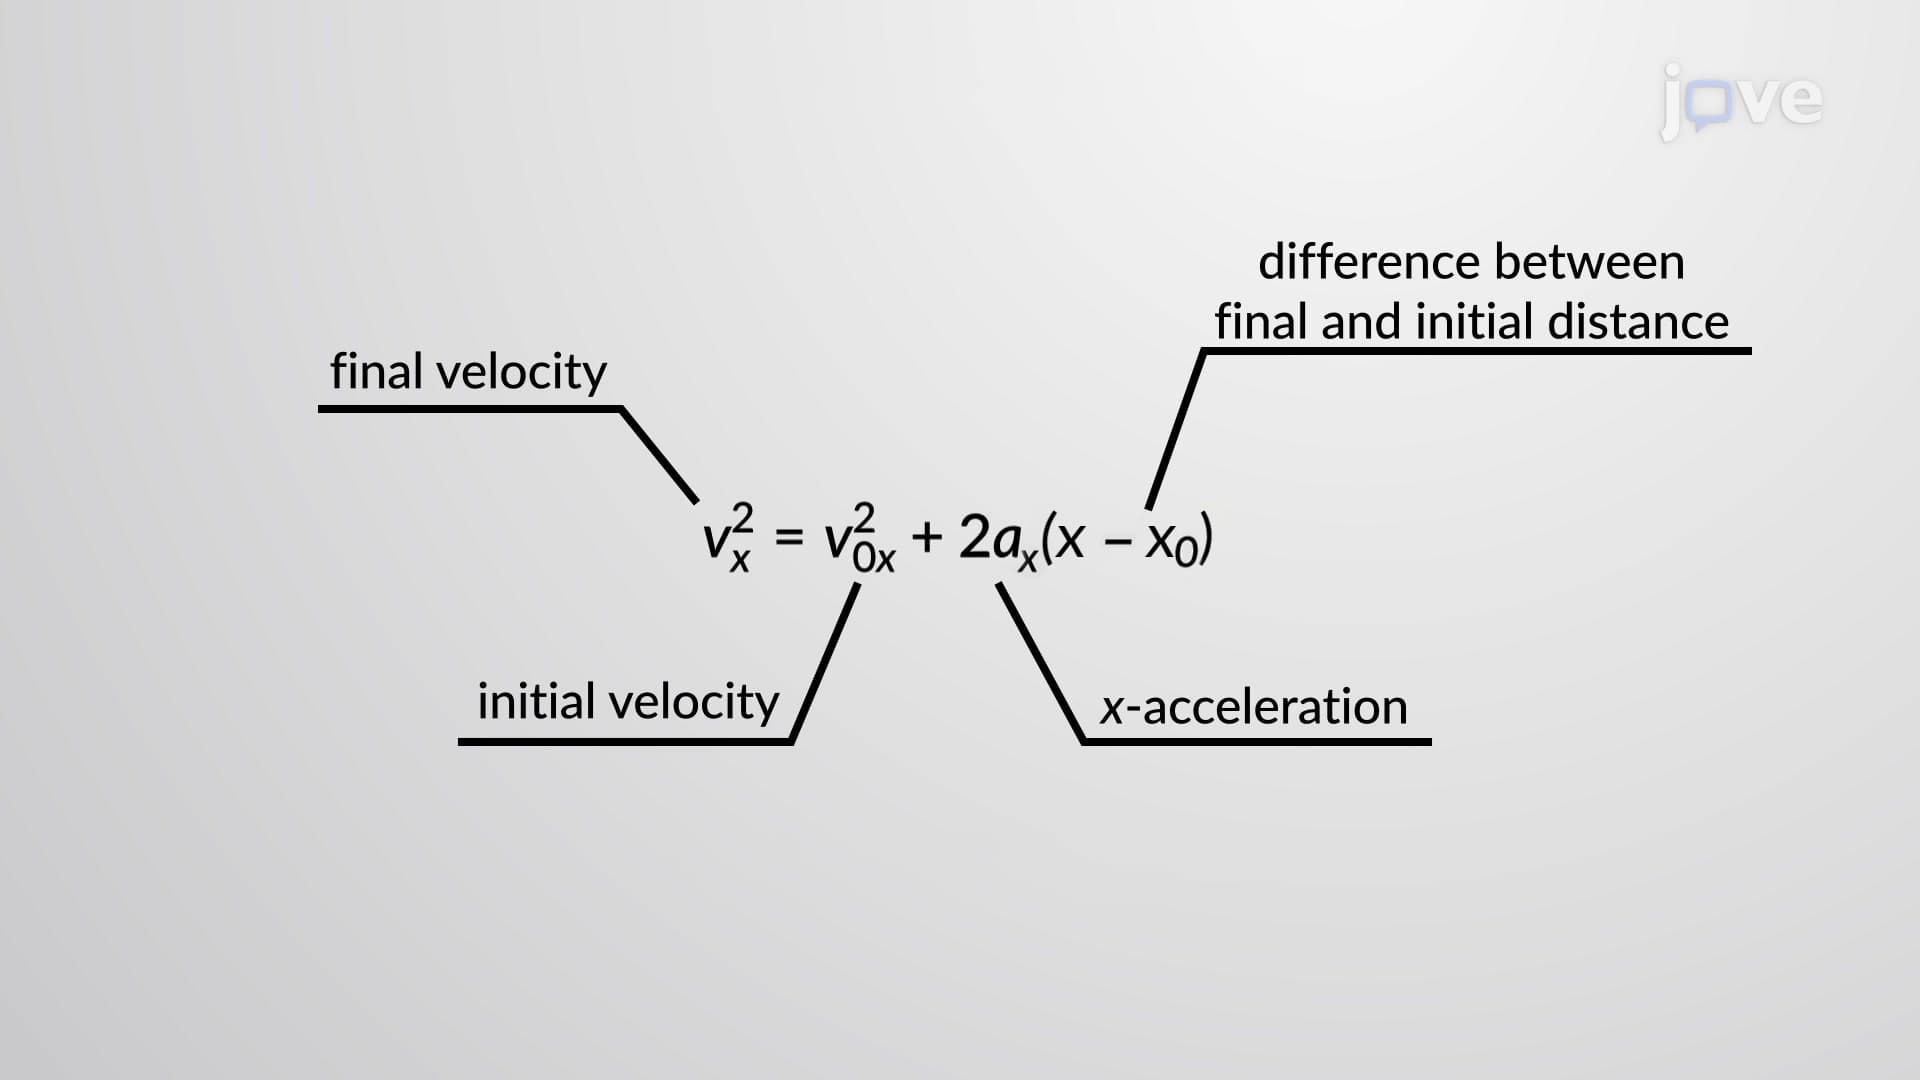
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...