Penalty methods for the inverse problem in EIT

B Hofmann1

  • 1Institut für Numerische und Angewandte Mathematik, Universität Göttingen, Germany.

Physiological Measurement
|November 1, 1996
PubMed

Related Concept Videos

Derivatives of Inverse Trigonometric Functions01:30

Derivatives of Inverse Trigonometric Functions

A ship tracking an approaching aircraft relies on geometric measurements to find out the aircraft’s position relative to the observer. By measuring the slant distance to the aircraft and the angle of elevation, the horizontal and vertical components of the distance can be obtained using trigonometric relationships. This geometric approach provides a basis for analyzing how the observed angle changes as the aircraft moves closer to the ship.To examine the mathematical behavior of the angle of...
Deconvolution01:20

Deconvolution

Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving01:29

Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving

Mechanistic models play a crucial role in algorithms for numerical problem-solving, particularly in nonlinear mixed effects modeling (NMEM). These models aim to minimize specific objective functions by evaluating various parameter estimates, leading to the development of systematic algorithms. In some cases, linearization techniques approximate the model using linear equations.
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
Inverse z-Transform by Partial Fraction Expansion01:20

Inverse z-Transform by Partial Fraction Expansion

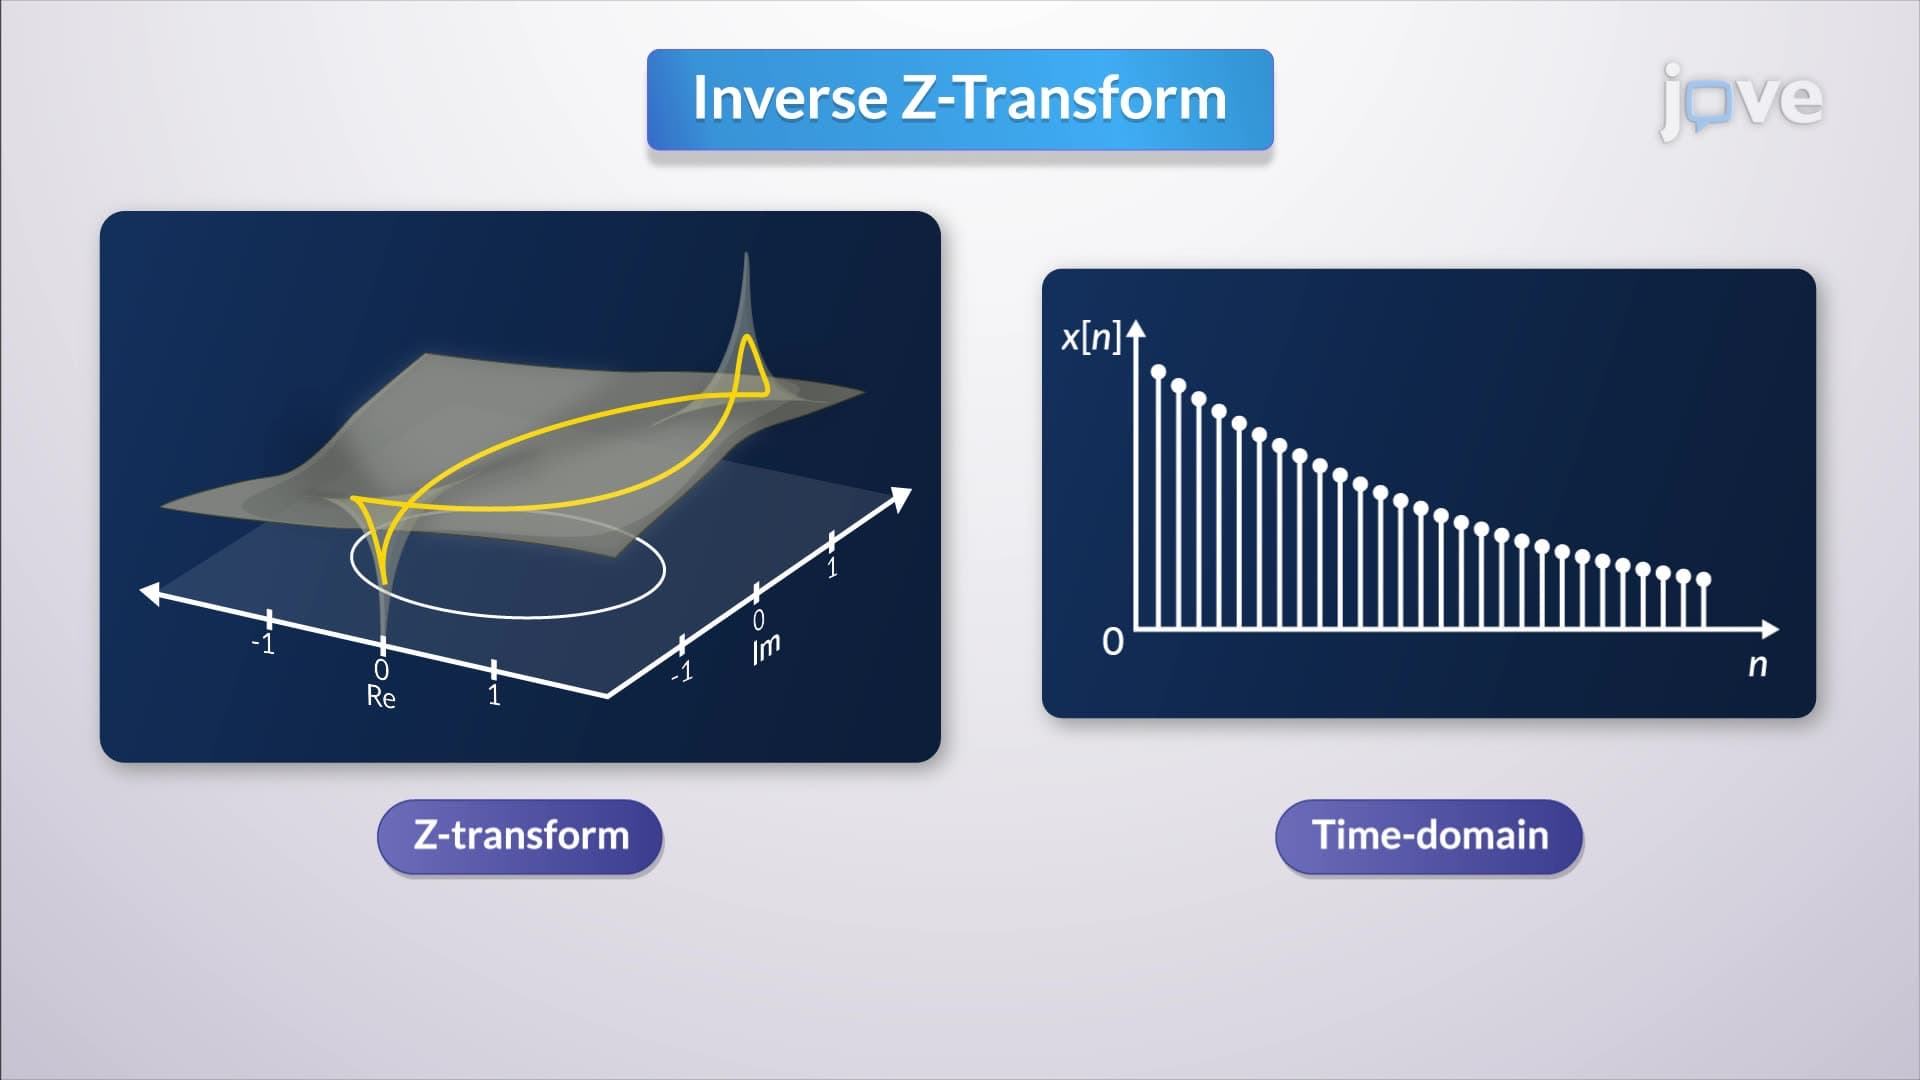
The inverse z-transform is a crucial technique for converting a function from its z-domain representation back to the time domain. One effective method for finding the inverse z-transform is the Partial Fraction Method, which involves decomposing a function into simpler fractions with distinct coefficients. These fractions correspond to known z-transform pairs, facilitating the inverse transformation process.
To begin the process, the poles of the function are identified and the function is...
Poisson's And Laplace's Equation01:25

Poisson's And Laplace's Equation

The electric potential of the system can be calculated by relating it to the electric charge densities that give rise to the electric potential. The differential form of Gauss's law expresses the electric field's divergence in terms of the electric charge density.
Difference Equation Solution using z-Transform01:24

Difference Equation Solution using z-Transform

The z-transform is a powerful tool for analyzing practical discrete-time systems, often represented by linear difference equations. Solving a higher-order difference equation requires knowledge of the input signal and the initial conditions up to one term less than the order of the equation.
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...