Self-organization of trajectory formation. II. Theoretical model
Related Experiment Video
Updated: Aug 14, 2026
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
G C de Guzman1, J A Kelso, J J Buchanan
1Program in Complex Systems and Brain Sciences, Florida Atlantic University, Boca Raton 33431, USA.

Abstract:
Most studies of movement coordination deal with temporal patterns of synchronization between components, often without regard to the actual amplitudes the components make. When such a system is required to produce a composite action that is spatially constrained, coordination persists, but its stability is modulated by spatial requirements effected, we hypothesize, through the component amplitudes. As shown experimentally in part I, when a redundant three-joint system (wrist, elbow, and shoulder) is required to trace a specified arc in space, the joint angles may be frequency- and phased-locked even as the curvature of the trajectory is manipulated. Transitions between joint coordination patterns occur at a critical curvature, accompanied by a significant reduction in wrist amplitude. Such amplitude reduction is viewed as destabilizing the existing coordinative pattern under current task constraints, thereby forcing the joints into a more stable phase relationship. This paper presents a theoretical analysis of these multijoint patterns and proposes an amplitude mechanism for the transition process. Our model uses three linearly coupled, nonlinear oscillators for the joint angles and reproduces both the observed interjoint coordination and component amplitude effects as well as the resulting trajectories of the end effector.
More Related Videos

Related Concept Videos
 01:21
Principle of Linear Impulse and Momentum for a System of Particles
Notably, internal forces between particles, occurring in equal and opposite collinear pairs, cancel out and are not part of the equation of motion. This exclusion simplifies the...
 01:25
Transition State Theory
 01:21
Mechanistic Models: Overview of Compartment Models
 01:26
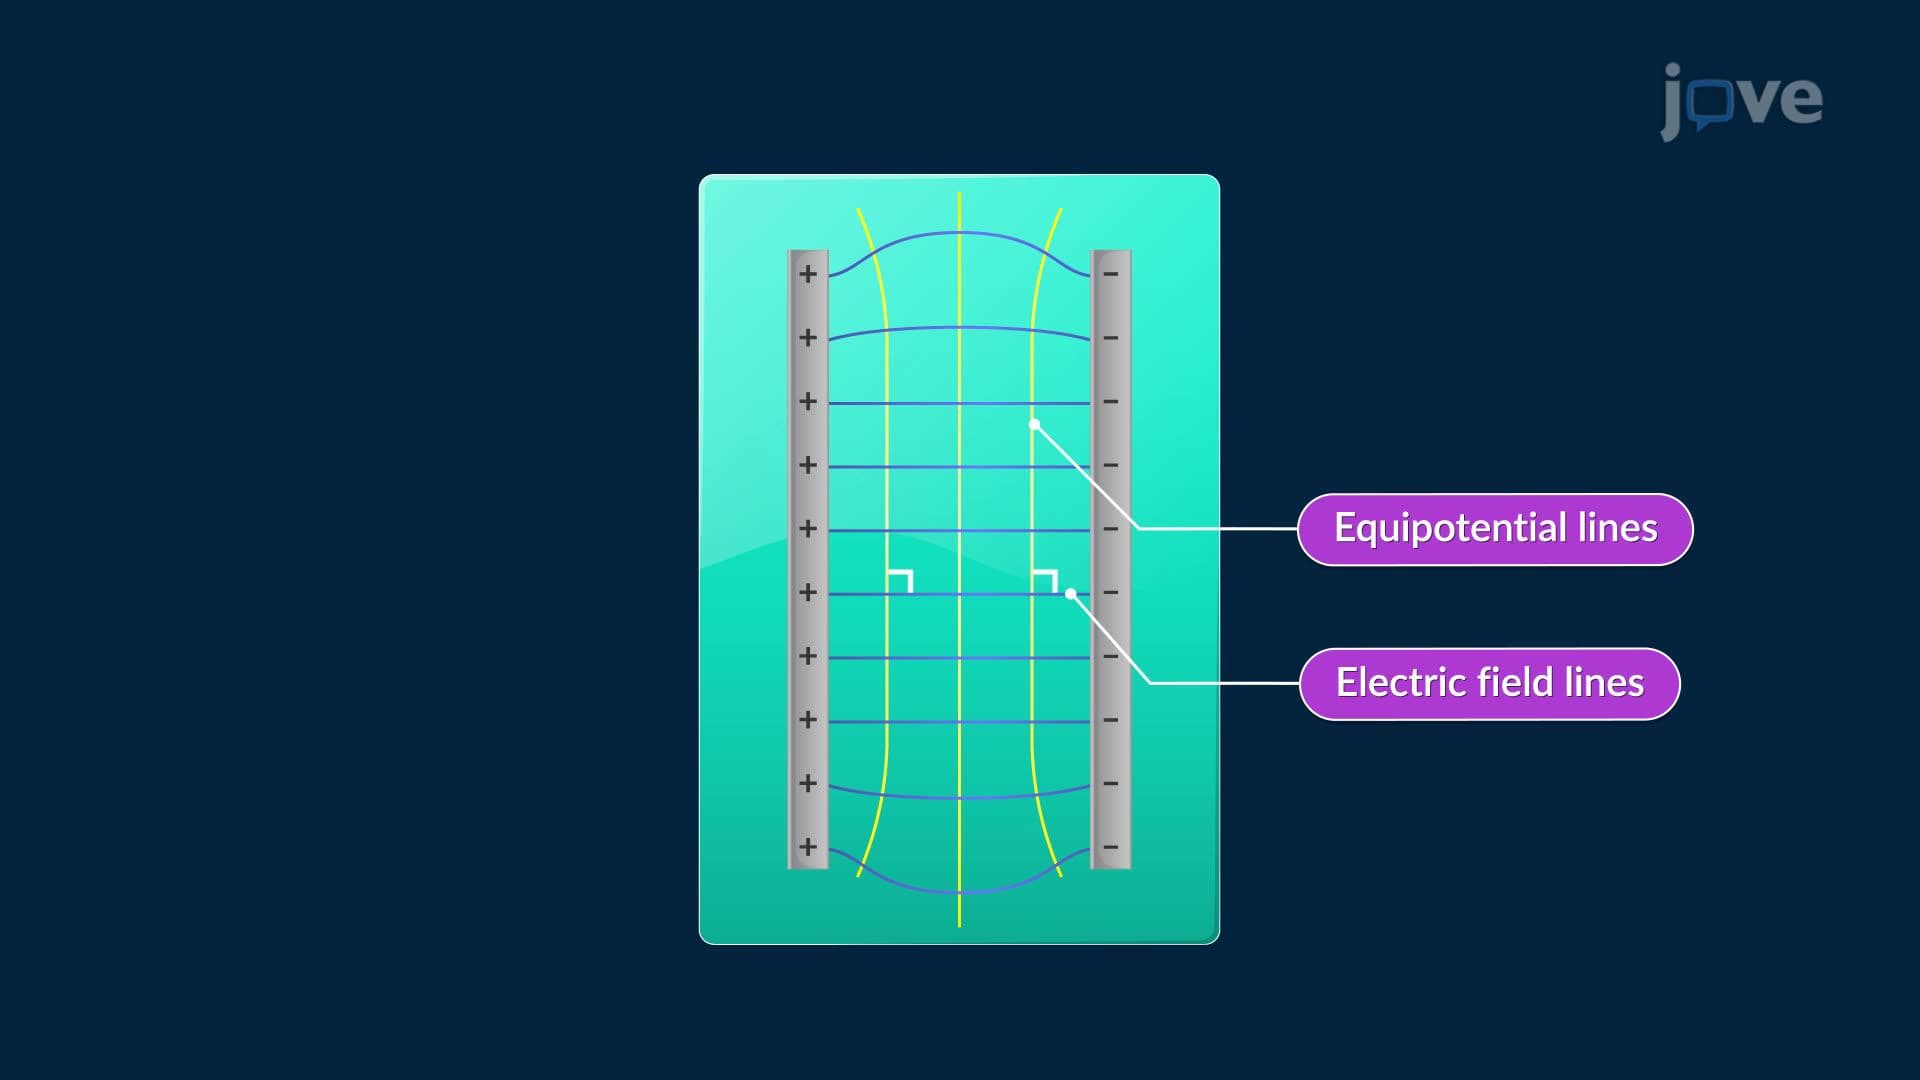
Orthogonal Trajectories
 01:21
Curves Defined by Parametric Equations
 01:30
Vector Functions and Motion: Problem Solving