Nonlinear systems identification: autocorrelation vs. autoskewness
Related Experiment Video
Updated: Oct 31, 2026
Assessing Cerebral Autoregulation via Oscillatory Lower Body Negative Pressure and Projection Pursuit Regression
Published on: December 10, 2014
1Division of Pulmonary and Critical Care Medicine, University of Massachusetts Medical Center, Worcester, Massachusetts 01655, USA.

Abstract:
Autocorrelation function (C1) or autoregressive model parameters are often estimated for temporal analysis of physiological measurements. However, statistical approximations truncated at linear terms are unlikely to be of sufficient accuracy for patients whose homeostatic control systems cannot be presumed to be stable local to a single equilibrium. Thus a quadratic variant of C1 [autoskewness function (C2)] is introduced to detect nonlinearities in an output signal as a function of time delays. By use of simulations of nonlinear autoregressive models, C2 is shown to identify only those nonlinearities that "break" the symmetry of a system, altering the mean and skewness of its outputs. Case studies of patients with cardiopulmonary dysfunction demonstrate a range of ventilatory patterns seen in the clinical environment; whereas testing of C1 reveals their breath-by-breath minute ventilation to be significantly autocorrelated, the C2 test concludes that the correlation is nonlinear and asymmetrically distributed. Higher-order functionals [e.g., autokurtosis (C3)] are necessary for global analysis of metastable systems that continuously "switch" between multiple equilibrium states and unstable systems exhibiting nonequilibrium dynamics.

Related Concept Videos
 01:09
Types of Skewness
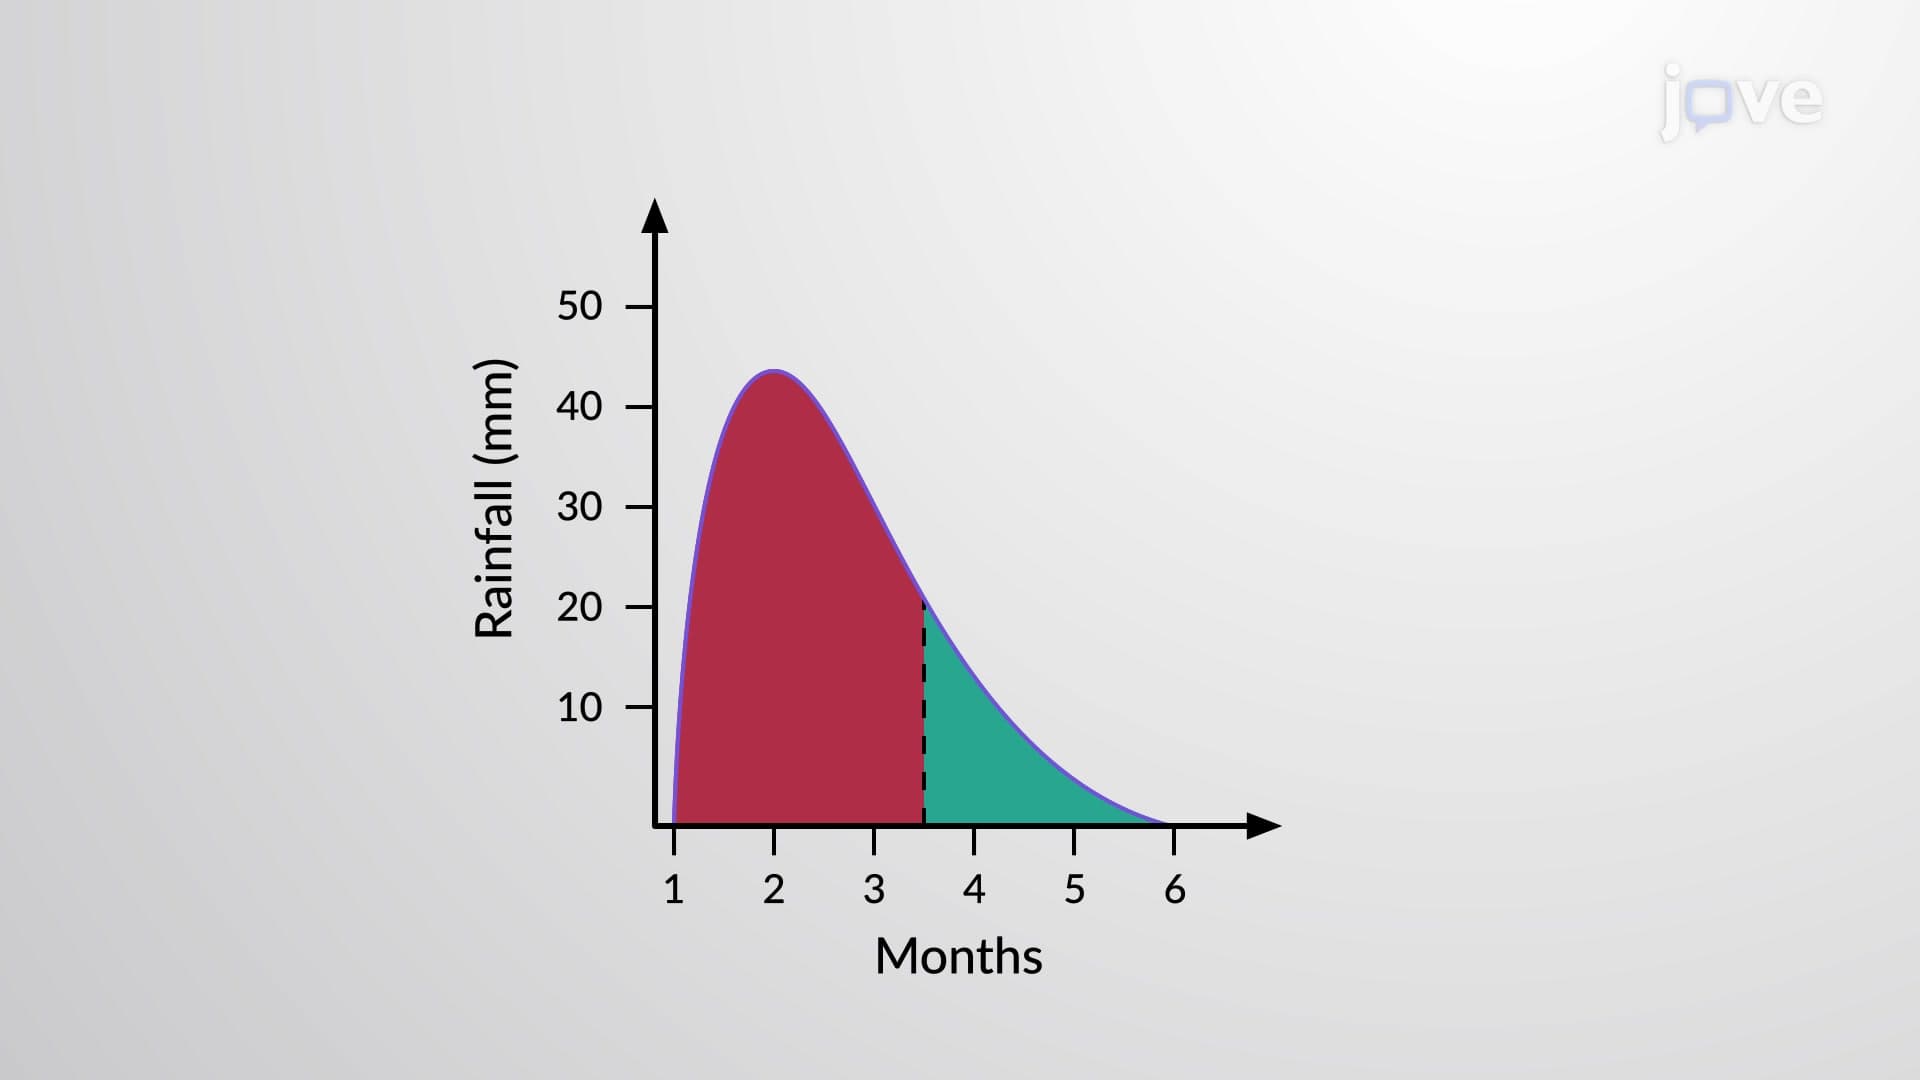
For instance, in the middle of a pandemic, the geographical distribution of vaccine coverage may be positively skewed towards populations in the global north countries. However,...
 01:06
Skewness
The longer the tail of the plot on one side, the more skewed it is. The skewness of a data set’s values suggests that the measures of central tendency are...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:10
Calibration Curves: Correlation Coefficient