Related Experiment Video
Updated: Aug 31, 2026
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Influence of frame rate and image delay on virtual driving performance
S P Sudarsan1, L Q Du, P N Cobb
1Cybernet Systems Corporation, Ann Arbor, MI 48108, USA.

Abstract:
The control and navigation of unmanned ground vehicles (UGVs) by humans requires a thorough understanding of the limitations in human perception and performance. Images of the external world recorded by cameras mounted on the UGV are presented as a video display to the operator, who then remotely manipulates the vehicle using a standard control. Operator performance is directly proportional to the computational complexity associated with the processing of video data. This work studies the effects of frame rate and image delay (lag) on remote driving performance. Experiments were conducted with five subjects using a driving simulator with a 1 dof force feedback steering wheel control. After sufficient training on the simulator, subjects drove a virtual car on a standard track under varying settings of frame rate and lag. Performance was measured by the duration to complete the course. Comparison of performance both within and between subjects showed characteristic driving patterns at different settings. Implications of the findings are discussed in relation to video data presentation for remote driving applications.

Related Concept Videos
 01:15
Instantaneous Velocity - I
 01:10
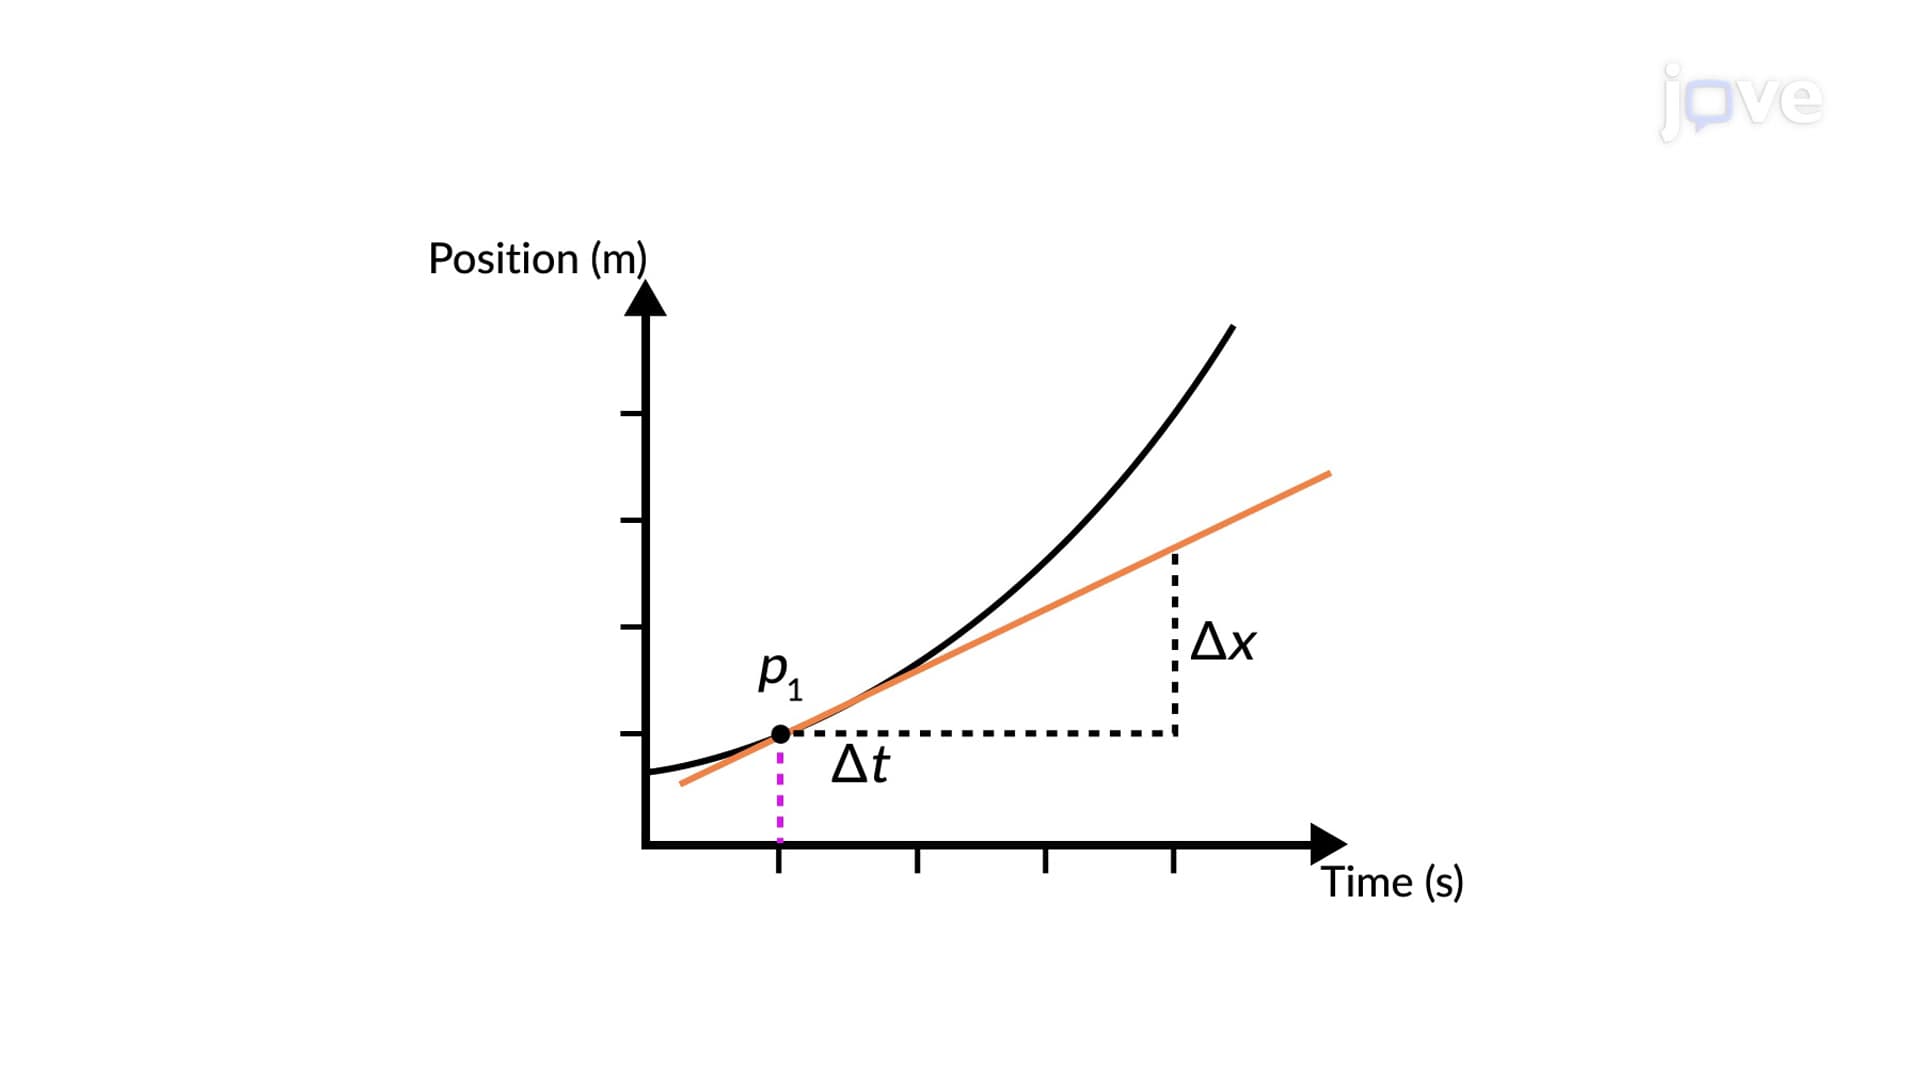
Instantaneous Velocity - II
 01:26
Frames: Problem Solving II
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...