The role of typical contours in the encodement of objects in three-dimensional arrays

J B Deregowski1, P McGeorge

  • 1Department of Psychology, Kings' College, University of Aberdeen, Scotland, UK. j.b.deregowski@abdn.ac.uk

Perception
|October 17, 1998
PubMed

Related Concept Videos

Cylinders in Three-Dimensional Space01:28

Cylinders in Three-Dimensional Space
A cylindrical surface is generated when a two-dimensional profile curve is translated along a straight line in three-dimensional space. The translated copies of the curve form a surface composed of parallel rulings, each oriented in the same fixed direction. This construction allows many three-dimensional forms to be described using relatively simple planar equations.In Cartesian coordinates, a cylindrical surface is often recognized by an equation that omits one of the three variables. For...
Level Curves and Contour Maps01:22

Level Curves and Contour Maps

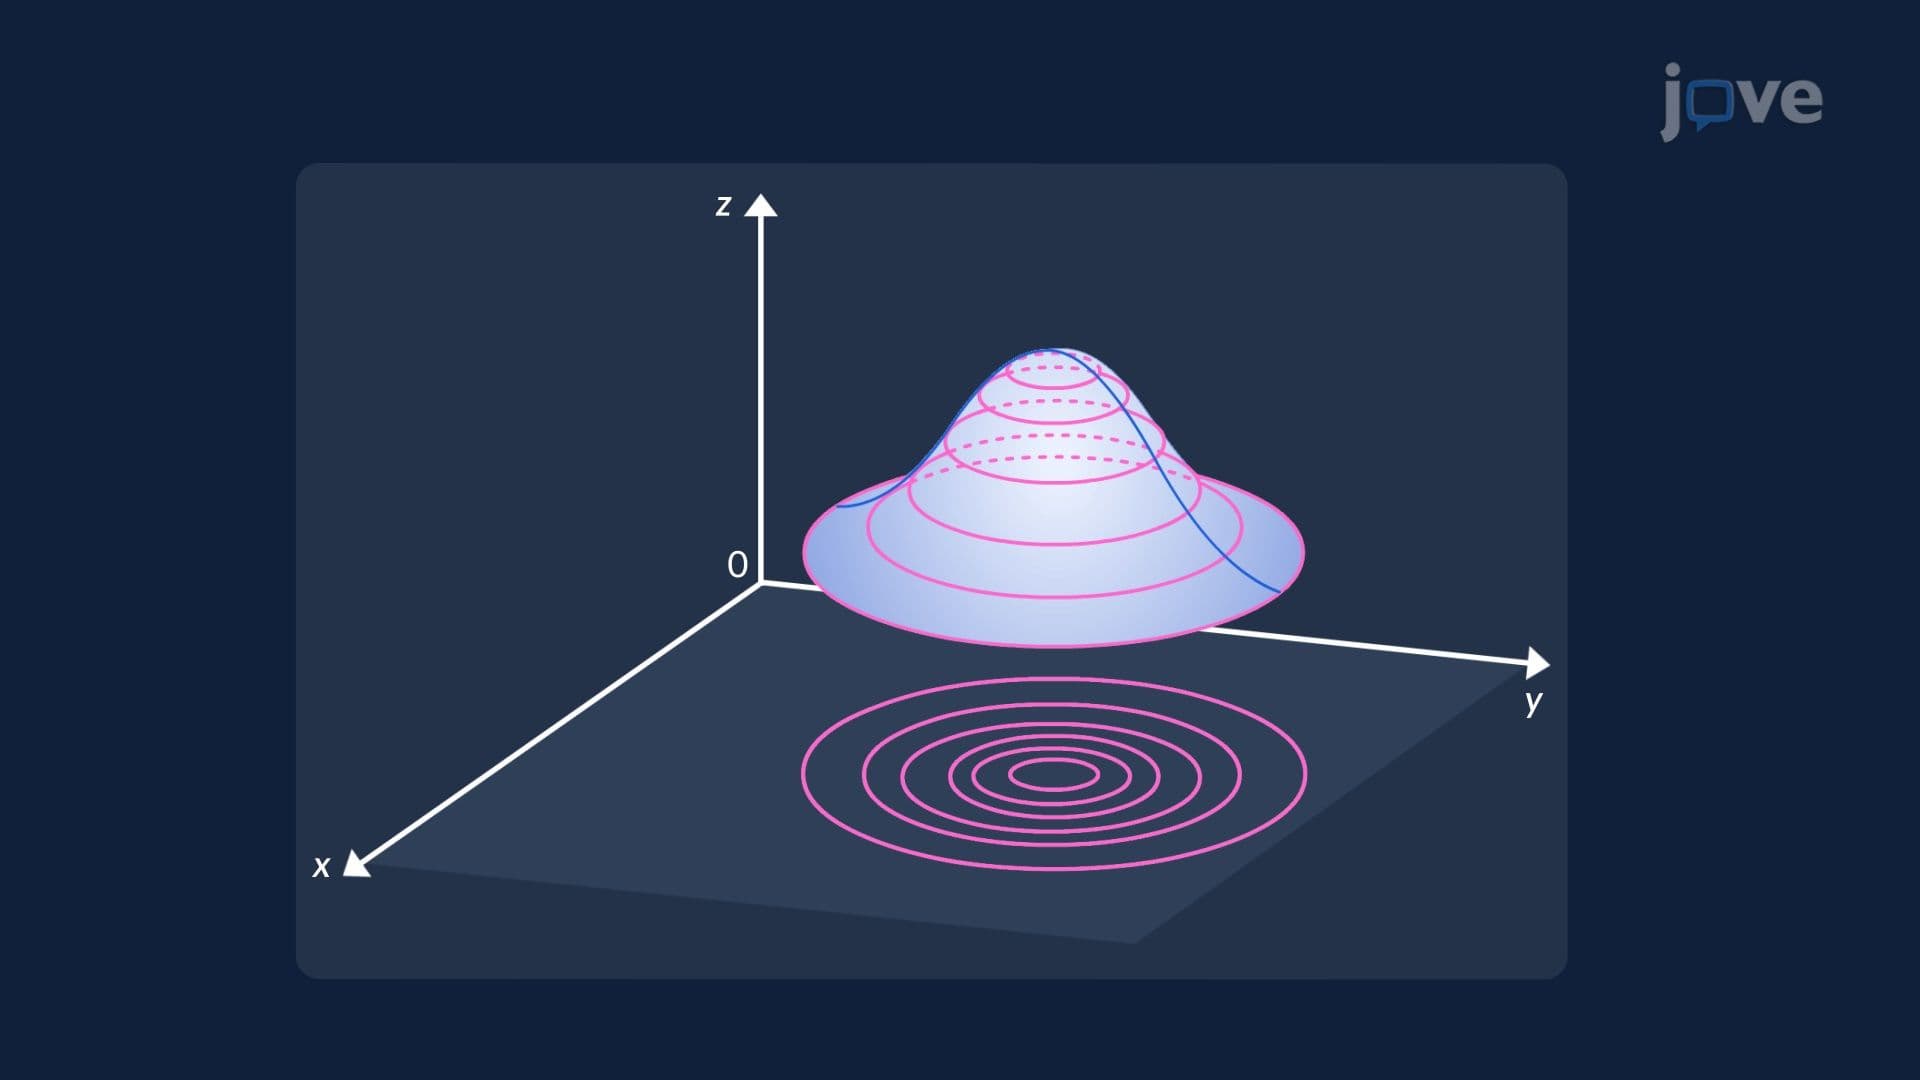
Level curves and contour maps provide a way to visualize functions of two variables on a two-dimensional plane. A useful example is a topographic map, where curved lines represent locations that share the same elevation. In mathematics, these curves are called level curves or contour lines. Each contour line corresponds to points in the domain where the function has a constant value. For a function of two variables written as z = f(x,y), a level curve is defined by the equation f(x,y) = k,...
Tangent Planes to Surfaces01:19

Tangent Planes to Surfaces

In multivariable calculus, the concept of a tangent plane plays a central role in approximating curved surfaces. When dealing with a surface defined by a function of two variables, such as z = f(x, y), the tangent plane at a given point provides the best linear approximation to the surface near that point. This local linearization allows complex, nonlinear geometries to be treated using simpler, planar models.The construction of the tangent plane involves taking vertical slices of the surface...
Parametric Surfaces01:30

Parametric Surfaces

A parametric surface in three-dimensional space is defined through a vector-valued function\begin{equation*}\mathbf{r}(u, v) = x(u, v)\mathbf{i} + y(u, v)\mathbf{j} + z(u, v)\mathbf{k}\end{equation*}where u and v are parameters within a specified domain D in the uv-plane. The functions x(u, v), y(u, v), and z(u, v) define the coordinates of points on the surface. As u and v vary over D, the position vector r(u, v) traces a continuous surface in space. This parametric representation is essential...
Oriented Surfaces01:30

Oriented Surfaces

A surface is called orientable if a consistent choice of unit normal vector can be made at every point on the surface. A thin soap film stretched across a wire loop provides a familiar example. The film separates the air on one side from the air on the other, so one side can be selected as positive and the opposite side as negative. Once this choice is made, a unit normal vector can be assigned smoothly across the entire surface.At each point on the soap film, a unit normal vector points...
Divergence Theorem in 3D Space01:20

Divergence Theorem in 3D Space

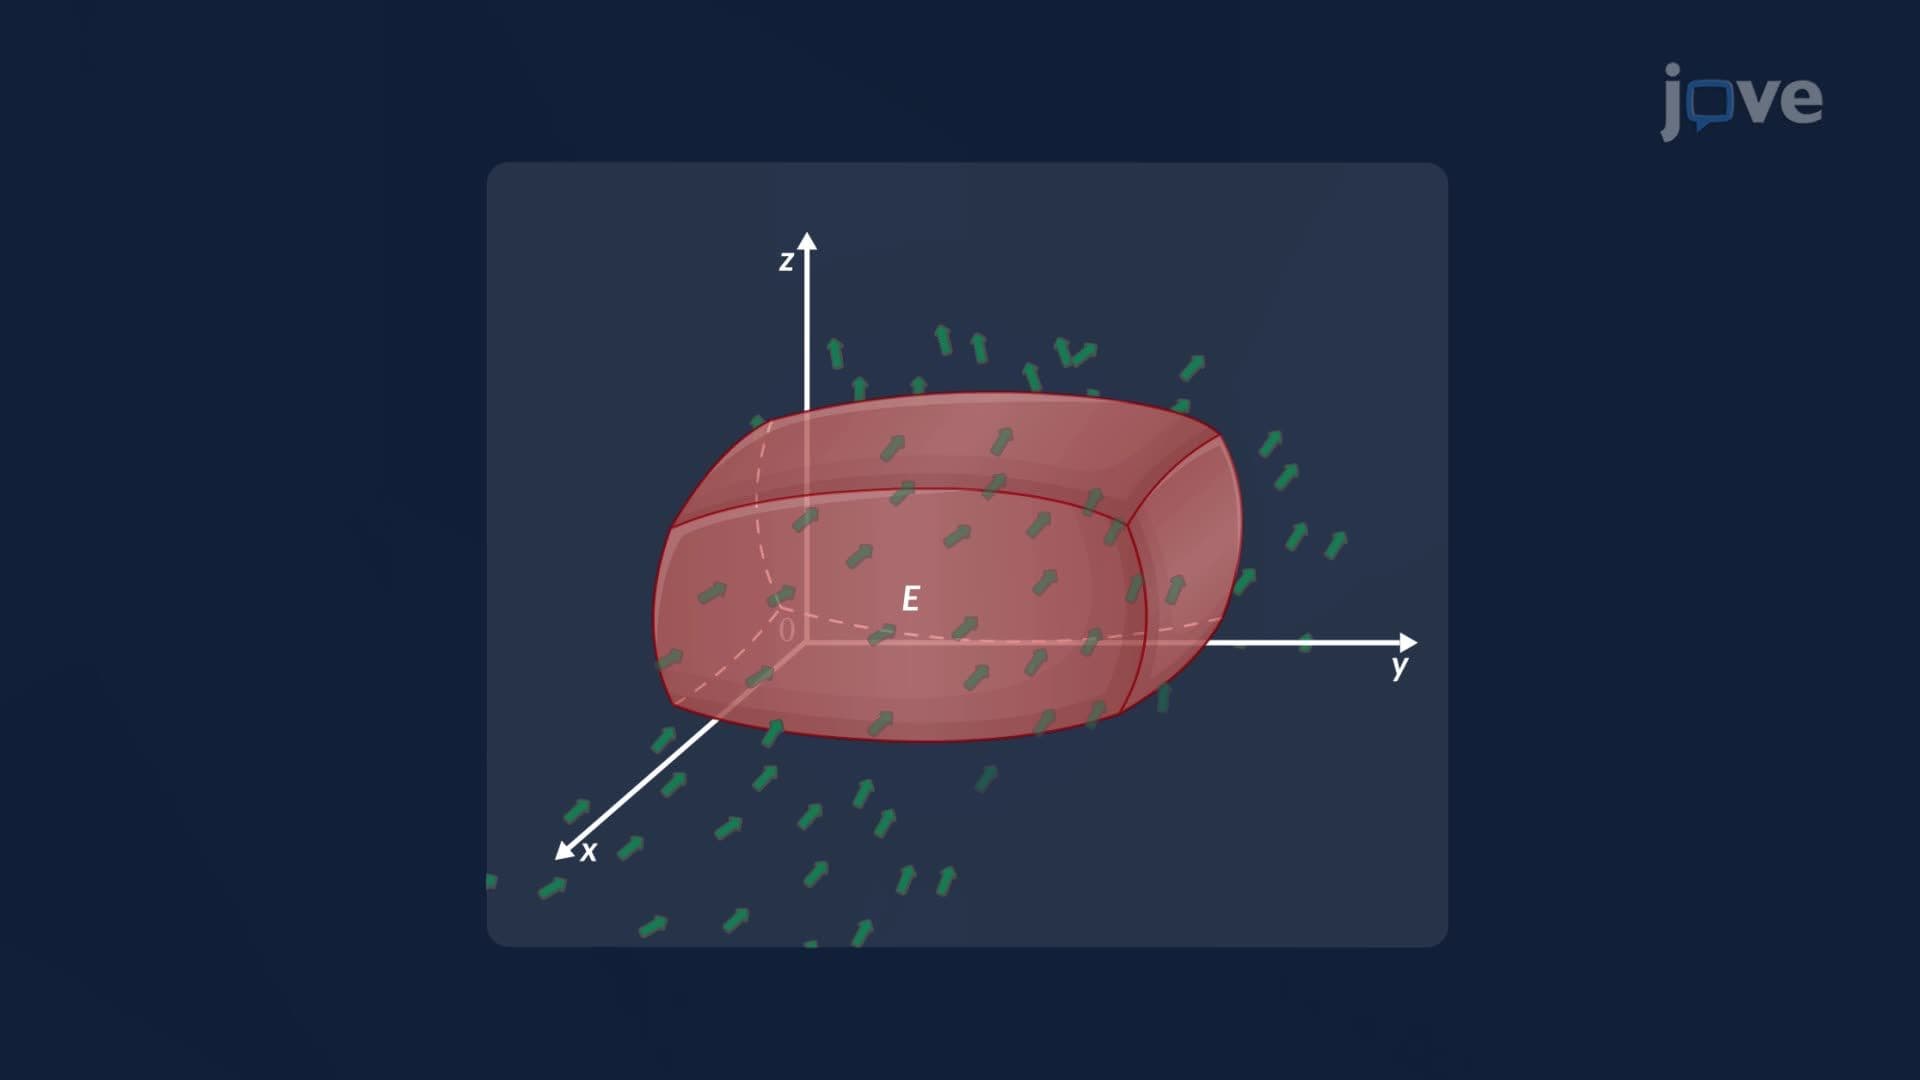
In vector calculus, flux measures the total flow of a vector field through a surface. For a closed surface in three-dimensional space, this means measuring how much of the field passes outward through every point on the boundary. Directly calculating this flux can be difficult when the surface has a complicated or irregular shape. The Divergence Theorem provides a powerful alternative by relating surface flux to behavior inside the enclosed region.The Divergence Theorem states that the outward...