Related Experiment Video
Updated: Oct 26, 2026
11:03
An Analog Macroscopic Technique for Studying Molecular Hydrodynamic Processes in Dense Gases and Liquids
Published on: December 4, 2017
Self-induced path formation among local attractors and spatiotemporal chaos in a complex Ginzburg-Landau equation
Physical Review. A, Atomic, Molecular, and Optical Physics
|July 15, 1991

Abstract
No abstract available in PubMed .
Related Concept Videos
 01:10
Entropy Change in Reversible Processes
In the Carnot engine, which achieves the maximum efficiency between two reservoirs of fixed temperatures, the total change in entropy is zero. The observation can be generalized by considering any reversible cyclic process consisting of many Carnot cycles. Thus, it can be stated that the total entropy change of any ideal reversible cycle is zero.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
 01:19
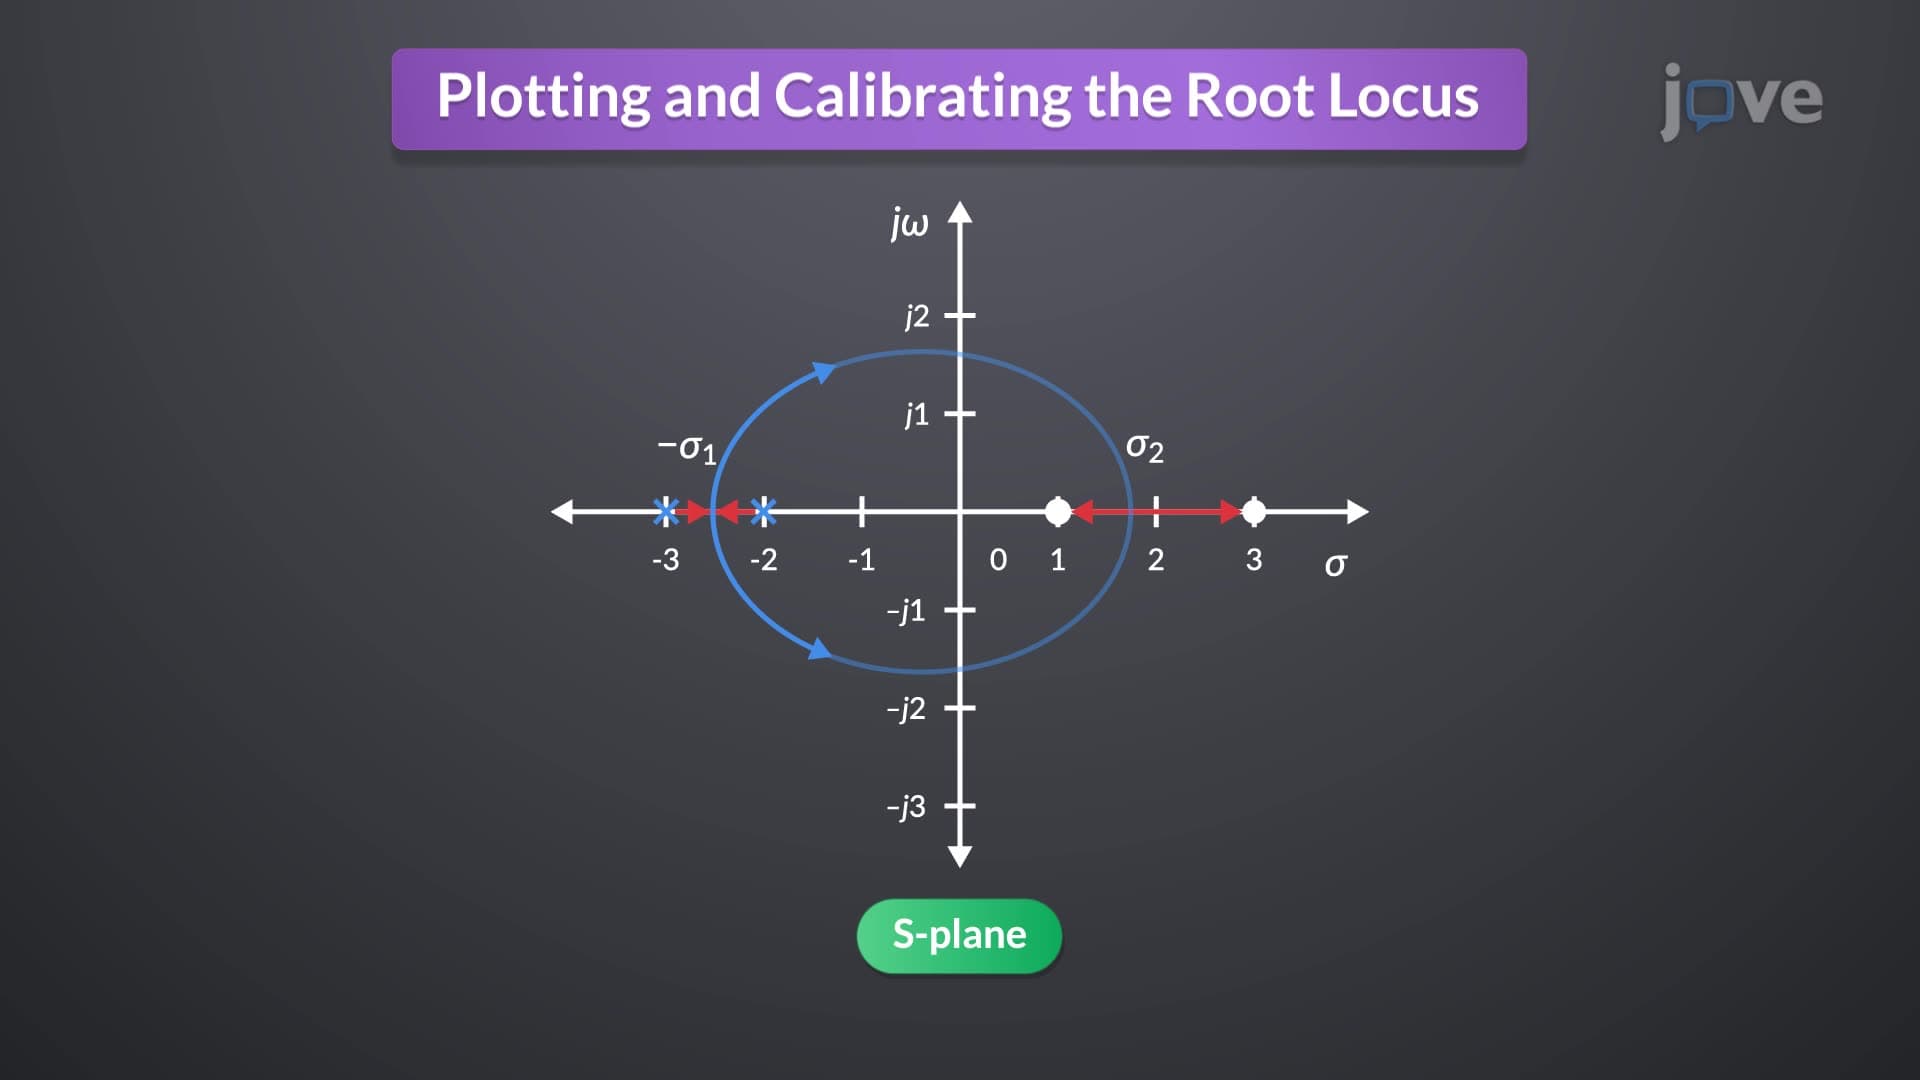
Plotting and Calibrating the Root Locus
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is observed...
 01:21
Entropy Changes Accompanying Specific Processes
Entropy, a measure of disorder in a system, changes during phase transitions like freezing or boiling. At the transition temperature Ttrs, where two phases are in equilibrium, the phase transition is a reversible process. The entropy change can be calculated from a substance's enthalpy of transition using the equation ΔStrs = ΔtrsH /Ttrs.When a perfect gas expands isothermally from one volume to another, entropy increases logarithmically with volume. Conversely, isothermal compression results...
 01:23
Stability of Equilibrium Configuration
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:26
Transmission-Line Differential Equations
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
 01:28
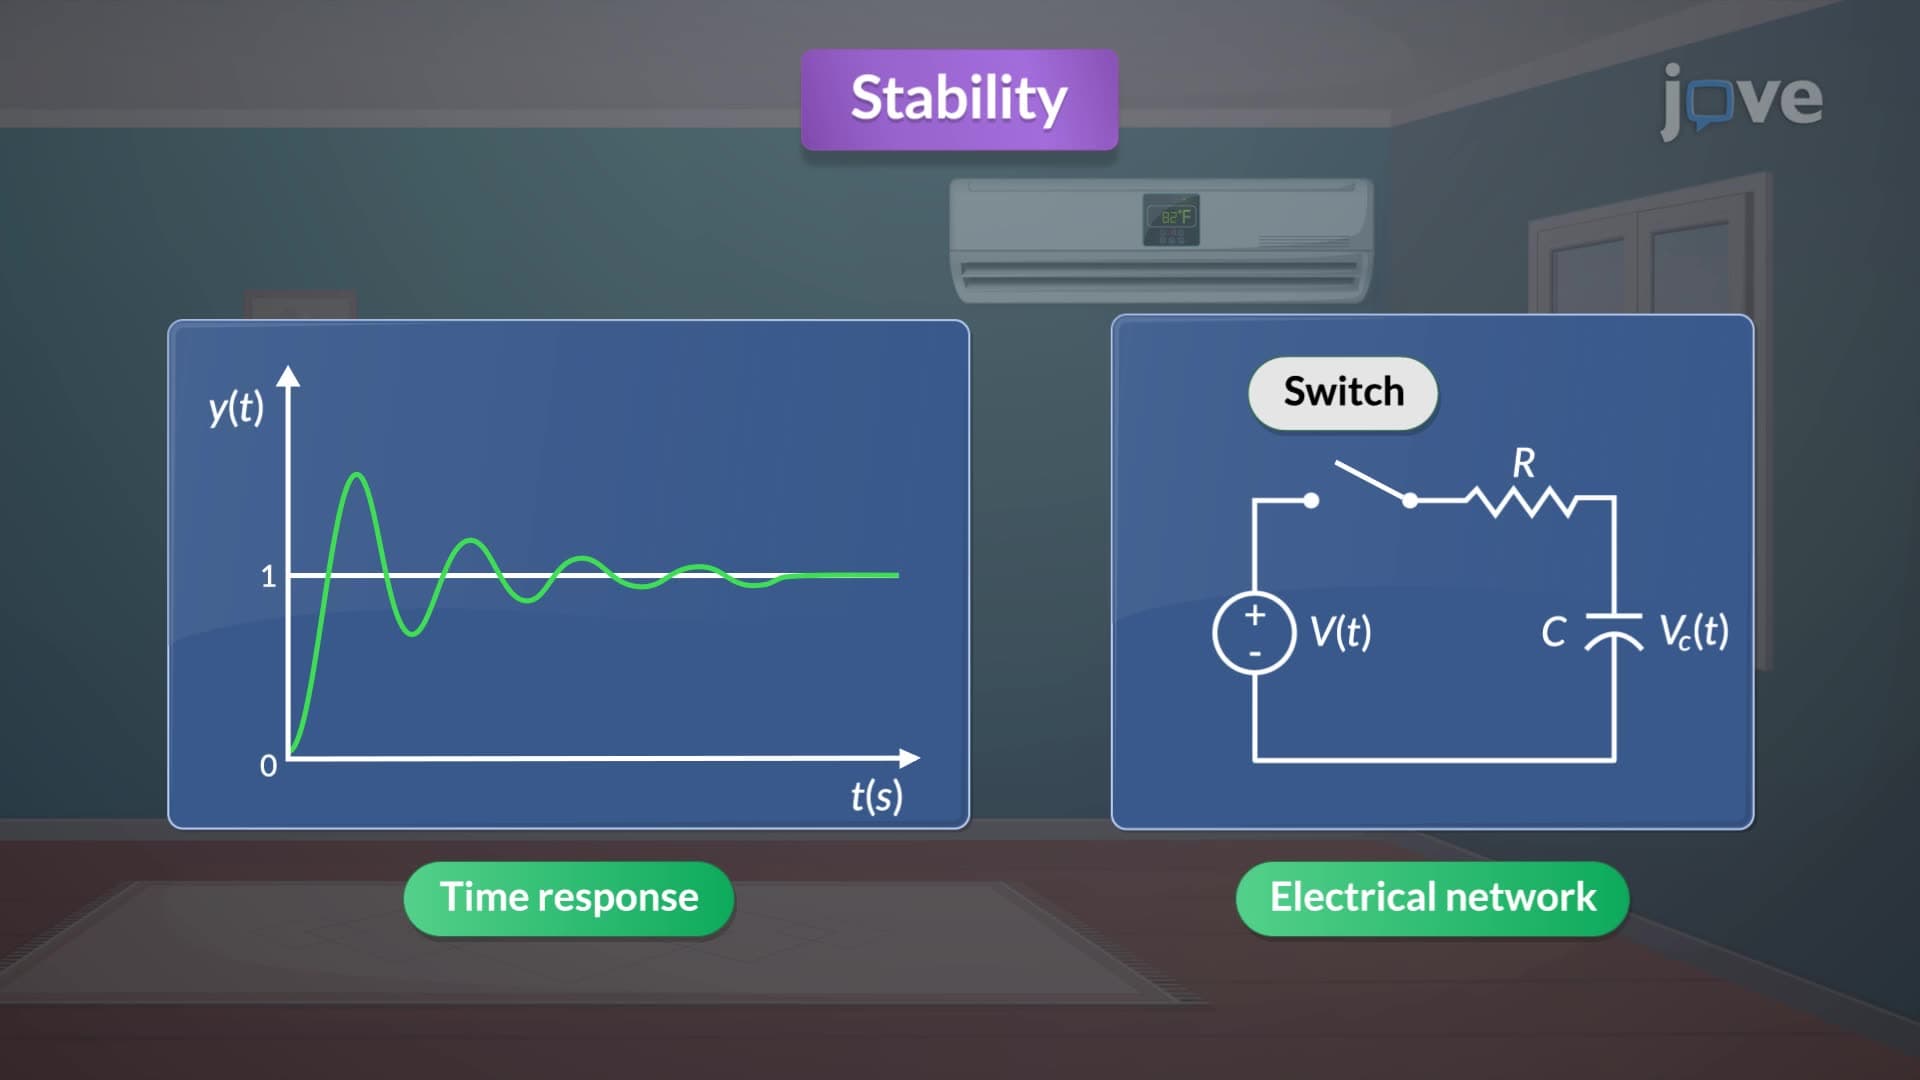
Stability
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...