一个强大的有限时间模型参考适应控制器用于任意顺序中断的LTI系统

Héctor Ríos1, Roberto Franco2, Alejandra Ferreira de Loza3
1Tecnológico Nacional de México/I.T. La Laguna, C.P. 27000, Torreón, Coahuila, Mexico; CONAHCYT, Investigadoras e Investigadores por México, C.P. 03940, Ciudad de México, Mexico.

一个新的自适应控制器实现了对不确定的系统的快速轨迹跟踪,即使有干扰. 它保证了错误的快速趋同,在模拟中证明了可行性.
科学领域:
- 控制系统工程 控制系统工程
- 机器人技术 机器人技术 机器人技术
- 适应性控制理论 适应性控制理论
背景情况:
- 轨迹跟踪对于自动驾驶系统至关重要.
- 系统的不确定性和外部干扰带来了重大挑战.
- 在这种情况下,现有的控制器可能会在有限时间的融合中扎.
研究的目的:
- 开发一个强大的有限时间模型参考自适应控制器.
- 针对带有不确定性和扰动的线性时间不变系统的轨迹跟踪.
- 为了确保追踪和参数识别错误的有限时间趋同.
主要方法:
- 一个强大的有限时间模型参考自适应控制器的设计.
- 应用Lyapunov和输入到状态稳定性理论用于收证明.
- 使用学术例子和机器人操纵器进行模拟验证.
主要成果:
- 在没有外部干扰的情况下,到零追踪和参数识别错误的有限时间收.
- 在存在时间依赖扰动的情况下,到始点周围的边界区域的有限时间收.
- 通过模拟研究证明了可行性和有效性.
结论:
- 拟议的自适应控制器有效地处理参数不确定性和外部干扰.
- 实现了有限时间的融合,比非对称方法提供了更好的性能.
- 该方法在机器人和控制系统中的实际应用中得到了验证.
更多相关视频
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
相关概念视频
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
First Order Systems
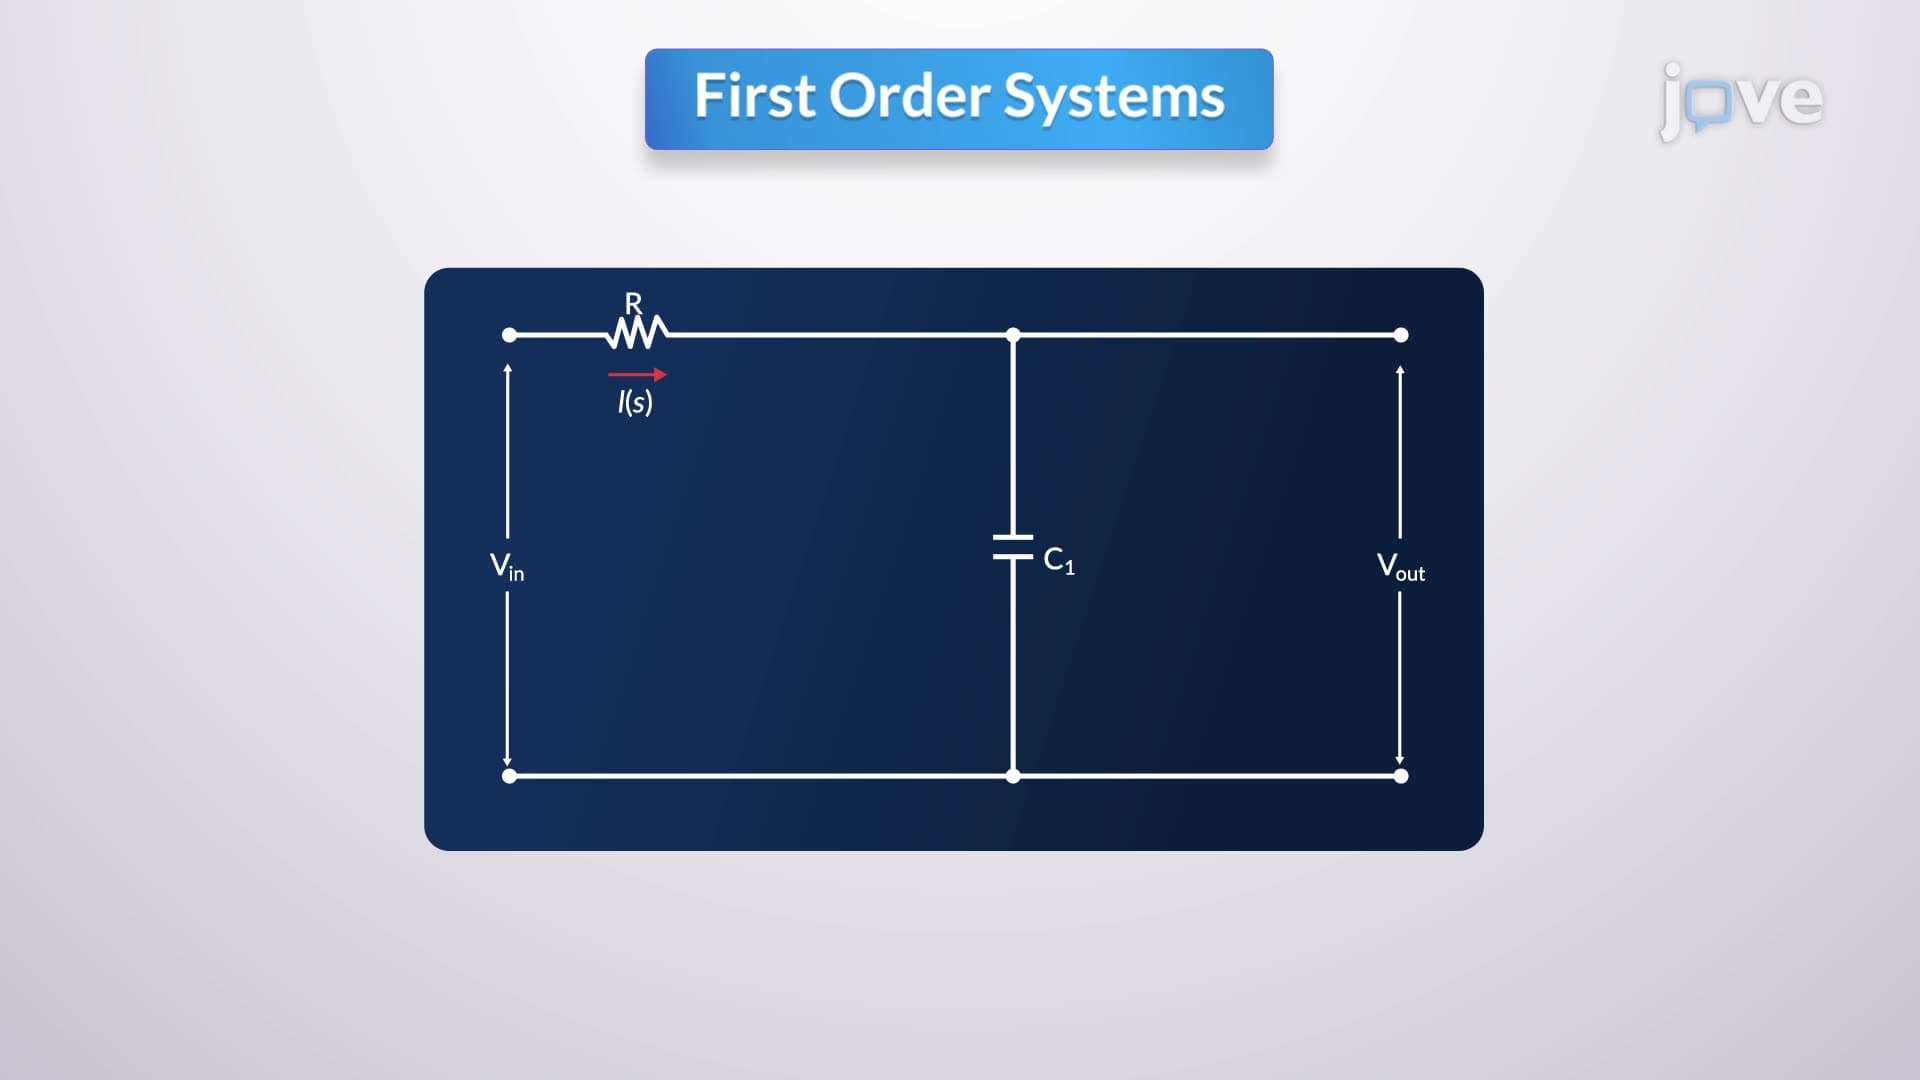
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
PI Controller: Design
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:28
Stability
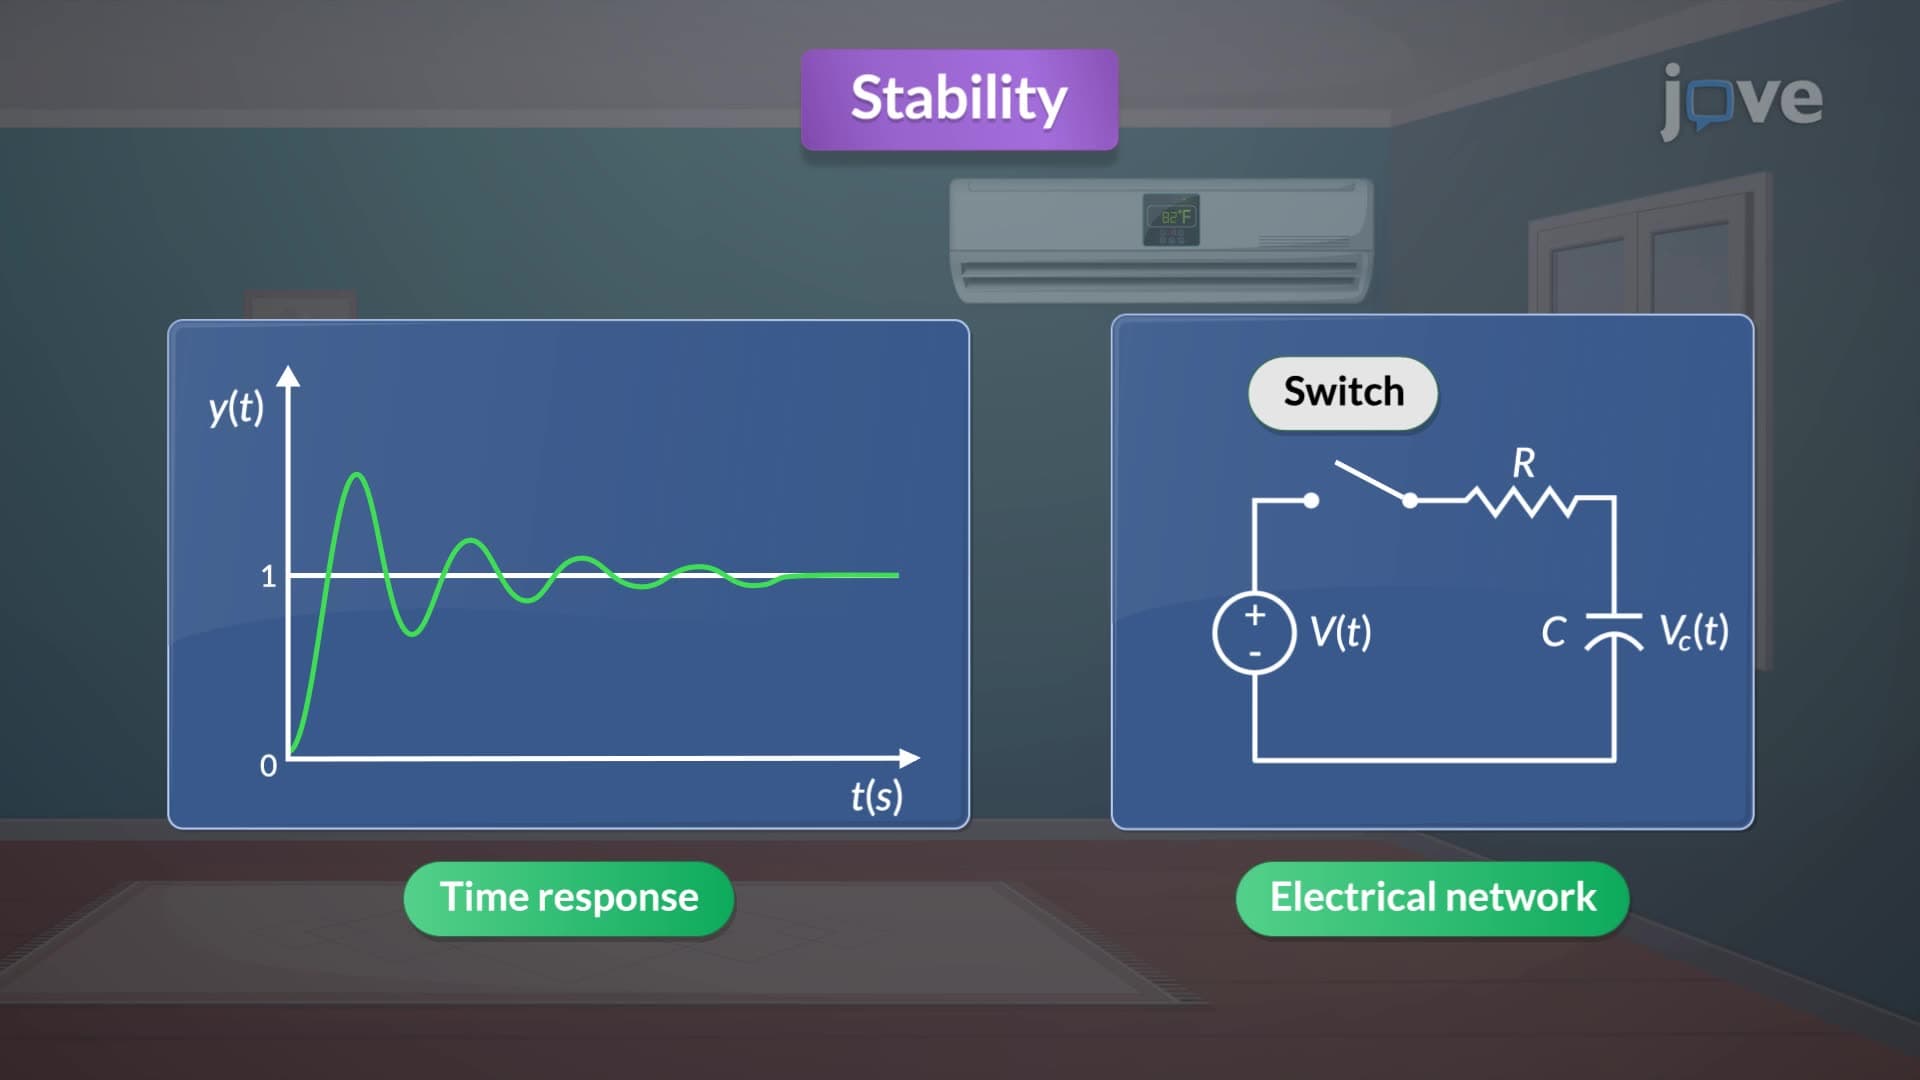
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...