

连续撞击吸引器网络需要明确的错误编码来进行增益重新校准
Gorkem Secer1,2, James J Knierim2,3,4, Noah J Cowan1,5
1Laboratory for Computational Sensing and Robotics, Johns Hopkins University, Baltimore, MD 21218, USA.
Research square
|May 3, 2024

概括
连续撞击吸引网络 (CBAN) 代表连续变量,但会积累错误. 这项研究揭示了增强重新校准,与错误校正不同,需要一个明确的错误率代码来准确的神经表征.
科学领域:
- 计算神经科学是一种计算神经科学.
- 神经网络的神经网络的神经网络
- 认知建模认知建模
背景情况:
- 连续撞击吸引网络 (CBAN) 是用于表示空间导航和工作记忆等大脑功能的连续变量的模型.
- CBAN集成输入以更新表示,但随着时间的推移积累错误.
- 现有的模型缺乏重新校准集成增益的机制,这是实验观察到的过程.
研究的目的:
- 在CBAN中调查集成获取再校准背后的神经机制.
- 为了模拟海马位细胞中增强再校准的实验发现.
- 弥合了解CBAN如何在其整合过程中实现可塑性的差距.
主要方法:
- 利用环吸引器网络,一种CBAN,来模拟实验条件.
- 分析了增益重新校准所需的网络动态.
- 开发了一种经过修改的环吸引器网络,结合了错误率代码和Hebbian可塑性.
主要成果:
- 确定增益重新校准,与错误校正不同,需要通过速率代码来编码显式神经信号编码表示错误.
- 证明基本真相输入微调集成收益,这是准确表示更新的关键因素.
- 拟议的修改后的CBAN模型成功实现了集成增益重新校准.
结论:
- 在CBAN中增益重新校准需要特定的神经机制,而不仅仅是简单的错误校正.
- 一个明确的错误率代码与Hebbian可塑性相结合,可以实现集成增益重新校准.
- 这项工作为理解连续变量表示中的神经可塑性提供了理论和计算框架.
更多相关视频
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
10.4K
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
5.0K
相关概念视频
 01:21
Control System Problem
113
In an open-loop system, such as a basic thermostat, the poles of the transfer function influence the system's response but do not determine its stability. However, when feedback is introduced to form a closed-loop system, such as an advanced thermostat that adjusts heating based on room temperature, stability is governed by the new poles of the closed-loop transfer function.
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
113
 01:28
Load-frequency control
160
Load-frequency control (LFC) is vital for maintaining power system stability, ensuring that frequency and power flows remain within acceptable limits during load changes. Turbine-governor control eliminates rotor accelerations and decelerations following load changes. However, a steady-state frequency error persists when the change in the turbine-governor reference setting is zero. In an interconnected power system, each area agrees to export or import a scheduled amount of power through...
160
 01:24
PI Controller: Design
251
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
251
 01:19
Plotting and Calibrating the Root Locus
116
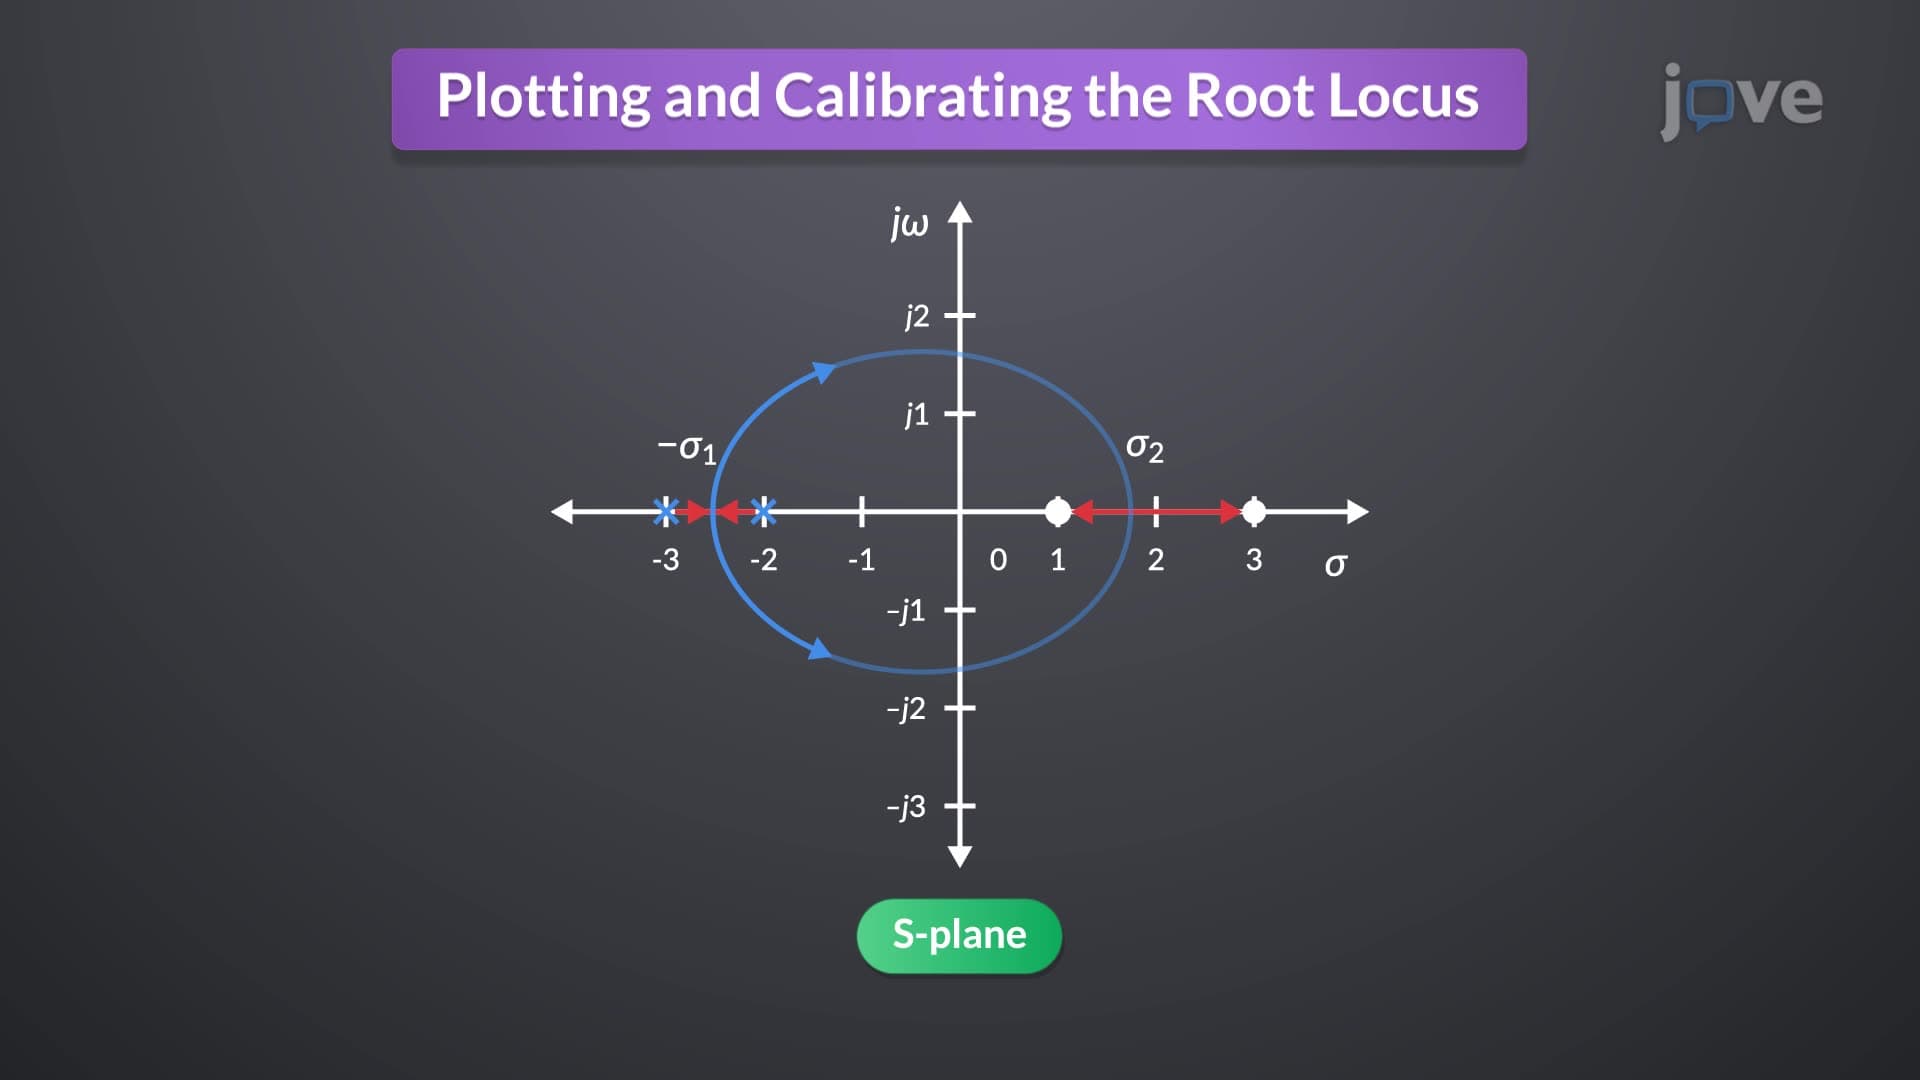
Root loci often diverge as system poles shift from the real axis to the complex plane. Key points in this transition are the breakaway and break-in points, indicating where the root locus leaves and reenters the real axis. The branches of the root locus form an angle of 180/n degrees with the real axis, where n is the number of branches at a breakaway or break-in point.
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
116
 01:26
Feedback control systems
307
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
307
 01:22
Controller Configurations
94
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
94