一般化交互多模型卡尔曼过算法用于在非高斯噪音下操纵目标跟踪

Jie Wang1, Jiacheng He1, Bei Peng1

  • 1School of Mechanical and Electrical Engineering, University of Electronic Science and Technology of China, PR China.

ISA transactions
|September 22, 2024
PubMed
概括

高斯混合模型卡尔曼波器 (GIMM-KF) 在非高斯噪声下增强了目标跟踪. 这种强大的算法提高了对机动目标的准确性和稳定性.

相关概念视频

Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
70
Linear Momentum in Control Volume01:13

Linear Momentum in Control Volume

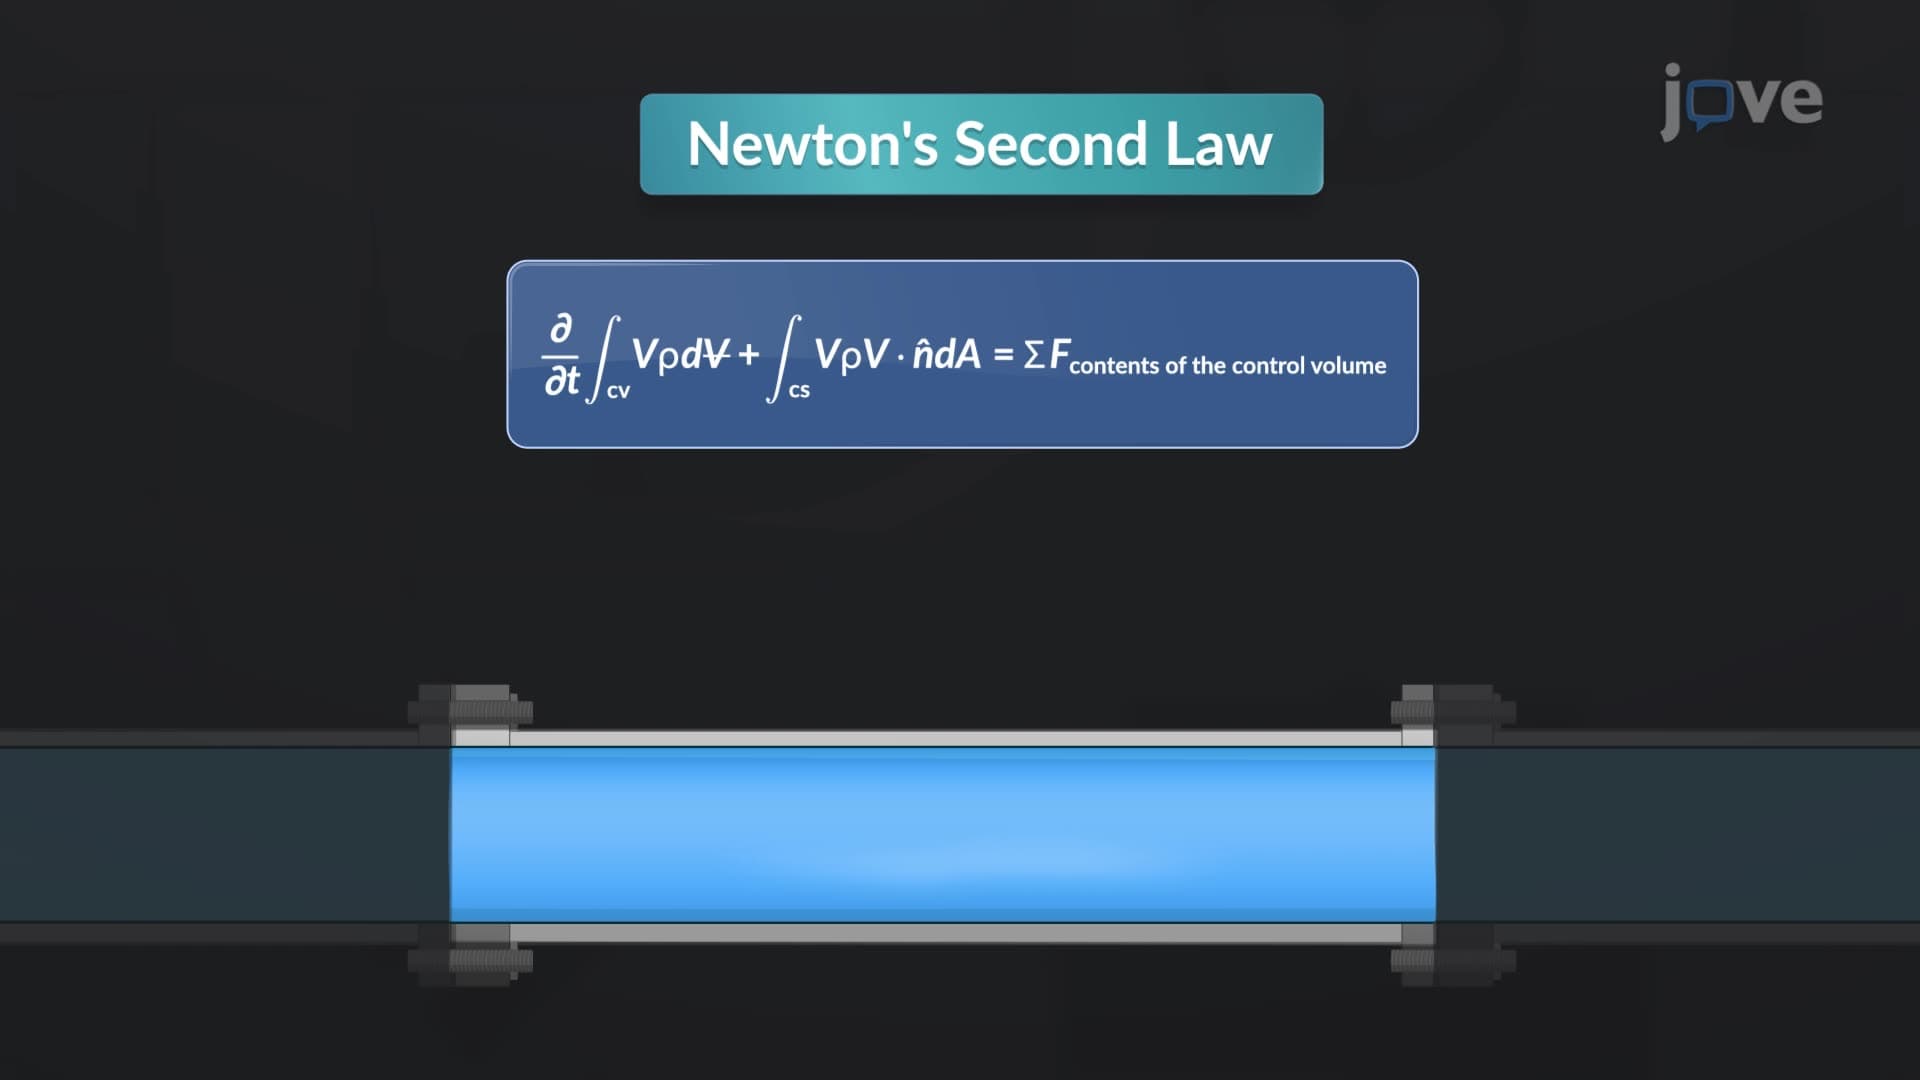
Newton's second law is applied to obtain the linear momentum in a control volume in a fluid system. According to this law, the rate of change of linear momentum is equal to the sum of external forces acting on the system. When a control volume matches the fluid system at a specific moment, the forces acting on both are identical. Reynolds transport theorem helps explain this by breaking down the system's linear momentum into two components: the rate of change of linear momentum within...
897
Multi-input and Multi-variable systems01:22

Multi-input and Multi-variable systems

Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence...
101
Kinematic Equations - III01:18

Kinematic Equations - III

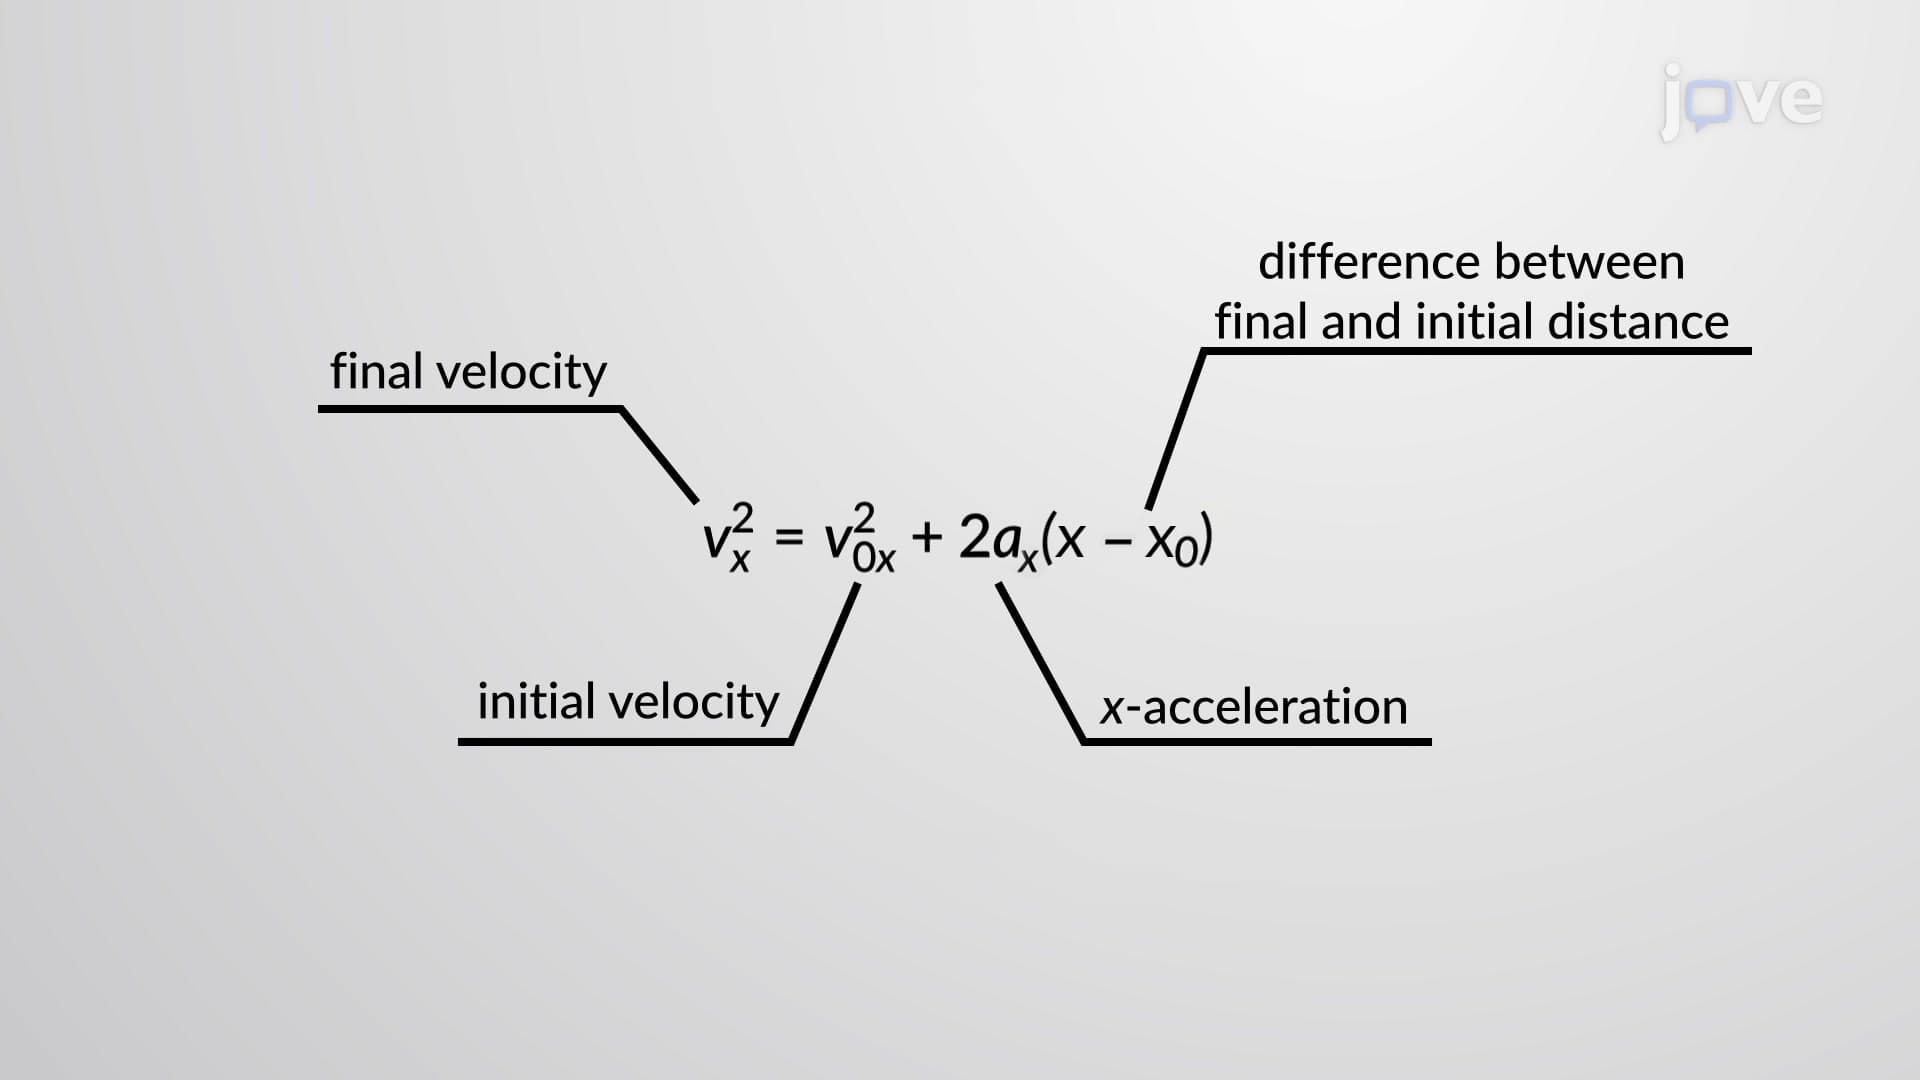
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
7.6K
Non-uniform Circular Motion01:22

Non-uniform Circular Motion

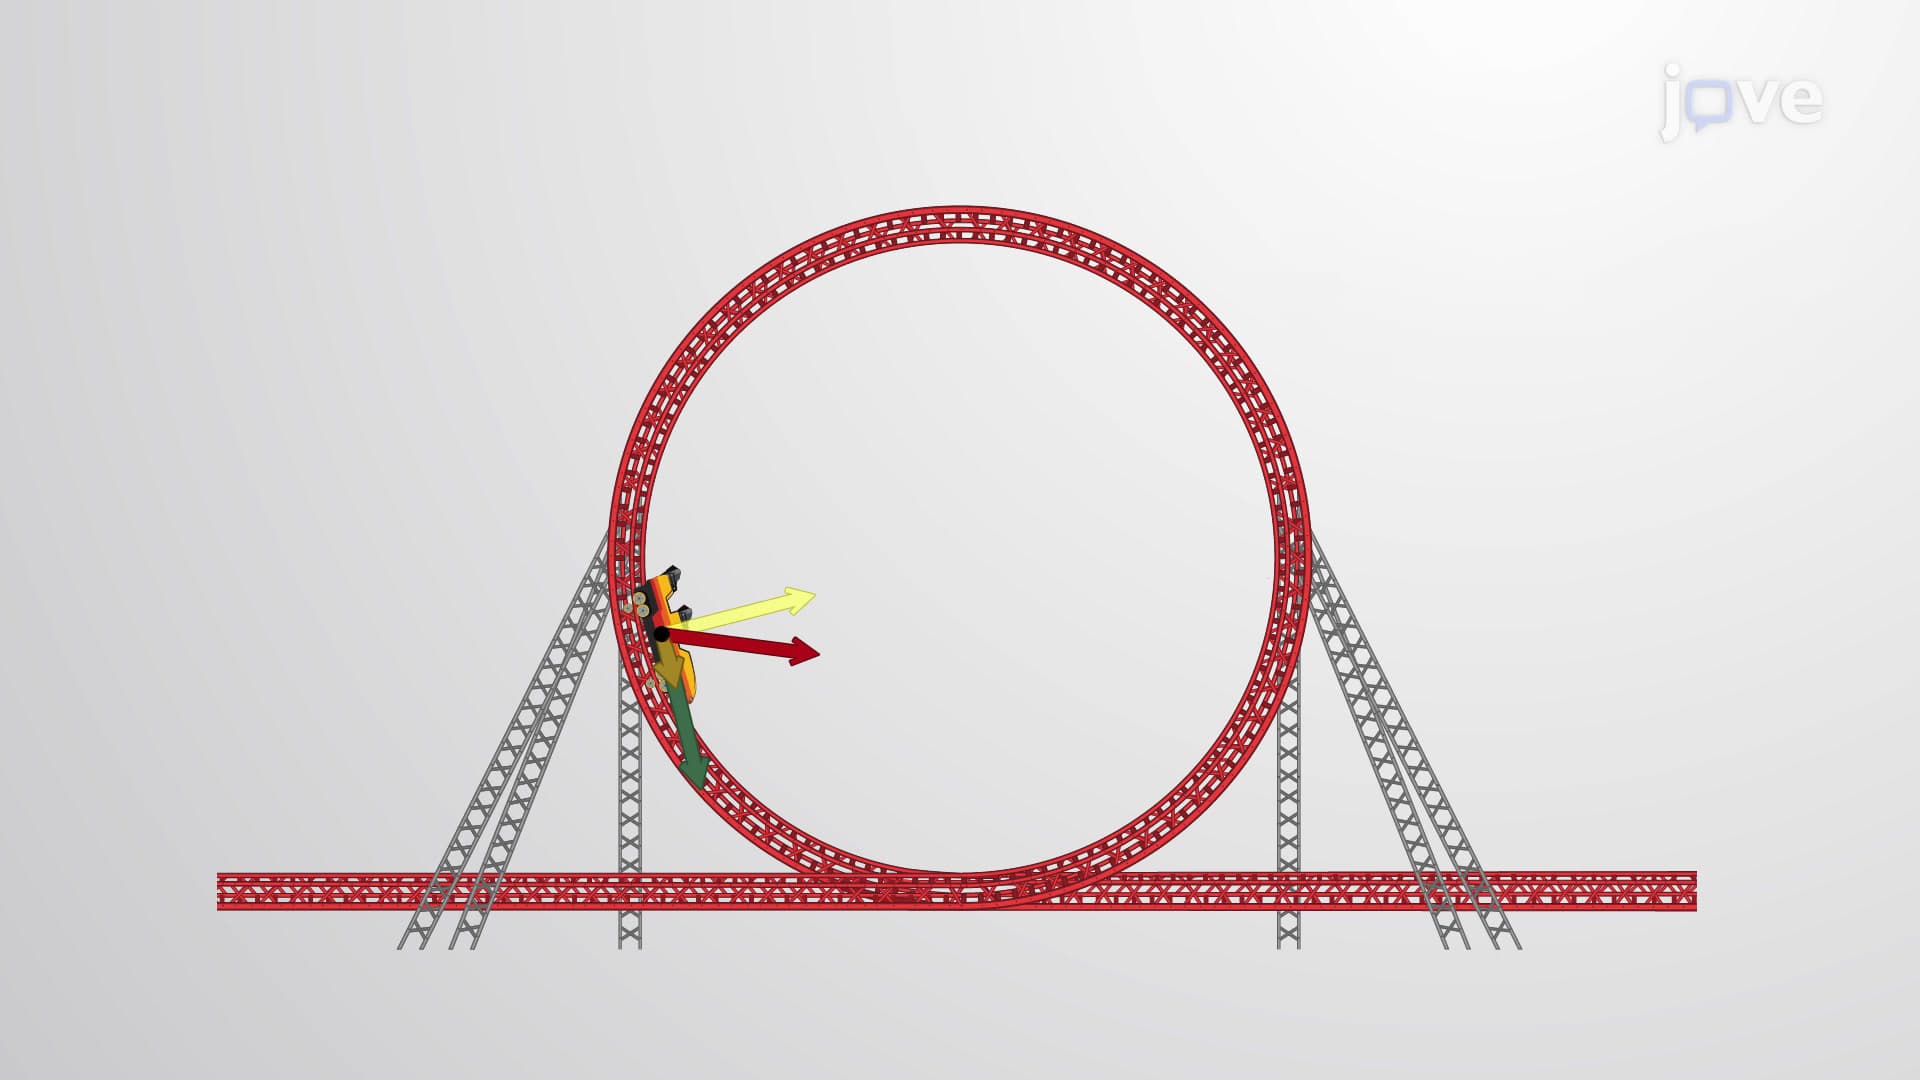
In uniform circular motion, the particle executing circular motion has a constant speed, and the circle is at a fixed radius. However, not all circular motion occurs at a constant speed. A particle can travel in a circle and speed up or slow down, showing an acceleration in the direction of motion. In that case, the motion is called non-uniform circular motion, and an additional acceleration is introduced, which is in the direction tangential to the circle. 
For example, such...
7.1K
Kinematic Equations - II01:17

Kinematic Equations - II

The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
9.4K