Does early non-linearity account for second-order motion?
Related Experiment Video
Updated: Oct 19, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
N E Scott-Samuel1, M A Georgeson
1School of Psychology, University of Birmingham, UK. n.scott-samuel@rhbnc.ac.uk

Abstract:
A contrast-modulated (CM) pattern is formed when a modulating or envelope function imposes local contrast variations on a higher-frequency carrier. Motion may be seen when the envelope drifts across a stationary carrier and this has been attributed to a second-order pathway for motion. However, an early compressive response to luminance (e.g. in the photoreceptors) would introduce a distortion product at the modulating frequency. We used a nulling method to measure the distortion product, and then asked whether this early distortion could account for perception of second-order motion. The first stimulus sequence consisted of alternate frames of CM (100% modulation) and luminance-modulated (LM) patterns. Carriers were either 2-D binary noise (4 x 4 min arc dots) or a 4 c/deg grating, both modulated at 0.6 c/deg. The carrier was stationary while the phase of the modulating signal (LM alternating with CM) stepped successively through 90 degrees to the left or right. Motion was seen in a direction opposite to the phase stepping, consistent with early compressive distortion that induces an out-of-phase LM component into the CM stimulus. We measured distortion amplitude by adding LM to the CM frames to null the perceived motion. Distortion increased as the square of carrier contrast, as predicted by the compressive transducer. It also increased with modulation drift rate, implying that the transducer is time-dependent, not static. Thus early compressive non-linearity does induce first-order artefacts into second-order stimuli. Nevertheless this does not account for second-order motion, since perceived motion of second-order sequences (CM in every frame) could in general not be nulled by adding LM components. We conclude that two pathways for motion do exist.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
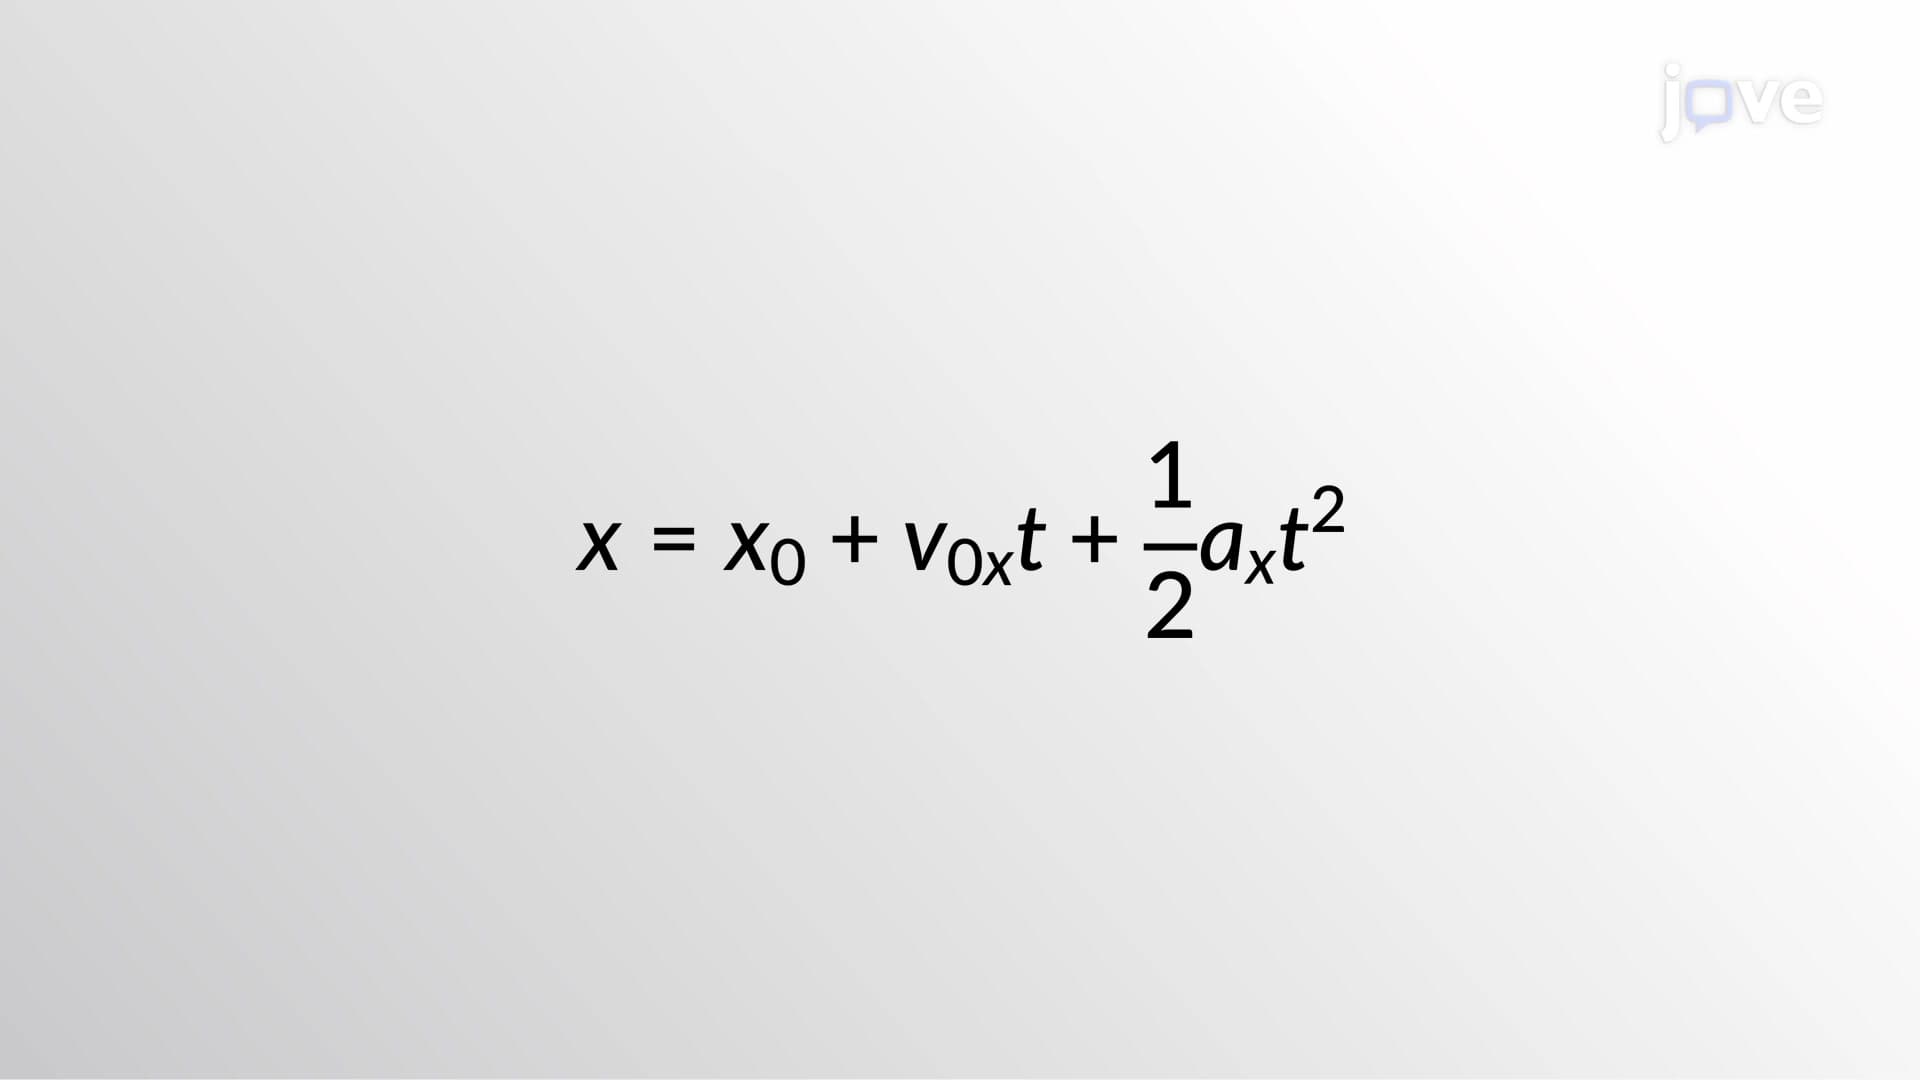 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
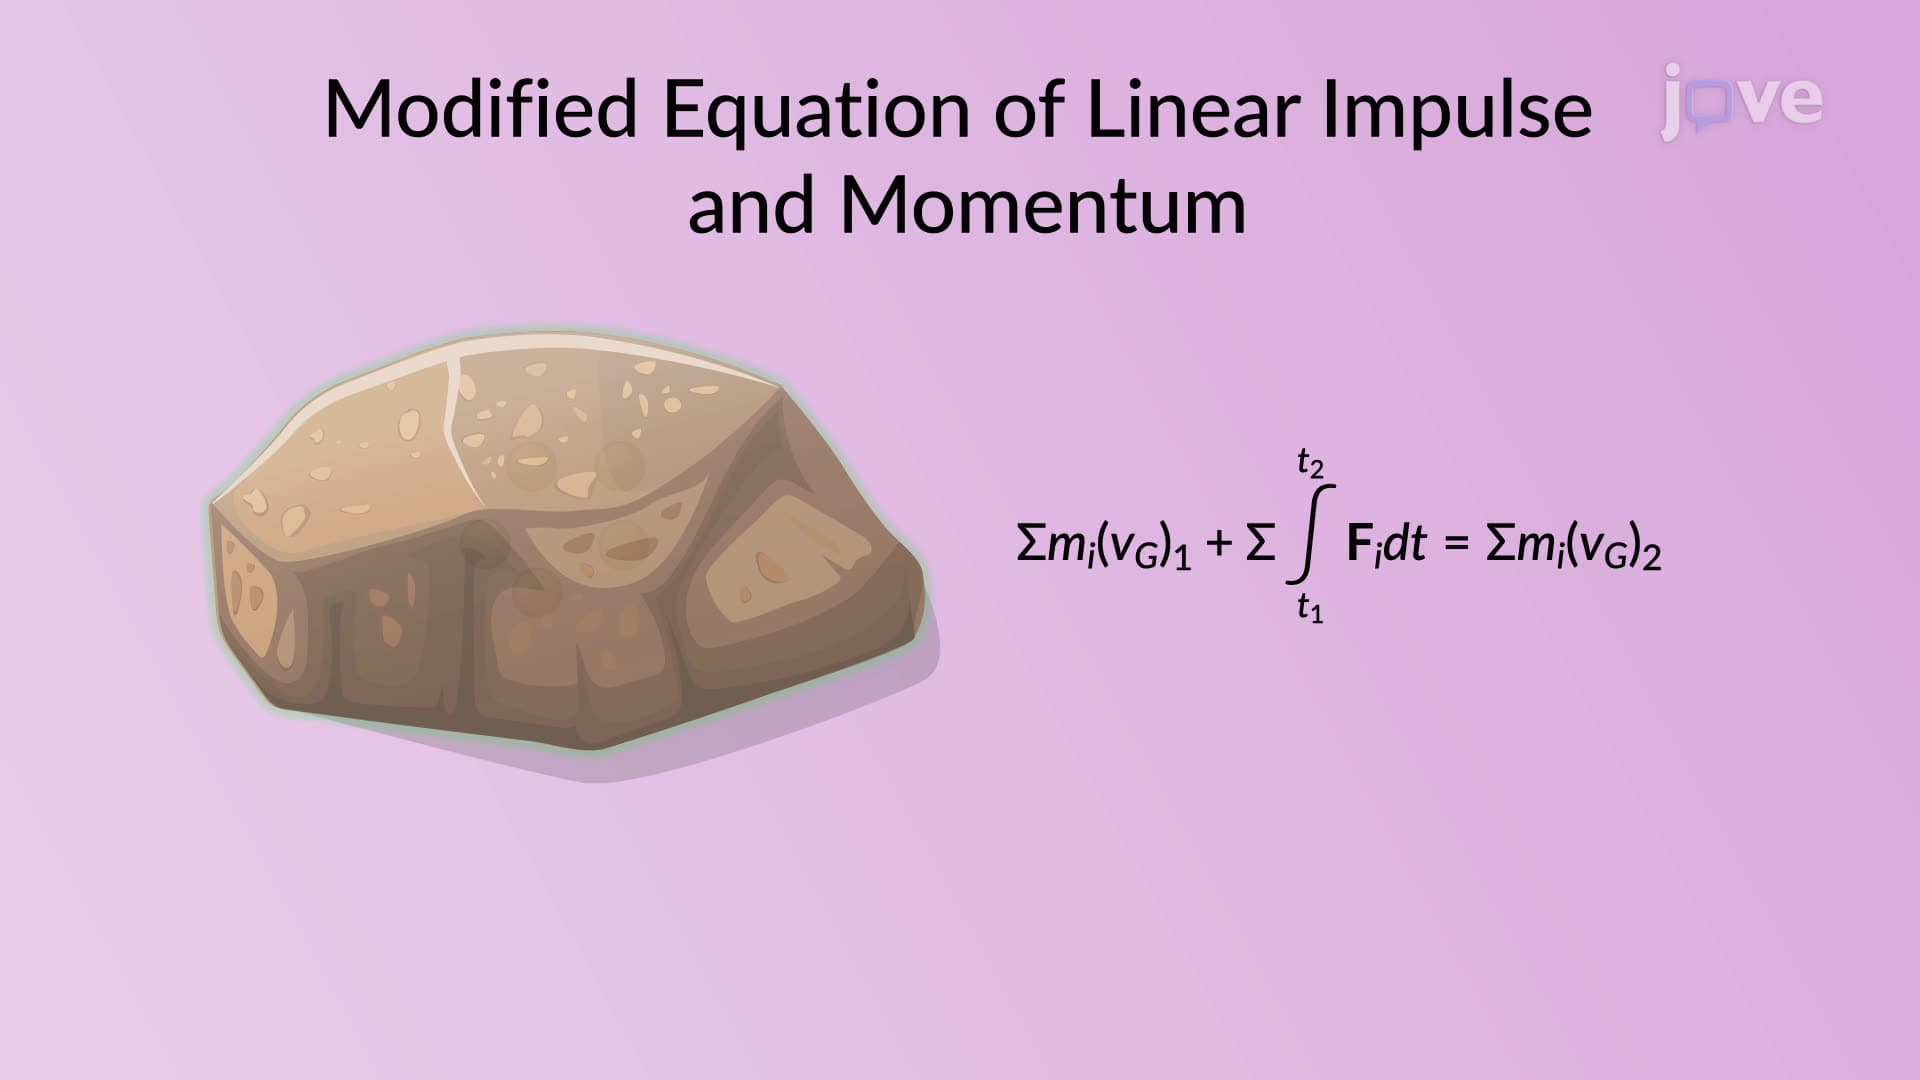
Principle of Linear Impulse and Momentum for a System of Particles
Notably, internal forces between particles, occurring in equal and opposite collinear pairs, cancel out and are not part of the equation of motion. This exclusion simplifies the...
 01:09
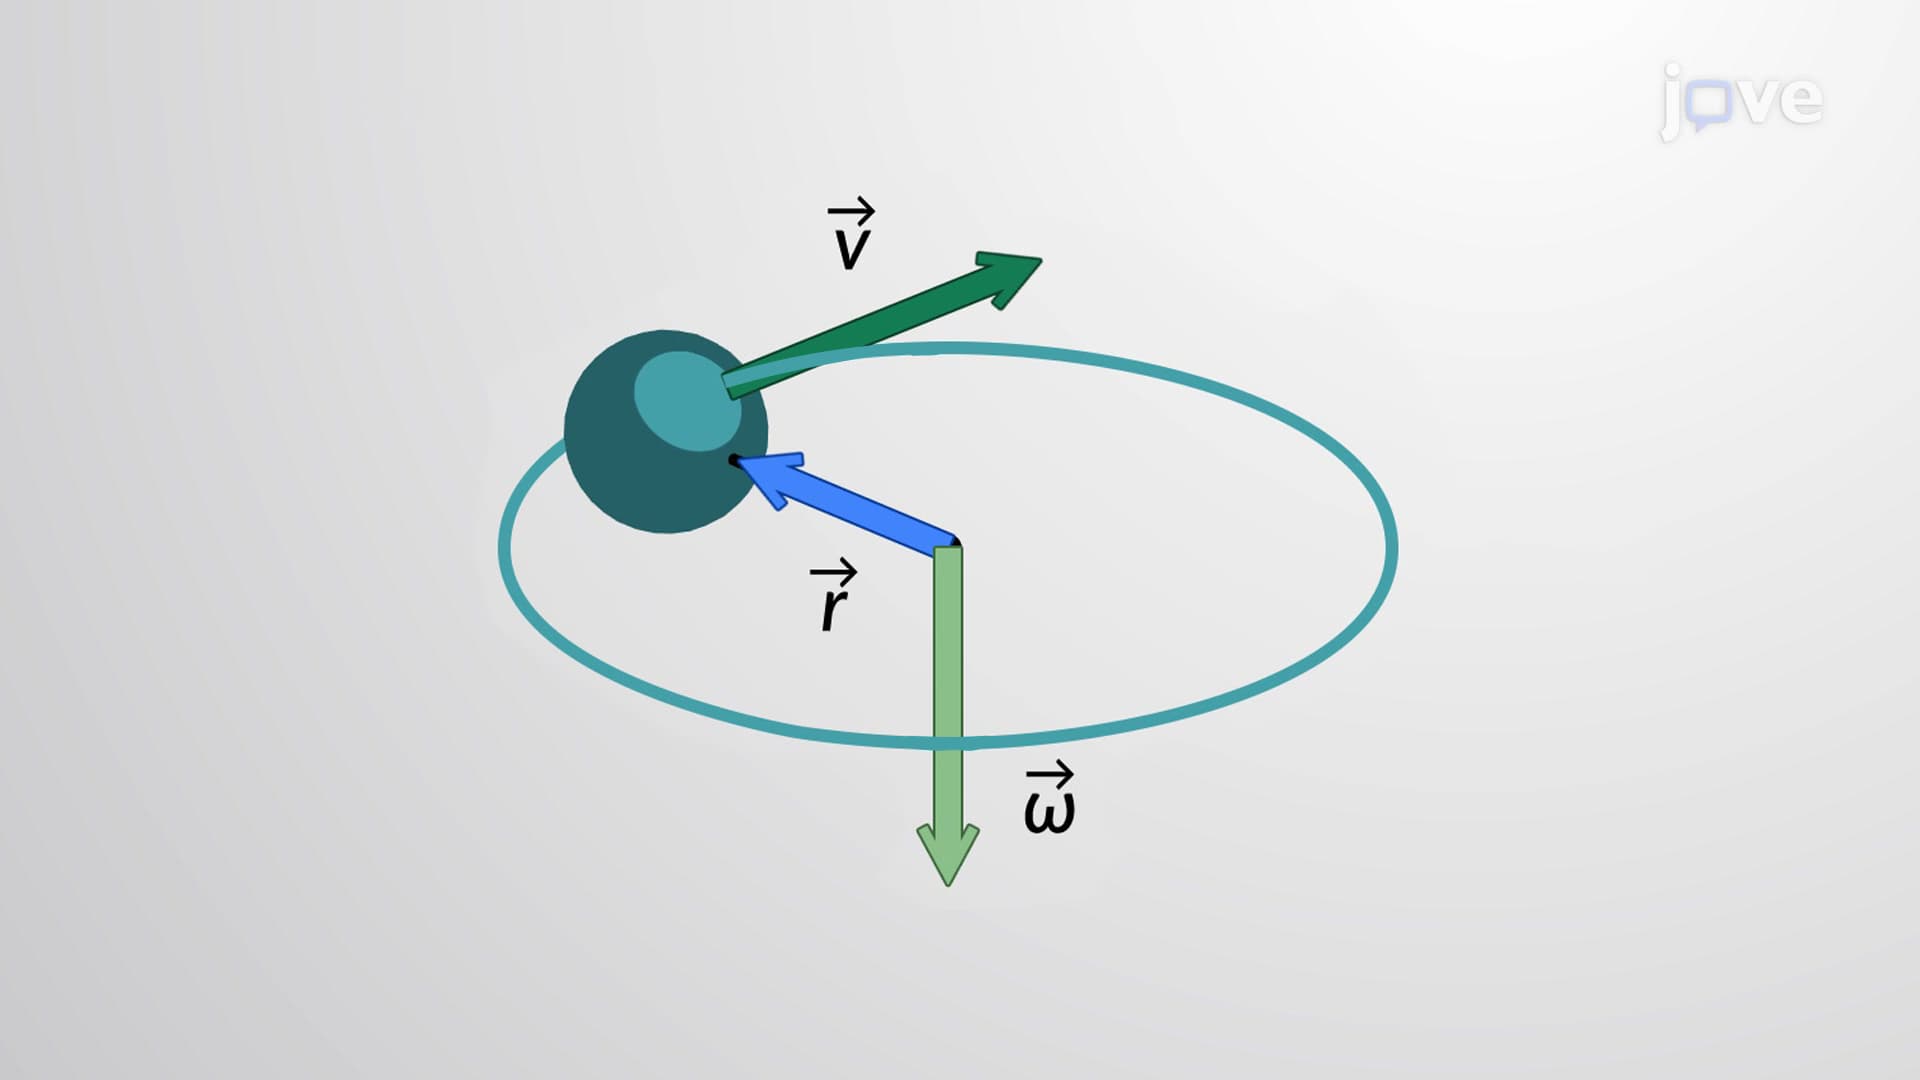
Relating Angular And Linear Quantities - I
When comparing the linear and rotational variables individually, the linear variable of position has physical units of meters, whereas the angular position variable has dimensionless units of radians, as it is the ratio of two lengths. The linear velocity...