Robust PID tuning strategy for uncertain plants based on the Kharitonov theorem
Related Experiment Video
Updated: Oct 10, 2026
Robotic Sensing and Stimuli Provision for Guided Plant Growth
Published on: July 1, 2019
1Institute of Electrical Engineering, Yuan Ze University, Chungli, Taiwan. eeyjh@saturn.yzu.edu.tw

Abstract:
In this paper, the Kharitonov theorem for interval plants is exploited for the purpose of synthesizing a stabilizing controller. The aim here is to develop a controller to simultaneously stabilize the four Kharitonov-defined vortex polynomials. Different from the prevailing works, the controller is designed systematically and graphically through the search of a non-conservative Kharitonov region in the controller coefficient parameter plane. The region characterizes all stabilizing PID controllers that stabilize an uncertain plant. Thus the relationship between the Kharitonov region and the stabilizing controller parameters is manifest. Extensively, to further guarantee the system with certain robust safety margins, a virtual gain phase margin tester compensator is added. Stability analysis is carried out. The control system is proved to maintain robustness at least to the pre-specified margins. The synthesized controller with coefficients selected from the obtained non-conservative Kharitonov region can stabilize the concerned uncertain plants and fulfill system specifications in terms of gain margins and phase margins.
Related Concept Videos
 01:19
PID Controller
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:19
Routh-Hurwitz Criterion II
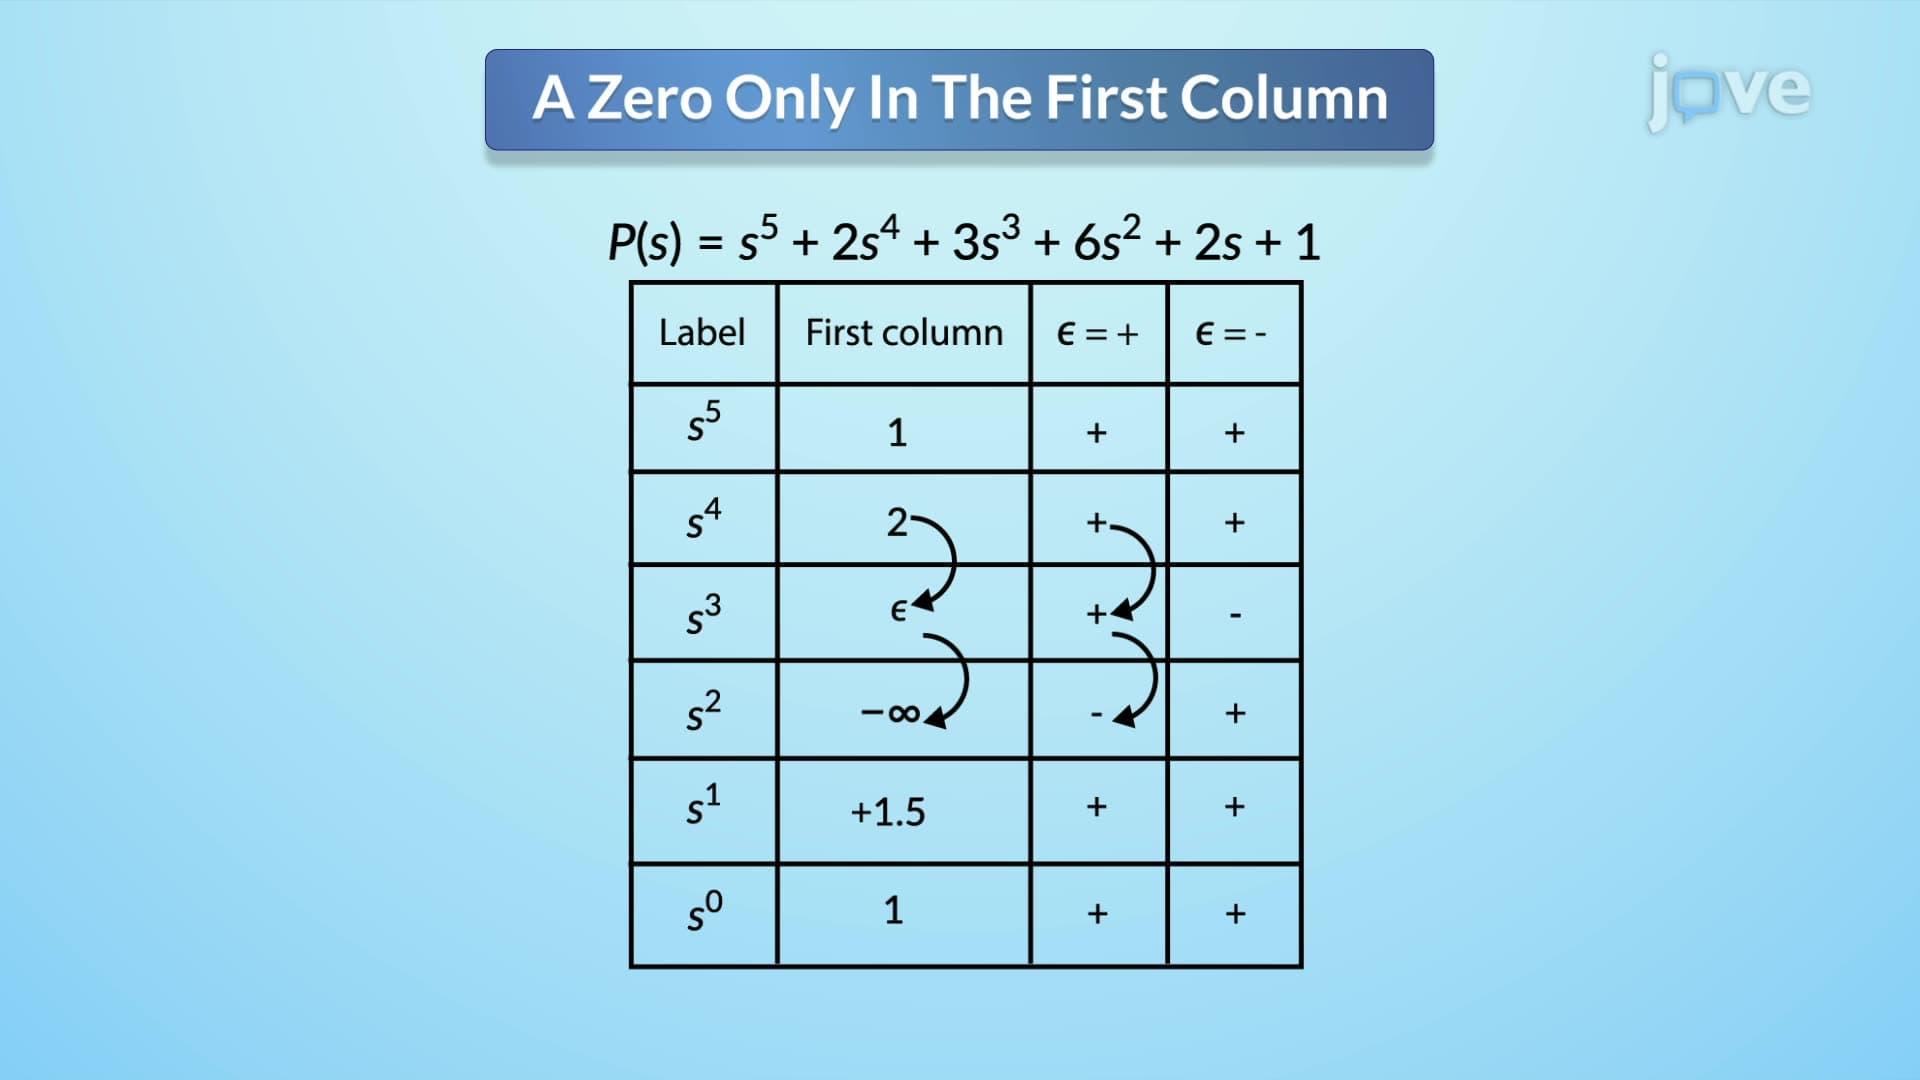
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
 01:15
Routh-Hurwitz Criterion I
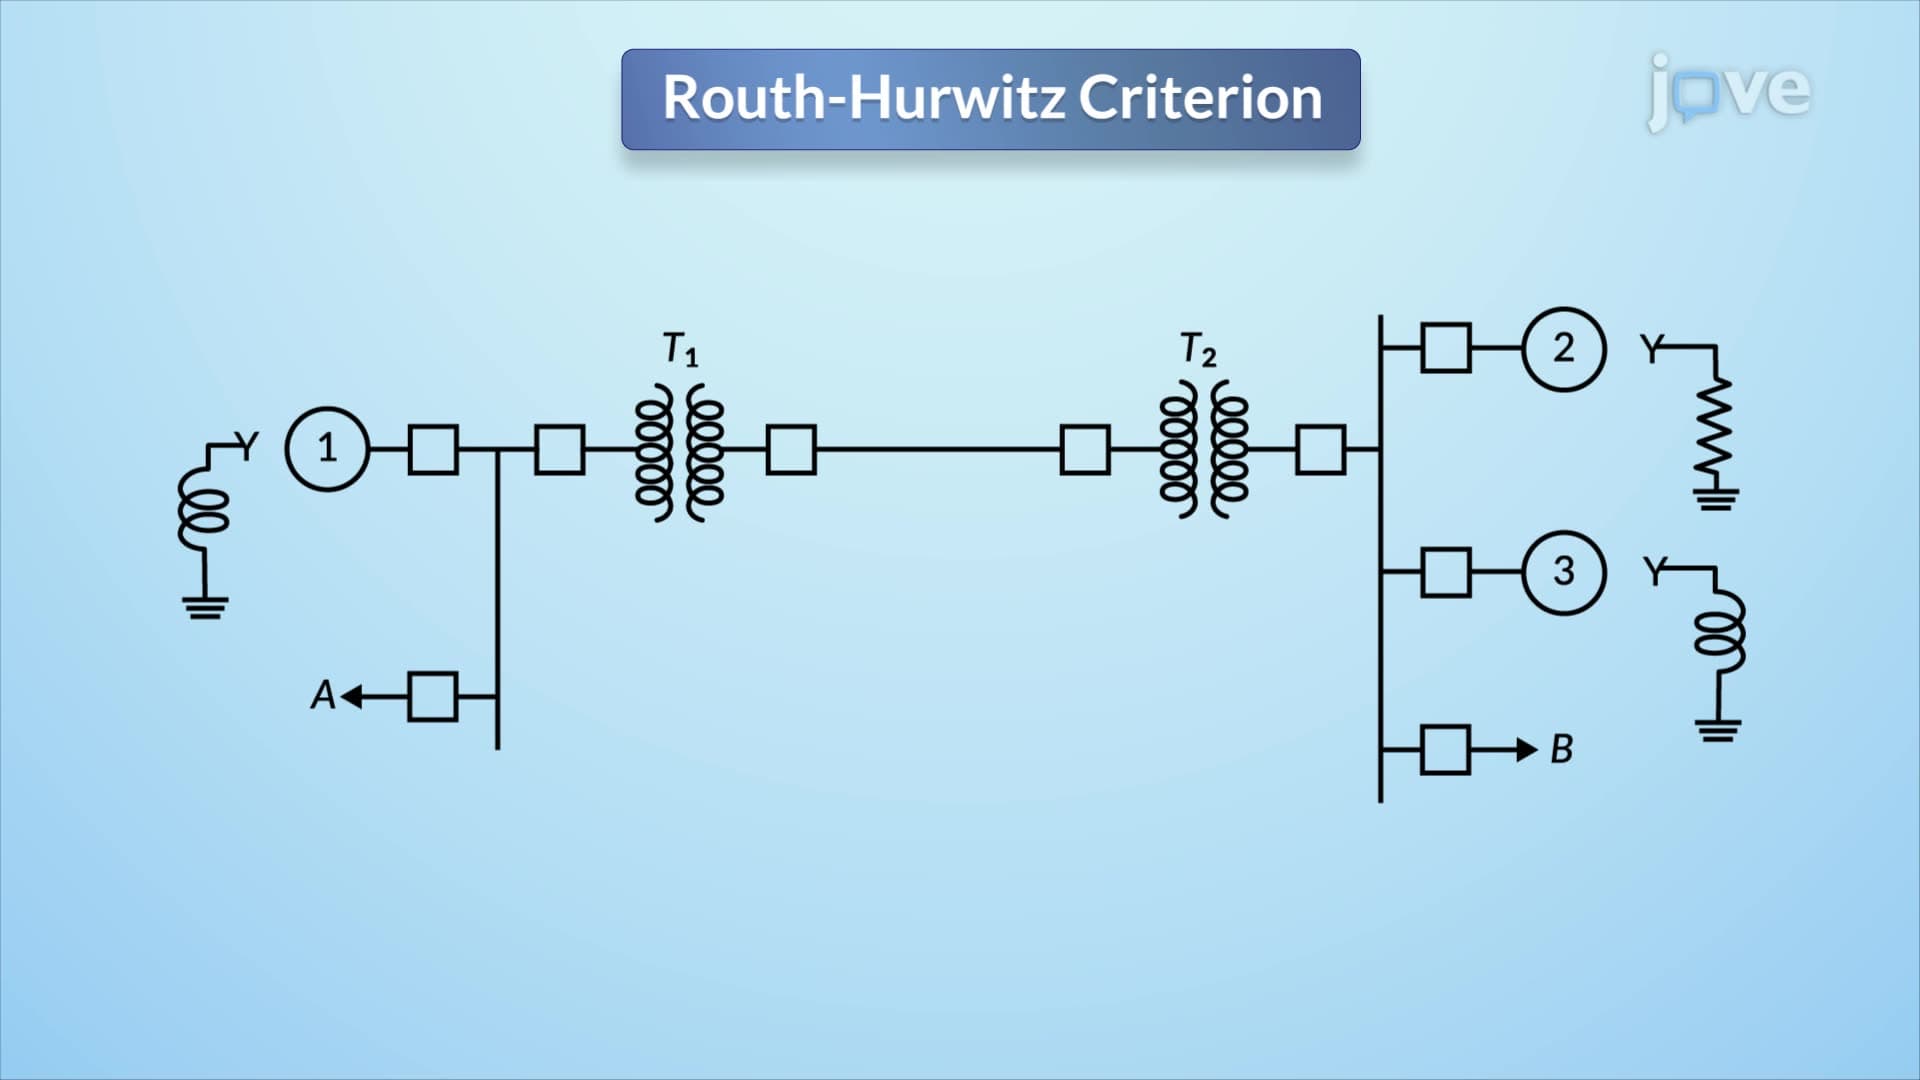
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...