Interaction of first- and second-order direction in motion-defined motion
Related Experiment Video
Updated: Oct 4, 2026
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
1Department of Psychology, Royal Holloway University of London, Egham, Surrey, England. J.Zanker@rhul.ac.uk

Abstract:
Motion-defined motion can play a special role in the discussion of whether one or two separate systems are required to process first- and second-order information because, in contrast to other second-order stimuli, such as contrast-modulated contours, motion detection cannot be explained by a simple input nonlinearity but requires preprocessing by motion detectors. Furthermore, the perceptual quality that defines an object (motion on the object surface) is identical to that which is attributed to the object as an emergent feature (motion of the object), raising the question of how these two object properties are linked. The interaction of first- and second-order information in such stimuli has been analyzed previously in a direction-discrimination task, revealing some cooperativity. Because any comprehensive integration of these two types of motion information should be reflected in the most fundamental property of a moving object, i.e., the direction in which it moves, we now investigate how motion direction is estimated in motion-defined objects. Observers had to report the direction of moving objects that were defined by luminance contrast or in random-dot kinematograms by differences in the spatiotemporal properties between the object region and the random-noise background. When the dots were moving coherently with the object (Fourier motion), direction sensitivity resembled that for luminance-defined objects, but performance deteriorated when the dots in the object region were static (drift-balanced motion). When the dots on the object surface were moving diagonally relative to the object direction (theta motion), the general level of accuracy declined further, and the perceived direction was intermediate between the veridical object motion direction and the direction of dot motion, indicating that the first- and second-order velocity vectors are somehow pooled. The inability to separate first- and second-order directional information suggests that the two corresponding subsystems of motion processing are not producing independent percepts and provides clues for possible implementations of the two-layer motion-processing network.
Related Concept Videos
 01:21
Equations of Motion: Rectangular Coordinates and Cylindrical Coordinates
When a particle moves relative to an inertial frame, the equations of motion can be expressed using rectangular components. If the motion is confined to the x-y plane, the equations having the x and y coordinates only can be used to simplify the mathematical representation.
However, when particles...
 01:10
Relative Velocity in One Dimension
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:18
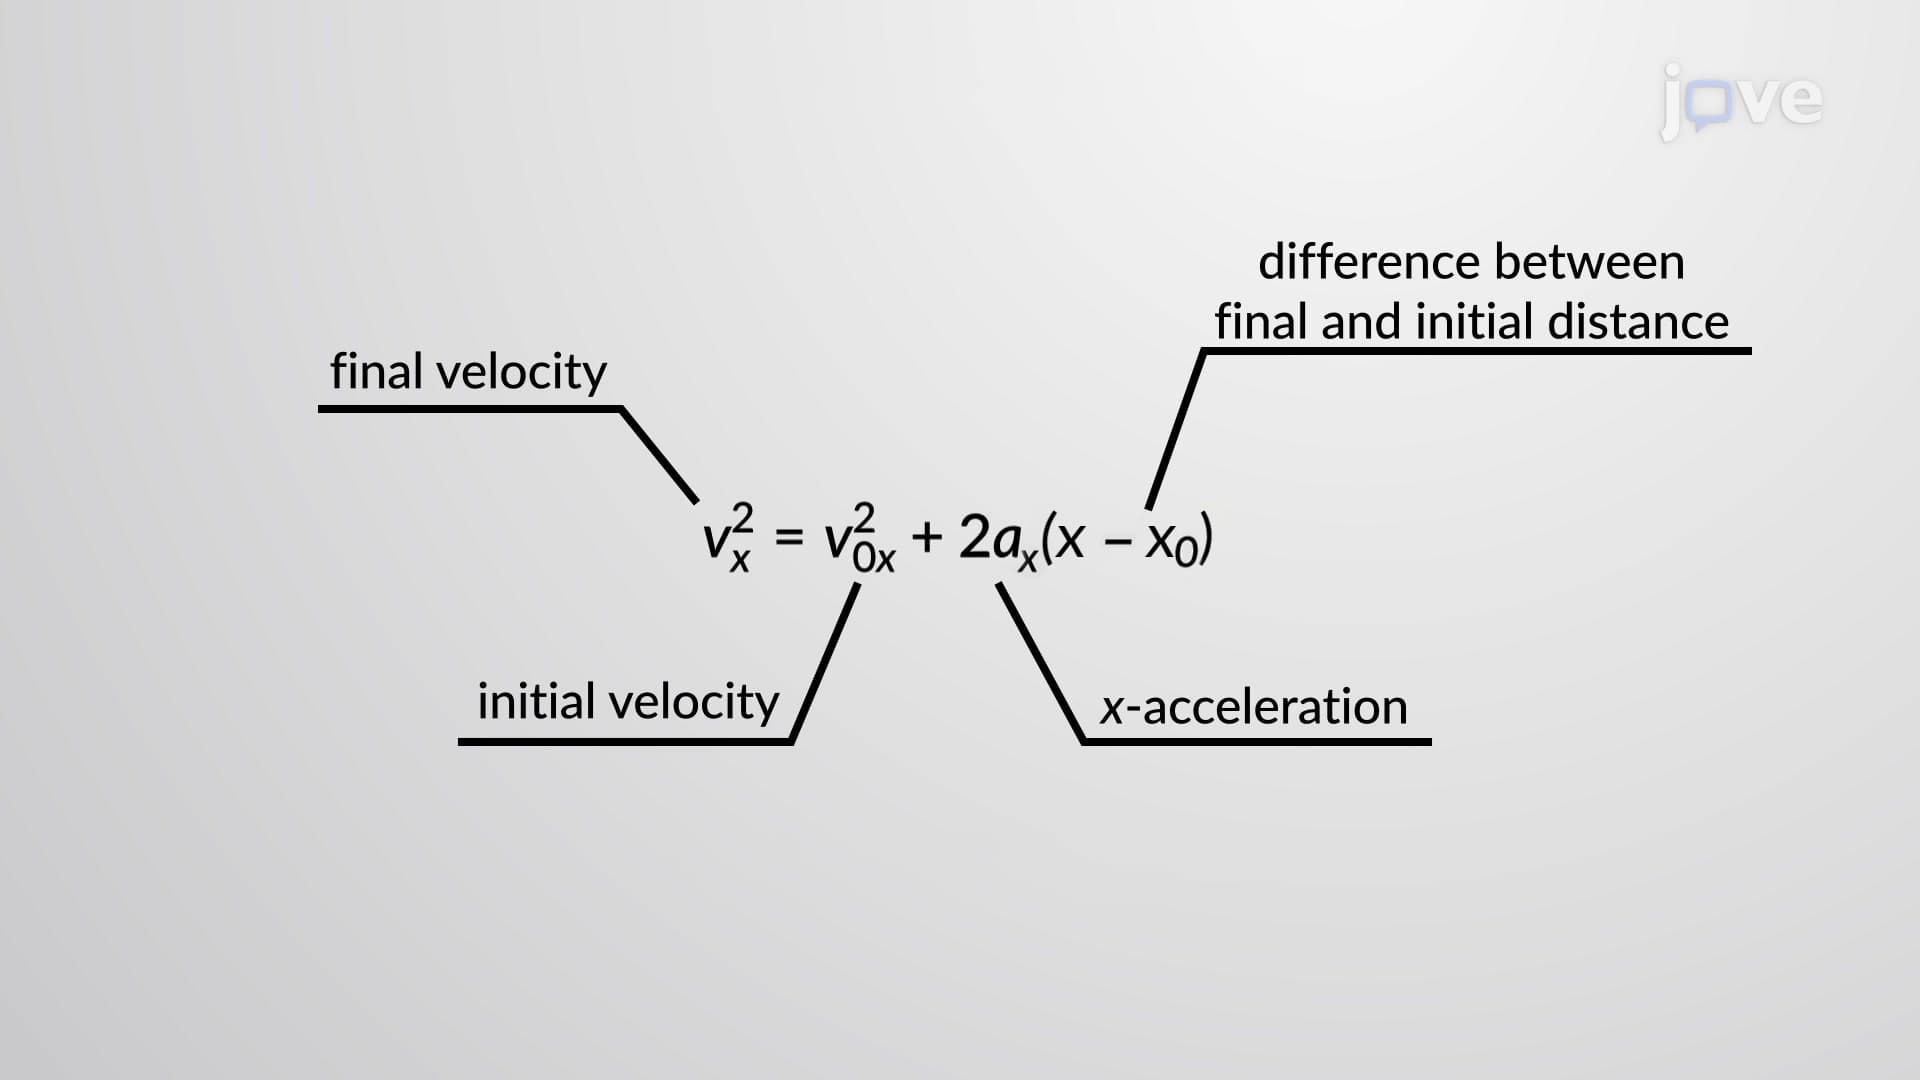
Kinematic Equations - III
Using the kinematic equations,...
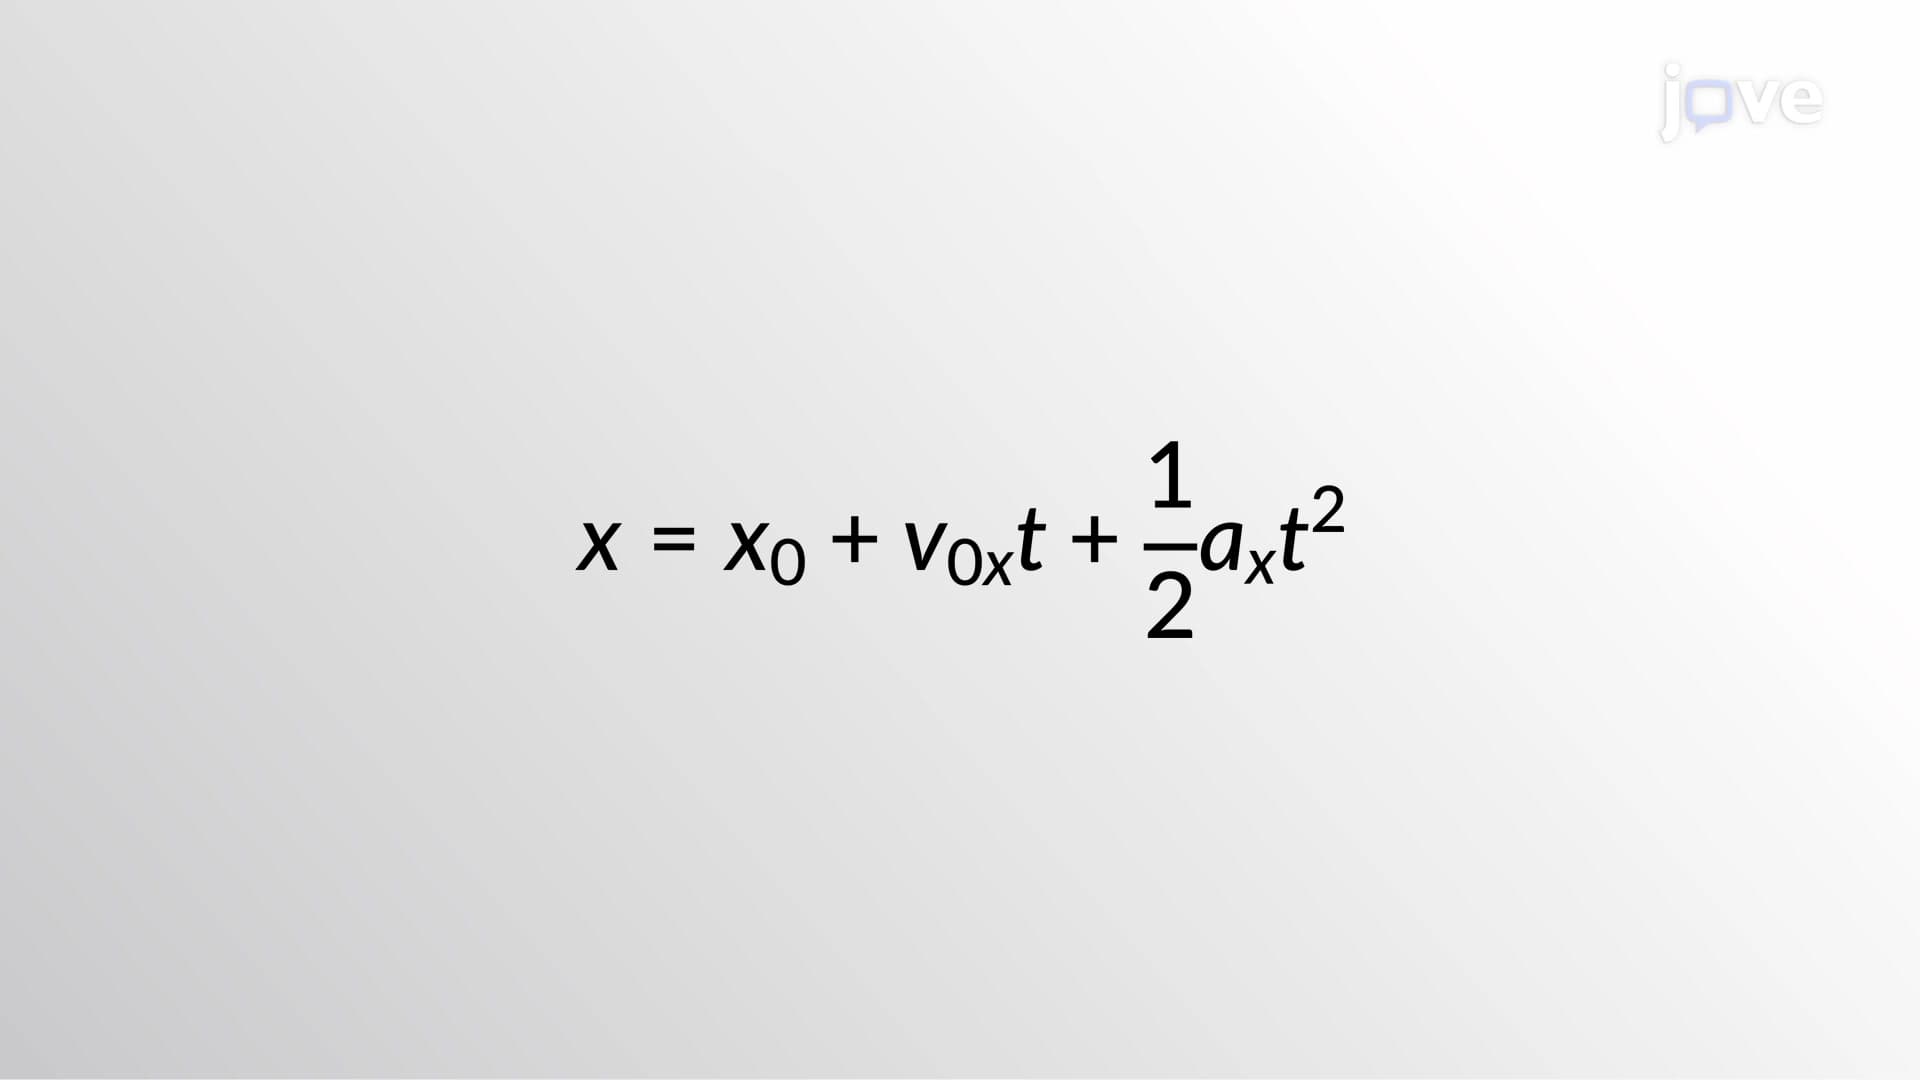 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:17
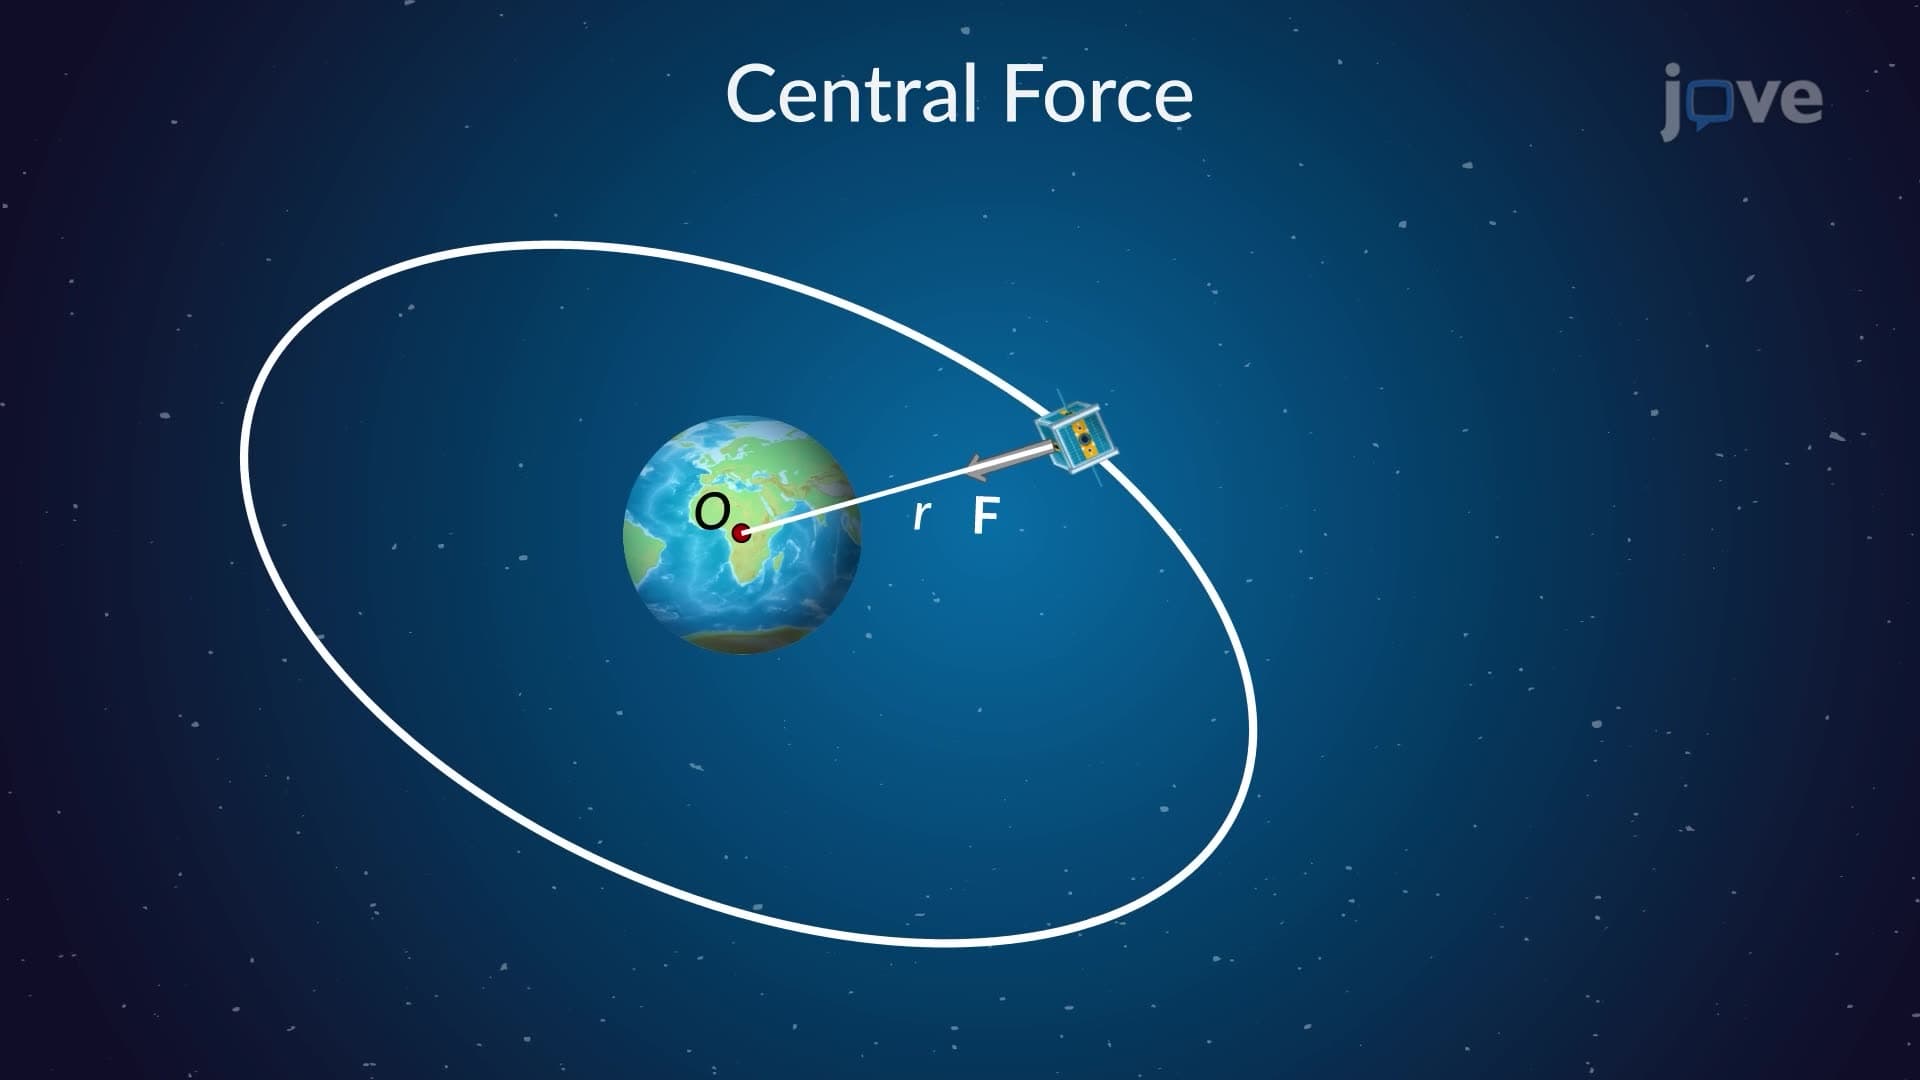
Central-Force Motion