A vector-integration-to-endpoint model for performance of viapoint movements
Related Experiment Video
Updated: Aug 11, 2026
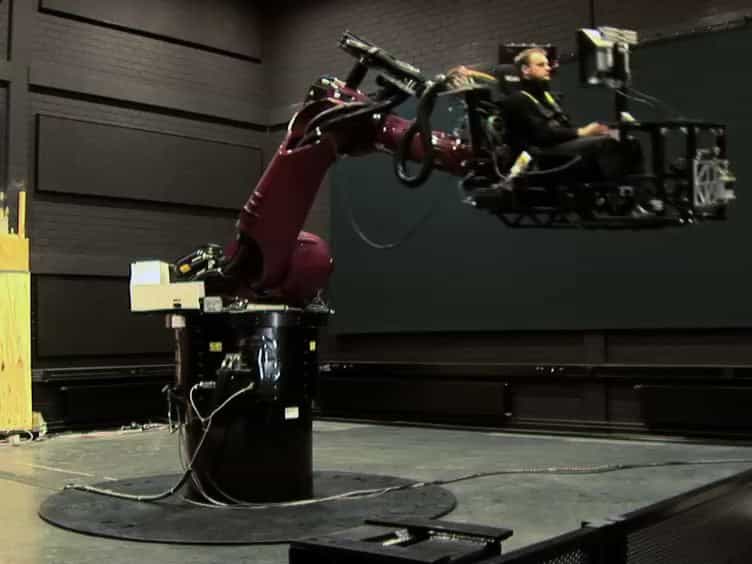
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Daniel Bullock1, Raoul M. Bongers, Marnix Lankhorst
1Department of Cognitive and Neural Systems, Boston University, 677 Beacon Street, Boston, USA

Abstract:
Viapoint (VP) movements are movements to a desired point that are constrained to pass through an intermediate point. Studies have shown that VP movements possess properties, such as smooth curvature around the VP, that are not explicable by treating VP movements as strict concatenations of simpler point-to-point (PTP) movements. Such properties have led some theorists to propose whole-trajectory optimization models, which imply that the entire trajectory is precomputed before movement initiation. This paper reports new experiments conducted to systematically compare VP with PTP trajectories. Analyses revealed a statistically significant early directional deviation in VP movements but no associated curvature change. An explanation of this effect is offered by extending the vector-integration-to-endpoint (VITE) model (Bullock, D., & Grossberg, S. (1988a). Neural dynamics of planned arm movements: Emergent invariants and speed-accuracy properties during trajectory formation. Psychological Review, 95, 49-90; Bullock, D., & Grossberg, S. (1988b). The VITE model: A neural command circuit for generating arm and articulator trajectories. In J.A.S. Kelso, A.J. Mandell & M.F. Schlesinger (Eds.), Dynamic patterns in complex systems (pp. 305-326). Singapore: World Scientific Publishers.), which postulates that voluntary movement trajectories emerge as internal gating signals control the integration of continuously computed vector commands based on the evolving, perceptible difference between desired and actual position variables. The model explains the observed trajectories of VP and PTP movements as emergent properties of a dynamical system that does not precompute entire trajectories before movement initiation. The new model includes a working memory and a stage sensitive to time-to-contact information. These cooperate to control serial performance. The structural and functional relationships proposed in the model are consistent with available data on forebrain physiology and anatomy.
More Related Videos
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
 07:34
Utilizing vmTracking to Improve the Accuracy of Multi-Animal Pose Estimation in Rodent Social Behavior Studies
Published on: November 7, 2025
Related Concept Videos
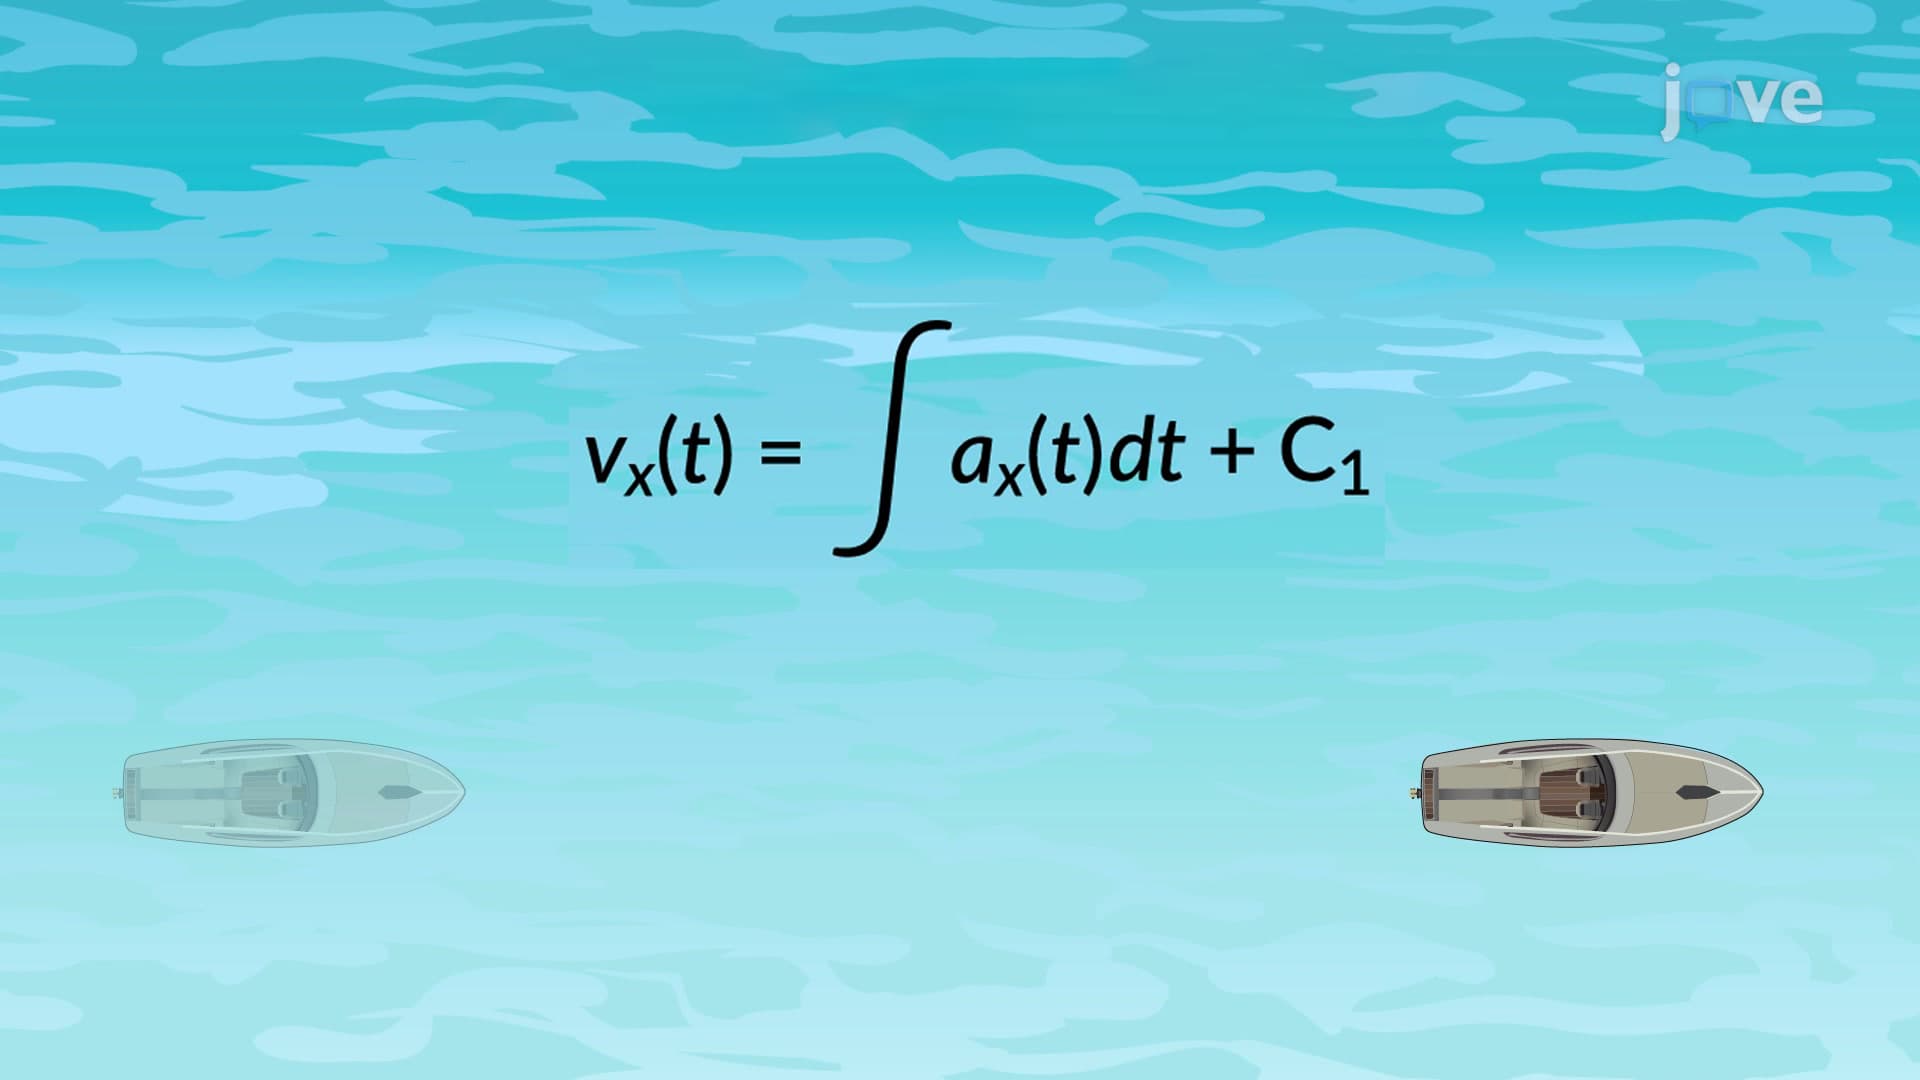 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:00
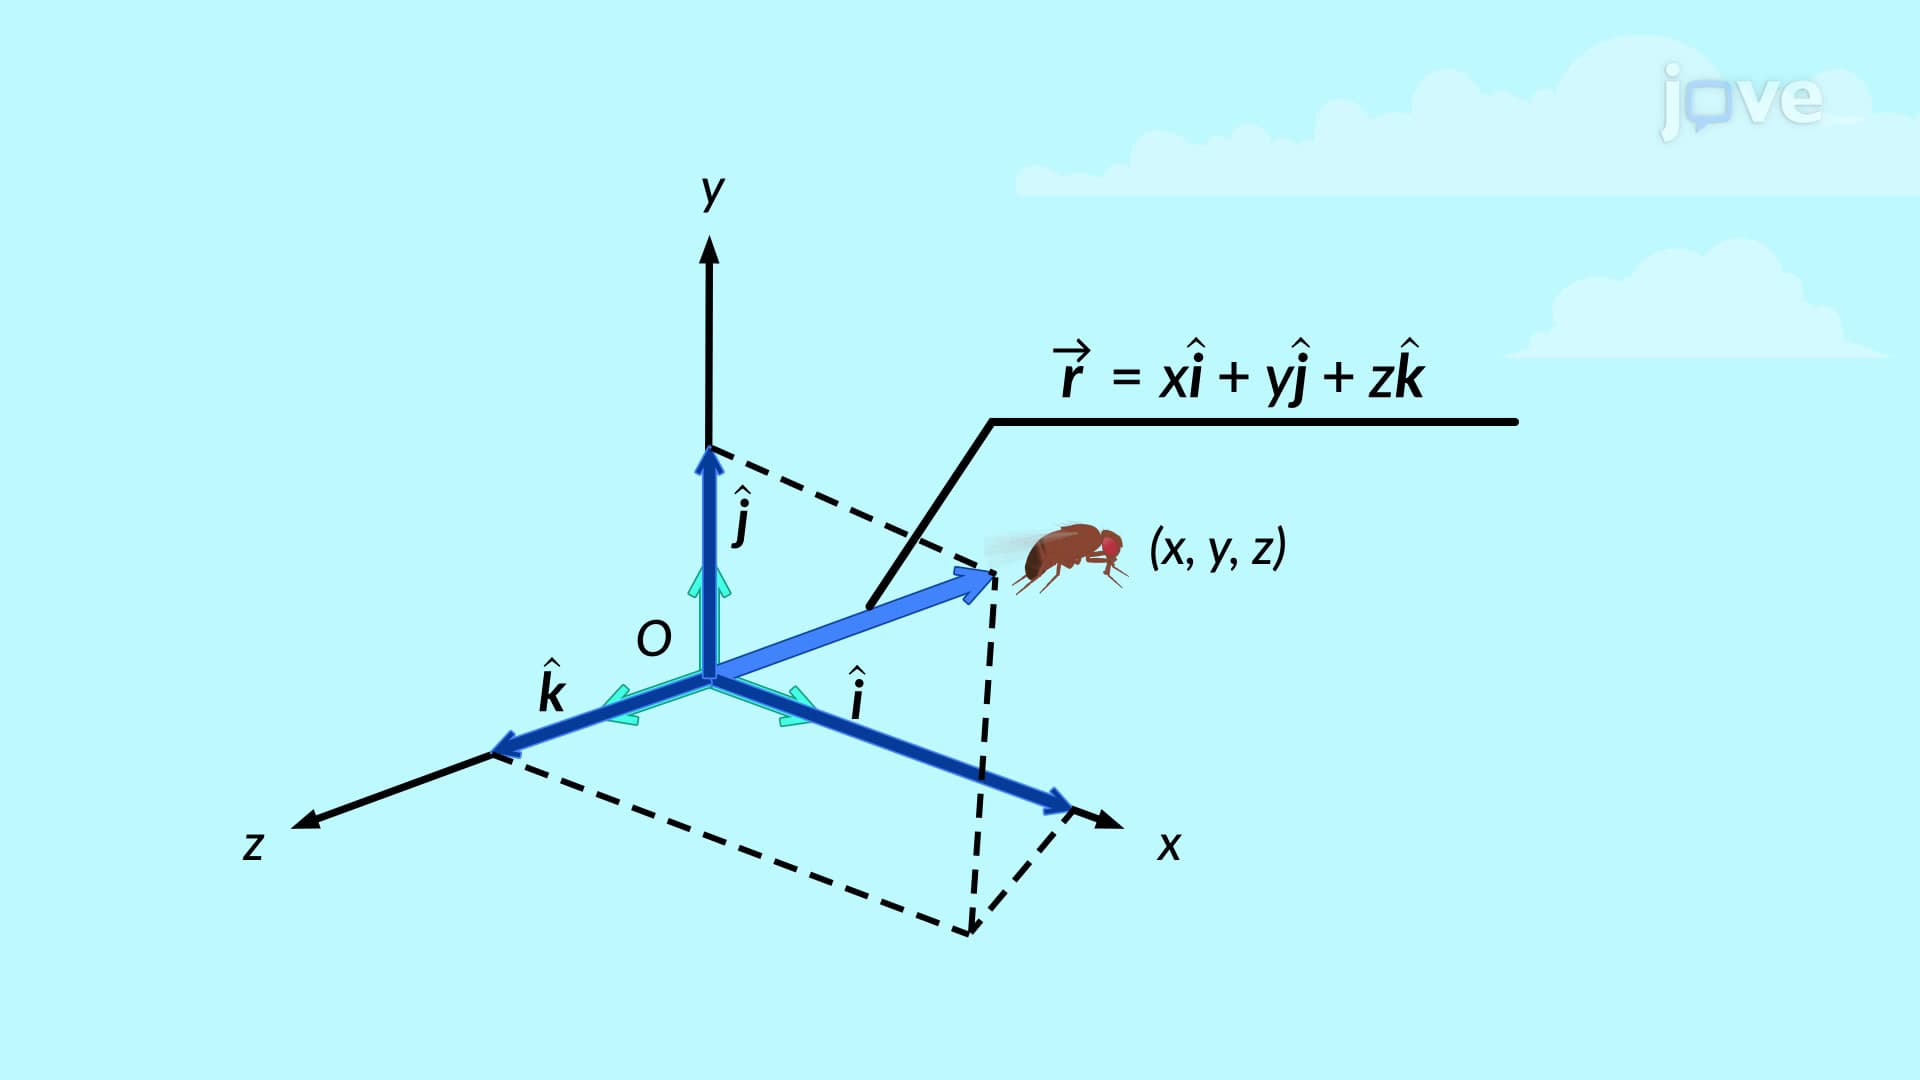
Position and Displacement Vectors
Further, several important kinds of...
 01:29
Position Vectors
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...
 01:16
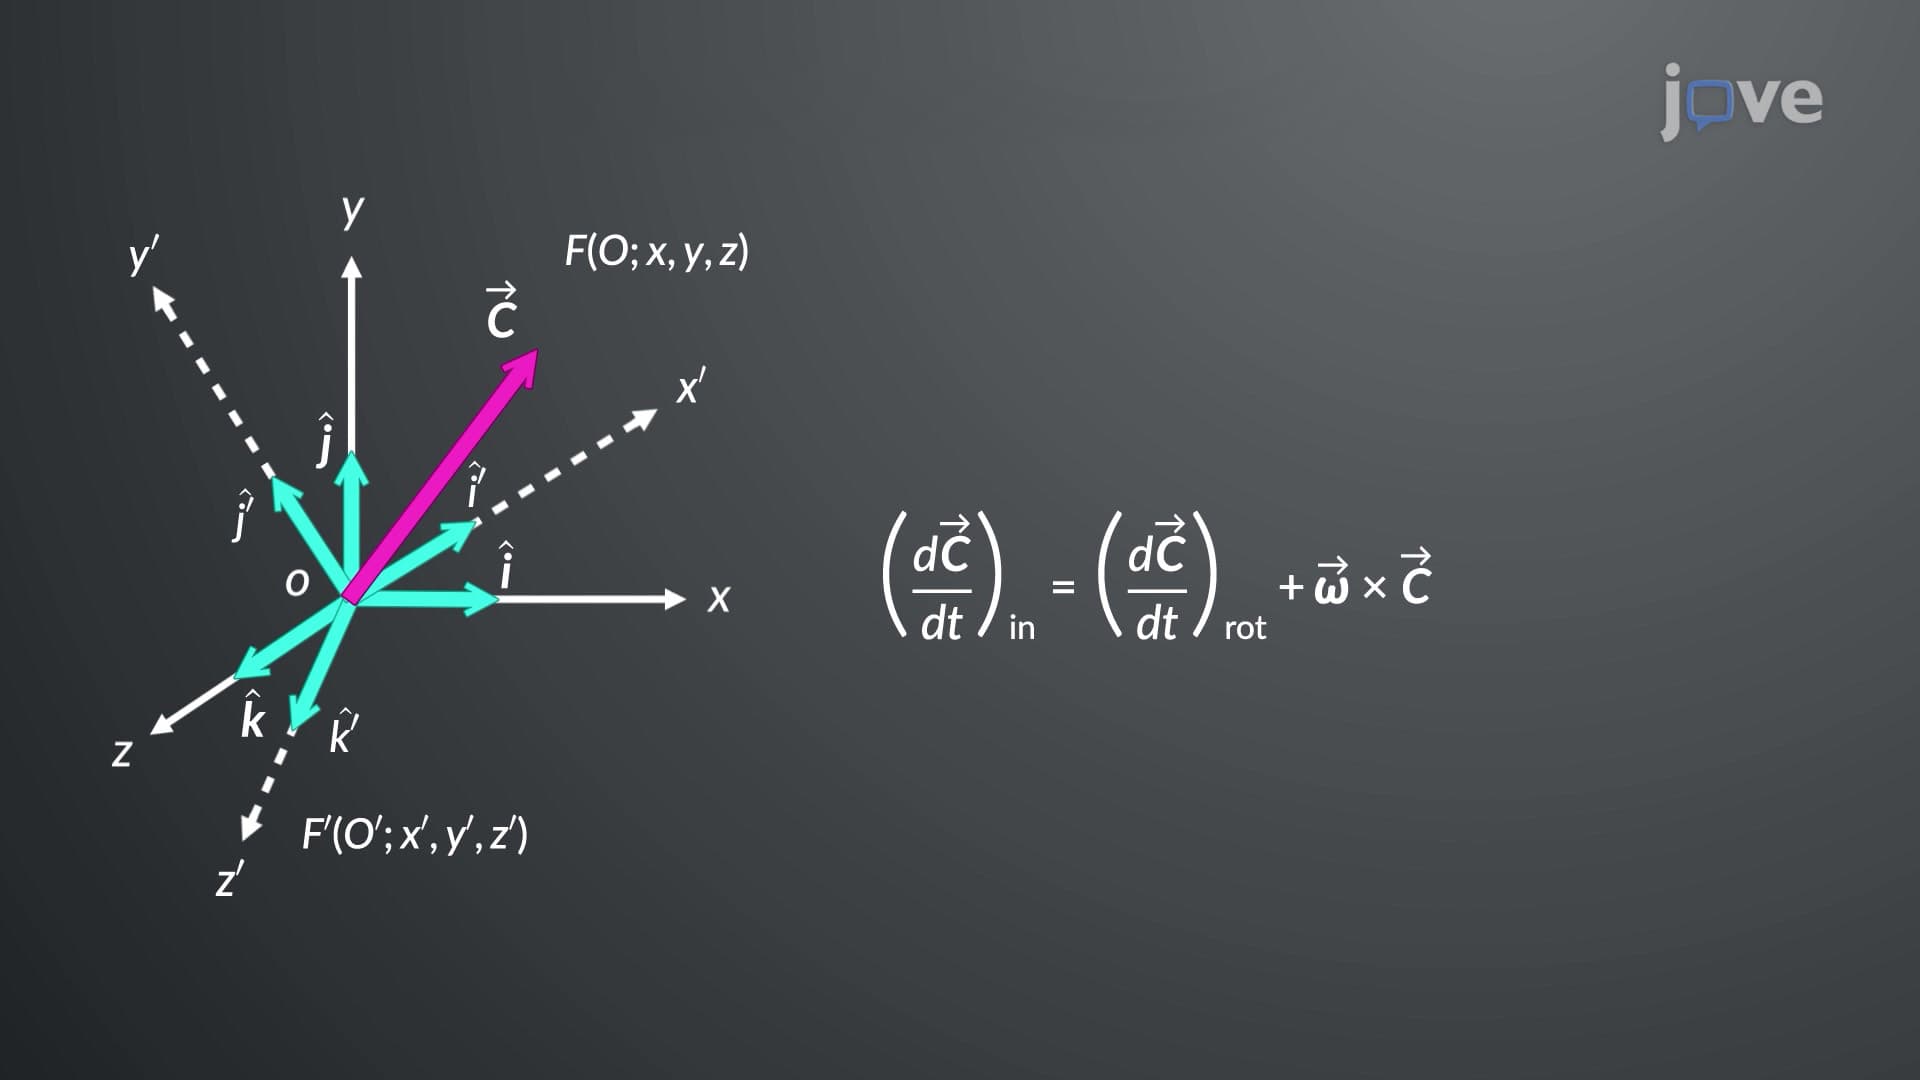
Vector Transformation in Rotating Coordinate Systems
 01:23
Integrals of Vector Functions
 01:30
Vector Functions and Motion: Problem Solving