Related Experiment Video
Updated: Sep 23, 2026
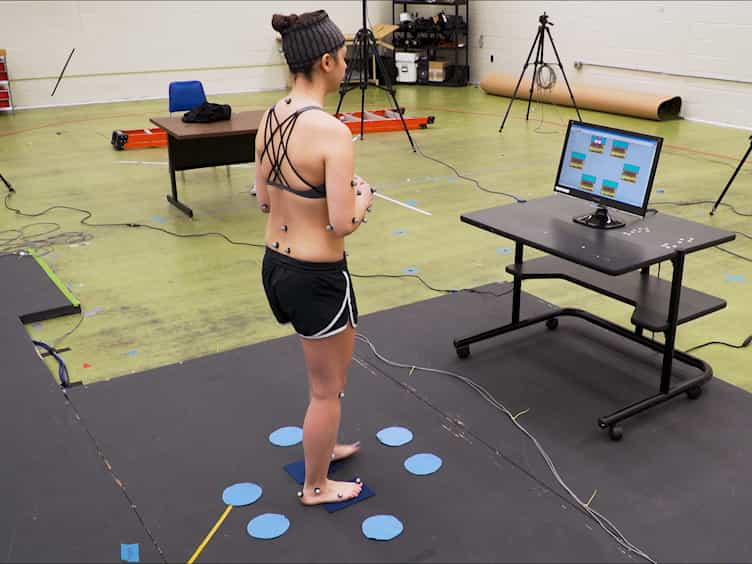

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Sequence, time, or state representation: how does the motor control system adapt to variable environments?
Amir Karniel1, Ferdinando A Mussa-Ivaldi
1Department of Electrical Engineering, Technion - Israel Institute of Technology, Haifa 32000, Israel. karniel@ee.technion.ac.il

Abstract:
Does the observation of well-timed movements imply the existence of some internal representation of time, such as a hypothetical neural clock? Here we report the results of experiments designed to investigate whether subjects form a correct adaptive representation of mechanical environments that change in a very predictable manner. In these experiments, subjects were asked to execute arm movements over a two-dimensional workspace while experiencing time-dependent disturbing forces. We provide a formal definition for time representation and conclude that our subjects didn't use time representation for motor adaptation under the tested conditions. Subjects performed arm-reaching movements in the following experiments: (1) six experiments in a sinusoidal time-varying force field; (2) six experiments in a simple sequence of alternating viscous force fields, in which the number of targets allowed for the approximation of the force by a complex state-dependent force field; and (3) six experiments in the same simple sequence of alternating viscous force fields, in which no state-dependent force field approximation was possible. We found that the subjects did not adapt to the time-varying force field and were unable to form an adequate representation of the simple sequence of force fields. In the latter case, whenever possible, they adapted to a single state-dependent field that produced forces similar to the two alternating fields. This state-dependent field produced the same forces as the applied sequence of fields only over the trajectories that subjects executed during the training phase. However, the state-dependent field was inadequate to produce the correct forces generated by the field sequence over a new set of trajectories.These results are not consistent with the hypothesis that subjects would develop a correct representation of time-dependent forces, at least under the tested circumstances. We speculate that the system responsible for adaptation of movements to external forces may be unable to employ temporal representation. While it is possible that such a representation may emerge in a more prolonged and/or intense training, our findings indicate a preference by the adaptive system to generalize based on representing dependence of external forces upon state rather than upon time.

Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:31
Classification of Systems-II
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...