Related Experiment Video
Updated: Aug 26, 2026

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Digital redesign of analog smith predictor for systems with input time delays
Alex C Dunn1, Leang-San Shieh, Shu-Mei Guo
1Department of Electrical and Computer Engineering, University of Houston, Houston, TX 77204-4005, USA.

Abstract:
This paper presents a new methodology for digitally redesigning an existing analog Smith predictor control system, such that the cascaded analog controller with input delay can be implemented with a digital controller. A traditional analog Smith predictor system is reformulated into an augmented system, which is then digitally redesigned using the predicted intersampling states. The paper extends the prediction-based digital redesign method from a delay free feedback system to an input time-delay cascaded system. A tuning parameter v is optimally determined online such that in any sampling period, the output response error between the original analogously controlled time-delay system and the digitally controlled sampled-data time-delay system is significantly reduced. The proposed method gives very good performance in dealing with systems with delays in excess of several integer sampling periods and shows good robustness to sampling period selection.

Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:31
Classification of Systems-II
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
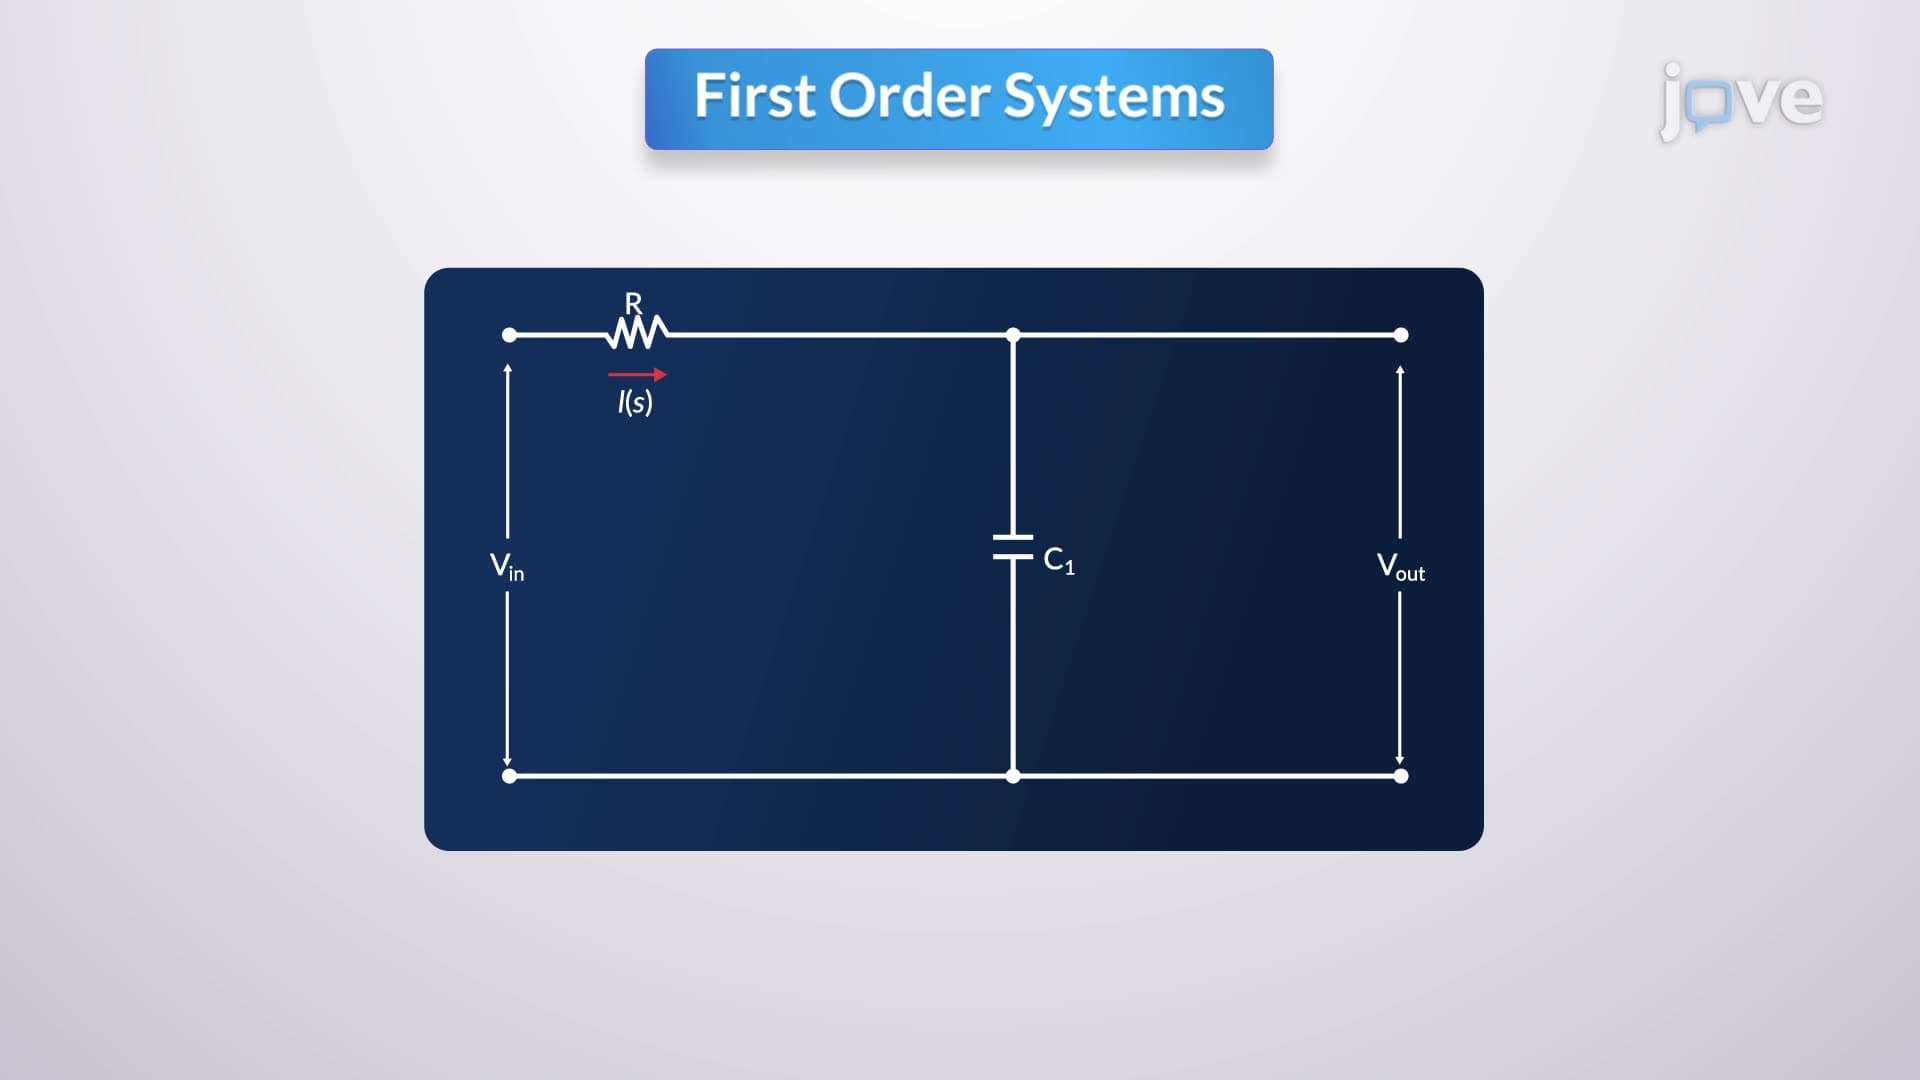
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:18
Second Order systems II
If ζ...
 01:10
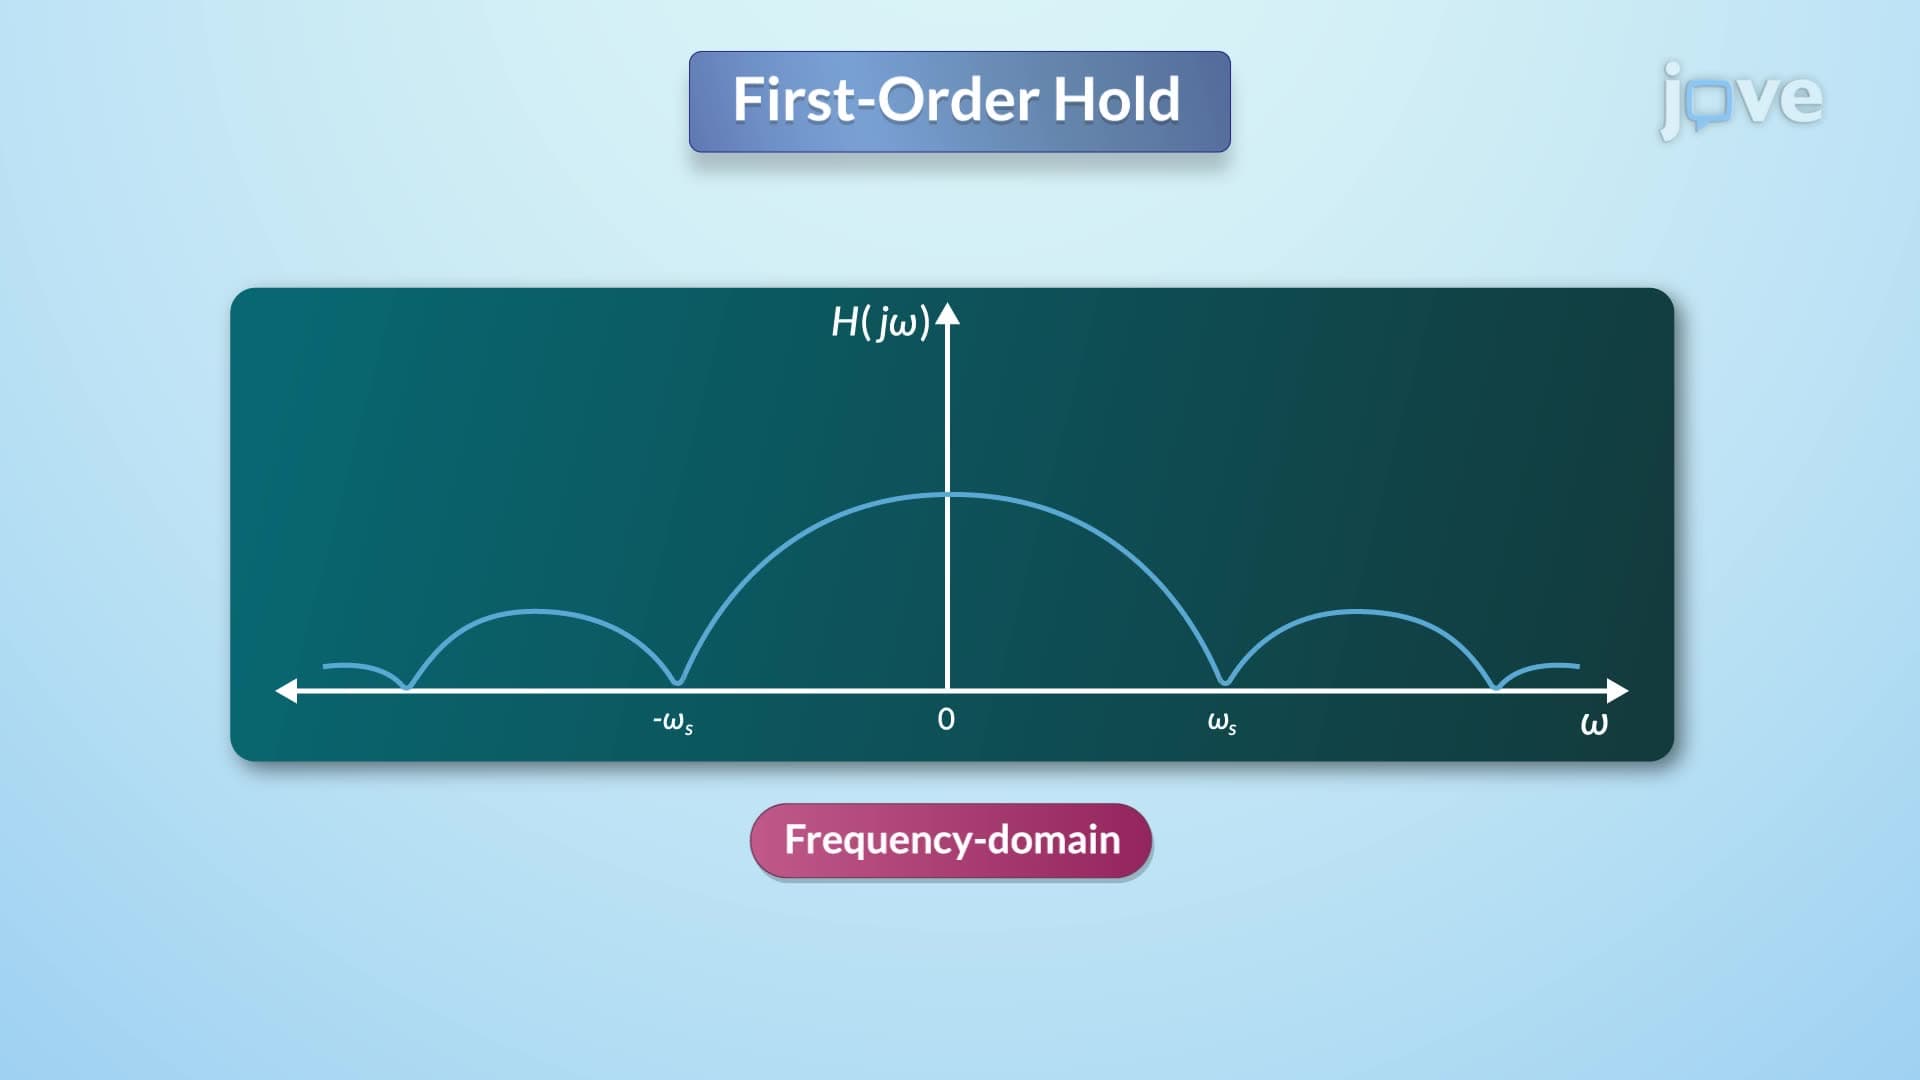
Reconstruction of Signal using Interpolation