Related Experiment Video
Updated: Aug 23, 2026
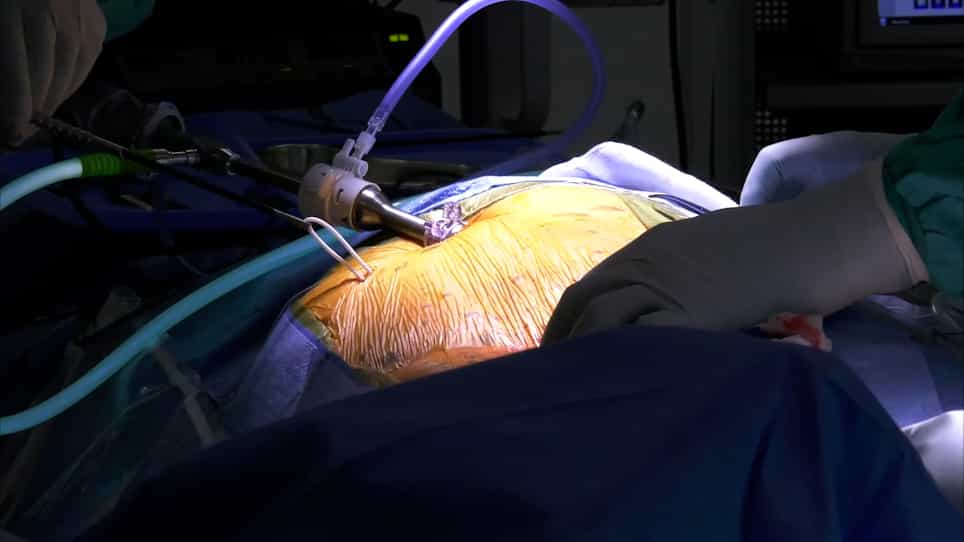

Neuronavigation and Laparoscopy Guided Ventriculoperitoneal Shunt Insertion for the Treatment of Hydrocephalus
Published on: October 14, 2022
Robot-assisted navigated endoscopic ventriculostomy: implementation of a new technology and first clinical results
M Zimmermann1, R Krishnan, A Raabe
1Department of Neurosurgery, Johann Wolfgang Goethe-University, Frankfurt am Main, Germany. Michael.Zimmerman@em.uni-frankfurt.de

Background:
Important landmarks in the evolution of advanced neurosurgical techniques during the past decades include microneurosurgery, neuro-endoscopy and its minimally invasive nature, as well as neuronavigation and advanced intra-operative imaging. With conventional neuroendoscopic techniques, e.g. free-hand endoscopy or the use of mechanical or pneumatic holding devices, a definitive and controlled movement of the endoscope within the brain does depend on the experience and manual skill of the individual neurosurgeon. Therefore, the development of robotic systems to assist surgeons in performing complex neurosurgical procedures is a growing field of interest.
Method:
With the precision robot "Evolution 1" (U.R.S. Universal Robot Systems, Schwerin, Germany) a new neurosurgical tool has just become available for the precise steering of instruments within the cranium. After preclinical anatomical as well as precision studies the system was used for robot-assisted navigated endoscopic third ventriculostomies in six patients with hydrocephalus related to aqueductal stenosis.
Findings:
All robot-assisted navigated endoscopic procedures were successfully completed. The time for the registration procedure and setup of the robot decreased from 60 min. for the first procedure down to 30 min. The time for the surgical part of the neuro-endoscopic procedure itself ranged from 17 to 35 min. During all procedures no system-related complications occurred.
Interpretation:
The use of robotic technology for neuro-endoscopic third ventriculostomies is a major step towards the controlled movement of the neuro-endoscope within the cranium. The start up procedure and calibration of the robot is still time consuming, but the real operation time is comparable to free hand neuro-endoscopy. The steering of the endoscope is facilitated and the precision of the endoscopic movements is noteworthy.