Related Experiment Video
Updated: Aug 21, 2026
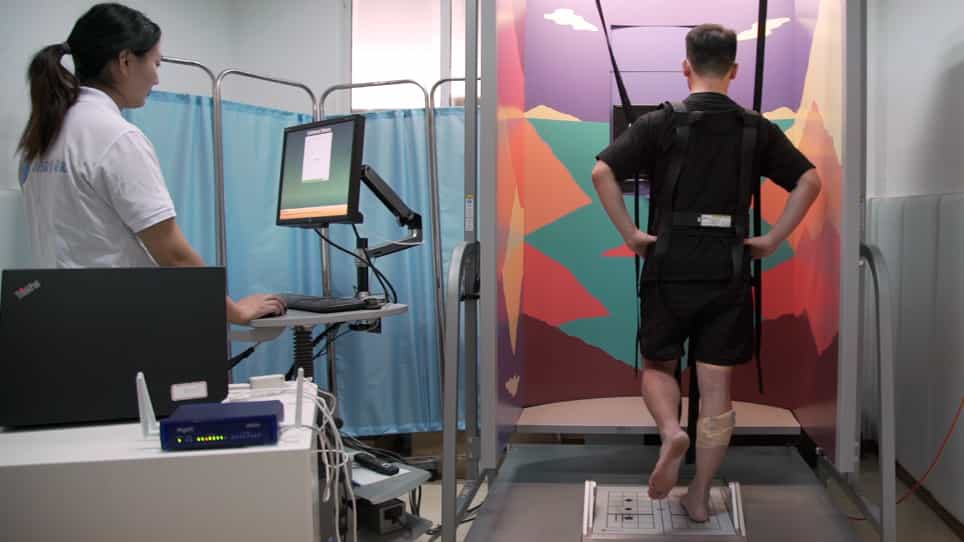
Evaluating Postural Control and Lower-extremity Muscle Activation in Individuals with Chronic Ankle Instability
Published on: September 18, 2020
The condition for dynamic stability
A L Hof1, M G J Gazendam, W E Sinke
1Institute of Human Movement Sciences, University of Groningen, University Hospital, PO BOX 196, AD Groningen 9700, The Netherlands. a.l.hof@med.rug.nl

Abstract:
The well-known condition for standing stability in static situations is that the vertical projection of the centre of mass (CoM) should be within the base of support (BoS). On the basis of a simple inverted pendulum model, an extension of this rule is proposed for dynamical situations: the position of (the vertical projection of) the CoM plus its velocity times a factor (square root l/g) should be within the BoS, l being leg length and g the acceleration of gravity. It is proposed to name this vector quantity 'extrapolated centre of mass position' (XcoM). The definition suggests as a measure of stability the 'margin of stability' b, the minimum distance from XcoM to the boundaries of the BoS. An alternative measure is the temporal stability margin tau, the time in which the boundary of the BoS would be reached without intervention. Some experimental data of subjects standing on one or two feet, flatfoot and tiptoe, are presented to give an idea of the usual ranges of these margins of stability. Example data on walking are also presented.

Related Concept Videos
 01:14
Stability of structures
 01:28
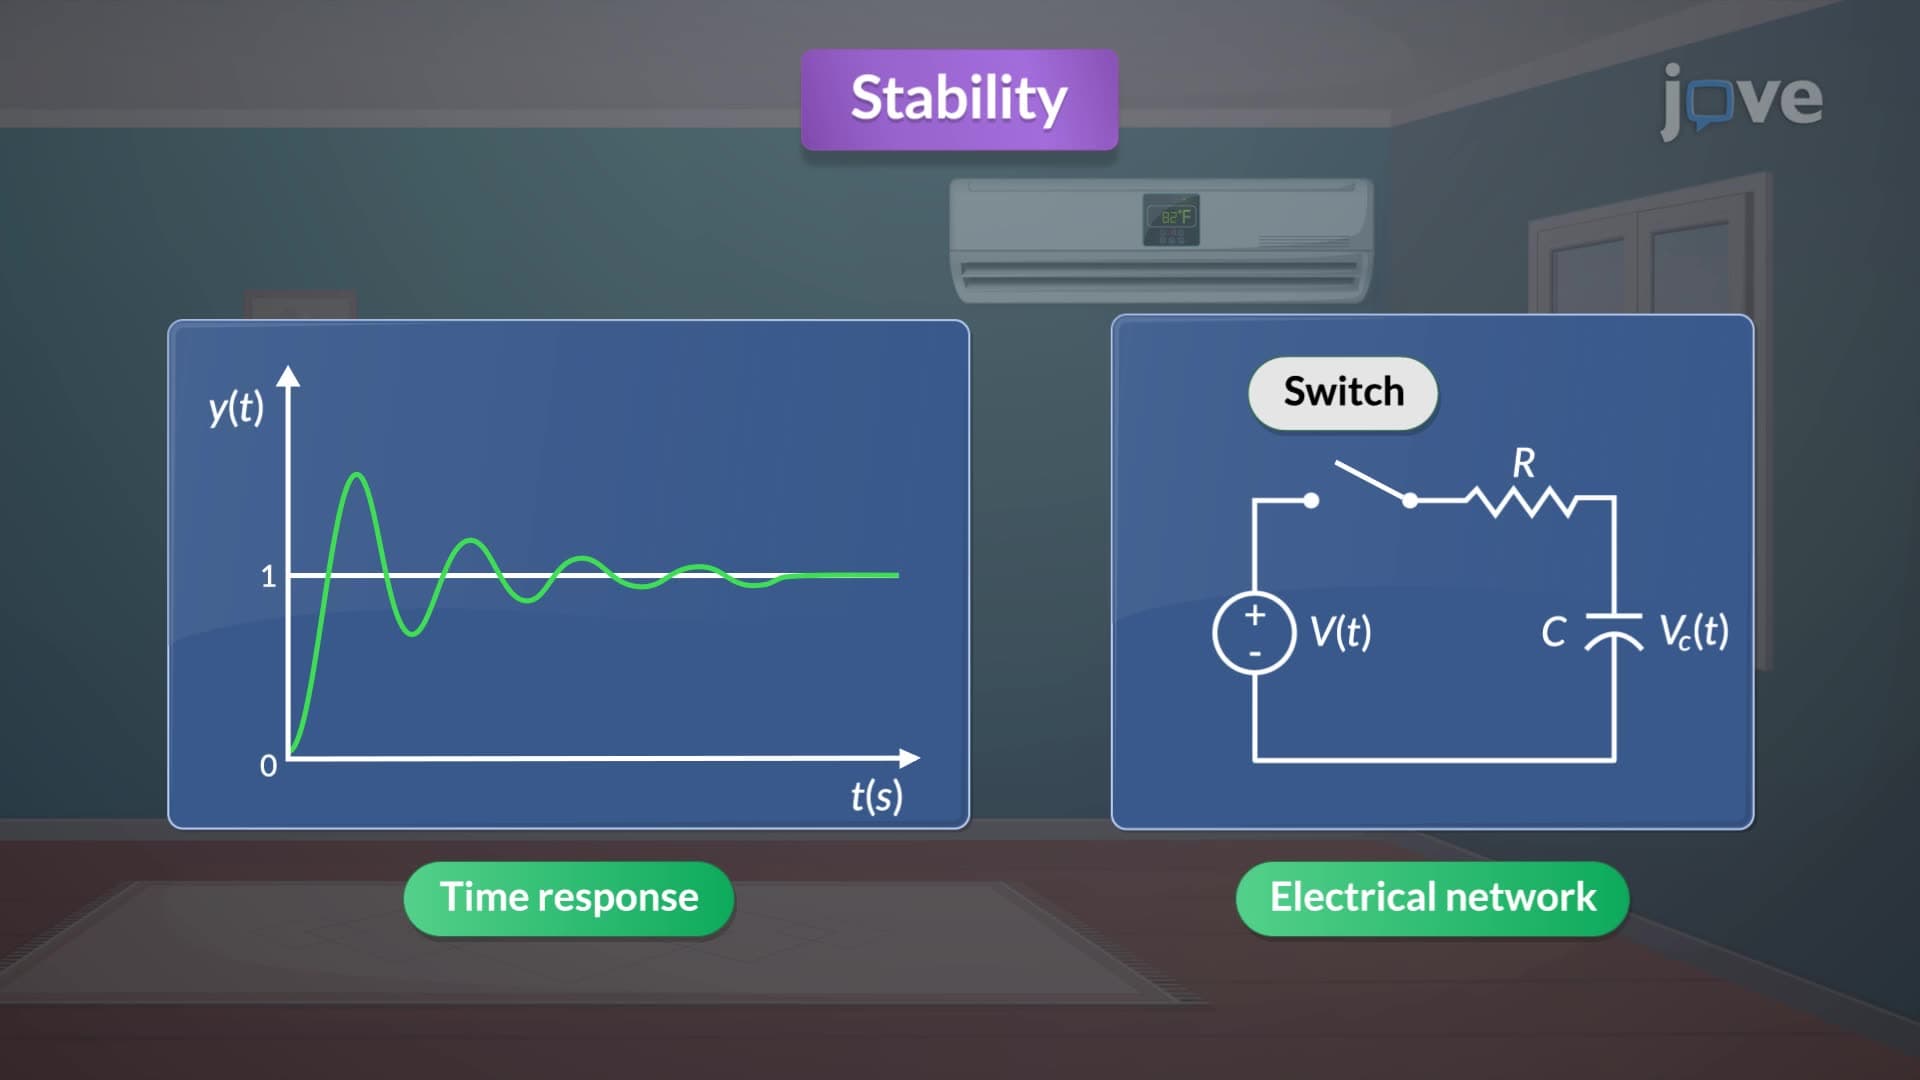
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:26
Constraints and Statical Determinacy
 01:07
Static Equilibrium - II
 01:05
Static Equilibrium - I
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...