Perfectly matched layers as nonlinear coordinate transforms: a generalized formalization

Related Experiment Videos

Jean Paul Hugonin1, Philippe Lalanne

  • 1Laboratoire Charles Fabry de l'Institut d'Optique, Centre National de la Recherche Scientifique, F-91403 Orsay cedex, France. Jean-Paul.Hugonin@iota.u-psud.fr

Related Concept Videos

Linear Approximation in Frequency Domain01:26

Linear Approximation in Frequency Domain

Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
Linearization and Approximation01:26

Linearization and Approximation

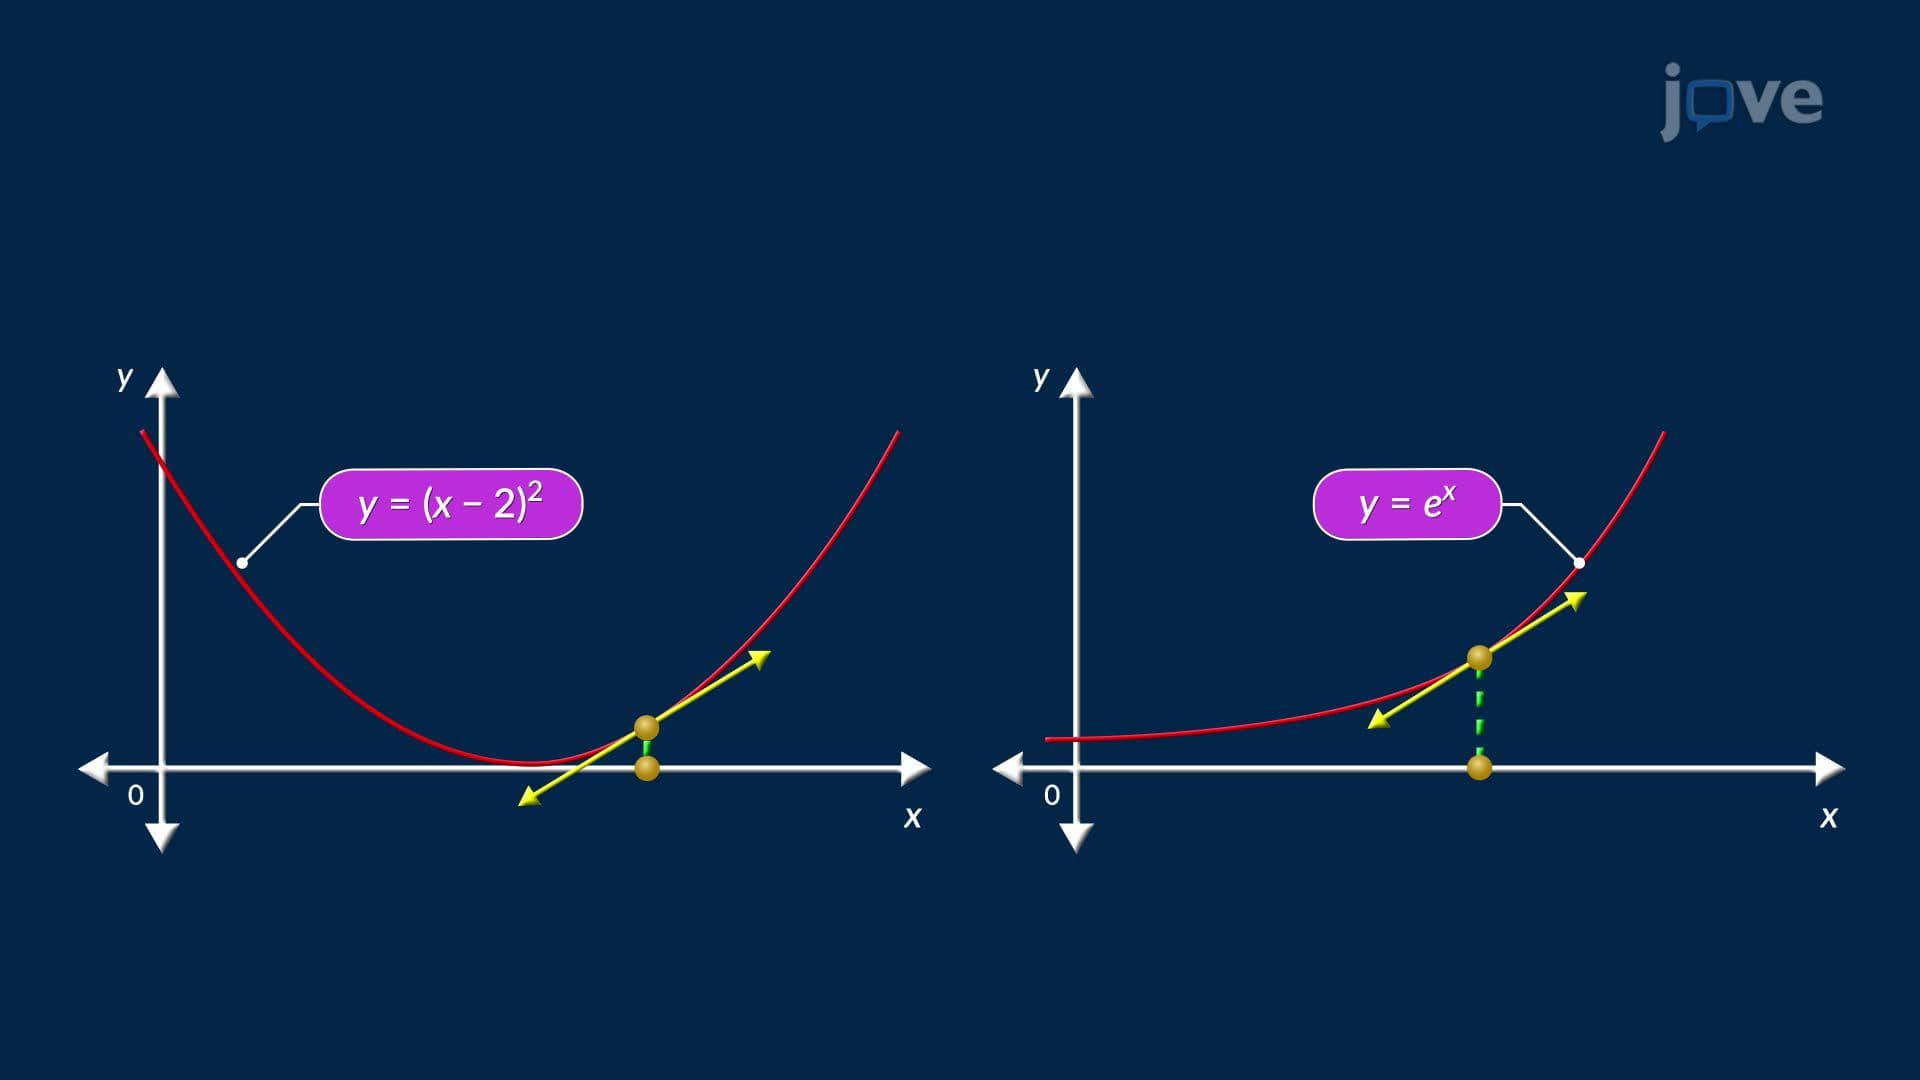
Linearization is a mathematical technique used to approximate complex, nonlinear functions with simpler linear models in the vicinity of a chosen reference point. The method is based on the idea that, although a function may be difficult to evaluate exactly, its behavior near a specific input value can often be closely approximated by the tangent line at that point. This approach is particularly useful when small deviations from a known value are involved.Consider the square root function, for...
Transformations of Functions II01:29

Transformations of Functions II

Transformations in mathematics alter the position or orientation of a function’s graph while preserving its fundamental shape. One important type of transformation is the horizontal shift, which involves modifying the input variable within a function’s equation. This operation affects where outputs occur along the horizontal axis but does not alter the function’s overall structure.A horizontal shift is achieved by replacing the input variable x with either x + c or x - c, where c is a constant.
Vector Transformation in Rotating Coordinate Systems01:16

Vector Transformation in Rotating Coordinate Systems
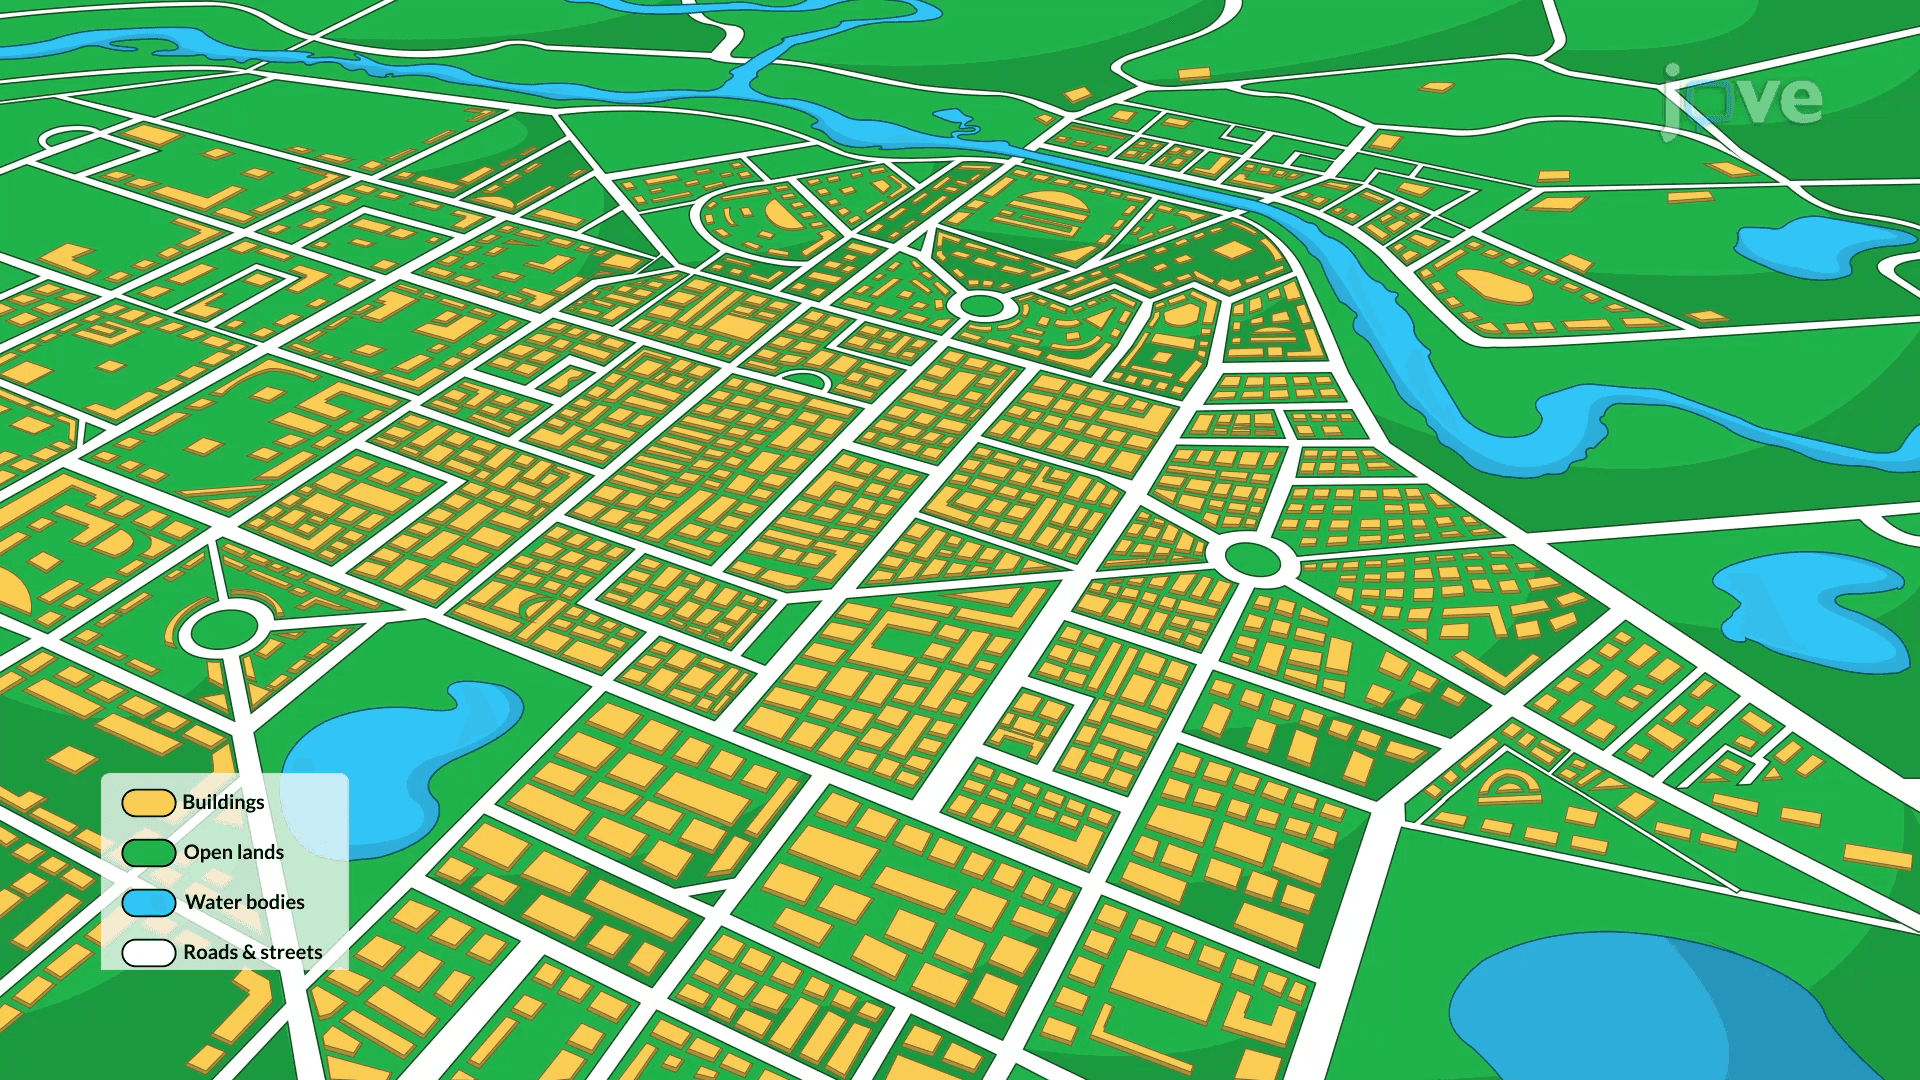
Consider a vector rotating about an axis with an angular velocity, such that its tip sweeps a circular path.
Linear Approximations01:23

Linear Approximations

For a differentiable function of two variables, linear approximation estimates values near a known point by replacing the curved surface with its tangent plane. Consider the function\begin{equation*}f(x,y)=x^2+3y^2\end{equation*}near the point (2, 1). The exact value at this point is f(2, 1) = 22 + 3(1)2 = 4 + 3 = 7.The linear approximation of f(x, y)) near (a, b) is\begin{equation*}L(x,y)=f(a,b)+f_x(a,b)(x-a)+f_y(a,b)(y-b)\end{equation*}First, compute the partial derivatives: fx(x, y) = 2x and...
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...