Characteristics of pixel arrangements in various rhombuses for full-parallax three-dimensional image generation

Jung-Young Son1, Vladmir V Saveljev, Kae-Dal Kwack

  • 1Whole Imaging Laboratory, Hanyang University, Seoul, South Korea.

Applied Optics
|April 25, 2006
PubMed

Related Concept Videos

Depth Perception and Spatial Vision01:15

Depth Perception and Spatial Vision
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
Lines in Space01:29

Lines in Space

In three-dimensional analytic geometry, a line can be fully described using vector equations when both a point on the line and its direction are known. This approach has practical applications in fields such as engineering and surveying, where precise spatial modeling is essential. For instance, a laser beam from a surveying instrument directed across a construction site can be modeled mathematically as a line using vectors.Let the laser beam originate from a known point P₀, represented by the...
Planes in Space01:31

Planes in Space

A plane in three-dimensional space is fundamentally characterized by a point that lies on the plane and a normal vector that is perpendicular to its surface. This normal vector uniquely determines the orientation of the plane, making it an essential geometric descriptor. In architectural applications, such as the installation of a sloped glass panel on a building façade, this mathematical model provides a precise representation of the panel’s position and orientation in space.Let r₀ be the...
Polar and Cylindrical Coordinates01:22

Polar and Cylindrical Coordinates
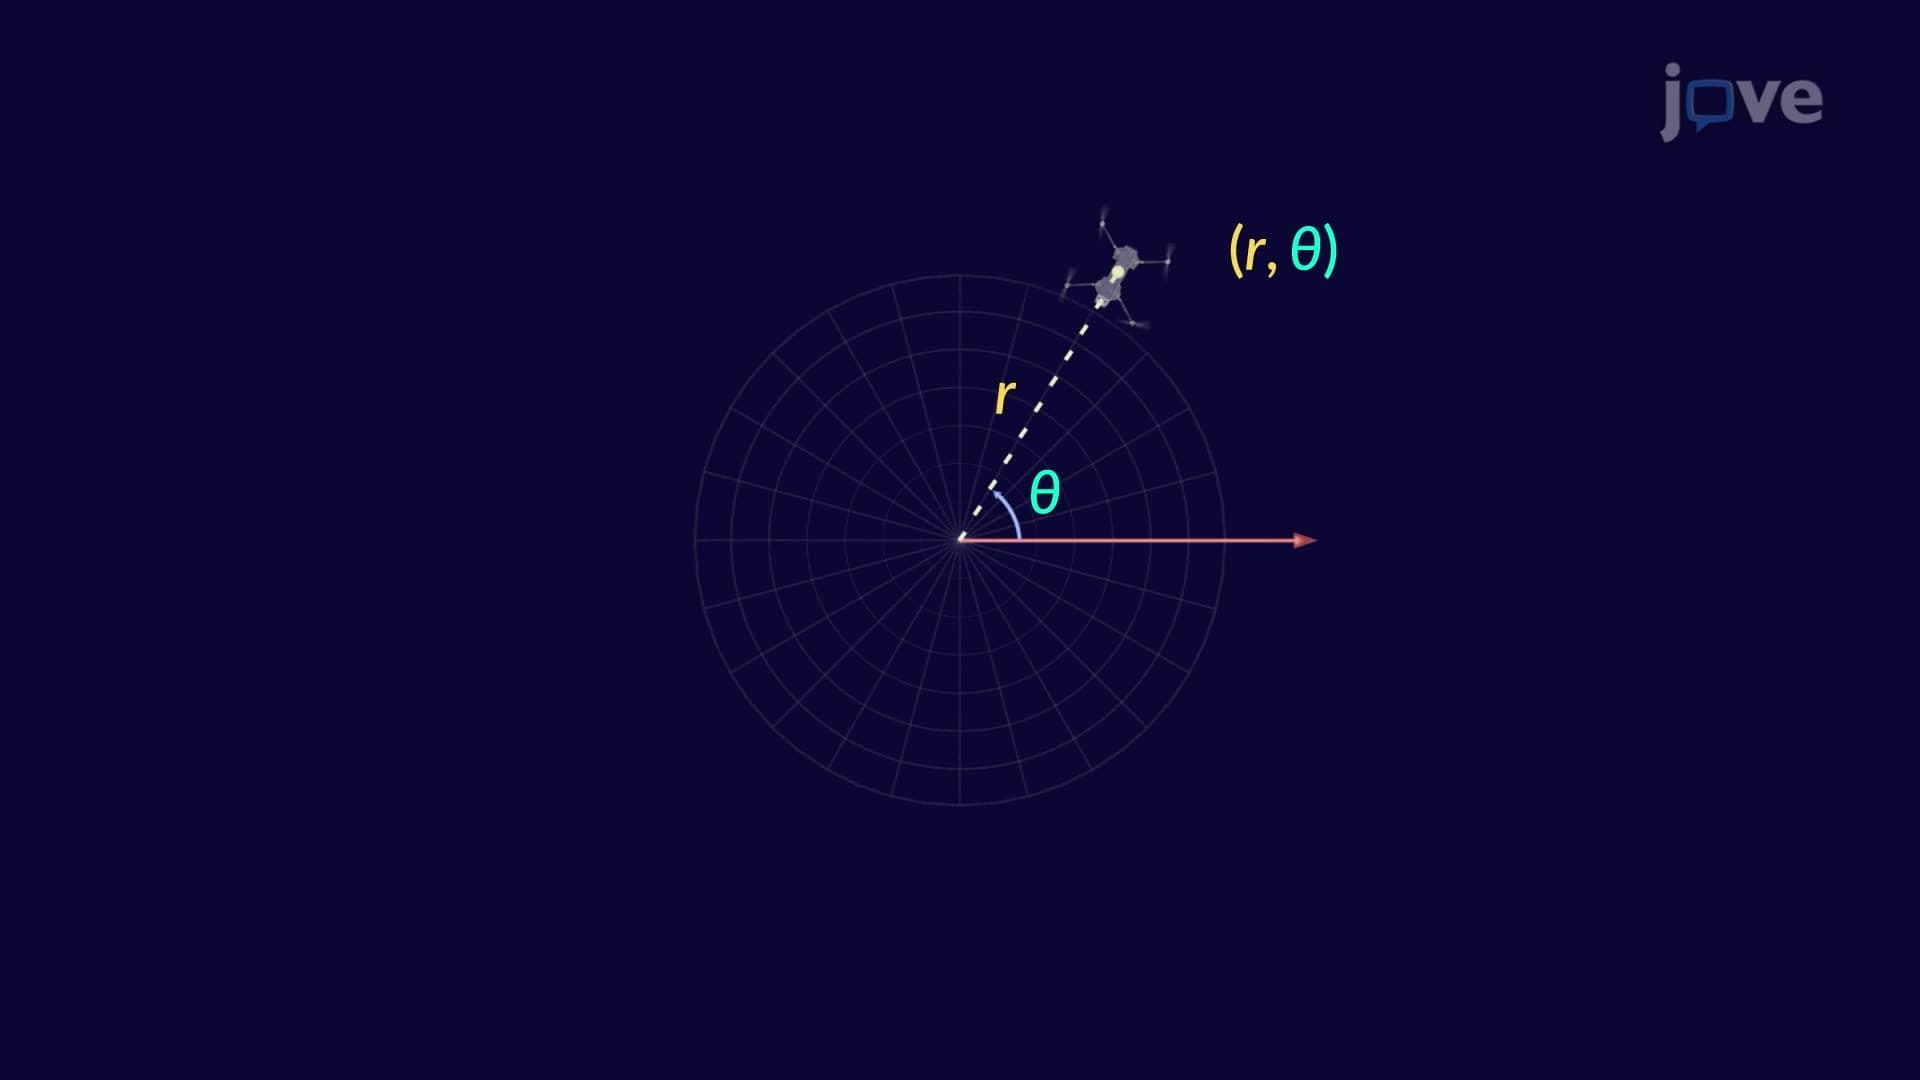
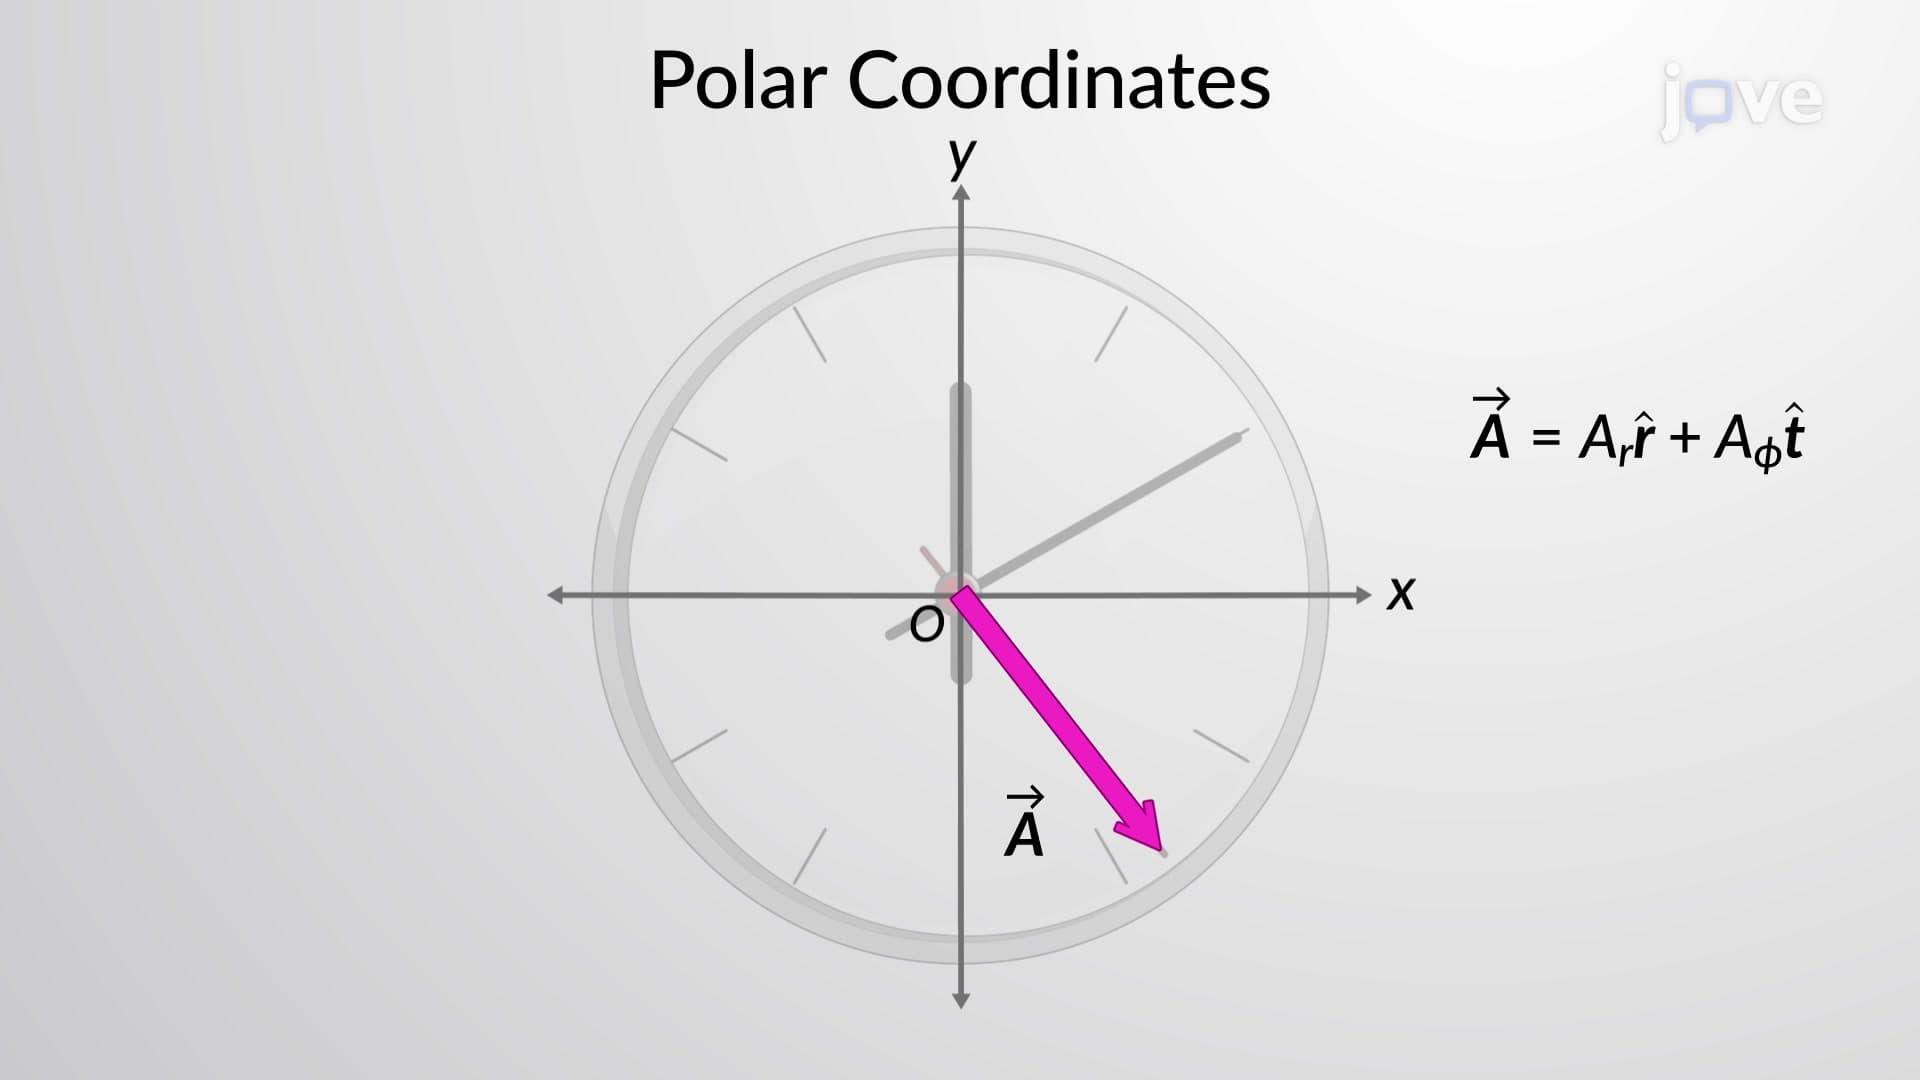
The Cartesian coordinate system is a very convenient tool to use when describing the displacements and velocities of objects and the forces acting on them. However, it becomes cumbersome when we need to describe the rotation of objects. So, when describing rotation, the polar coordinate system is generally used.
Polar Coordinates01:24

Polar Coordinates

The polar coordinate system offers an alternative to the Cartesian coordinate system for specifying points in a plane, using a distance and an angle instead of x and y coordinates. This system is particularly advantageous in situations involving circular or rotational symmetry, such as in physics or engineering problems involving waves, oscillations, or orbital paths.Defining Polar CoordinatesIn polar coordinates, a point is represented as P(r, ��), where r is the radial distance from a fixed...
Parametric Surfaces01:30

Parametric Surfaces

A parametric surface in three-dimensional space is defined through a vector-valued function\begin{equation*}\mathbf{r}(u, v) = x(u, v)\mathbf{i} + y(u, v)\mathbf{j} + z(u, v)\mathbf{k}\end{equation*}where u and v are parameters within a specified domain D in the uv-plane. The functions x(u, v), y(u, v), and z(u, v) define the coordinates of points on the surface. As u and v vary over D, the position vector r(u, v) traces a continuous surface in space. This parametric representation is essential...