Limitations of a PI controller for a first-order nonlinear process with dead time
Related Experiment Video
Updated: Aug 9, 2026

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
R Anandanatarajan1, M Chidambaram, T Jayasingh
1Pondicherry Engineering College, Pondicherry, India. ananda_natarajan@yahoo.com

Abstract:
A nonlinear process, the conical tank level process whose parameters vary with respect to the process variable, is considered. The time constant and gain of the chosen process vary as a function of level. A deliberate dead time is introduced in the system by delaying the valve opening. The limitations of the conventional PI controller tuned using Ziegler-Nichols settings for the chosen process are brought out. The servo and regulatory responses through simulation and experimentation for various magnitudes of set-point changes and load changes at various operating points with the controller tuned only at a chosen nominal operating point are obtained and analyzed. Regulatory responses for output load changes are studied. A benchmark system is presented to understand clearly how variations of system parameters affect the performance of the controller. A gain scheduled controller is proposed to handle the control problem. Present work illustrates the simplicity and effectiveness of the gain scheduling.
Related Concept Videos
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:19
PID Controller
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
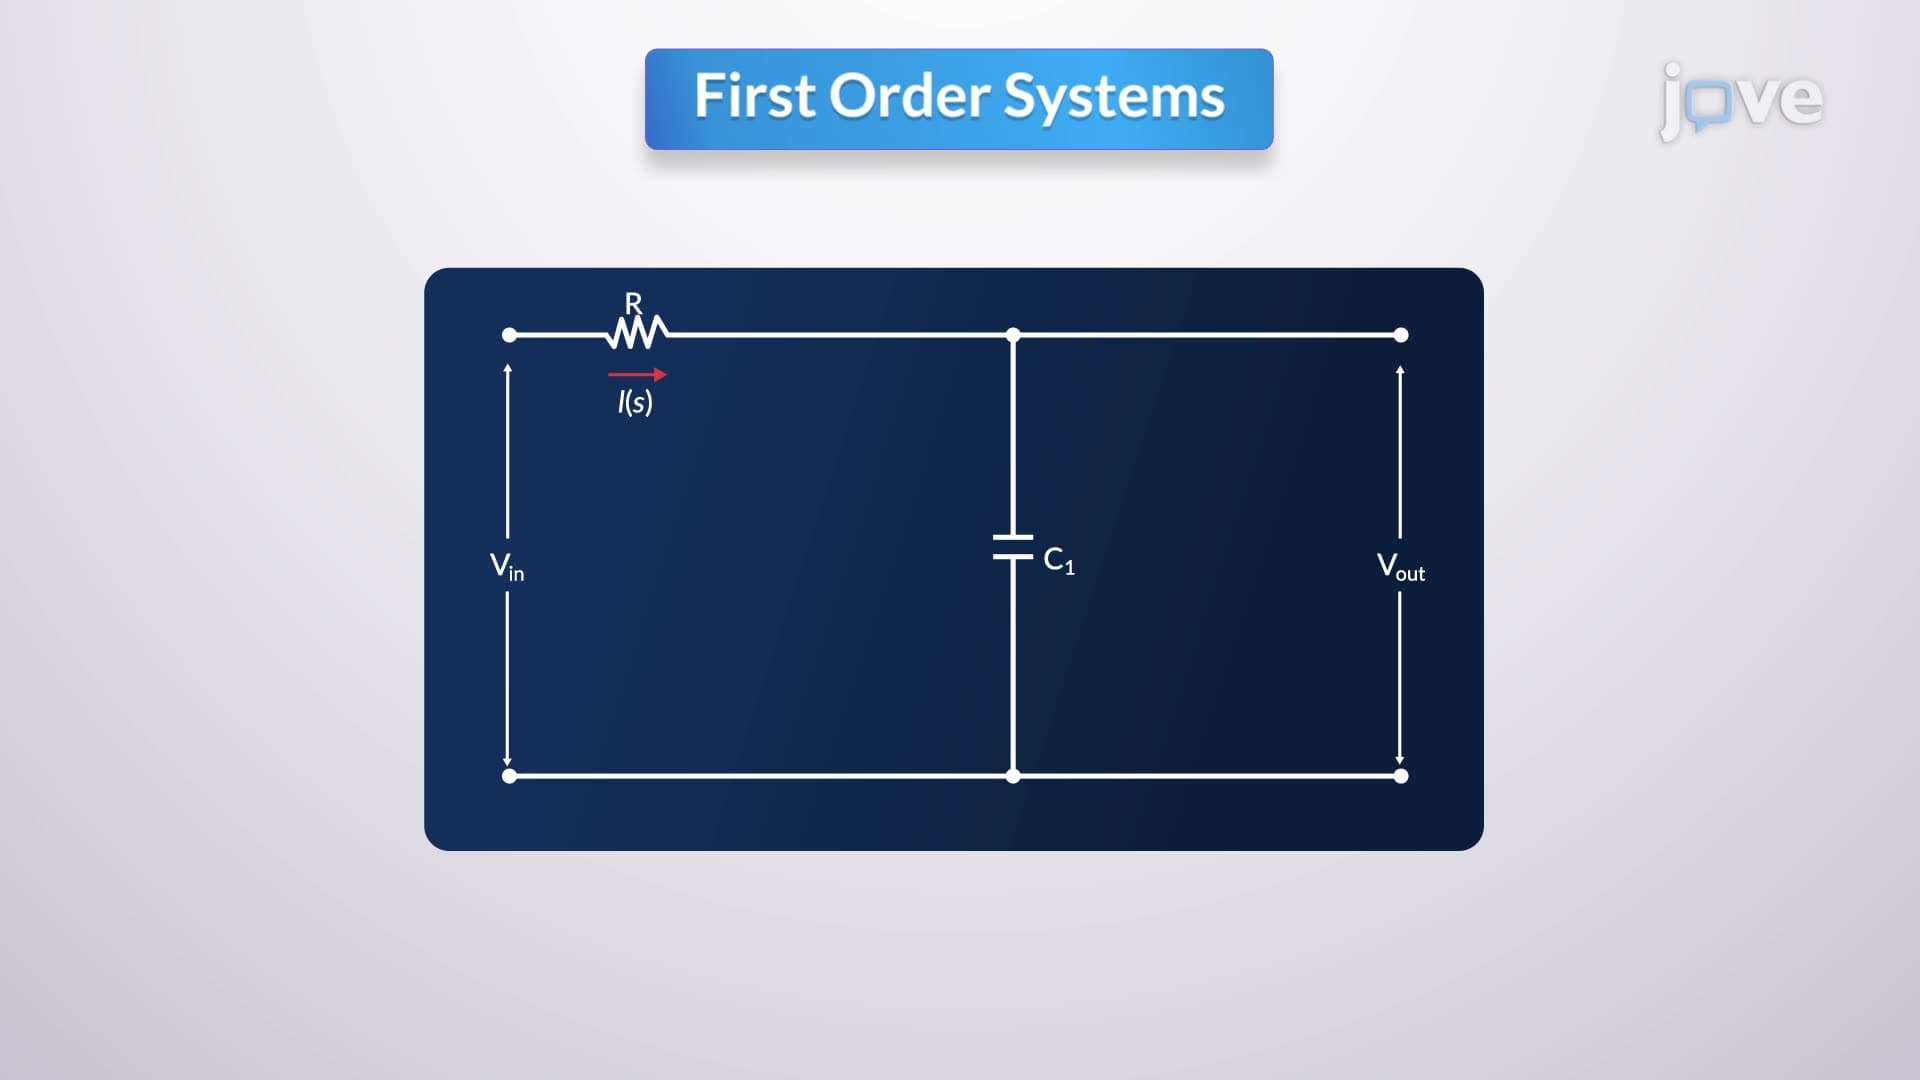
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...