Travel distance estimation from visual motion by leaky path integration
Related Experiment Video
Updated: Jul 17, 2026

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Markus Lappe1, Michael Jenkin, Laurence R Harris
1Psychological Institute II, Westf. Wilhelms-University, Fliednerstr. 21, 48149 Munster, Germany. mlappe@psy.uni-muenster.de

Abstract:
Visual motion can be a cue to travel distance when the motion signals are integrated. Distance estimates from visually simulated self-motion are imprecise, however. Previous work in our labs has given conflicting results on the imprecision: experiments by Frenz and Lappe had suggested a general underestimation of travel distance, while results from Redlick, Jenkin and Harris had shown an overestimation of travel distance. Here we describe a collaborative study that resolves the conflict by tracing it to differences in the tasks given to the subjects. With an identical set of subjects and identical visual motion simulation we show that underestimation of travel distance occurs when the task involves a judgment of distance from the starting position, and that overestimation of travel distance occurs when the task requires a judgment of the remaining distance to a particular target position. We present a leaky integrator model that explains both effects with a single mechanism. In this leaky integrator model we introduce the idea that, depending on the task, either the distance from start, or the distance to target is used as a state variable. The state variable is updated during the movement by integration over the space covered by the movement, rather than over time. In this model, travel distance mis-estimation occurs because the integration leaks and because the transformation of visual motion to travel distance involves a gain factor. Mis-estimates in both tasks can be explained with the same leak rate and gain in both conditions. Our results thus suggest that observers do not simply integrate traveled distance and then relate it to the task. Instead, the internally represented variable is either distance from the origin or distance to the goal, whichever is relevant.
Related Concept Videos
 01:29
Distance Problem
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
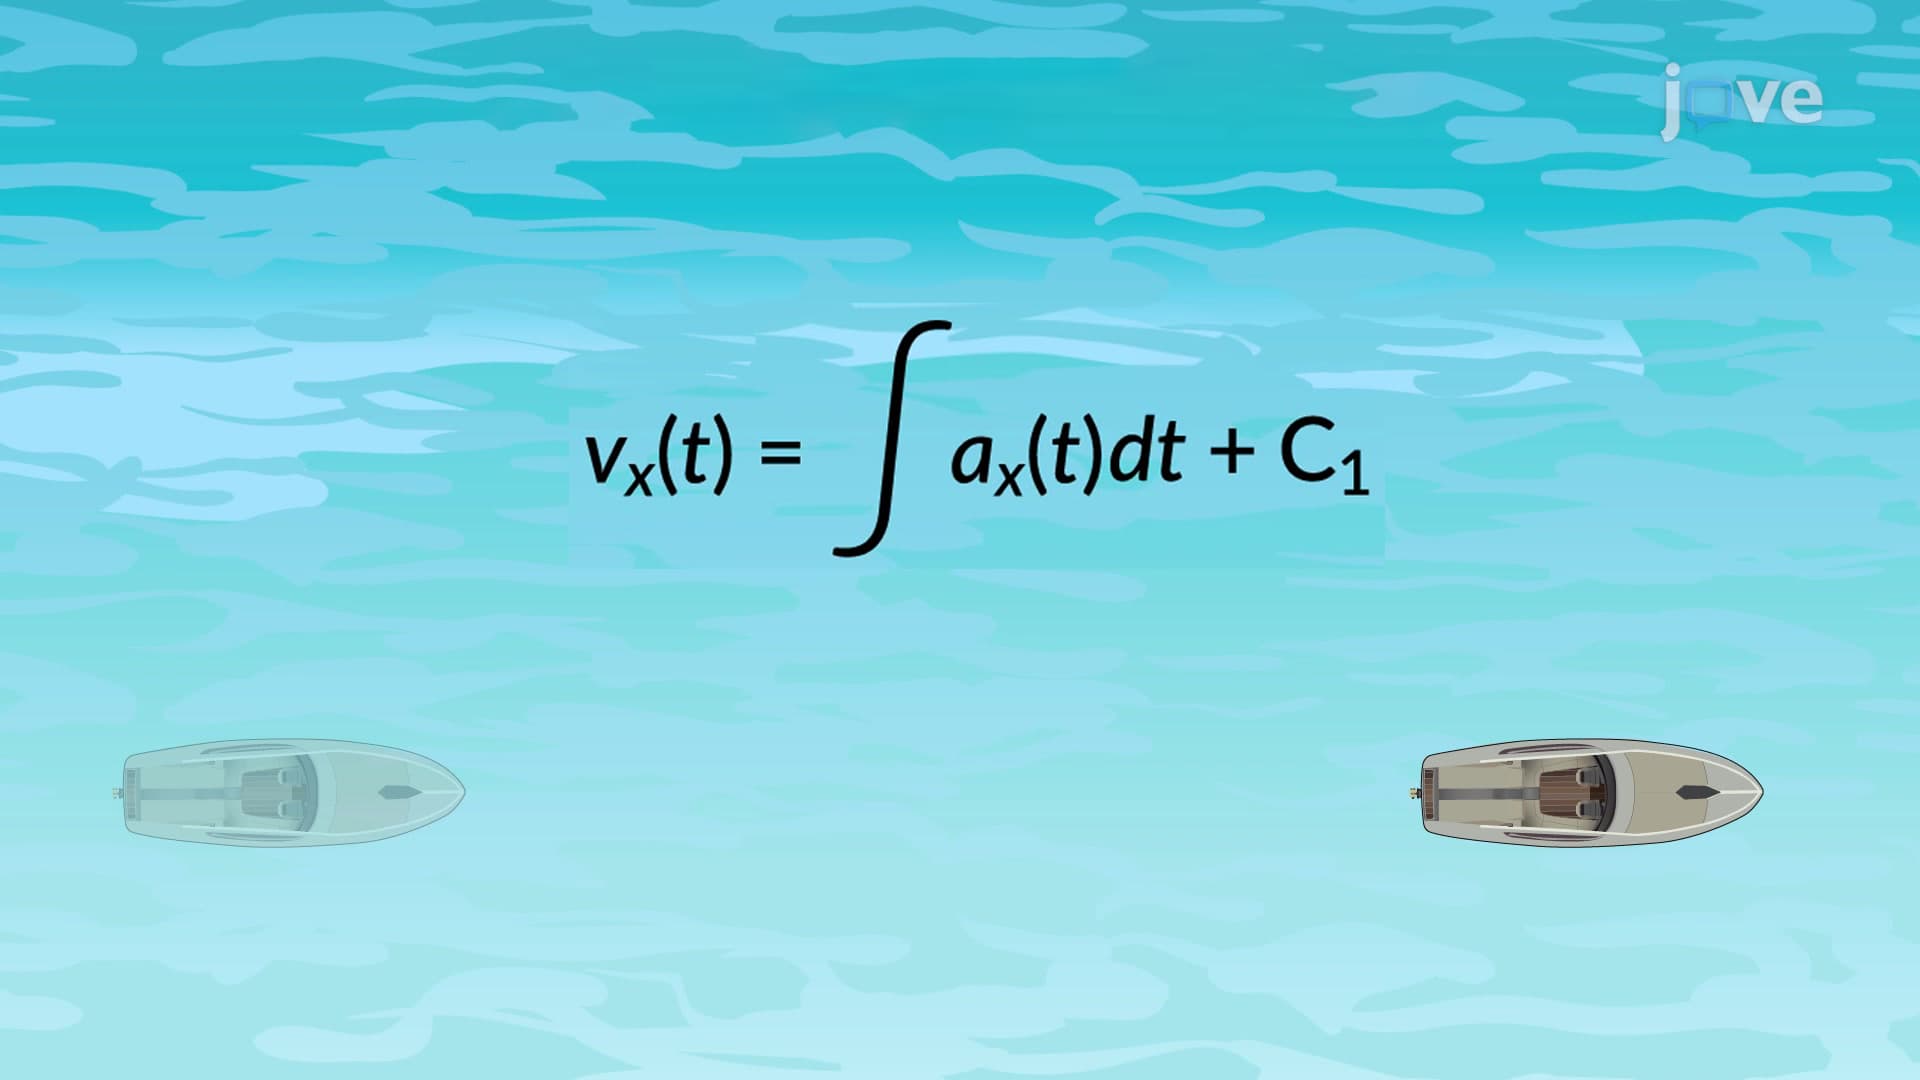 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...