Related Experiment Video
Updated: Jul 17, 2026
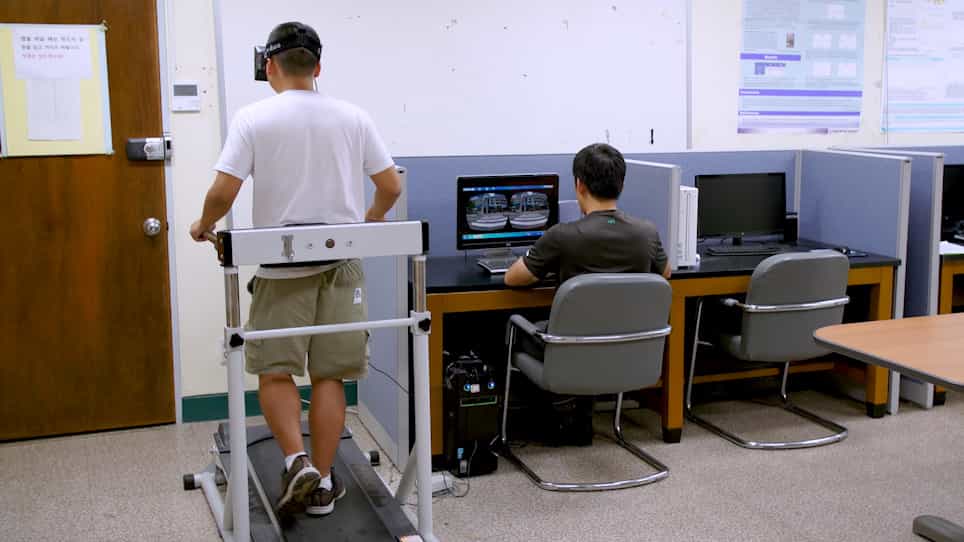

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Virtual walkway system and prediction of gait mode transition for the control of the gait simulator
N Shiozawa1, S Arima, M Makikawa
1Graduate Sch. of Sci. & Eng., Ritsumeikan Univ., Shiga, Japan.

Abstract:
A virtual walkway system is proposed in This work. This system consists of a new developed gait simulator and a HMD system to present virtual space to the user. The gait simulator is designed to permit the user to walk straight, change direction, go up and down stairs, etc. Main part of this gait simulator is two foot plates driven by three arms and actuators. Each foot plate follows the foot during swing phase and pulls it back during the stance phase while the user is walking straight However this gait simulator has one weak point, that is, this simulator cannot follow the change of gait mode sufficiently, like the start of walking or the end of walking. To solve this problem it is necessary to predict the change of gait mode to follow the transition perfectly. In this paper we chose the start and the end of straight walking and have tried to measure this transition of gait mode. To do this we paid attention on the anterior bending of the upper trunk. It is expected that the trunk bends forward before the start of walking and bends back before the stop of walking. In the experiment the distance between the upper trunk and the center of gravity (COG) was measured and it was proven that the measurement of this distance showed to be useful to know the transition of straight walking. This result was examined again on the gait simulator. Implanted control algorithm of gait simulator is as follows; two foot plates pull back the feet when the start of walking was predicted and stop when the stop of walking was predicted. Results show that the gait simulator was able to reproduce the start and the end of walking by this prediction algorithm.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016