Related Experiment Video
Updated: Jul 16, 2026
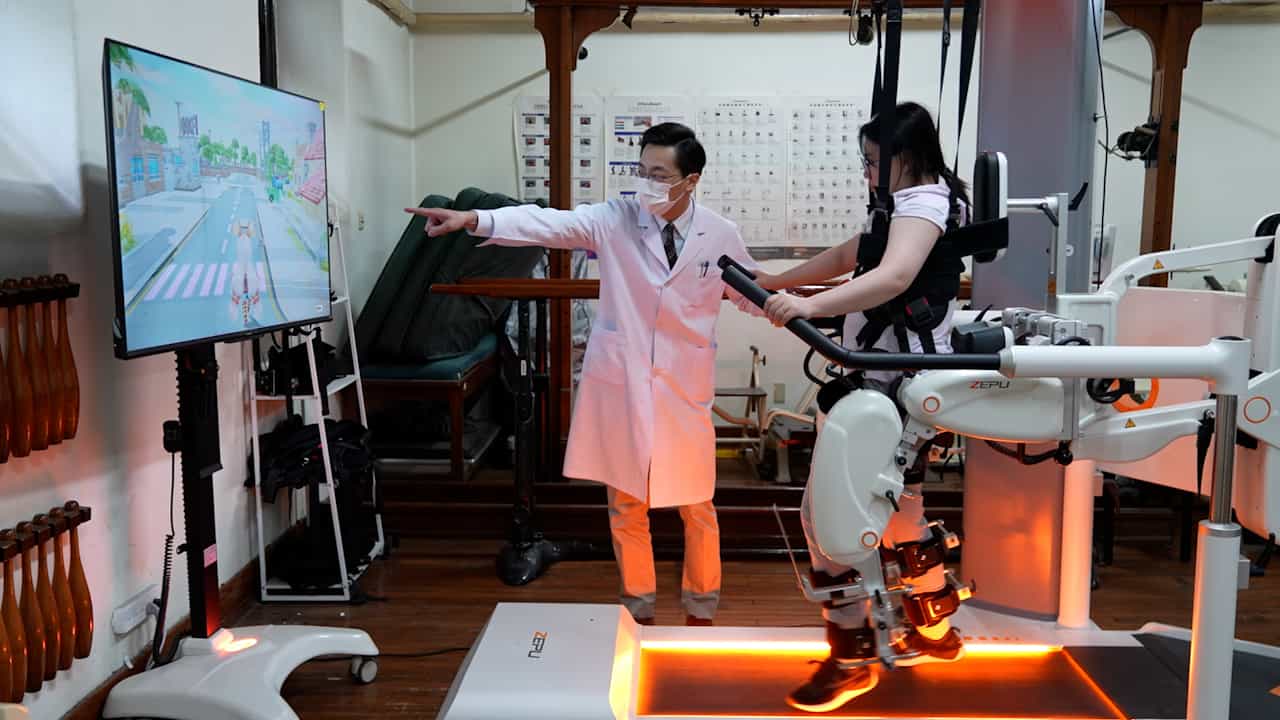

A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
Obstacle crossing in a virtual environment with the rehabilitation gait robot LOKOMAT
Mathias Wellner1, Thomas Thüring, Eldin Smajic
1Sensory-Motor Systems Group, ETH Zurich. wellner@mavt.ethz.ch

Abstract:
The rehabilitation robot LOKOMAT has been developed at the Balgrist University Hospital to automate treadmill training of spinal cord injury and stroke patients. A virtual environment setup was implemented to increase patient's motivation and provide biofeedback, consisting of visual, acoustic and haptic modalities. Based on the knee and hip angles of the orthosis, an animated figurine moves through a virtual environment. This contribution describes the setup of the system and selected technical performance parameters. We focused on delay times caused by the setup, stability of the haptic obstacle rendering and on the level of immersion as judged by four healthy subjects. Results show that subjects judged the system's performance well (questionnaire scores over 80%). Problems exist though for obstacle rendering (questionnaire scores of 55%).
More Related Videos
 05:25
An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024
 06:52
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026