Related Experiment Video
Updated: Jul 15, 2026
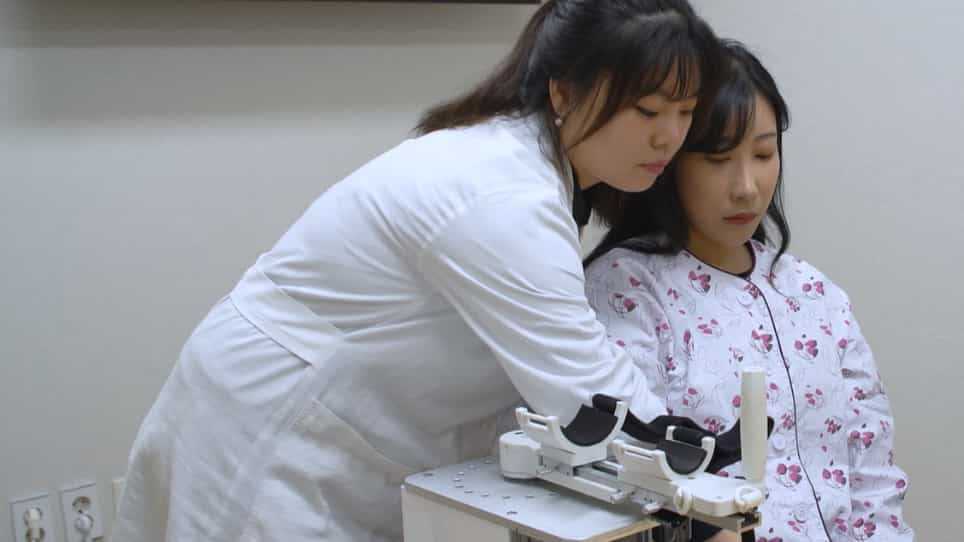
Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
Effect of joystick stiffness, movement speed and movement direction on joystick and upper limb kinematics when using
M Oliver1, M Tingley, R Rogers
1School of Engineering, University of Guelph, Guelph, Ontario, Canada N1G 2W1. moliver@uoguelph.ca

Abstract:
Despite the widespread use of hydraulic-actuation joysticks in mobile North American construction, mining and forestry vehicles, the biomechanical effects that joysticks have on their human operators has not been studied extensively. Using nine unskilled joystick operators and a laboratory mock-up with a commonly used North American heavy off-road equipment hydraulic-actuation joystick and operator seat, the purpose of this work was to quantify and compare the effects of three hydraulic-actuation joystick stiffnesses and two movement speeds on upper limb and joystick kinematics as one of the initial steps towards the development of a hydraulic-actuation joystick design protocol. In addition to providing a detailed description of the kinematics of a constrained occupational task, coupled with the corresponding effects of the task on operator upper limb kinematics, results from principal component analysis and ANOVA procedures revealed a number of differences in joystick and upper limb angle ranges and movement curve shapes resulting from the various joystick stiffness-speed combinations tested. For the most part, these joystick motion alterations were caused by small, insignificant changes in one or more upper limb joint angles. The two exceptions occurred for forward movements of the joystick; the fast speed - light stiffness condition movement pattern shape change was caused primarily by an alteration of the elbow flexion-extension movement pattern. Similarly, the fast speed - normal stiffness condition movement curve shape perturbation - was caused principally by a combination of significant movement curve shape alterations to elbow flexion-extension, external-internal shoulder rotation and flexion-extension of the shoulder. The finding that joystick stiffness and speed alterations affect joystick and upper limb kinematics minimally indicates that the joystick design approach of modelling the joystick and operator upper limb as a closed linkage system should be pursued. This approach would allow one to simulate the upper limb and joystick kinematics that result from virtual changes to upper limb and joystick lengths.
Related Concept Videos
 01:21
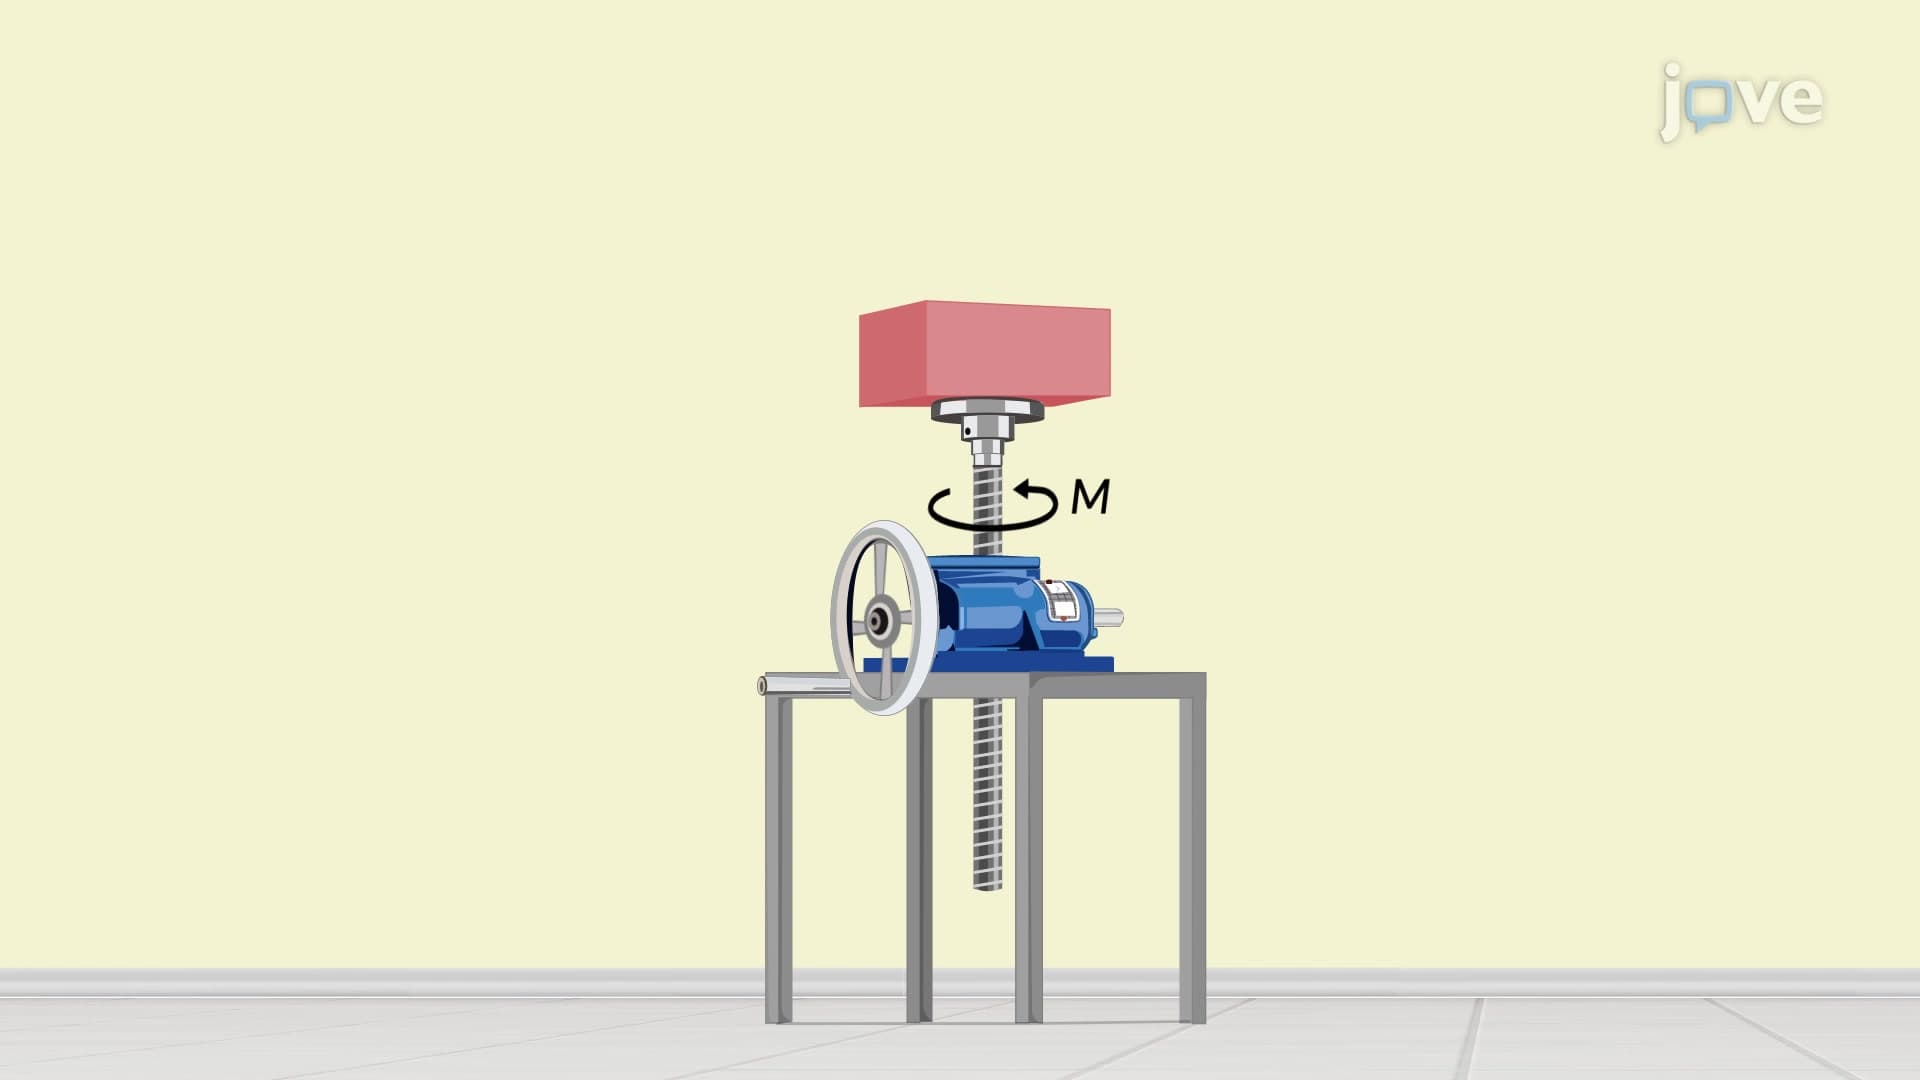
Upward Impending Motion
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...
 01:03
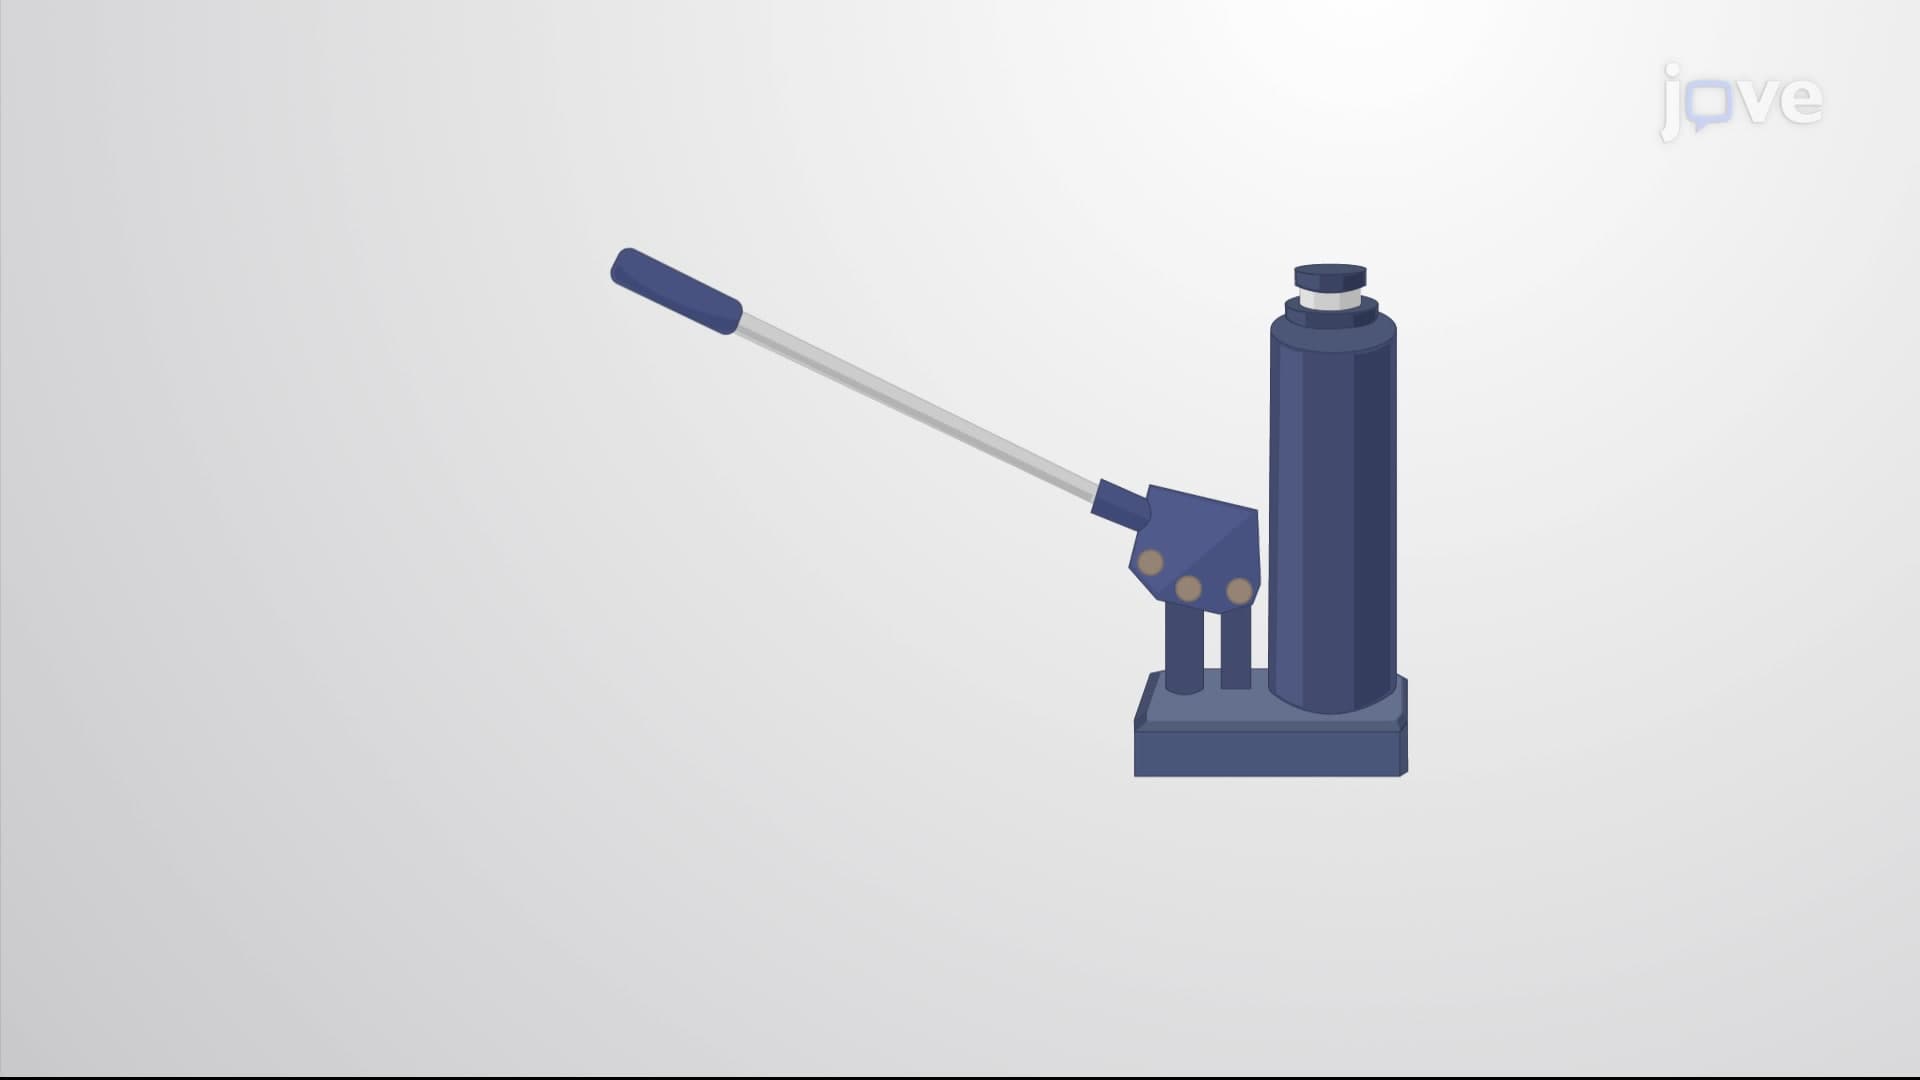
Application of Pascal's Law
Hydraulic systems are used to operate automotive brakes, hydraulic jacks, and numerous other mechanical systems. We can derive a relationship between the forces in a simple hydraulic system by applying...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:17
Rolling Resistance: Problem Solving
 01:18
Hierarchy of Motor Control
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...