Related Experiment Video
Updated: Jul 11, 2026

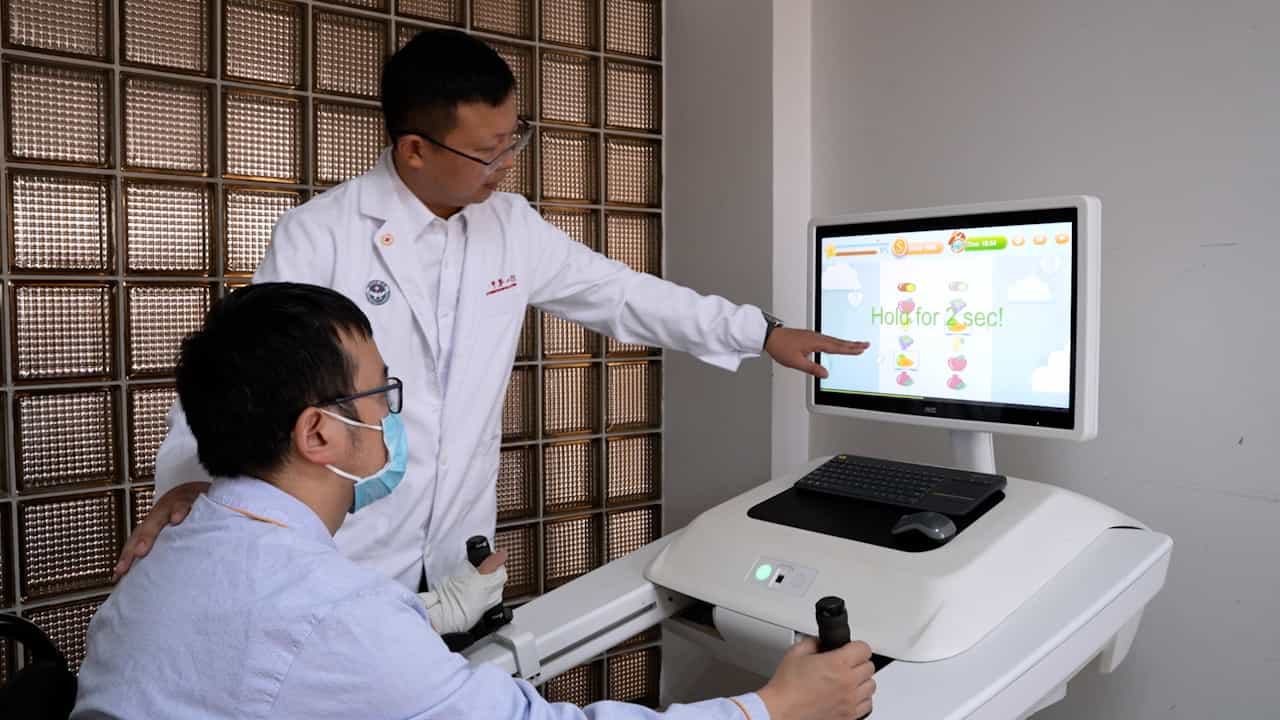
Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Control system design of a 3-DOF upper limbs rehabilitation robot
Alexandre Denève1, Saïd Moughamir, Lissan Afilal
1Centre de Recherche en Sciences et Technologies de l'Information et de la Communication, Université de Reims Champagne-Ardenne, Reims Cedex 2, France.

Abstract:
This paper presents the control system design of a rehabilitation and training robot for the upper limbs. Based on a hierarchical structure, this control system allows the execution of sequence of switching control laws (position, force, impedance and force/impedance) corresponding to the required training configuration. A model-based nonlinear controller is used to impose the desired environment to the patient's arm. The knowledge of robot kinematics and dynamics is thus necessary to ensure haptic transparency and patient safety. The identification process of robot dynamics is emphasised and experimental identification results are given for the designed robot. The paper also presents a particular rehabilitation mode named Active-Assisted. Simulation results of this rehabilitation mode illustrate the potentialities of the overall control scheme, which can also be applied to other rehabilitation robots.
More Related Videos
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:30
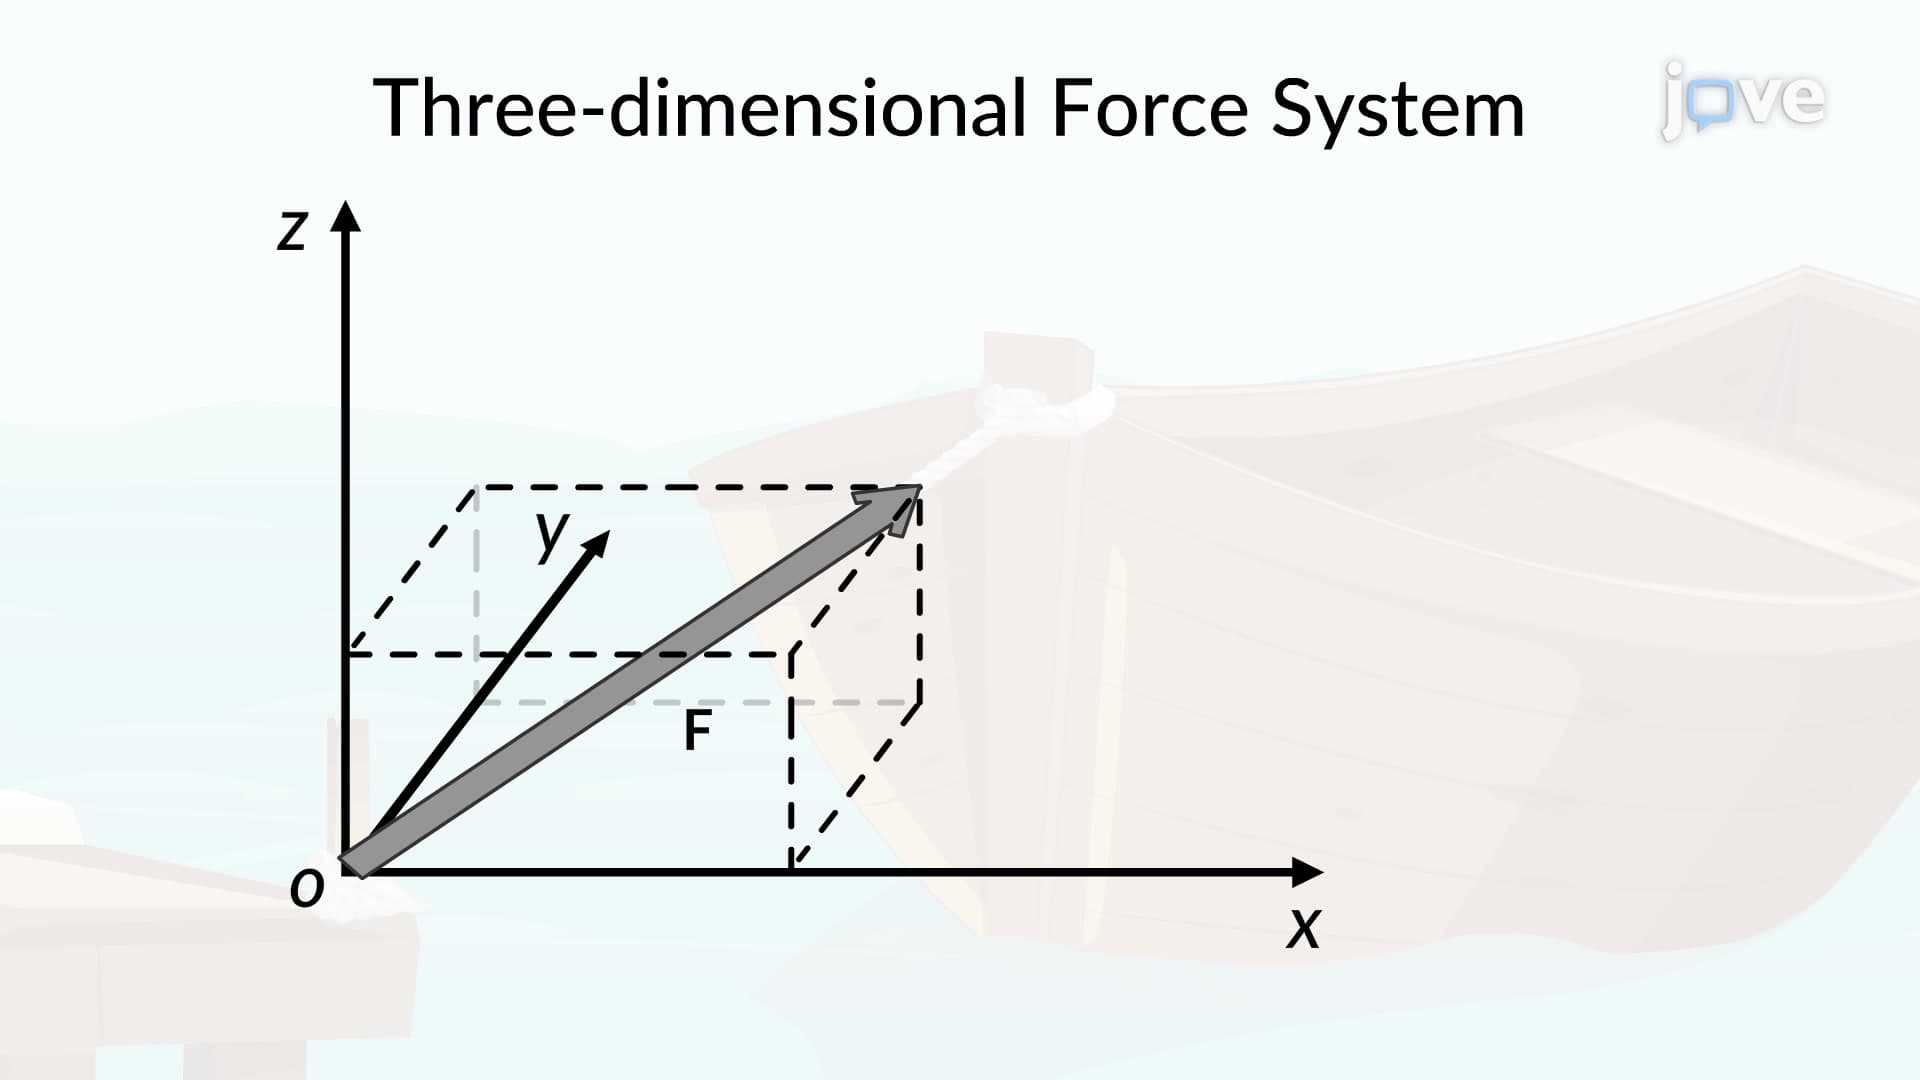
Three-Dimensional Force System
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...