On linear variational surface deformation methods
Related Experiment Video
Updated: Jul 10, 2026
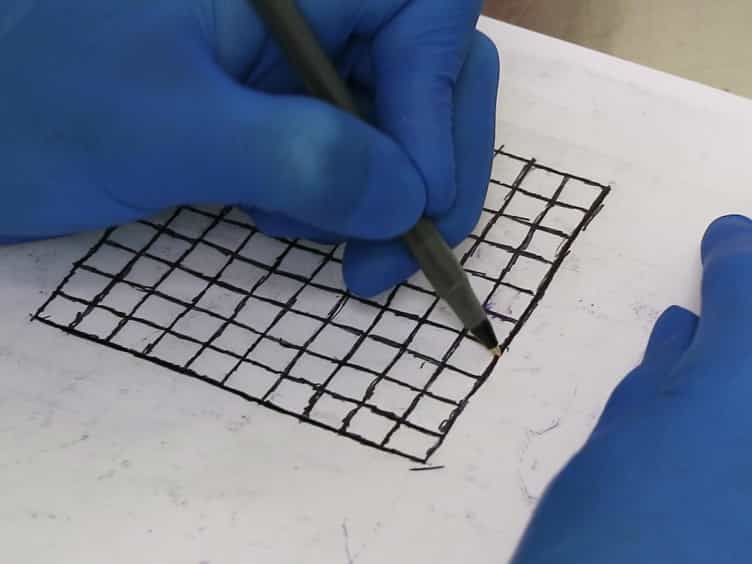
Quantification of Strain in a Porcine Model of Skin Expansion Using Multi-View Stereo and Isogeometric Kinematics
Published on: April 16, 2017
1Computer Graphis Laboratory, ETH Zurich, Zurich, Switzerland. botsch@inf.ethz.ch

Abstract:
This survey reviews the recent advances in linear variational mesh deformation techniques. These methods were developed for editing detailed high-resolution meshes, like those produced by scanning real-world objects. The challenge of manipulating such complex surfaces is three-fold: the deformation technique has to be sufficiently fast, robust, and intuitive and easy to control to be useful for interactive applications. An intuitive, and thus predictable, deformation tool should provide physically plausible and aesthetically pleasing surface deformations, which in particular requires its geometric details to be preserved. The methods we survey generally formulate surface deformation as a global variational optimization problem that addresses the differential properties of the edited surface. Efficiency and robustness are achieved by linearizing the underlying objective functional, such that the global optimization amounts to solving a sparse linear system of equations. We review the different deformation energies and detail preservation techniques that were proposed in the recent years, together with the various techniques to rectify the linearization artifacts. Our goal is to provide the reader with a systematic classification and comparative description of the different techniques, revealing the strengths and weaknesses of each approach in common editing scenarios.
Related Concept Videos
 01:14
Bending of Curved Members - Strain Analysis
The important part of bending analysis for such a member is the...
 01:12
Transformation of Plane Strain
Under plane strain conditions, typical for members where one dimension significantly exceeds the others, deformations and resultant strains are...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:30
Parametric Surfaces
 01:23
Linear Approximations
 01:22
Tangent Planes to a Parametric Surface