Related Experiment Video
Updated: Jul 9, 2026
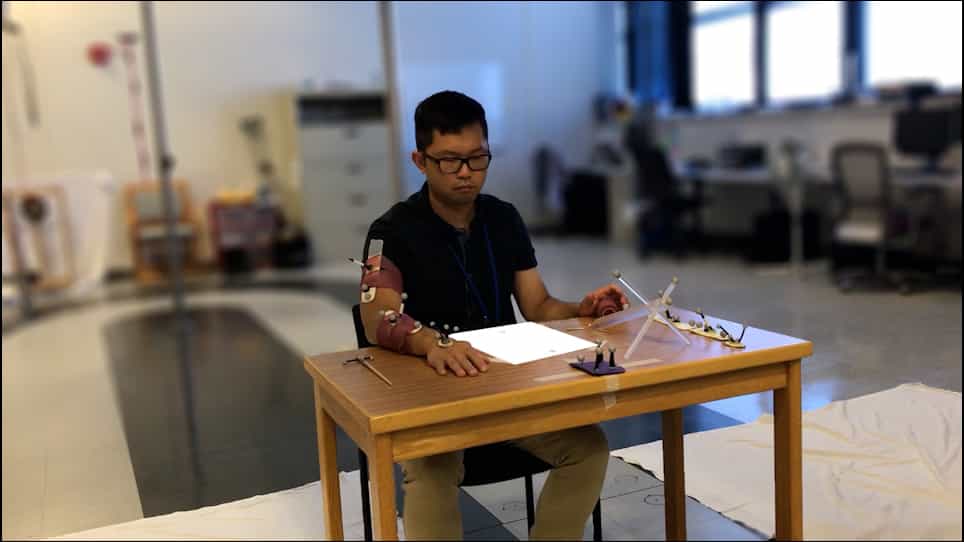

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Minimum acceleration criterion with constraints implies bang-bang control as an underlying principle for optimal
Shay Ben-Itzhak1, Amir Karniel
1Department of Electrical Engineering, Technion-Israel Institute of Technology, Haifa, Israel. bshay100@hotmail.com

Abstract:
Rapid arm-reaching movements serve as an excellent test bed for any theory about trajectory formation. How are these movements planned? A minimum acceleration criterion has been examined in the past, and the solution obtained, based on the Euler-Poisson equation, failed to predict that the hand would begin and end the movement at rest (i.e., with zero acceleration). Therefore, this criterion was rejected in favor of the minimum jerk, which was proved to be successful in describing many features of human movements. This letter follows an alternative approach and solves the minimum acceleration problem with constraints using Pontryagin's minimum principle. We use the minimum principle to obtain minimum acceleration trajectories and use the jerk as a control signal. In order to find a solution that does not include nonphysiological impulse functions, constraints on the maximum and minimum jerk values are assumed. The analytical solution provides a three-phase piecewise constant jerk signal (bang-bang control) where the magnitude of the jerk and the two switching times depend on the magnitude of the maximum and minimum available jerk values. This result fits the observed trajectories of reaching movements and takes into account both the extrinsic coordinates and the muscle limitations in a single framework. The minimum acceleration with constraints principle is discussed as a unifying approach for many observations about the neural control of movements.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:10
Relative Motion Analysis - Acceleration
 01:26
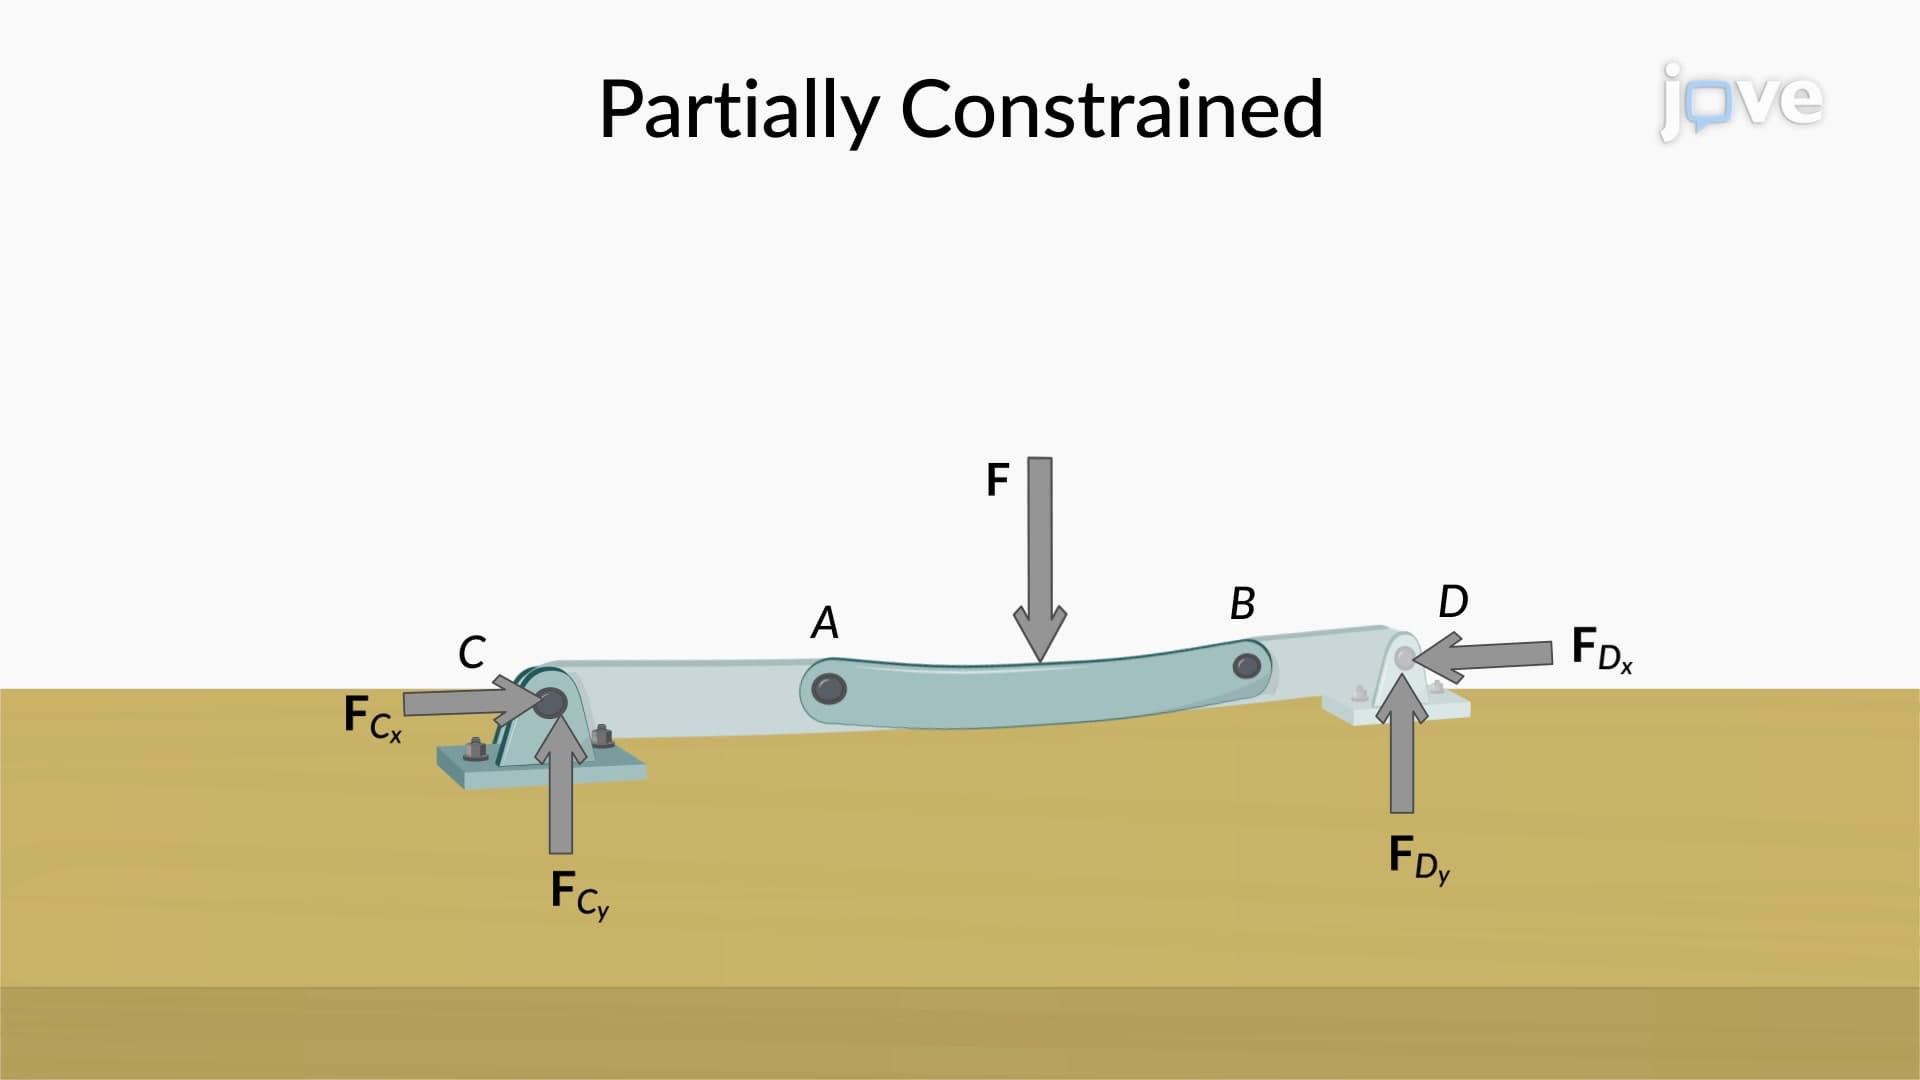
Constraints and Statical Determinacy
 01:21
Upward Impending Motion
To better comprehend how a screw jack functions, consider the completely unraveled thread as a block in contact with the...
 01:24
Normal and Tangetial Components: Problem Solving
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...