Constraint integration for efficient multiview pose estimation with self-occlusions

Related Experiment Videos

Abhinav Gupta1, Anurag Mittal, Larry S Davis

  • 1Department of Computer Science, University of Maryland College Park, College Park, MD 20742, USA. agupta@cs.umd.edu

Related Concept Videos

Kinematic Equations - III01:18

Kinematic Equations - III

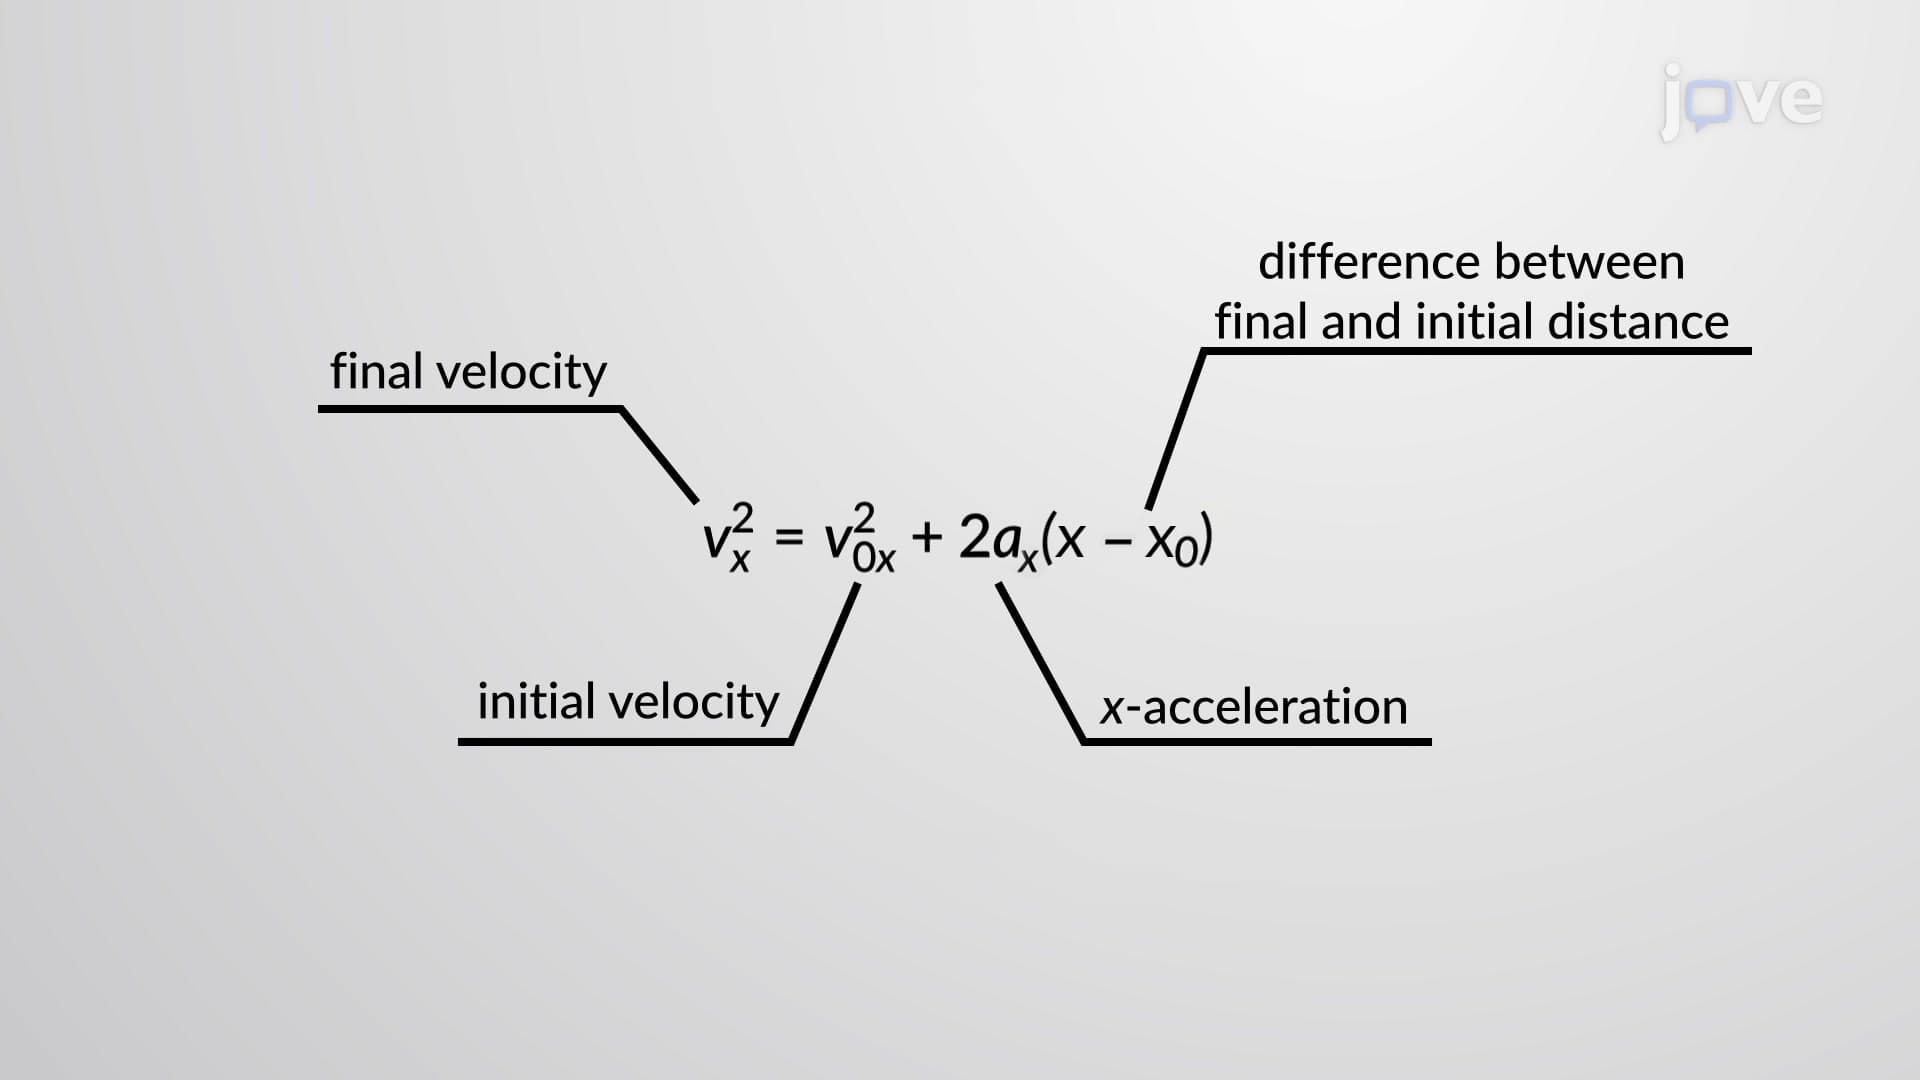
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Multicompartment Models: Overview01:14

Multicompartment Models: Overview

Multicompartment models are mathematical constructs that depict how drugs are distributed and eliminated within the body. They segment the body into several compartments, symbolizing various physiological or anatomical areas connected through drug transfer processes such as absorption, metabolism, distribution, and elimination.
These models offer a more comprehensive representation of drug behavior in the body than one-compartment models. They accommodate the complexity of drug distribution,...
Structural Classification of Joints01:20

Structural Classification of Joints

Joints, also known as articulations, are classified based on their structural characteristics, i.e., based on whether the articulating surfaces of the adjacent bones are directly connected by fibrous connective tissue or cartilage, or whether the articulating surfaces contact each other within a fluid-filled joint cavity. These differences serve to divide the joints of the body into three structural classifications.
A fibrous joint is where the adjacent bones are united by fibrous connective...

Kinematic Equations: Problem Solving01:15

Kinematic Equations: Problem Solving

When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
Relative Motion Analysis using Rotating Axes-Problem Solving01:29

Relative Motion Analysis using Rotating Axes-Problem Solving

Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Lagrange Multipliers: One Constraint01:29

Lagrange Multipliers: One Constraint

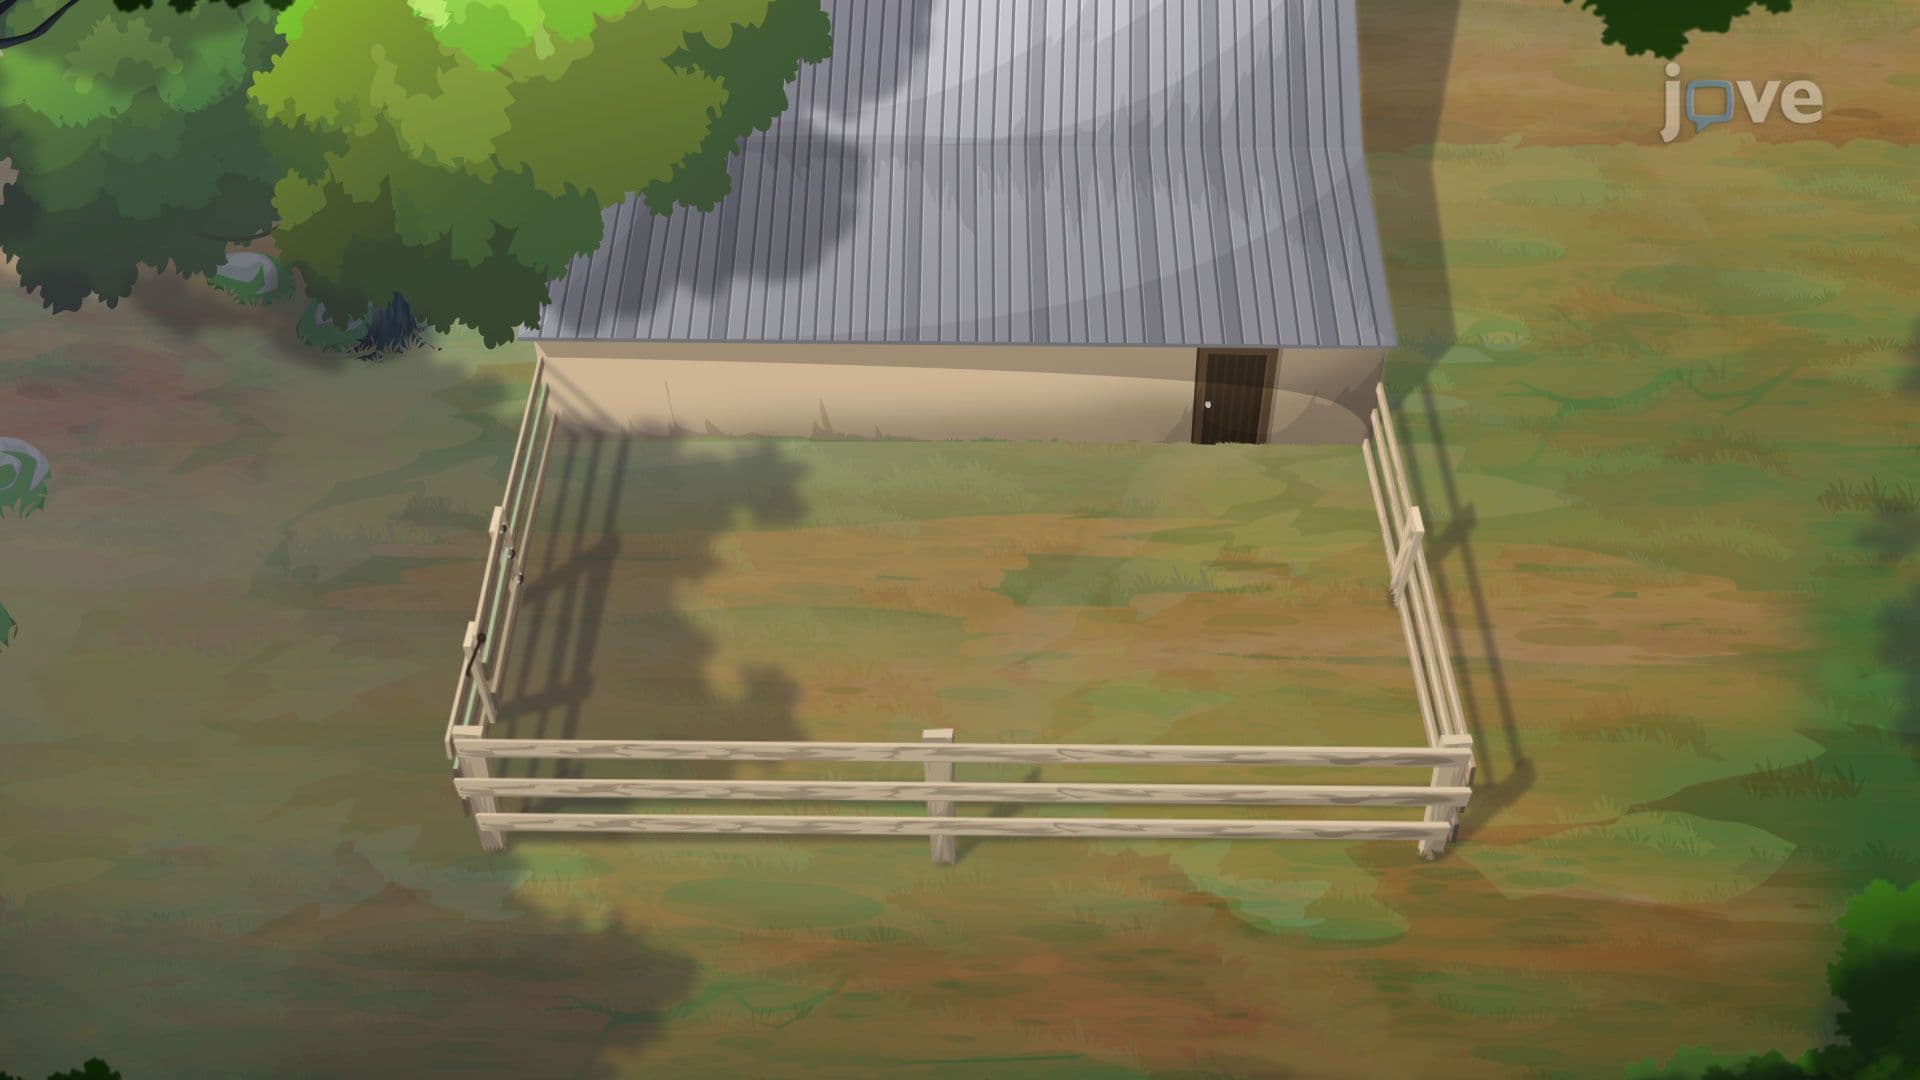
In constrained optimization, the objective is to maximize or minimize a quantity while satisfying a fixed condition. A standard example is a rectangular pen built against a barn wall using 100 meters of fencing. Because the wall provides one side of the enclosure, only the other three sides require fencing. The problem is to find the dimensions that produce the greatest possible area.Let L represent the length parallel to the wall and W the width perpendicular to it. The area of the pen is A =...